
Pedestrian-centric Augmented Reality Visualization of Real-time Autonomous Vehicle Dynamics
Workshop on Intelligent Cloud Continuum for B5G Services in the IEEE International Conference on Cloud Networking (CloudNet 2023), New York City, USA, 2023年11月4日
PDFDOI: 10.1109/CloudNet59005.2023.10490048
3行要約
- 実際に稼働するコネクテッド車両からデータを受け取り、歩行者向けにARで表示する。
- 実地実験と展示での利用者アンケートにより、車両情報が伝わるか調べた。
- 追加の情報を提示すると、参加者は車両に対して安全だと感じやすかった。
論文の図
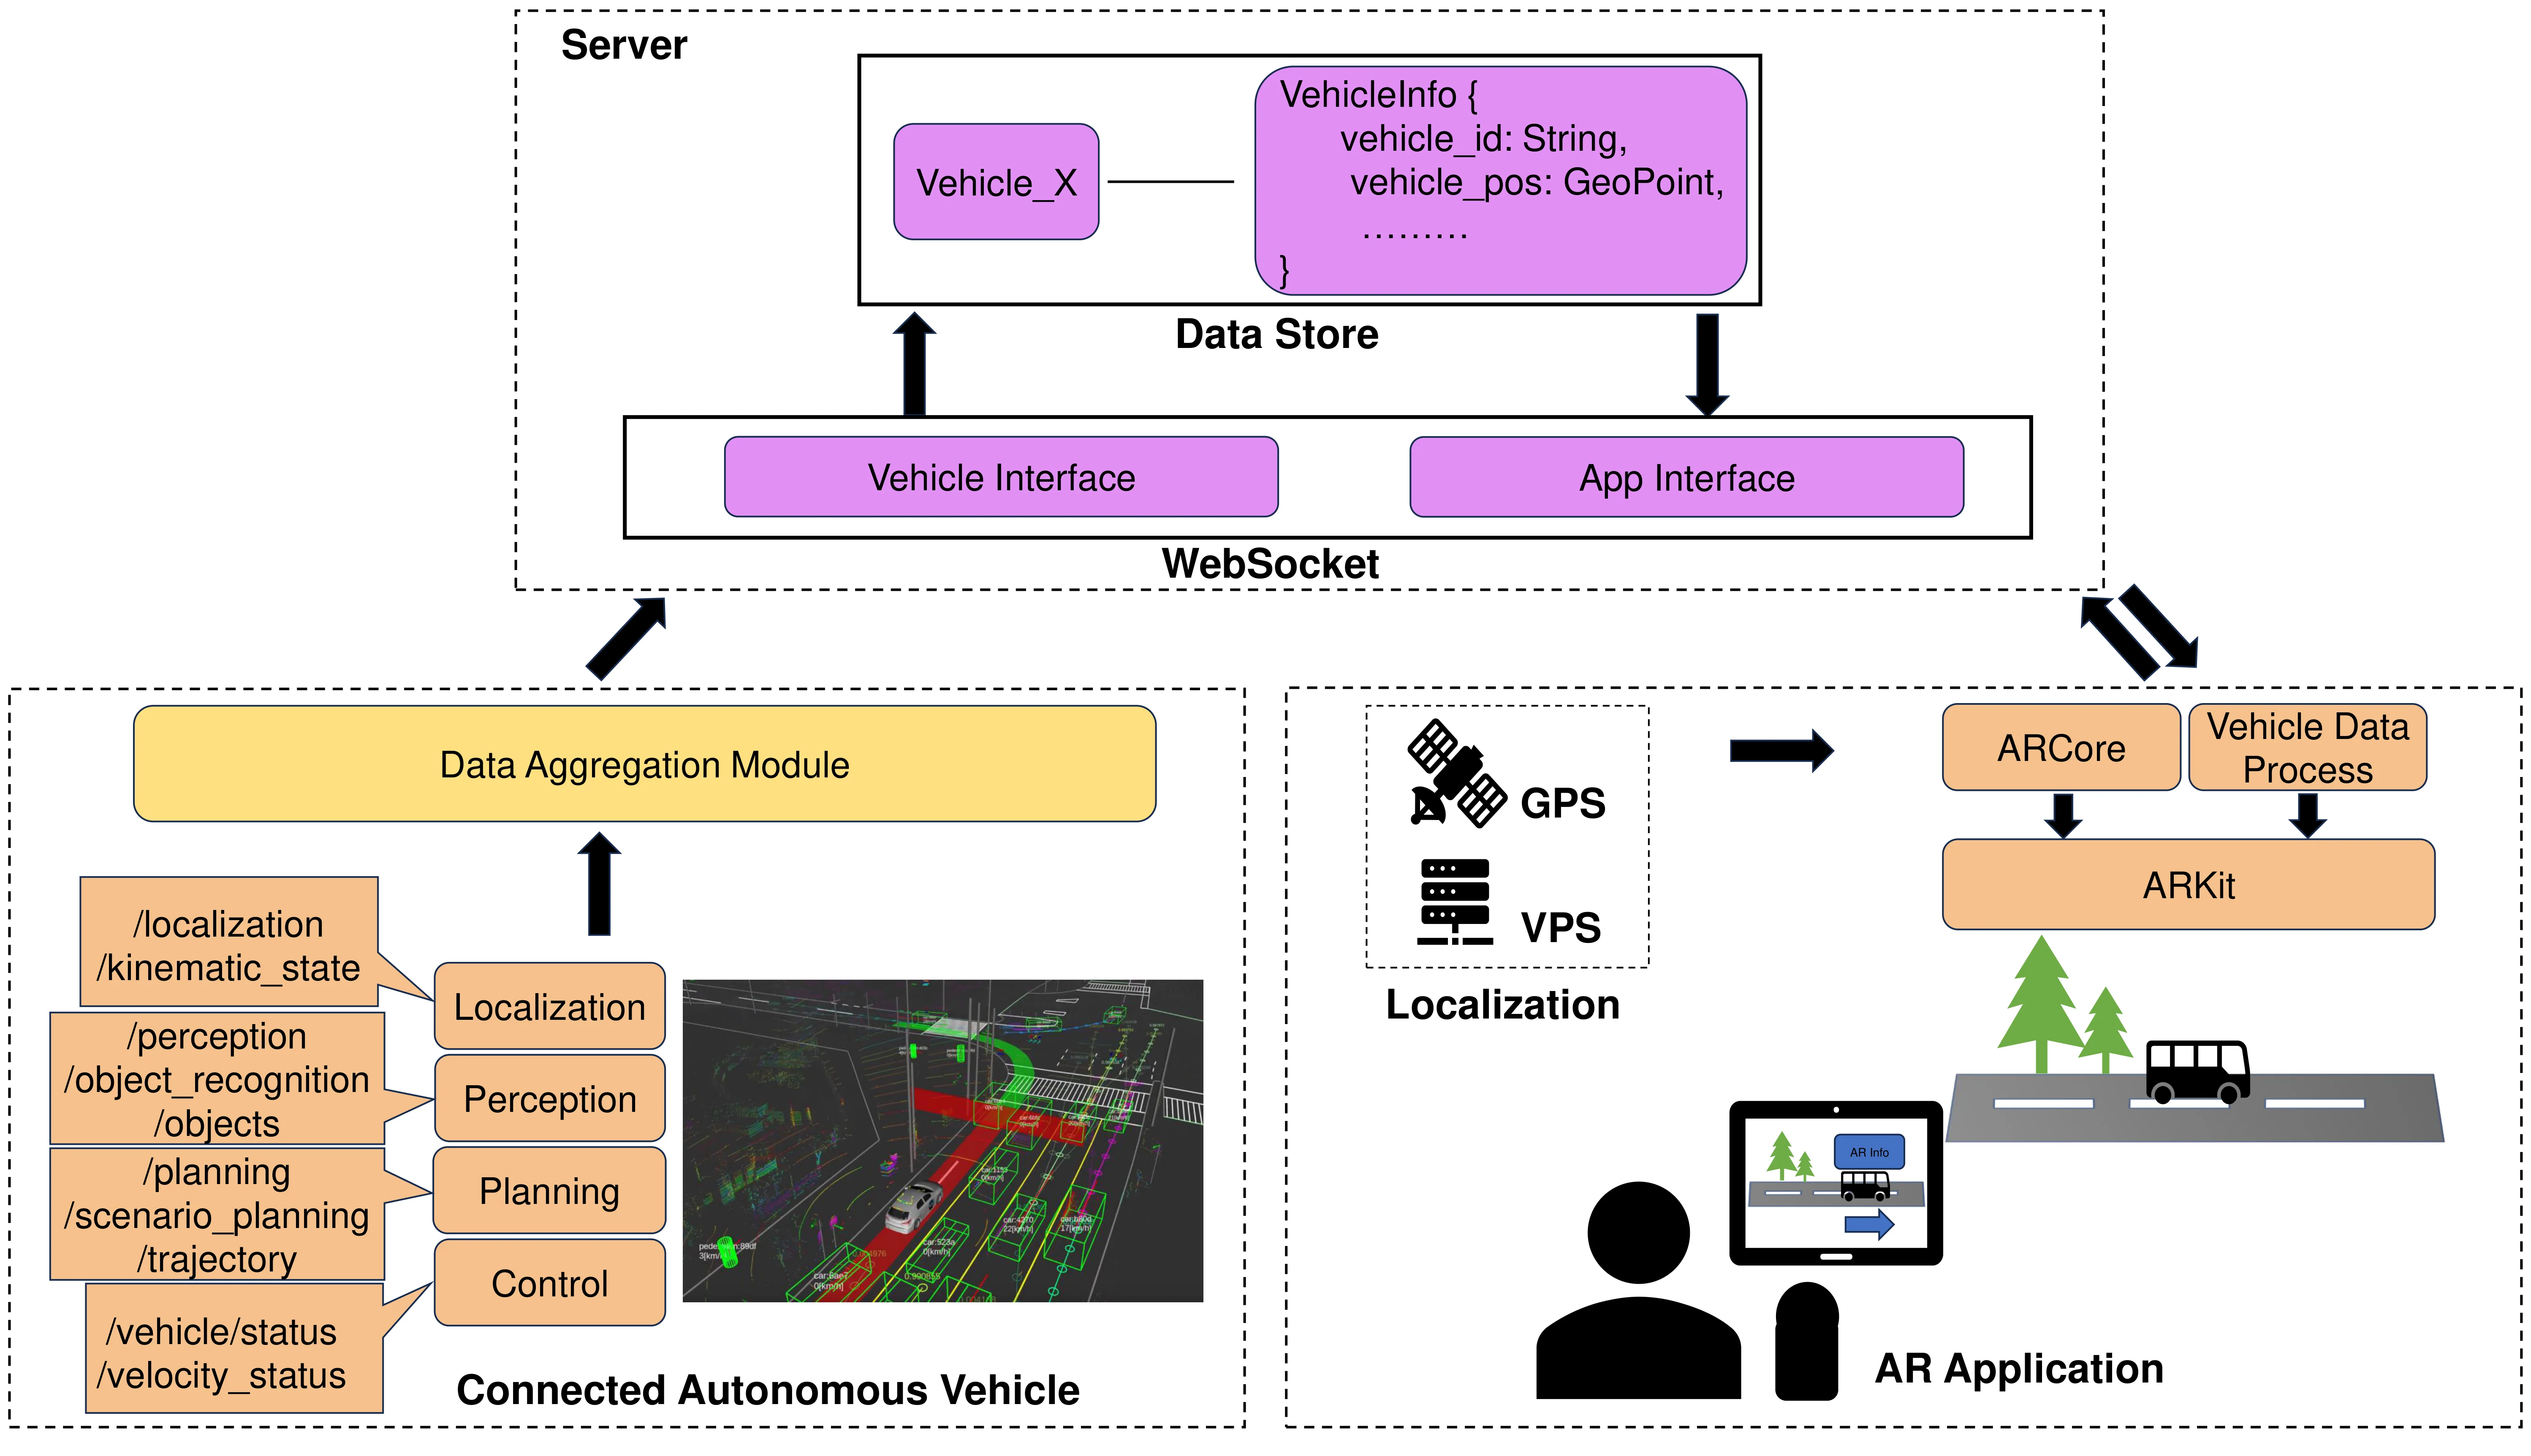
アブストラクト(原文)
Connected Autonomous Vehicles (CAVs) produce a variety of information within their systems. With the advancement of communication and V2X (Vehicle-to-Everything) communication technology, there is a growing challenge to effectively convey this information to pedestrians and enhance their sense of safety when encountering such vehicles. Efforts to communicate this information to pedestrians have been made through various means, with Augmented Reality (AR) emerging as a notable approach. However, previous studies have yet to integrate a functional AR application with a real-world autonomous driving system. In response to this gap, we proposed an architecture for an AR application that visualizes real-time data from an active CAV and subsequently developed the system. Furthermore, we conducted field experiments using this developed system and conducted user surveys during exhibitions to gather insights into the public’s perception of the system. Our results showed that the system can effectively transmit information from the CAV, and when provided with additional information, people tend to feel safer regarding the vehicle.
関連ニュース
引用方法
Y. Cheng, J. Nakazato, E. Javanmardi, C.-M. Chang, and M. Tsukada, “Pedestrian-centric Augmented Reality Visualization of Real-time Autonomous Vehicle Dynamics,” in Workshop on Intelligent Cloud Continuum for B5G Services in the IEEE International Conference on Cloud Networking (CloudNet 2023), New York City, USA, 2023, doi: 10.1109/CloudNet59005.2023.10490048.
BibTeX
@workshop{Cheng2023,
  title         = {Pedestrian-centric Augmented Reality Visualization of Real-time Autonomous Vehicle Dynamics},
  author        = {Yiwei Cheng and Jin Nakazato and Ehsan Javanmardi and Chia-Ming Chang and Manabu Tsukada},
  url           = {https://www.researchgate.net/profile/Jin-Nakazato/publication/374387897_Pedestrian-centric_Augmented_Reality_Visualization_of_Real-time_Autonomous_Vehicle_Dynamics/links/651bda961e2386049df3c4ee/Pedestrian-centric-Augmented-Reality-Visualization-of-Real-time-Autonomous-Vehicle-Dynamics.pdf},
  doi           = {10.1109/CloudNet59005.2023.10490048},
  year          = {2023},
  date          = {2023-11-04},
  urldate       = {2023-11-04},
  booktitle     = {Workshop on Intelligent Cloud Continuum for B5G Services in the IEEE International Conference on Cloud Networking (CloudNet 2023)},
  address       = {New York City, USA},
  abstract      = {Connected Autonomous Vehicles (CAVs) produce a variety of information within their systems. With the advancement of communication and V2X (Vehicle-to-Everything) communication technology, there is a growing challenge to effectively convey this information to pedestrians and enhance their sense of safety when encountering such vehicles. Efforts to communicate this information to pedestrians have been made through various means, with Augmented Reality (AR) emerging as a notable approach. However, previous studies have yet to integrate a functional AR application with a real-world autonomous driving system. In response to this gap, we proposed an architecture for an AR application that visualizes real-time data from an active CAV and subsequently developed the system. Furthermore, we conducted field experiments using this developed system and conducted user surveys during exhibitions to gather insights into the public’s perception of the system. Our results showed that the system can effectively transmit information from the CAV, and when provided with additional information, people tend to feel safer regarding the vehicle.},
  keywords      = {SDM},
  pubstate      = {published},
  tppubtype     = {workshop}
}