
OTFS Based RIS-assisted vehicle positioning and tracking in V2X scenario
IEEE Transactions on Communications, vol. 73, pp. 10676–10691, 2025年7月8日
DOI: 10.1109/TCOMM.2025.3588559
3行要約
- GPSと直接の電波経路を安定して使えないV2X環境で、車両の位置と速度を推定する。
- 到来角とRIS支援型OTFSの速度推定をアンセンテッドカルマンフィルタで統合する。
- 数値実験でOTFSのフレーム構成を比較し、測位性能と通信特性を評価した。
論文の図
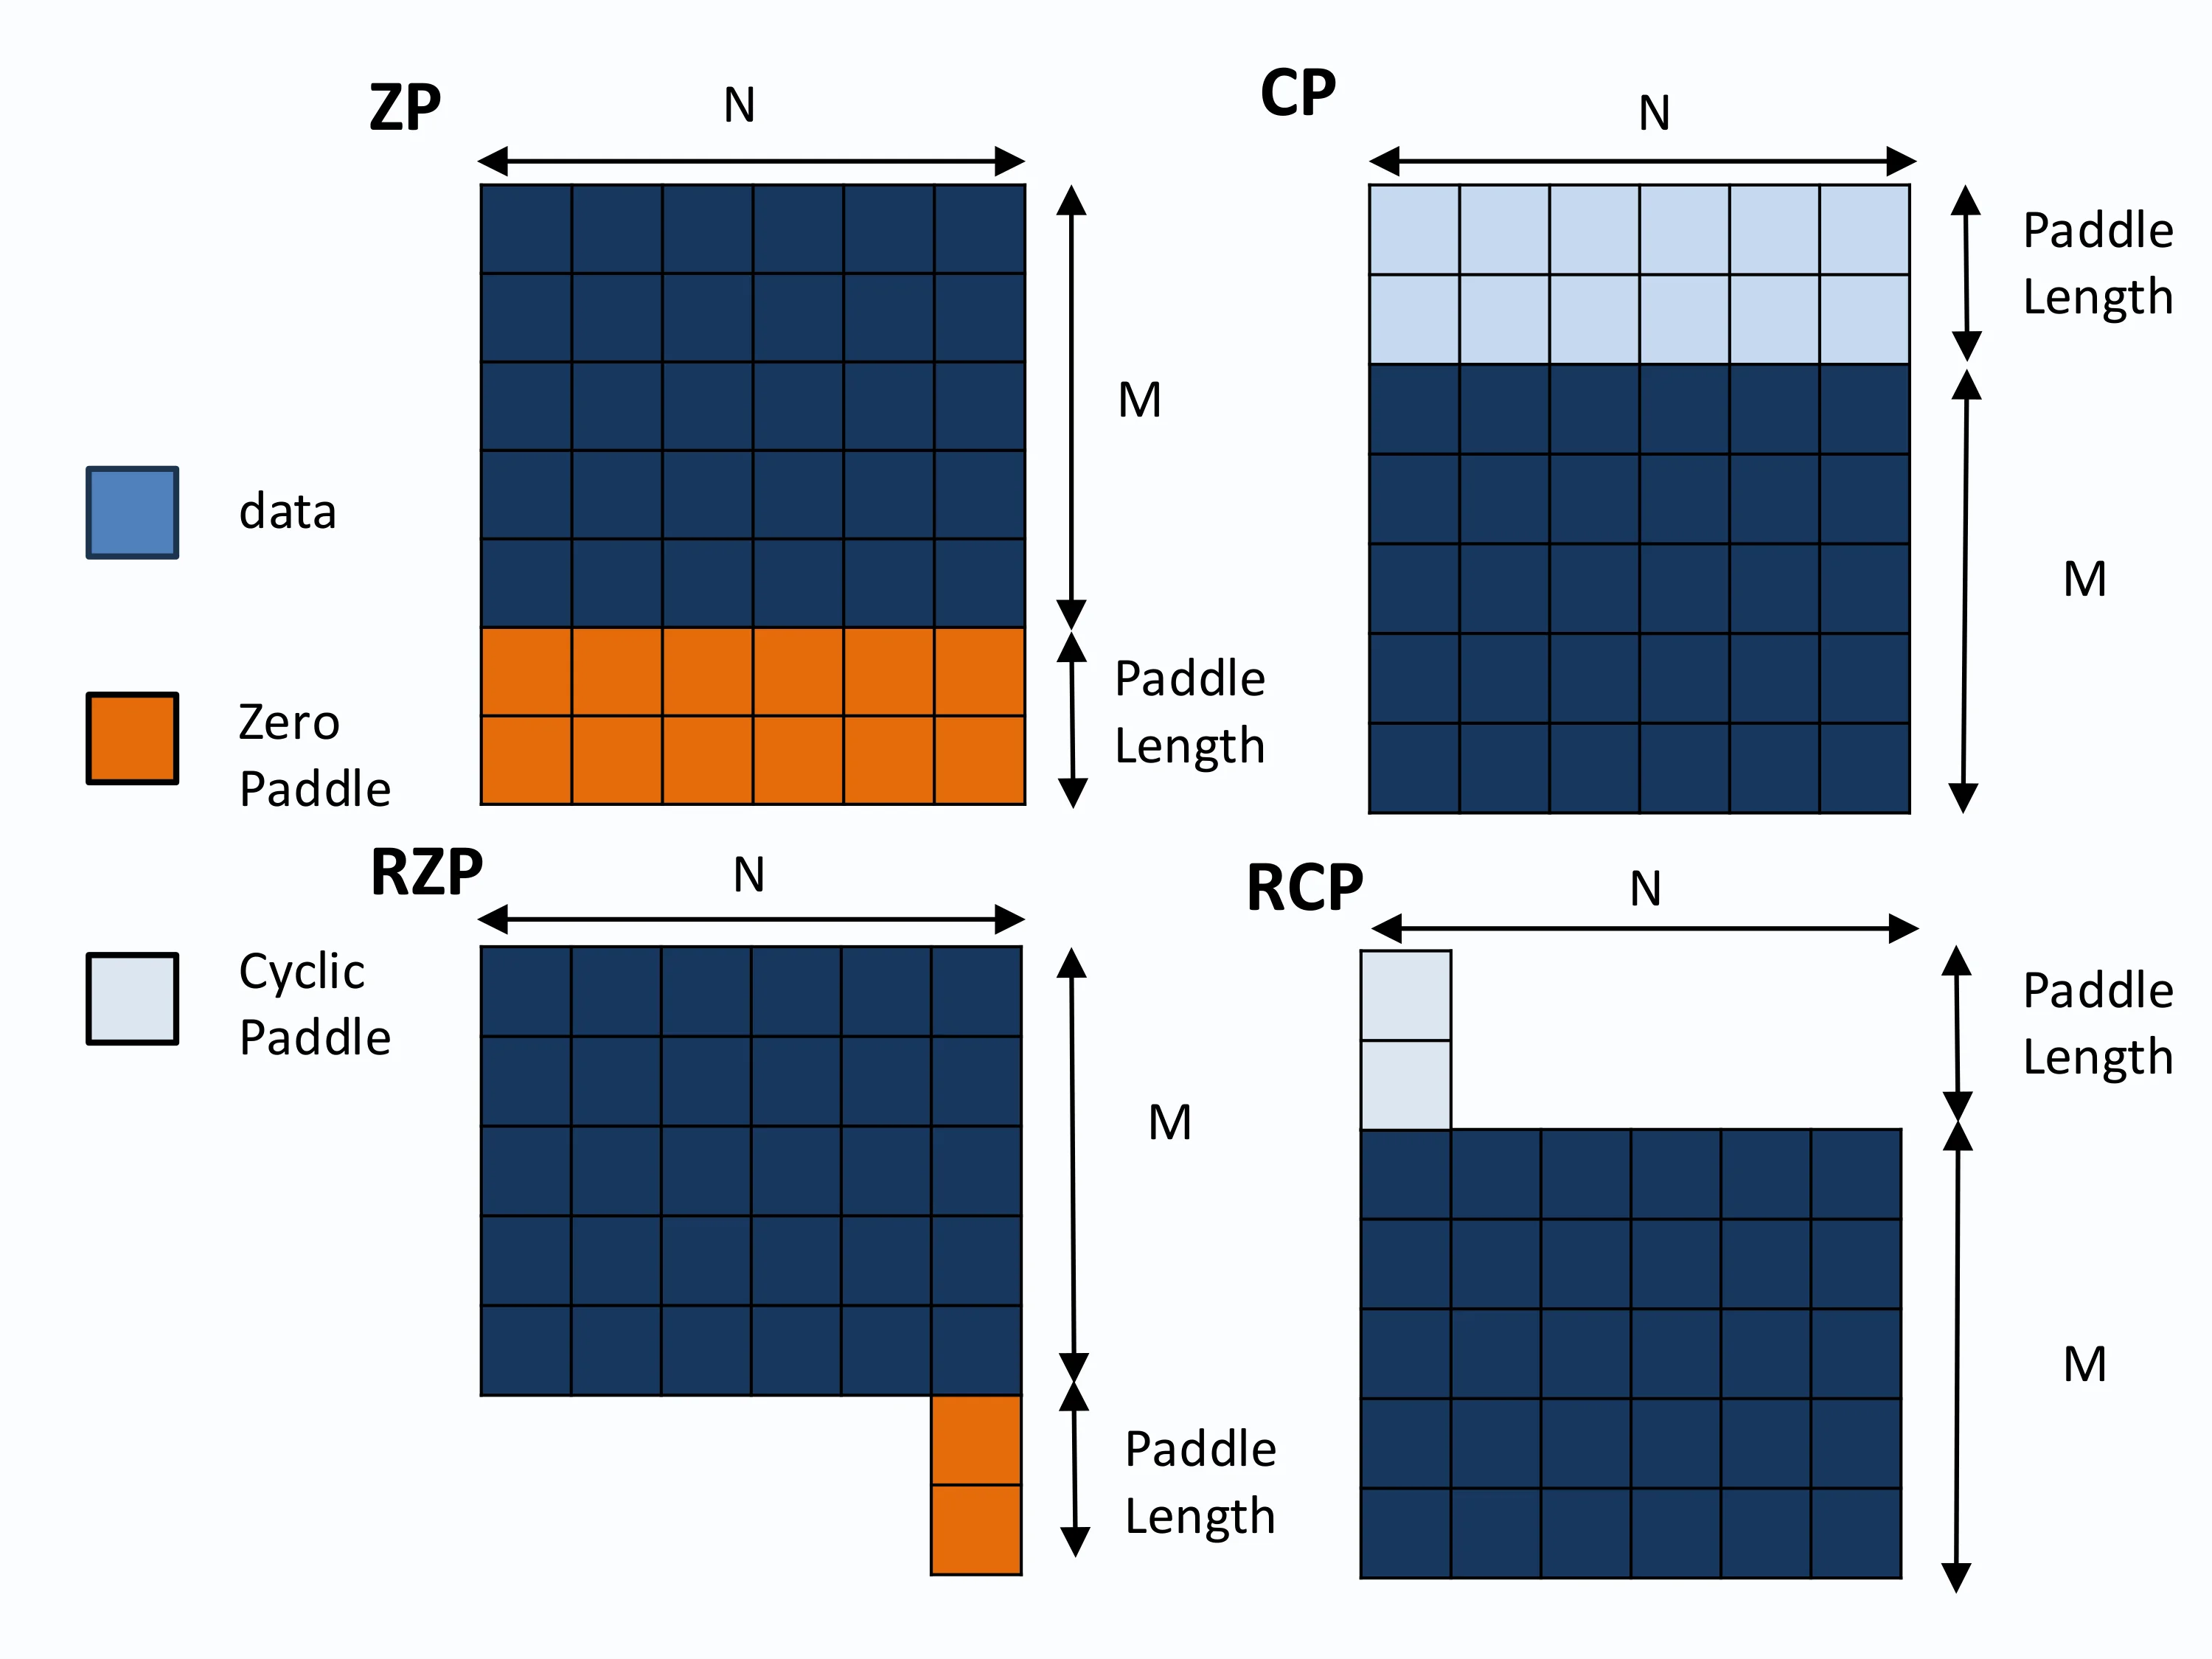
アブストラクト(原文)
This paper proposes a novel and robust framework for velocity and position estimation in vehicle-to-everything (V2X) communication networks, targeting challenges that arise when traditional GPS systems and line-of-sight (LoS) channels fail due to signal blockages between vehicles, base stations (BSs), and satellites. The proposed solution integrates multiple complementary methods to enhance robustness and accuracy. Specifically, the framework first applies the MUSIC algorithm for angle-of-arrival (AoA) estimation to obtain reliable initial positioning. In parallel, a newly designed low peak-to-average power ratio (PAPR) frame structure is introduced under reconfigurable intelligent surface (RIS)-assisted Orthogonal Time Frequency Space (OTFS) modulation, enabling resilient velocity embedding against noise and interference. These methods jointly support an unscented Kalman Filter (UKF), which refines the velocity and position estimation with high reliability. Extensive numerical evaluations confirm the effectiveness of the proposed multi-method integrated framework. Various modulation techniques, including zero padding (ZP), cyclic prefix (CP), and their recursive variants (e.g., RZP, RCP), demonstrate improved bit error rate (BER) performance over traditional OFDM. The proposed low-PAPR signal design achieves a 21.5% PAPR reduction compared to conventional embedded pilot schemes, significantly improving BER in 4-QAM scenarios. Velocity estimation results also show that the UKF outperforms the extended Kalman Filter (EKF) in both straight and curved road conditions. By combining MUSIC-based AoA estimation with RIS assistance under NLoS conditions, the proposed framework remains effective even in high-Doppler and low-SNR environments.
関連する研究・ソフトウェア
引用方法
D. Hu, J. Nakazato, K. Maruta, R. Dinis, O. A. Aghda, and M. Tsukada, “OTFS Based RIS-assisted vehicle positioning and tracking in V2X scenario,” IEEE Transactions on Communications, vol. 73, pp. 10676–10691, 2025, doi: 10.1109/TCOMM.2025.3588559.
BibTeX
@article{Hu2025b,
  title         = {OTFS Based RIS-assisted vehicle positioning and tracking in V2X scenario},
  author        = {Dou Hu and Jin Nakazato and Kazuki Maruta and Rui Dinis and Omid Abbassi Aghda and Manabu Tsukada},
  doi           = {10.1109/TCOMM.2025.3588559},
  issn          = {0090-6778},
  year          = {2025},
  date          = {2025-07-08},
  urldate       = {2025-07-08},
  journal       = {IEEE Transactions on Communications},
  volume        = {73},
  issue         = {11},
  pages         = {10676--10691},
  abstract      = {This paper proposes a novel and robust framework for velocity and position estimation in vehicle-to-everything (V2X) communication networks, targeting challenges that arise when traditional GPS systems and line-of-sight (LoS) channels fail due to signal blockages between vehicles, base stations (BSs), and satellites. The proposed solution integrates multiple complementary methods to enhance robustness and accuracy. Specifically, the framework first applies the MUSIC algorithm for angle-of-arrival (AoA) estimation to obtain reliable initial positioning. In parallel, a newly designed low peak-to-average power ratio (PAPR) frame structure is introduced under reconfigurable intelligent surface (RIS)-assisted Orthogonal Time Frequency Space (OTFS) modulation, enabling resilient velocity embedding against noise and interference. These methods jointly support an unscented Kalman Filter (UKF), which refines the velocity and position estimation with high reliability. Extensive numerical evaluations confirm the effectiveness of the proposed multi-method integrated framework. Various modulation techniques, including zero padding (ZP), cyclic prefix (CP), and their recursive variants (e.g., RZP, RCP), demonstrate improved bit error rate (BER) performance over traditional OFDM. The proposed low-PAPR signal design achieves a 21.5% PAPR reduction compared to conventional embedded pilot schemes, significantly improving BER in 4-QAM scenarios. Velocity estimation results also show that the UKF outperforms the extended Kalman Filter (EKF) in both straight and curved road conditions. By combining MUSIC-based AoA estimation with RIS assistance under NLoS conditions, the proposed framework remains effective even in high-Doppler and low-SNR environments.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {article}
}