
Multi-UAVs Strategies for Ad Hoc Network with Multi-Agent Reinforcement Learning
38th International Conference on Information Networking (ICOIN 2024), Ho Chi Minh City, Vietnam, 2024年1月17日
Web サイトDOI: 10.1109/ICOIN59985.2024.10572031
3行要約
- 複数の無人航空機で空中アドホックネットワークを構成する方法を扱う。
- マルチエージェント強化学習を用いて、それぞれの無人航空機の配置を決める。
- 評価を通じ、無人航空機が協調して動作することを示した。
論文の図
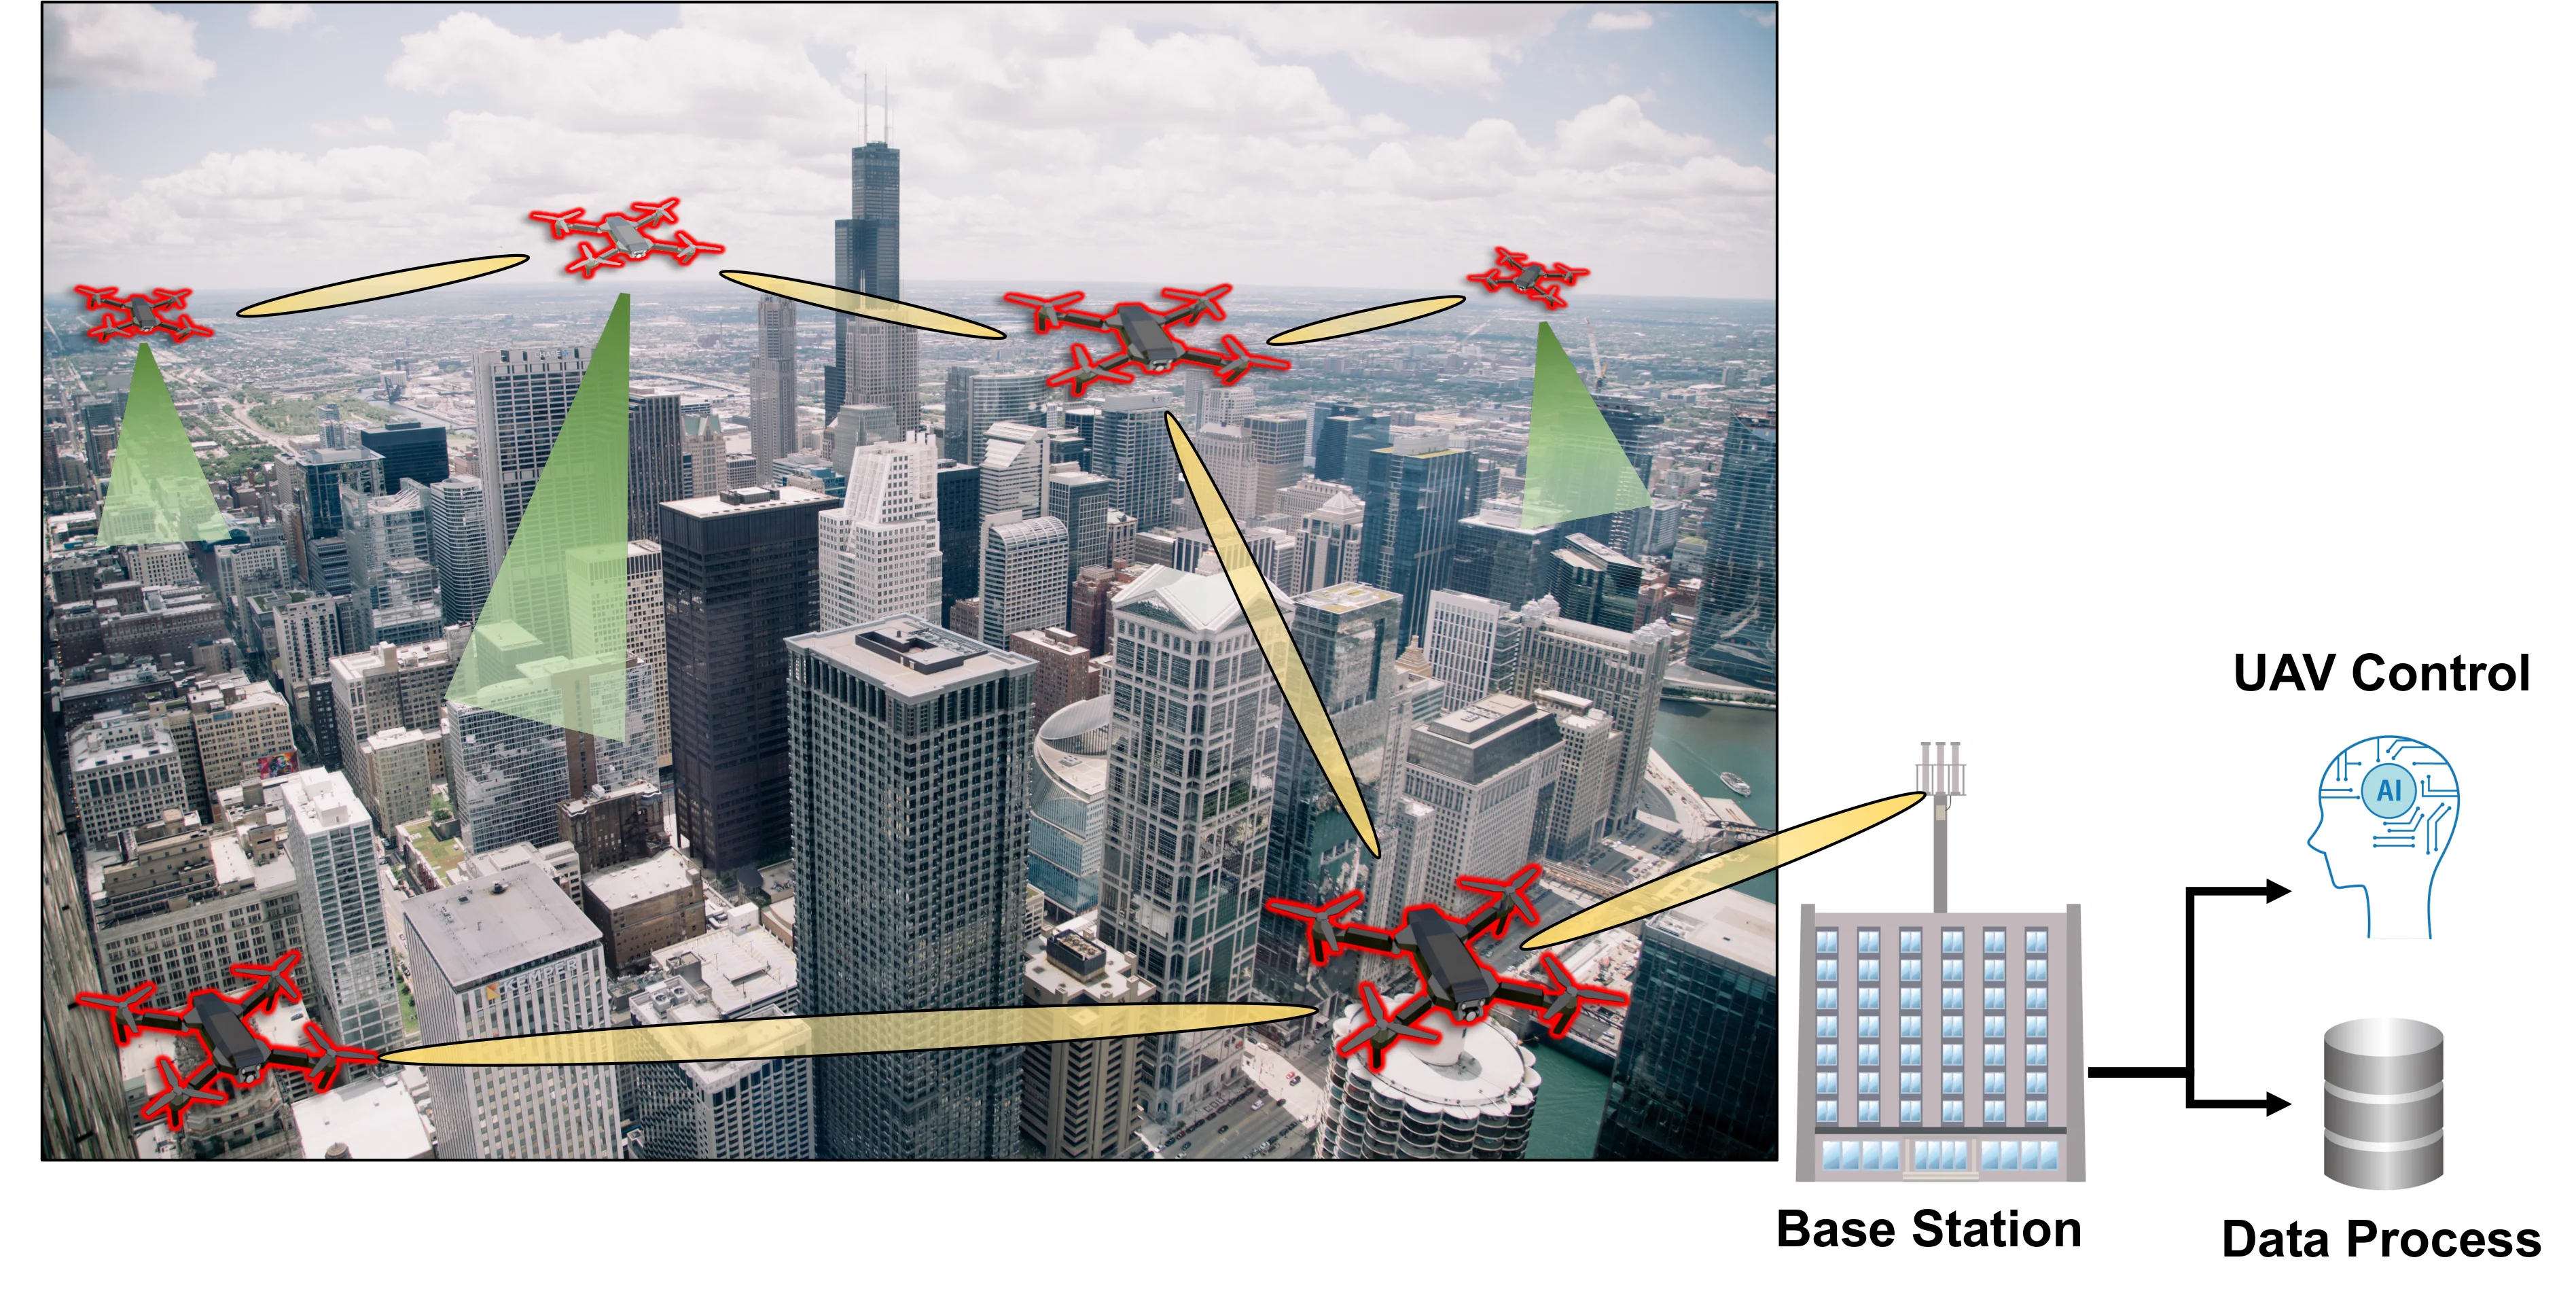
アブストラクト(原文)
In recent years, extensive research has focused on leveraging advanced technologies beyond 5G and for Industry 5.0 to promote sustainability and prosperity in society. Our study advances this effort by seeking to create an aerial perspective using Unmanned Aerial Vehicles (UAVs). This paper introduces a method for optimizing UAV deployment strategies using multi-agent reinforcement learning, facilitating the formation of a flying ad hoc network. The results demonstrate practical cooperation among UAVs in flight.
引用方法
G. Karimata, J. Nakazato, G. K. Tran, K. Suto, M. Tsukada, and H. Esaki, “Multi-UAVs Strategies for Ad Hoc Network with Multi-Agent Reinforcement Learning,” in 38th International Conference on Information Networking (ICOIN 2024), Ho Chi Minh City, Vietnam, 2024, doi: 10.1109/ICOIN59985.2024.10572031.
BibTeX
@inproceedings{Karimata2024,
  title         = {Multi-UAVs Strategies for Ad Hoc Network with Multi-Agent Reinforcement Learning},
  author        = {George Karimata and Jin Nakazato and Gia Khanh Tran and Katsuya Suto and Manabu Tsukada and Hiroshi Esaki},
  url           = {https://icoin.org/media?key=site/icoin2024/abs/P-4-1.pdf},
  doi           = {10.1109/ICOIN59985.2024.10572031},
  year          = {2024},
  date          = {2024-01-17},
  urldate       = {2024-01-17},
  booktitle     = {38th International Conference on Information Networking (ICOIN 2024)},
  address       = {Ho Chi Minh City, Vietnam},
  abstract      = {In recent years, extensive research has focused on leveraging advanced technologies beyond 5G and for Industry 5.0 to promote sustainability and prosperity in society. Our study advances this effort by seeking to create an aerial perspective using Unmanned Aerial Vehicles (UAVs). This paper introduces a method for optimizing UAV deployment strategies using multi-agent reinforcement learning, facilitating the formation of a flying ad hoc network. The results demonstrate practical cooperation among UAVs in flight.},
  keywords      = {Other},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}