
Cross-Attention Enhanced Imitation Learning for End-to-end Autonomous Driving in Unprotected Turns
Best Paper Award (Silver)International Conference on Intelligent Computing and its Emerging Applications (ICEA 2024), Tokyo, Japan, pp. 81–86, 2024年11月28日
3行要約
- 右折専用信号のない交差点では、周囲の交通状況と自車の状態の両方が判断に必要となる。
- 交差注意を使い、画像と自車状態の特徴を融合して模倣学習する。
- AWSIMでは、少ないお手本データで従来の模倣学習を上回った。
論文の図
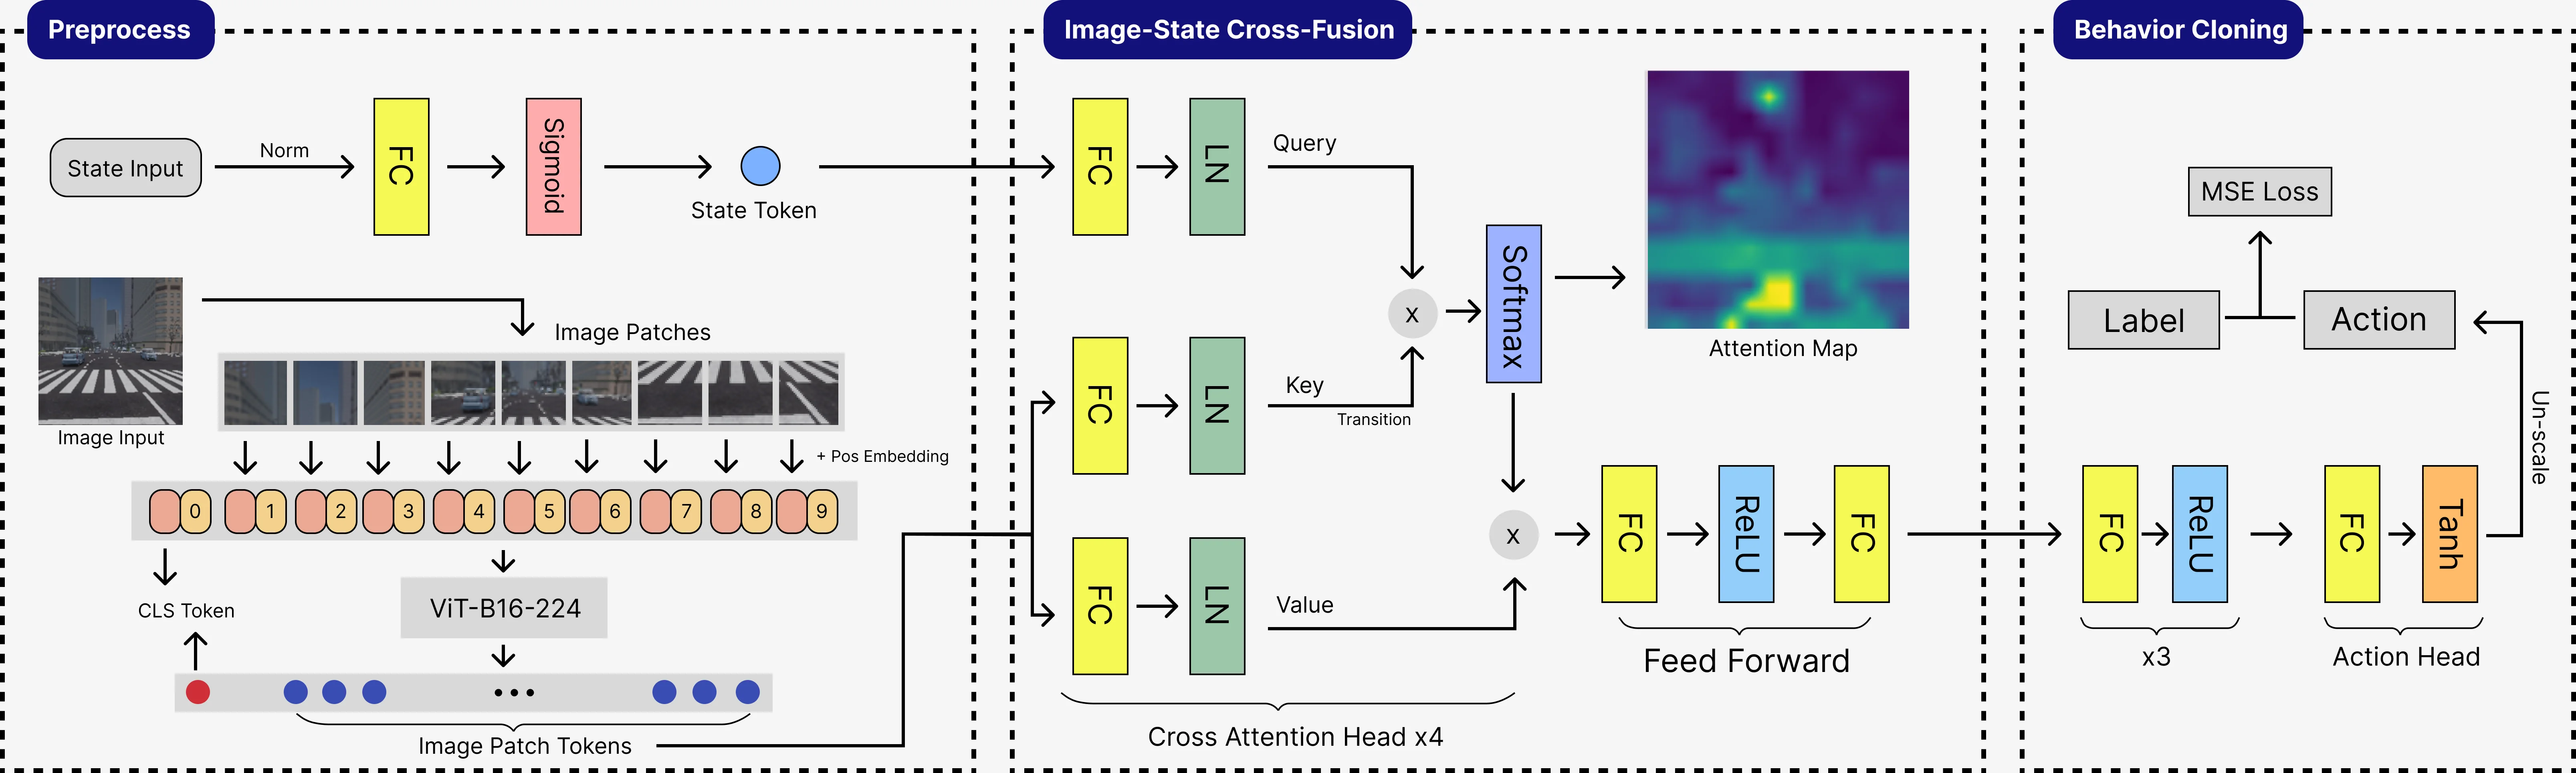
アブストラクト(原文)
Performing an unprotected turn in the intersection is a complex scenario for autonomous vehicles. It not only requires a comprehensive understanding of the surrounding environment but also highly relies on the ego vehicle’s current state to make safe decisions. A conventional way to learn end-to-end autonomous driving is imitation learning, which is learning from expert demonstrations. While most imitation learning methods focus on imitating the expert action, they often fail to imitate a complex policy efficiently when the ego vehicle’s states are crucial to the scenario because there might be arbitrary optimal actions under different states. To address this issue and investigate how vehicle states affect autonomous driving, we present a novel cross-attention enhanced imitation learning approach for end-to-end autonomous driving in unprotected turns, focusing on capturing the relationships between the ego vehicle’s states and its perception of the environment. We evaluate our model in AWSIM, an open-source autonomous driving simulator, and the results demonstrate that our model outperformed conventional imitation learning-based baselines in performing unprotected turn scenarios, showcasing its ability to imitate a complex policy efficiently.
関連ニュース
引用方法
D. Li, E. Javanmardi, N. Bao, and M. Tsukada, “Cross-Attention Enhanced Imitation Learning for End-to-end Autonomous Driving in Unprotected Turns,” in International Conference on Intelligent Computing and its Emerging Applications (ICEA 2024), Tokyo, Japan, 2024, doi: 10.1145/3732437.3732764.
BibTeX
@inproceedings{Li2024,
  title         = {Cross-Attention Enhanced Imitation Learning for End-to-end Autonomous Driving in Unprotected Turns},
  author        = {Dongyang Li and Ehsan Javanmardi and Naren Bao and Manabu Tsukada},
  doi           = {10.1145/3732437.3732764},
  year          = {2024},
  date          = {2024-11-28},
  urldate       = {2024-11-28},
  booktitle     = {International Conference on Intelligent Computing and its Emerging Applications (ICEA 2024)},
  pages         = {81--86},
  address       = {Tokyo, Japan},
  abstract      = {Performing an unprotected turn in the intersection is a complex scenario for autonomous vehicles. It not only requires a comprehensive understanding of the surrounding environment but also highly relies on the ego vehicle’s current state to make safe decisions. A conventional way to learn end-to-end autonomous driving is imitation learning, which is learning from expert demonstrations. While most imitation learning methods focus on imitating the expert action, they often fail to imitate a complex policy efficiently when the ego vehicle’s states are crucial to the scenario because there might be arbitrary optimal actions under different states. To address this issue and investigate how vehicle states affect autonomous driving, we present a novel cross-attention enhanced imitation learning approach for end-to-end autonomous driving in unprotected turns, focusing on capturing the relationships between the ego vehicle’s states and its perception of the environment. We evaluate our model in AWSIM, an open-source autonomous driving simulator, and the results demonstrate that our model outperformed conventional imitation learning-based baselines in performing unprotected turn scenarios, showcasing its ability to imitate a complex policy efficiently.},
  note          = {Best Paper Award (Silver)},
  keywords      = {Award, ITS},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}