
Zero-Knowledge Proof of Traffic: A Deterministic and Privacy-Preserving Cross Verification Mechanism for Cooperative Perception Data
IEEE Access, vol. 11, pp. 142846–142861, 2023年12月17日
arXivDOI: 10.1109/ACCESS.2023.3343405
3行要約
- 協調認識メッセージを、プライバシーを保ちながら決定論的に相互検証する方式を提案する。
- Flowsim上の車載ソフトウェアスタックに実装した。
- 都市規模のシミュレーションで80〜96%を相互検証でき、2秒以内に80%に達した。
論文の図
アブストラクト(原文)
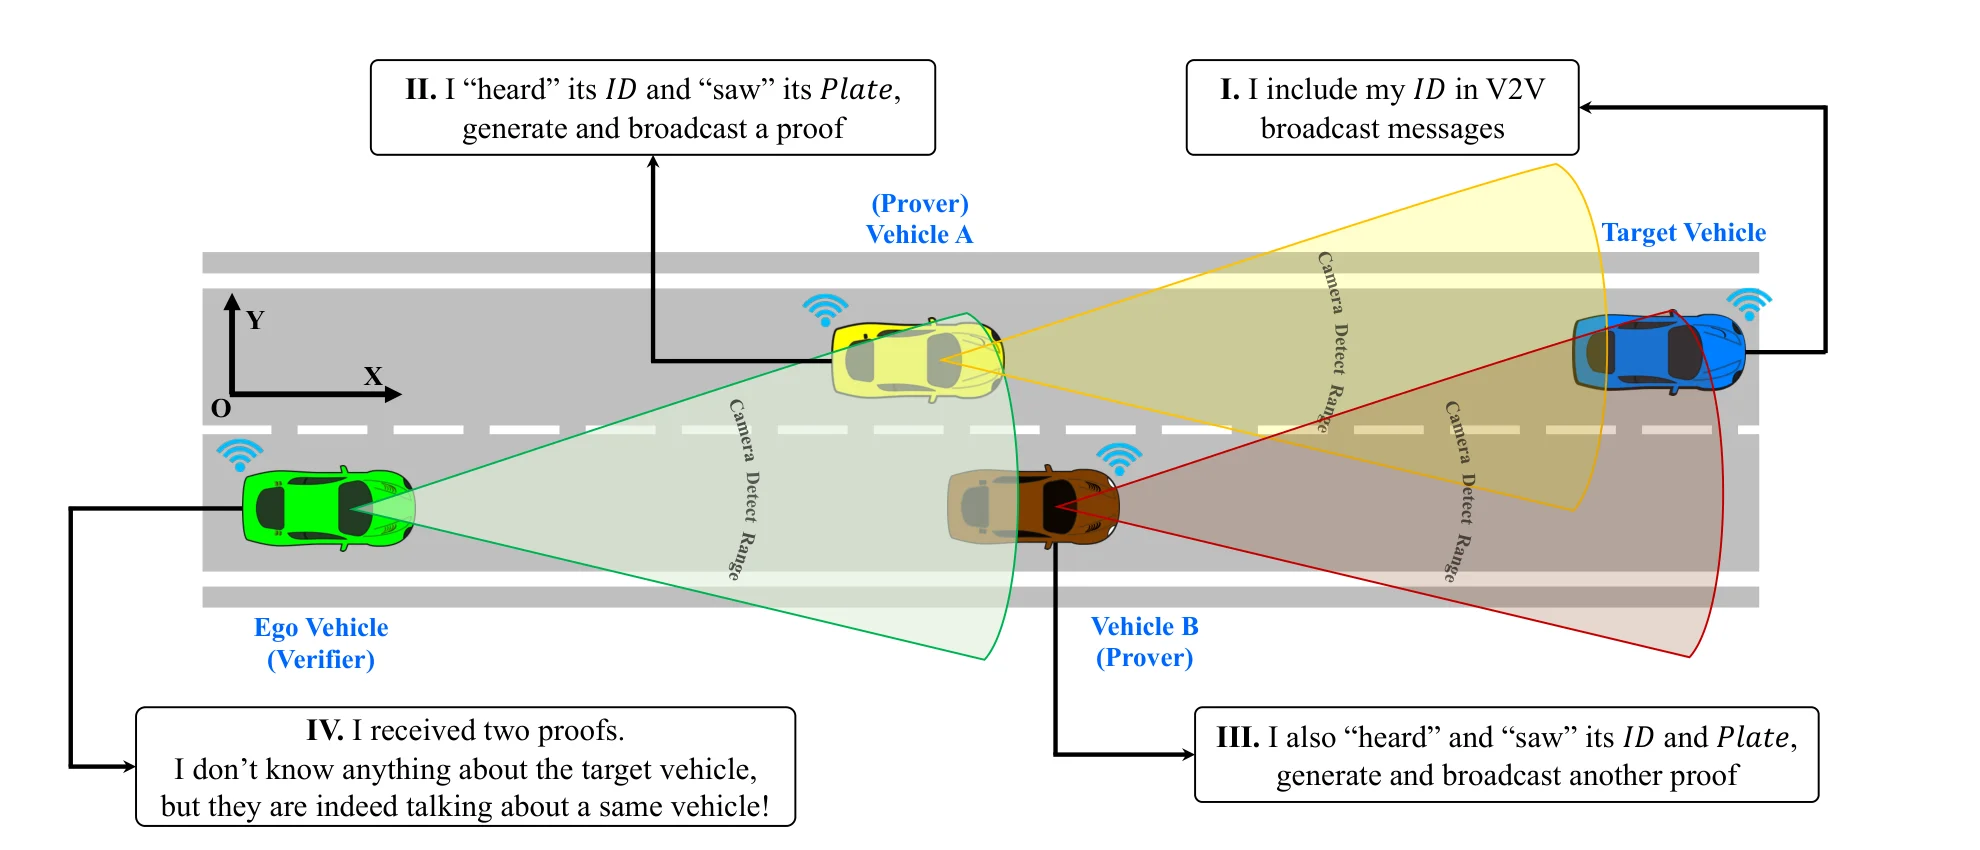
Cooperative perception is crucial for connected automated vehicles in intelligent transportation systems (ITSs); however, ensuring the authenticity of perception data remains a challenge as the vehicles cannot verify events that they do not witness independently. Various studies have been conducted on establishing the authenticity of data, such as trust-based statistical methods and plausibility-based methods. However, these methods are limited as they require prior knowledge such as previous sender behaviors or predefined rules to evaluate the authenticity. To overcome this limitation, this study proposes a novel approach called zero-knowledge Proof of Traffic (zk-PoT), which involves generating cryptographic proofs to the traffic observations. Multiple independent proofs regarding the same vehicle can be deterministically cross-verified by any receivers without relying on ground truth, probabilistic, or plausibility evaluations. Additionally, no private information is compromised during the entire procedure. A full on-board unit software stack that reflects the behavior of zk-PoT is implemented within a specifically designed simulator called Flowsim. A comprehensive experimental analysis is then conducted using synthesized city-scale simulations, which demonstrates that zk-PoT’s cross-verification ratio ranges between 80 % to 96 %, and 90 % of the verification is achieved in 5 s, with a protocol overhead of approximately 25 %. Furthermore, the analyses of various attacks indicate that most of the attacks could be prevented, and some, such as collusion attacks, can be mitigated. The proposed approach can be incorporated into existing works, including the European Telecommunications Standards Institute (ETSI) and the International Organization for Standardization (ISO) ITS standards, without disrupting the backward compatibility.
引用方法
Y. Tao, E. Javanmardi, P. Lin, Y. Jiang, J. Nakazato, M. Tsukada, and H. Esaki, “Zero-Knowledge Proof of Traffic: A Deterministic and Privacy-Preserving Cross Verification Mechanism for Cooperative Perception Data,” IEEE Access, vol. 11, pp. 142846–142861, 2023, doi: 10.1109/ACCESS.2023.3343405.
BibTeX
@article{Tao2023b,
  title         = {Zero-Knowledge Proof of Traffic: A Deterministic and Privacy-Preserving Cross Verification Mechanism for Cooperative Perception Data},
  author        = {Ye Tao and Ehsan Javanmardi and Pengfei Lin and Yuze Jiang and Jin Nakazato and Manabu Tsukada and Hiroshi Esaki},
  url           = {https://arxiv.org/abs/2312.07948},
  doi           = {10.1109/ACCESS.2023.3343405},
  issn          = {2169-3536},
  year          = {2023},
  date          = {2023-12-17},
  urldate       = {2023-12-17},
  journal       = {IEEE Access},
  volume        = {11},
  pages         = {142846--142861},
  abstract      = {Cooperative perception is crucial for connected automated vehicles in intelligent transportation systems (ITSs); however, ensuring the authenticity of perception data remains a challenge as the vehicles cannot verify events that they do not witness independently. Various studies have been conducted on establishing the authenticity of data, such as trust-based statistical methods and plausibility-based methods. However, these methods are limited as they require prior knowledge such as previous sender behaviors or predefined rules to evaluate the authenticity. To overcome this limitation, this study proposes a novel approach called zero-knowledge Proof of Traffic (zk-PoT), which involves generating cryptographic proofs to the traffic observations. Multiple independent proofs regarding the same vehicle can be deterministically cross-verified by any receivers without relying on ground truth, probabilistic, or plausibility evaluations. Additionally, no private information is compromised during the entire procedure. A full on-board unit software stack that reflects the behavior of zk-PoT is implemented within a specifically designed simulator called Flowsim. A comprehensive experimental analysis is then conducted using synthesized city-scale simulations, which demonstrates that zk-PoT’s cross-verification ratio ranges between 80 % to 96 %, and 90 % of the verification is achieved in 5 s, with a protocol overhead of approximately 25 %. Furthermore, the analyses of various attacks indicate that most of the attacks could be prevented, and some, such as collusion attacks, can be mitigated. The proposed approach can be incorporated into existing works, including the European Telecommunications Standards Institute (ETSI) and the International Organization for Standardization (ISO) ITS standards, without disrupting the backward compatibility.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {article}
}