
Traffic-load-responsive Intersection Management for Mixed-traffic Conditions
Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo, 2023年9月30日
3行要約
- コネクテッド車と非コネクテッド車が混在する交差点で、交通量と通過の緊急度に応じて車両グループに通行を割り当てる。
- 路側機でコネクテッド車両の速度を調整し、他の車両は信号機で誘導する。
- OpenCDAとCARLAの比較で、固定時間信号より通過台数が増え、待ち時間が短くなった。
論文の図
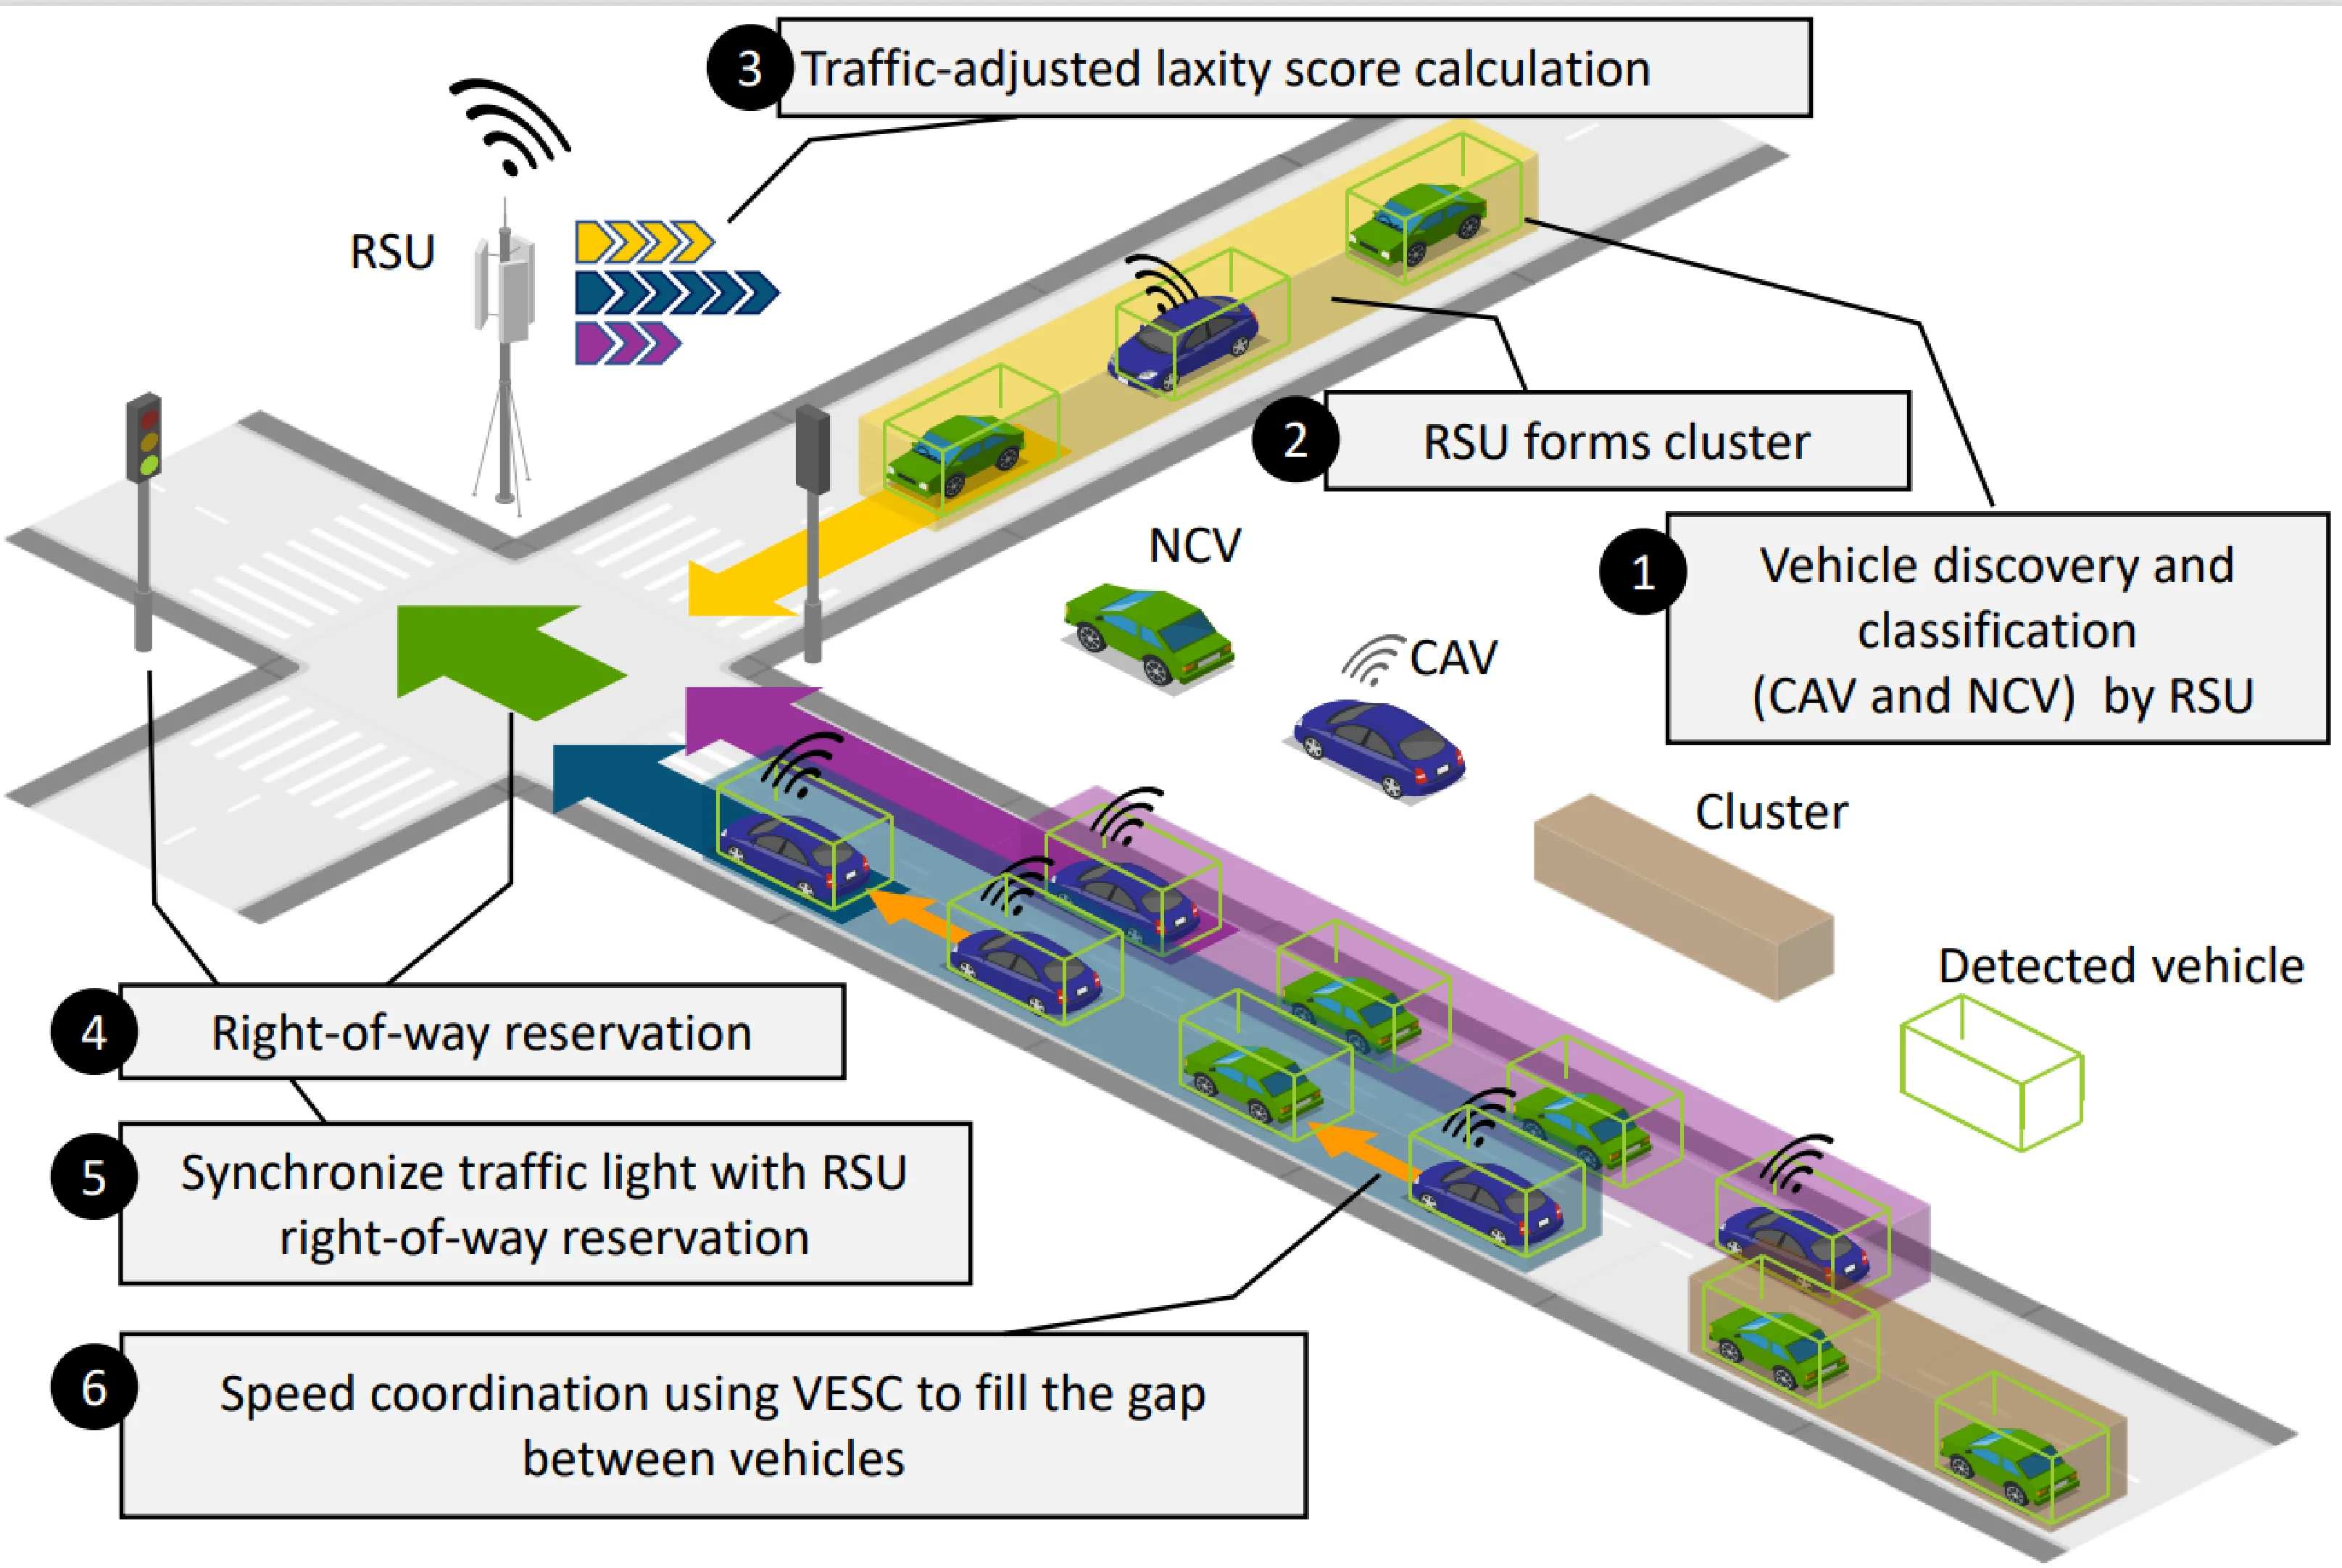
アブストラクト(原文)
Vehicle-to-everything (V2X) communication enables connected autonomous vehicles (CAVs) to share information with other vehicles, road infrastructures, and other road users. In turn, information sharing between CAVs and various road users and infrastructures enables CAVs to generate optimal decisions by considering information previously unavailable to them. Consequently, safety and traffic flow can be improved with the utilization of V2X communication by CAVs. One cutting-edge development derived from the emergence of V2X communication is autonomous intersection management (AIM) methods, which leverage CAVs to simultaneously improve traffic flows and prevent collisions in intersections. In this case, a variety of AIM approaches were developed, such as sharing of future paths of vehicles, ADMM optimization for path generation, and platoon formation. However, these AIM methods assumed 100% CAV market penetration, which is currently unrealistic owing to the gradual adoption of CAVs. Therefore, CAVs must share road usage with nonconnected vehicles (NCVs). To accommodate mixed-traffic conditions containing CAVs and NCVs, a variety of semi-autonomous intersection management (Semi-AIM) methods were introduced. These Semi-AIM methods can be categorized as signalized or unsignalized, depending on the utilization of traffic lights or lack thereof. Unfortunately, most Semi-AIM methods belonging to either category still have one or more of the following flaws: non-optimal scheduling, significant traffic flow degradation if the traffic has a high NCV ratio, inability to relay right-of-way instructions to NCVs, and inflexibility to variations in traffic loads. Therefore, we propose a signalized mixed-traffic intersection management method, traffic-load-responsive reservation for intersection management (TLRRIM), which addresses common issues present in existing Semi-AIM methods. In TLRRIM, the roadside unit (RSU) first classifies vehicles and groups them into clusters before selecting a reservation cluster to cross an intersection. The reservation cluster selection considers both traffic load and crossing urgency. In addition, we propose the V2X-enabled speed coordination (VESC) method to be installed on RSU to further improve traffic flow. VESC enables CAVs within the reservation cluster to close the gap between themselves and the vehicles in front of them. Simultaneously, traffic lights are utilized to guide NCVs. Simulation-based experiments using OpenCDA and CARLA showed that TLRRIM can increase throughput and reduce waiting time by up to 89.63% and 60.71%, respectively, compared to the fixed-time signaling method. Moreover, adding VESC can increase throughput by 12.21% and reduce waiting time by 10.80%. Hence, numerical results show that TLRRIM provides significant traffic flow improvements compared to the fixed-time signaling method, even for situations with 100% NCV. Furthermore, VESC can further enhance the performance of TLRRIM.
引用方法
N. D. Yosodipuro, “Traffic-load-responsive Intersection Management for Mixed-traffic Conditions,” in Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo, 2023.
BibTeX
@mastersthesis{Yosodipuro2023b,
  title         = {Traffic-load-responsive Intersection Management for Mixed-traffic Conditions},
  author        = {Nicholaus Danispadmanaba Yosodipuro},
  year          = {2023},
  date          = {2023-09-30},
  urldate       = {2023-09-30},
  school        = {Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo},
  abstract      = {
    Vehicle-to-everything (V2X) communication enables connected autonomous vehicles (CAVs) to share information with other vehicles, road infrastructures, and other road users. In turn, information sharing between CAVs and various road users and infrastructures enables CAVs to generate optimal decisions by considering information previously unavailable to them. Consequently, safety and traffic flow can be improved with the utilization of V2X communication by CAVs. One cutting-edge development derived from the emergence of V2X communication is autonomous intersection management (AIM) methods, which leverage CAVs to simultaneously improve traffic flows and prevent collisions in intersections. In this case, a variety of AIM approaches were developed, such as sharing of future paths of vehicles, ADMM optimization for path generation, and platoon formation. However, these AIM methods assumed 100% CAV market penetration, which is currently unrealistic owing to the gradual adoption of CAVs. Therefore, CAVs must share road usage with nonconnected vehicles (NCVs).

    To accommodate mixed-traffic conditions containing CAVs and NCVs, a variety of semi-autonomous intersection management (Semi-AIM) methods were introduced. These Semi-AIM methods can be categorized as signalized or unsignalized, depending on the utilization of traffic lights or lack thereof. Unfortunately, most Semi-AIM methods belonging to either category still have one or more of the following flaws: non-optimal scheduling, significant traffic flow degradation if the traffic has a high NCV ratio, inability to relay right-of-way instructions to NCVs, and inflexibility to variations in traffic loads.

    Therefore, we propose a signalized mixed-traffic intersection management method, traffic-load-responsive reservation for intersection management (TLRRIM), which addresses common issues present in existing Semi-AIM methods. In TLRRIM, the roadside unit (RSU) first classifies vehicles and groups them into clusters before selecting a reservation cluster to cross an intersection. The reservation cluster selection considers both traffic load and crossing urgency. In addition, we propose the V2X-enabled speed coordination (VESC) method to be installed on RSU to further improve traffic flow. VESC enables CAVs within the reservation cluster to close the gap between themselves and the vehicles in front of them. Simultaneously, traffic lights are utilized to guide NCVs.

    Simulation-based experiments using OpenCDA and CARLA showed that TLRRIM can increase throughput and reduce waiting time by up to 89.63% and 60.71%, respectively, compared to the fixed-time signaling method. Moreover, adding VESC can increase throughput by 12.21% and reduce waiting time by 10.80%. Hence, numerical results show that TLRRIM provides significant traffic flow improvements compared to the fixed-time signaling method, even for situations with 100% NCV. Furthermore, VESC can further enhance the performance of TLRRIM.
  },
  keywords      = {Thesis},
  pubstate      = {published},
  tppubtype     = {mastersthesis}
}