
Cellular Connected UAV Anti-Interference Path Planning Based on PDS-DDPG and TOPEM
IEEE Journal on Miniaturization for Air and Space Systems, 2024年11月4日
DOI: 10.1109/JMASS.2024.3490762
3行要約
- セルラー接続型の無人航空機について、任務時間と通信途絶時間を抑える経路を計画する。
- 事後決定状態を使う強化学習と、通信途絶確率を記録する仕組みを組み合わせた。
- シミュレーションでは、基本のDDPGより学習が速く、収束までのエピソードも少なかった。
論文の図
アブストラクト(原文)
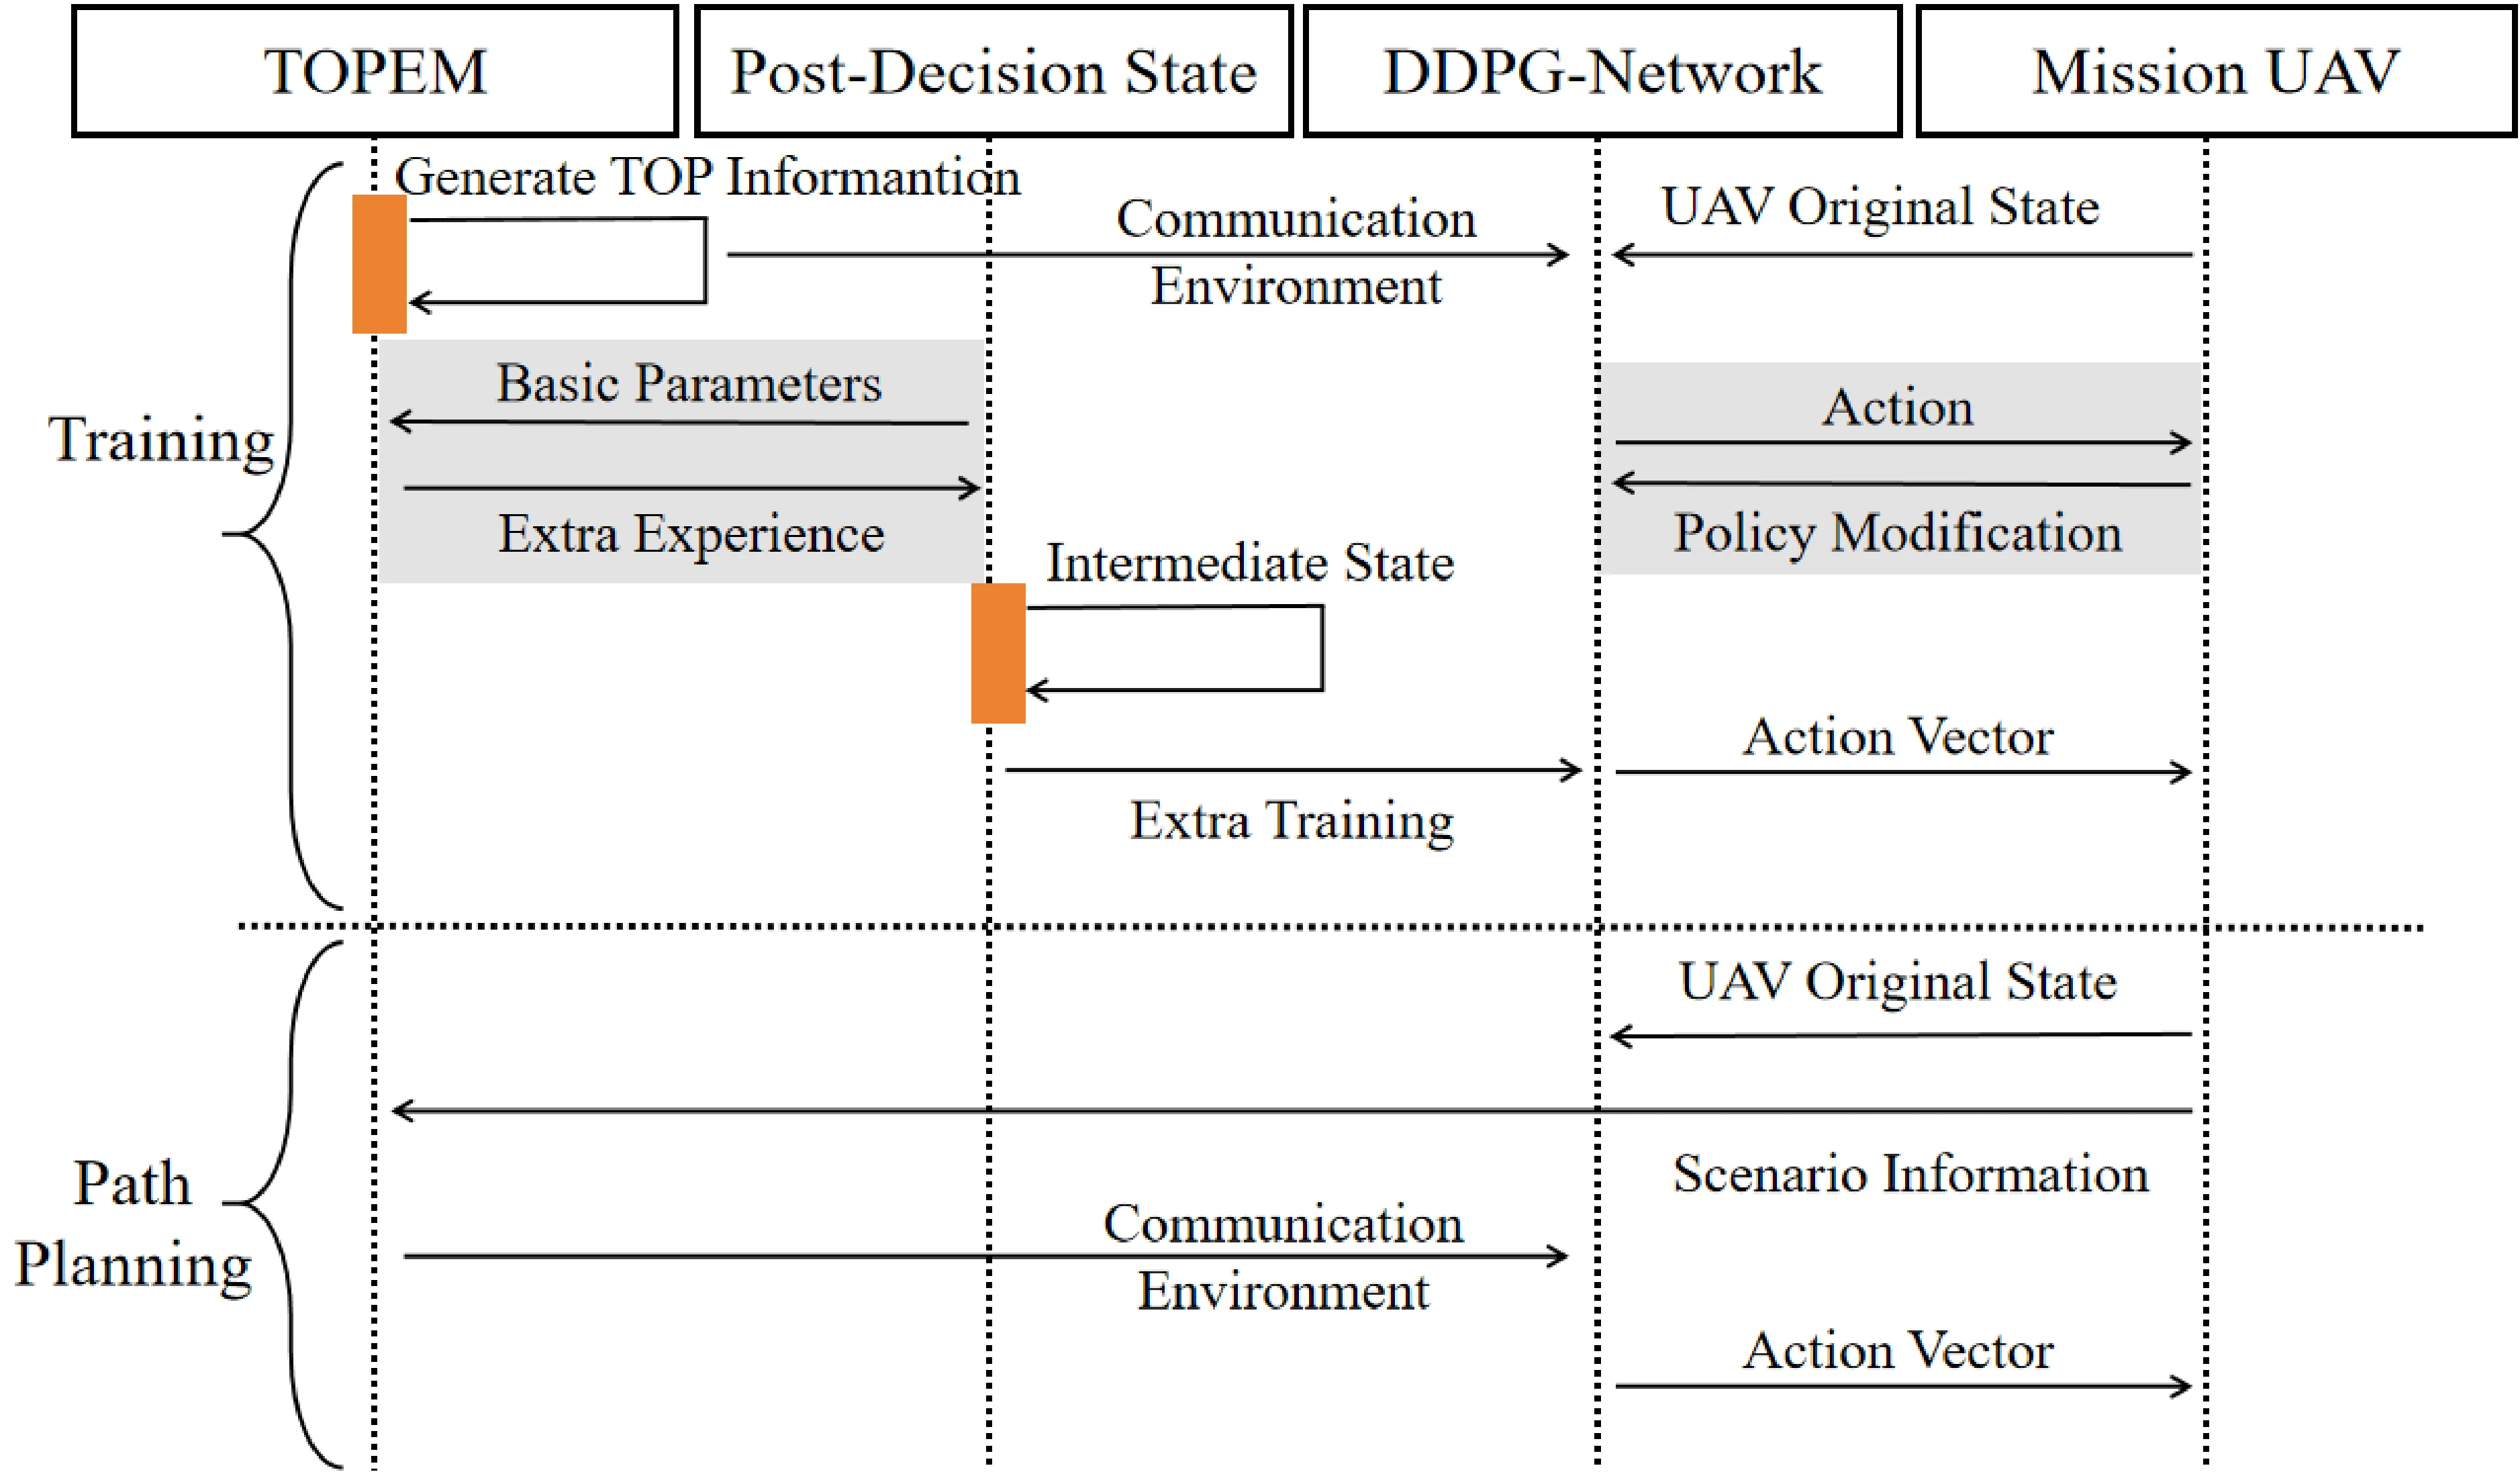
Due to the randomness of channel fading, communication devices, and malicious interference sources, unmanned aerial vehicles (UAVs) face a complex and ever-changing task scenario, which poses significant communication security challenges, such as transmission outages. Fortunately, these communication security challenges can be transformed into path planning problems that minimize the weighted sum of UAV mission time and transmission outage time. In order to design the complex communication environment faced by UAVs in actual scenarios, we propose a system model, including building distribution, communication channel, and antenna design in this paper. Besides, we introduce other UAVs with fixed flight paths and ground interference resources with random locations to ensure mission UAVs have better anti-interference ability. However, it is challenging for classical search algorithms and heuristic algorithms to cope with the complex path problems mentioned above. In this paper, we propose an improved deep deterministic policy gradient (DDPG) algorithm with better performance compared with basic DDPG and DDQN algorithms. Specifically, a post-decision state (PDS) mechanism has been introduced to accelerate the convergence rate and enhance the stability of the training process. In addition, a transmission outage probability experience memory (TOPEM) has been designed to quickly generate wireless communication quality maps and provide temporary experience for the post-decision process, resulting in better training results. Simulation experiments have proven that, compared to basic DDPG, the improved algorithm increases training speed by at least 50%, significantly improves convergence rate, and reduces the episode required for convergence to 20%. It can also help UAVs choose better paths than basic DDPG and DDQN algorithms.
動画
関連する研究・ソフトウェア
引用方法
Q. Zhou, Y. Wang, R. Shen, J. Nakazato, M. Tsukada, and Z. Guan, “Cellular Connected UAV Anti-Interference Path Planning Based on PDS-DDPG and TOPEM,” IEEE Journal on Miniaturization for Air and Space Systems, 2024, doi: 10.1109/JMASS.2024.3490762.
BibTeX
@article{Zhou2024,
  title         = {Cellular Connected UAV Anti-Interference Path Planning Based on PDS-DDPG and TOPEM},
  author        = {Quanxi Zhou and Yongjing Wang and Ruiyu Shen and Jin Nakazato and Manabu Tsukada and Zhenyu Guan},
  doi           = {10.1109/JMASS.2024.3490762},
  issn          = {2576-3164},
  year          = {2024},
  date          = {2024-11-04},
  urldate       = {2024-11-04},
  journal       = {IEEE Journal on Miniaturization for Air and Space Systems},
  abstract      = {Due to the randomness of channel fading, communication devices, and malicious interference sources, unmanned aerial vehicles (UAVs) face a complex and ever-changing task scenario, which poses significant communication security challenges, such as transmission outages. Fortunately, these communication security challenges can be transformed into path planning problems that minimize the weighted sum of UAV mission time and transmission outage time. In order to design the complex communication environment faced by UAVs in actual scenarios, we propose a system model, including building distribution, communication channel, and antenna design in this paper. Besides, we introduce other UAVs with fixed flight paths and ground interference resources with random locations to ensure mission UAVs have better anti-interference ability. However, it is challenging for classical search algorithms and heuristic algorithms to cope with the complex path problems mentioned above. In this paper, we propose an improved deep deterministic policy gradient (DDPG) algorithm with better performance compared with basic DDPG and DDQN algorithms. Specifically, a post-decision state (PDS) mechanism has been introduced to accelerate the convergence rate and enhance the stability of the training process. In addition, a transmission outage probability experience memory (TOPEM) has been designed to quickly generate wireless communication quality maps and provide temporary experience for the post-decision process, resulting in better training results. Simulation experiments have proven that, compared to basic DDPG, the improved algorithm increases training speed by at least 50%, significantly improves convergence rate, and reduces the episode required for convergence to 20%. It can also help UAVs choose better paths than basic DDPG and DDQN algorithms.},
  keywords      = {Other},
  pubstate      = {published},
  tppubtype     = {article}
}