
Localizability Estimation for Autonomous Driving: A Deep Learning-Based Feature Extraction Approach
Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo, Mar 30, 2024
Summary in three lines
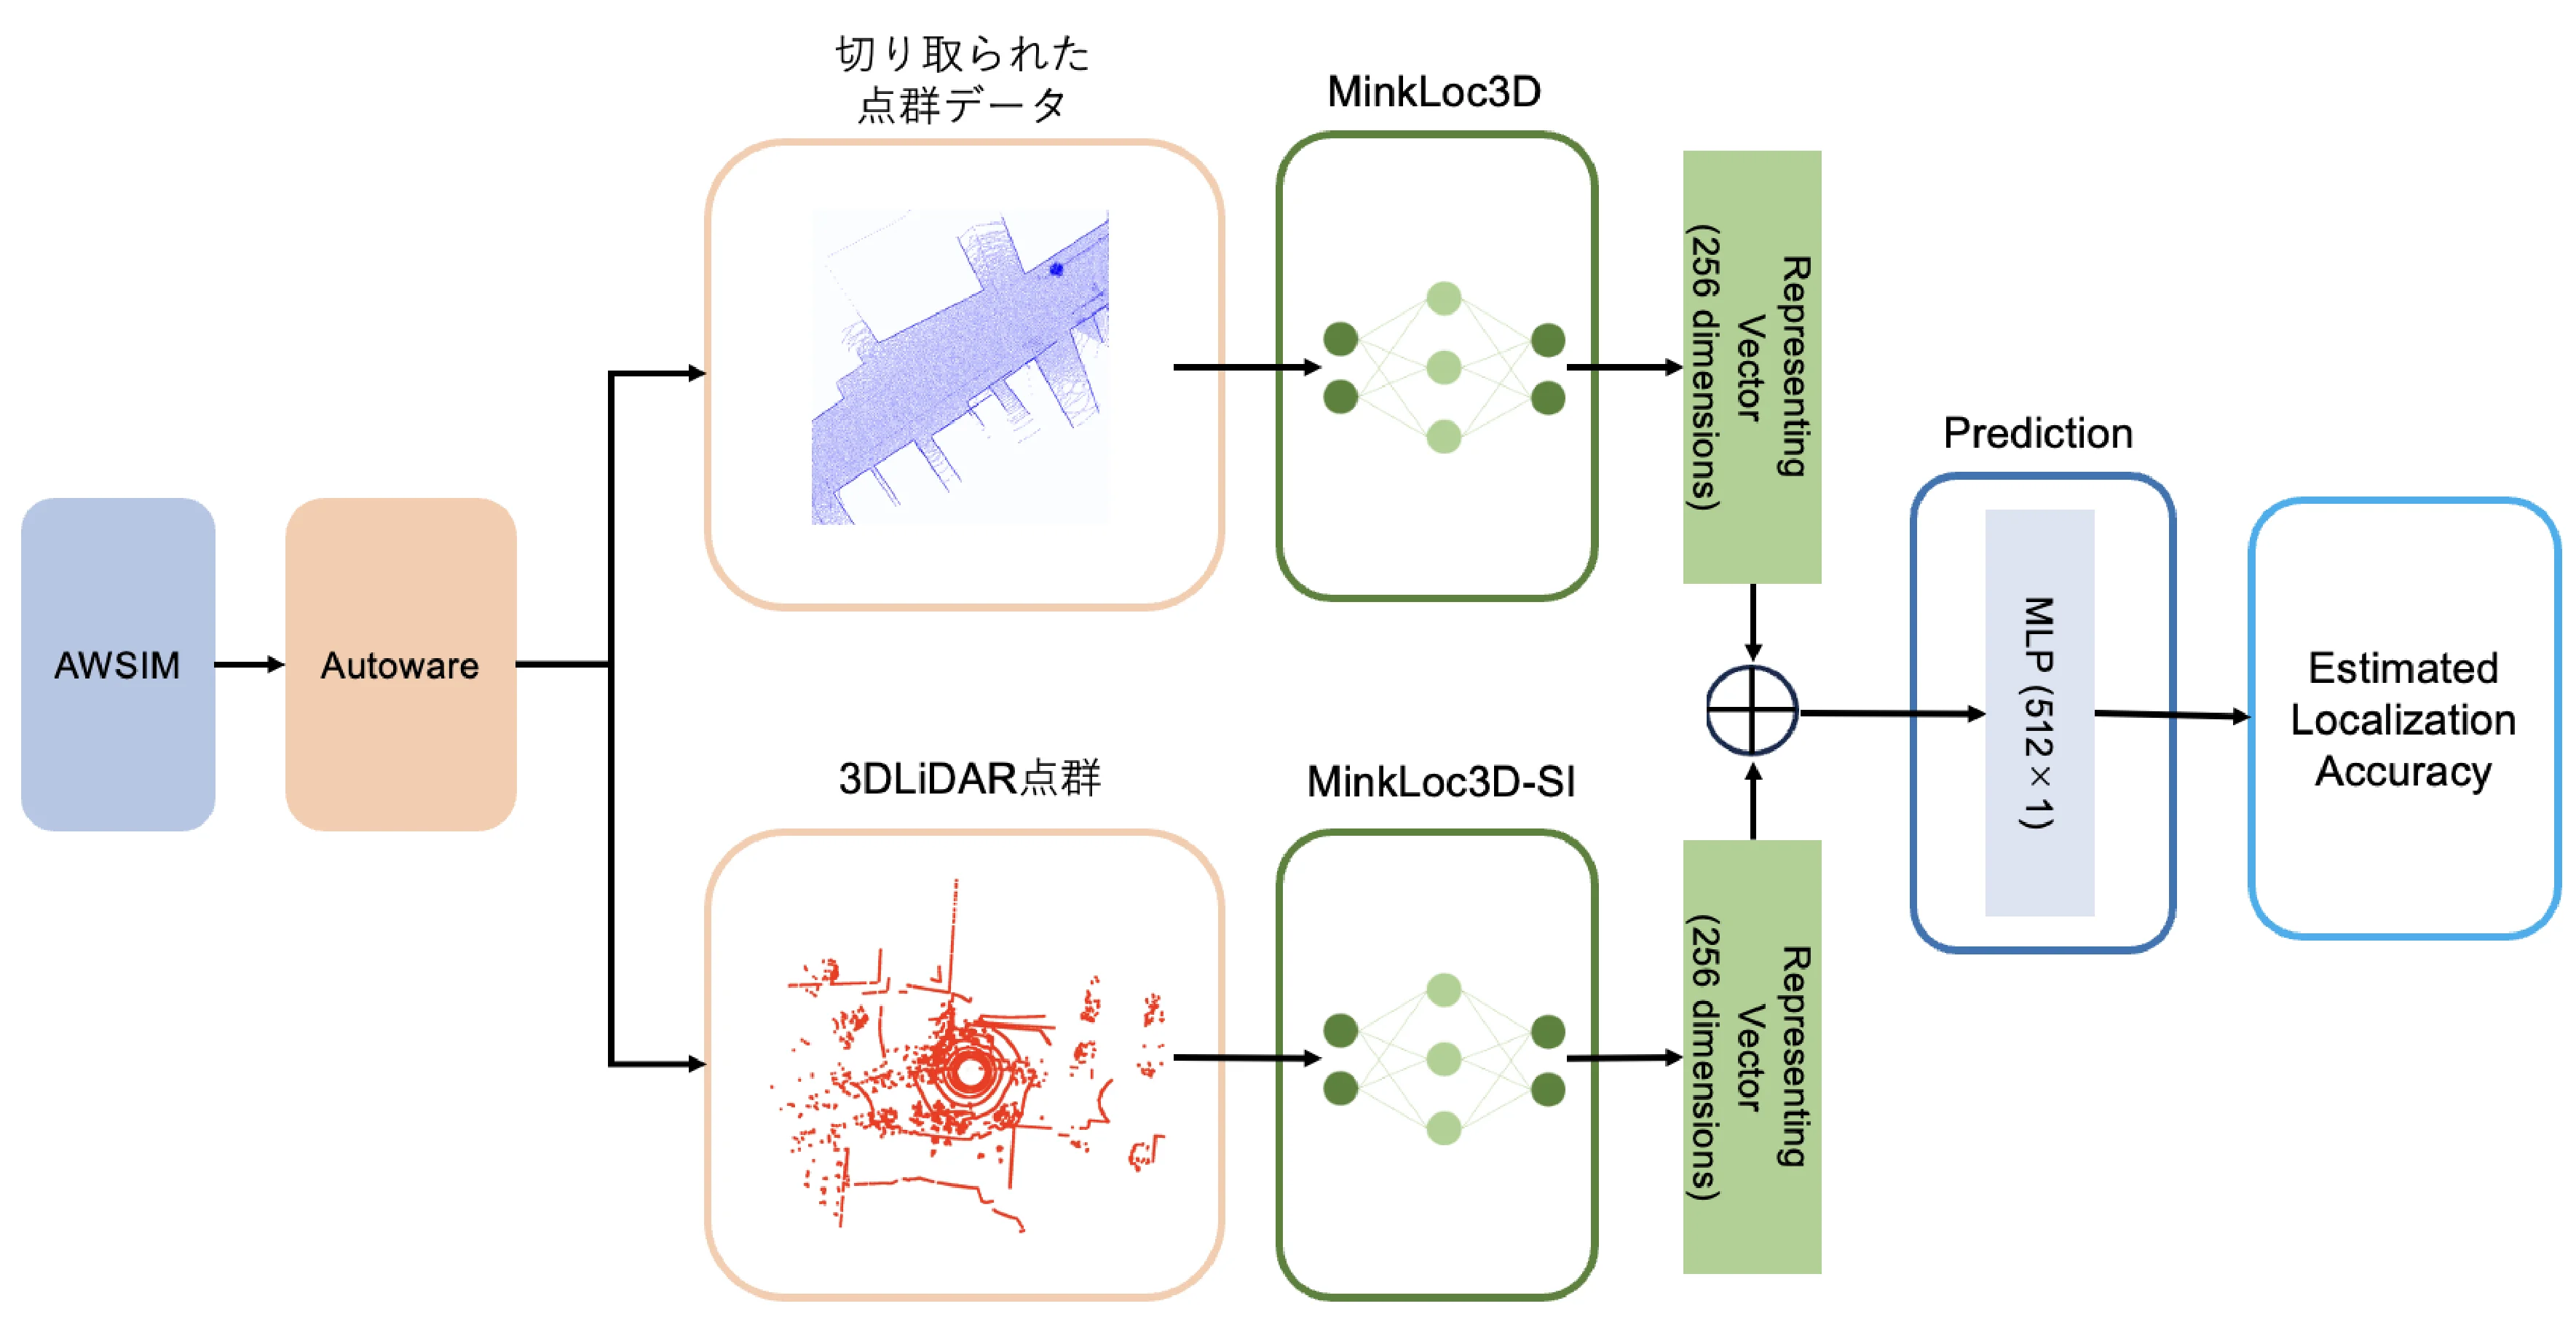
- LiDAR map matching can lose accuracy in places with few distinctive features.
- The thesis uses deep learning to extract features from vehicle LiDAR and point-cloud maps and predict localization accuracy.
- It compares point-cloud representations using MinkLoc3D and MinkLoc3D-SI.
Figures from the paper
How to cite
K. Matsumoto, “Localizability Estimation for Autonomous Driving: A Deep Learning-Based Feature Extraction Approach,” in Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo, 2024.
BibTeX
@mastersthesis{Matsumoto2024Thesis,
  title     = {Localizability Estimation for Autonomous Driving: A Deep Learning-Based Feature Extraction Approach},
  author    = {Kazuto Matsumoto},
  year      = {2024},
  date      = {2024-03-30},
  urldate   = {2024-03-31},
  school    = {Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo},
  keywords  = {ITS, Thesis},
  pubstate  = {published},
  tppubtype = {mastersthesis}
}