
Don't Worry, Just Follow Me: Prototyping and In-the-Wild Evaluation of Smart Pole Interaction Unit with Mobility
Honorable Mention AwardACM CHI Conference on Human Factors in Computing Systems (CHI 2026), Barcelona, Spain, Apr 13, 2026
Summary in three lines
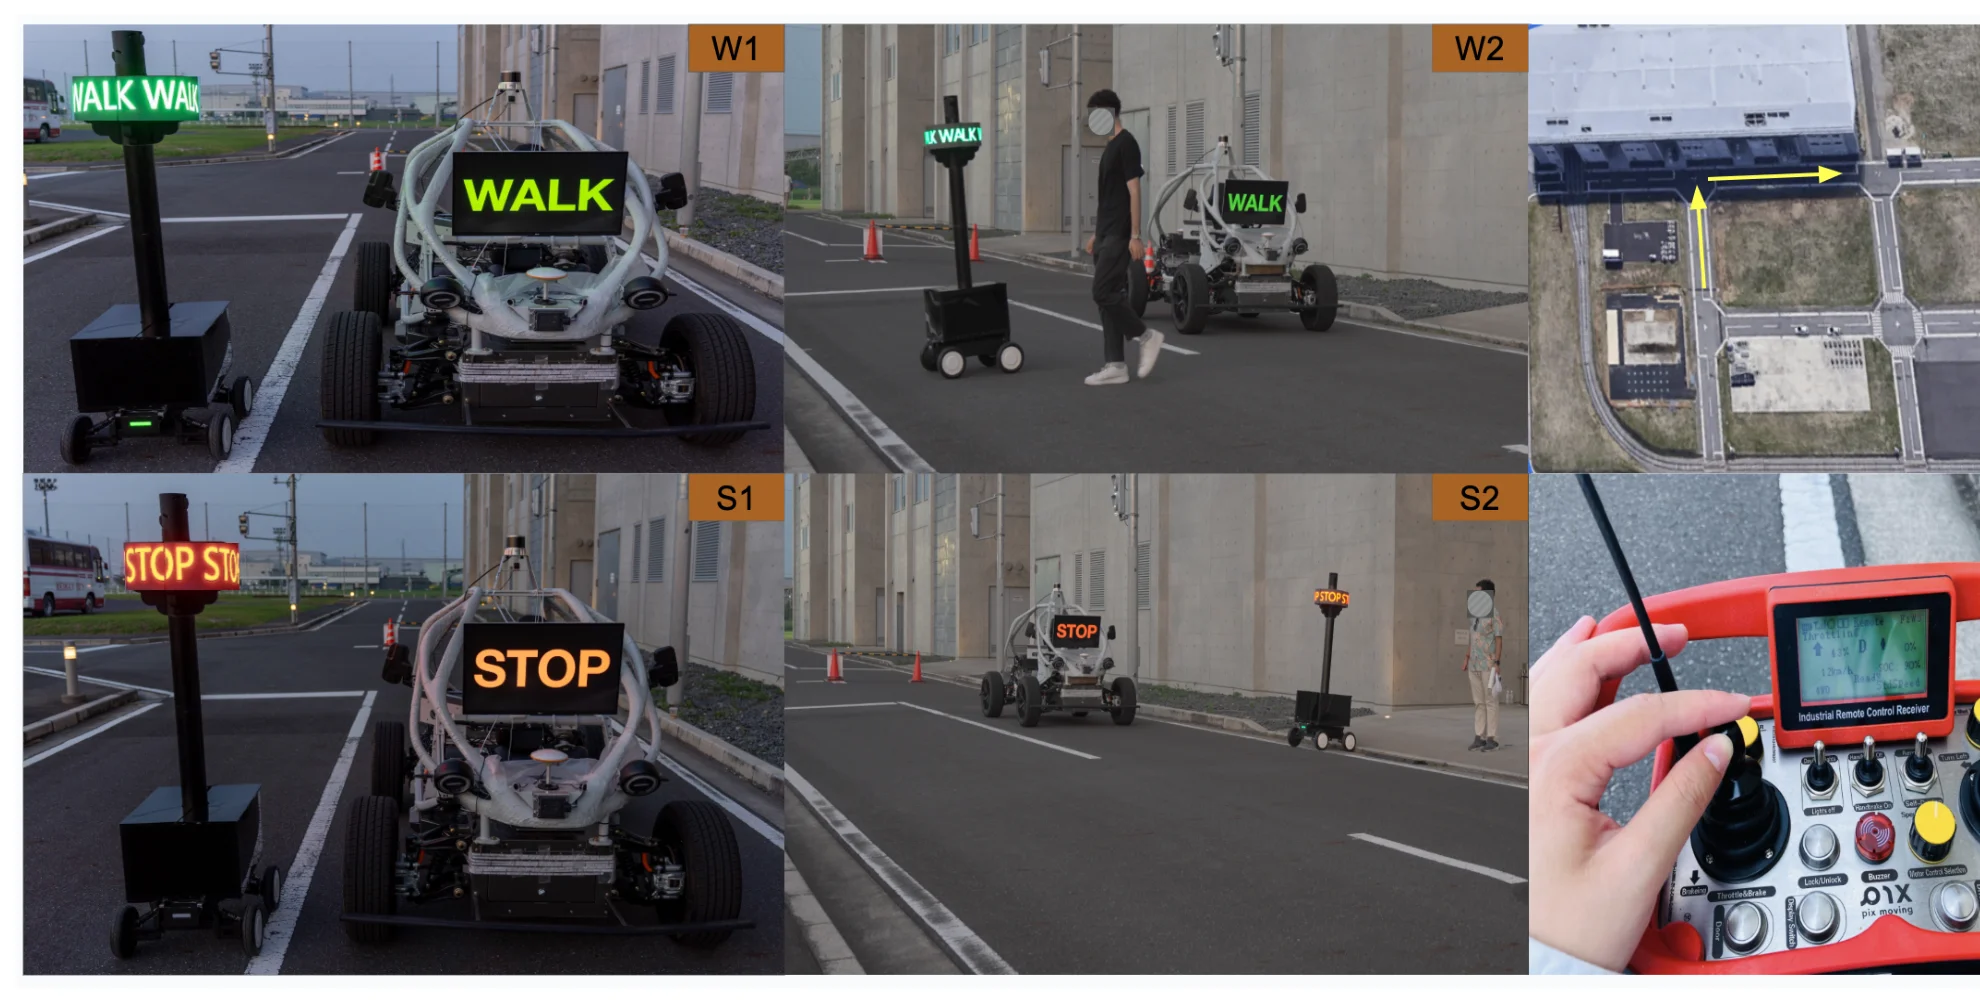
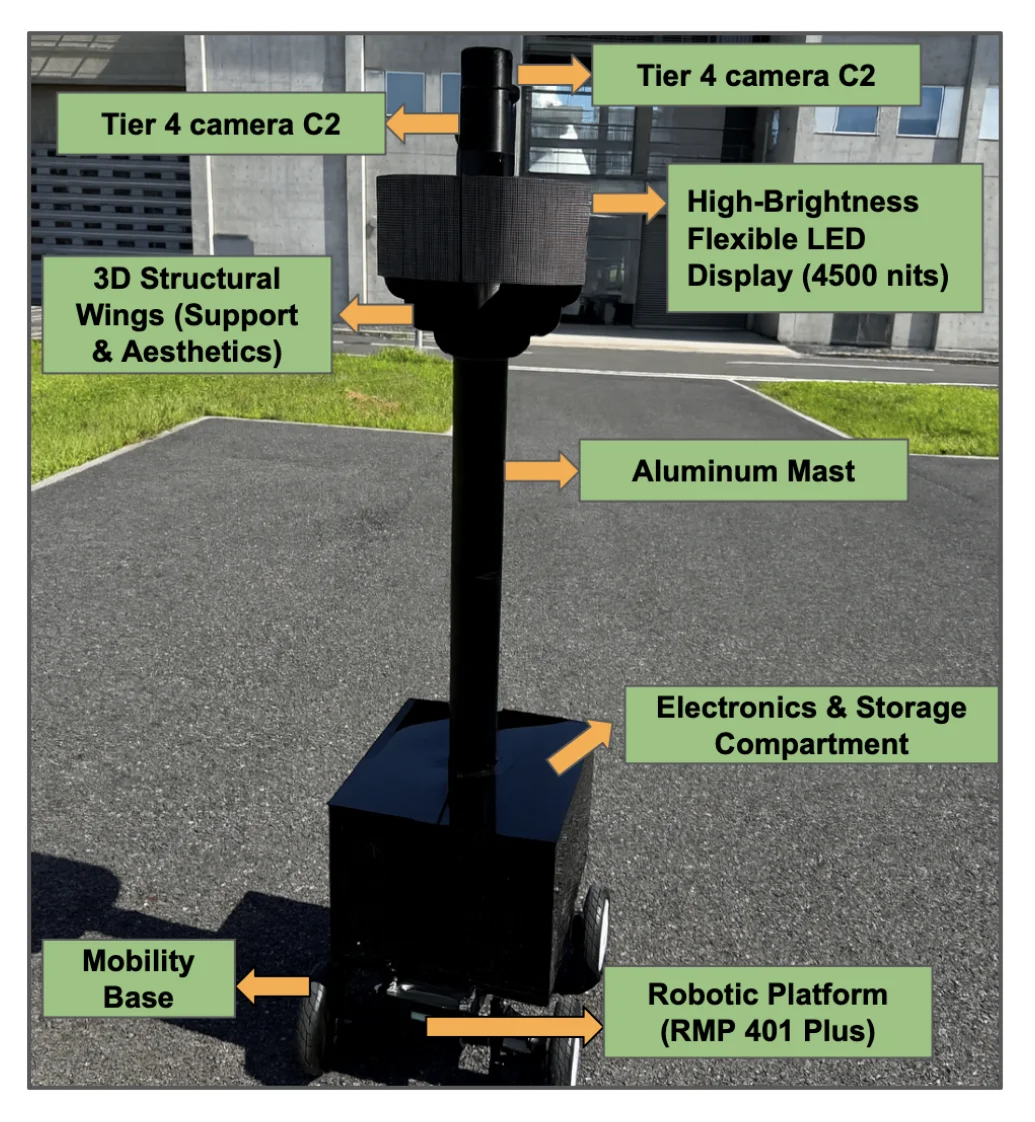
- Builds a mobile Smart Pole Interaction Unit (SPIU) and evaluates it in the wild with 21 participants on a closed shared-space lane.
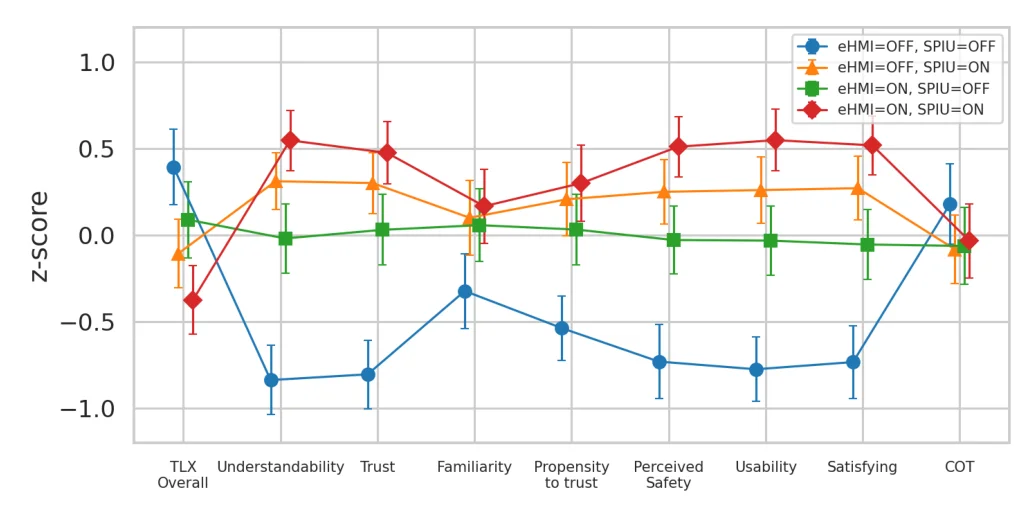
- A four-factor design (CarBehavior × Mobility × eHMI × SPIU) shows that combining the eHMI with the SPIU gives the best understandability, trust and perceived safety, with the lowest workload.
- Carries the earlier VR evaluation into the real world and proposes a new concept: a personal eHMI that moves with the pedestrian.
Figures from the paper
Abstract
Pedestrian–automated vehicle(AV) encounters in shared spaces often involve hesitation and ambiguity. Vehicle-mounted external human–machine interfaces(eHMIs) can help, but obscured or poorly timed communications create significant challenges. To address this, we present a mobile smart pole interaction unit(SPIU) with integrated cameras and LED displays, designed as a pedestrian-side system to deliver explicit cues(“WALK,” “STOP”). An in-the-wild evaluation of the SPIU(N=21) using a four-factor analysis (CarBehavior, Mobility, eHMI, SPIU) showed that the SPIU improved understandability, trust, and perceived safety, and reduced workload compared with the baseline, with a combination(eHMI+SPIU) yielding the strongest results. Beyond these quantitative benefits, participants appreciated the mobility of the SPIU for its “clear” and “easy to decide” mediation. This work contributes to(1) a design and deployment framework for a mobile SPIU and(2) an in-the-wild evaluation protocol for pedestrian–AV interactions in nonsignalized spaces. Our work sparks discussions on real world evaluations involving detailed vehicle kinematics and accessible multimodality(e.g., audio), focusing on the role of personal robots as user-side eHMIs.
Video
Related research and software
Related news
How to cite
V. Chauhan, A. Anubhav, M. Colley, C.-M. Chang, X. Gui, D. Xia, E. Javanmardi, T. Igarashi, K. Fujiwara, and M. Tsukada, “Don't Worry, Just Follow Me: Prototyping and In-the-Wild Evaluation of Smart Pole Interaction Unit with Mobility,” in ACM CHI Conference on Human Factors in Computing Systems (CHI 2026), Barcelona, Spain, 2026, doi: 10.1145/3772318.3790882.
BibTeX
@inproceedings{Chauhan2026b,
  title         = {Don't Worry, Just Follow Me: Prototyping and In-the-Wild Evaluation of Smart Pole Interaction Unit with Mobility},
  author        = {Vishal Chauhan and Anubhav Anubhav and Mark Colley and Chia-Ming Chang and Xinyue Gui and Ding Xia and Ehsan Javanmardi and Takeo Igarashi and Kantaro Fujiwara and Manabu Tsukada},
  url           = {https://youtu.be/PLmCgmTwsHQ},
  doi           = {10.1145/3772318.3790882},
  year          = {2026},
  date          = {2026-04-13},
  urldate       = {2026-04-13},
  booktitle     = {ACM CHI Conference on Human Factors in Computing Systems (CHI 2026)},
  address       = {Barcelona, Spain},
  abstract      = {Pedestrian–automated vehicle(AV) encounters in shared spaces often involve hesitation and ambiguity. Vehicle-mounted external human–machine interfaces(eHMIs) can help, but obscured or poorly timed communications create significant challenges. To address this, we present a mobile smart pole interaction unit(SPIU) with integrated cameras and LED displays, designed as a pedestrian-side system to deliver explicit cues(``WALK,'' ``STOP''). An in-the-wild evaluation of the SPIU(N=21) using a four-factor analysis (CarBehavior, Mobility, eHMI, SPIU) showed that the SPIU improved understandability, trust, and perceived safety, and reduced workload compared with the baseline, with a combination(eHMI+SPIU) yielding the strongest results. Beyond these quantitative benefits, participants appreciated the mobility of the SPIU for its ``clear'' and ``easy to decide'' mediation. This work contributes to(1) a design and deployment framework for a mobile SPIU and(2) an in-the-wild evaluation protocol for pedestrian–AV interactions in nonsignalized spaces. Our work sparks discussions on real world evaluations involving detailed vehicle kinematics and accessible multimodality(e.g., audio), focusing on the role of personal robots as user-side eHMIs.},
  note          = {Honorable Mention Award},
  keywords      = {Award, CRONOS, ITS},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}