
Generation of V2X messages from Carla Simulator for cooperative perception: Application to pedestrian safety
IEEE 100th Vehicular Technology Conference (VTC2024-Fall), Washington D.C., USA, Oct 7, 2024
DOI: 10.1109/VTC2024-Fall63153.2024.10757467
Summary in three lines
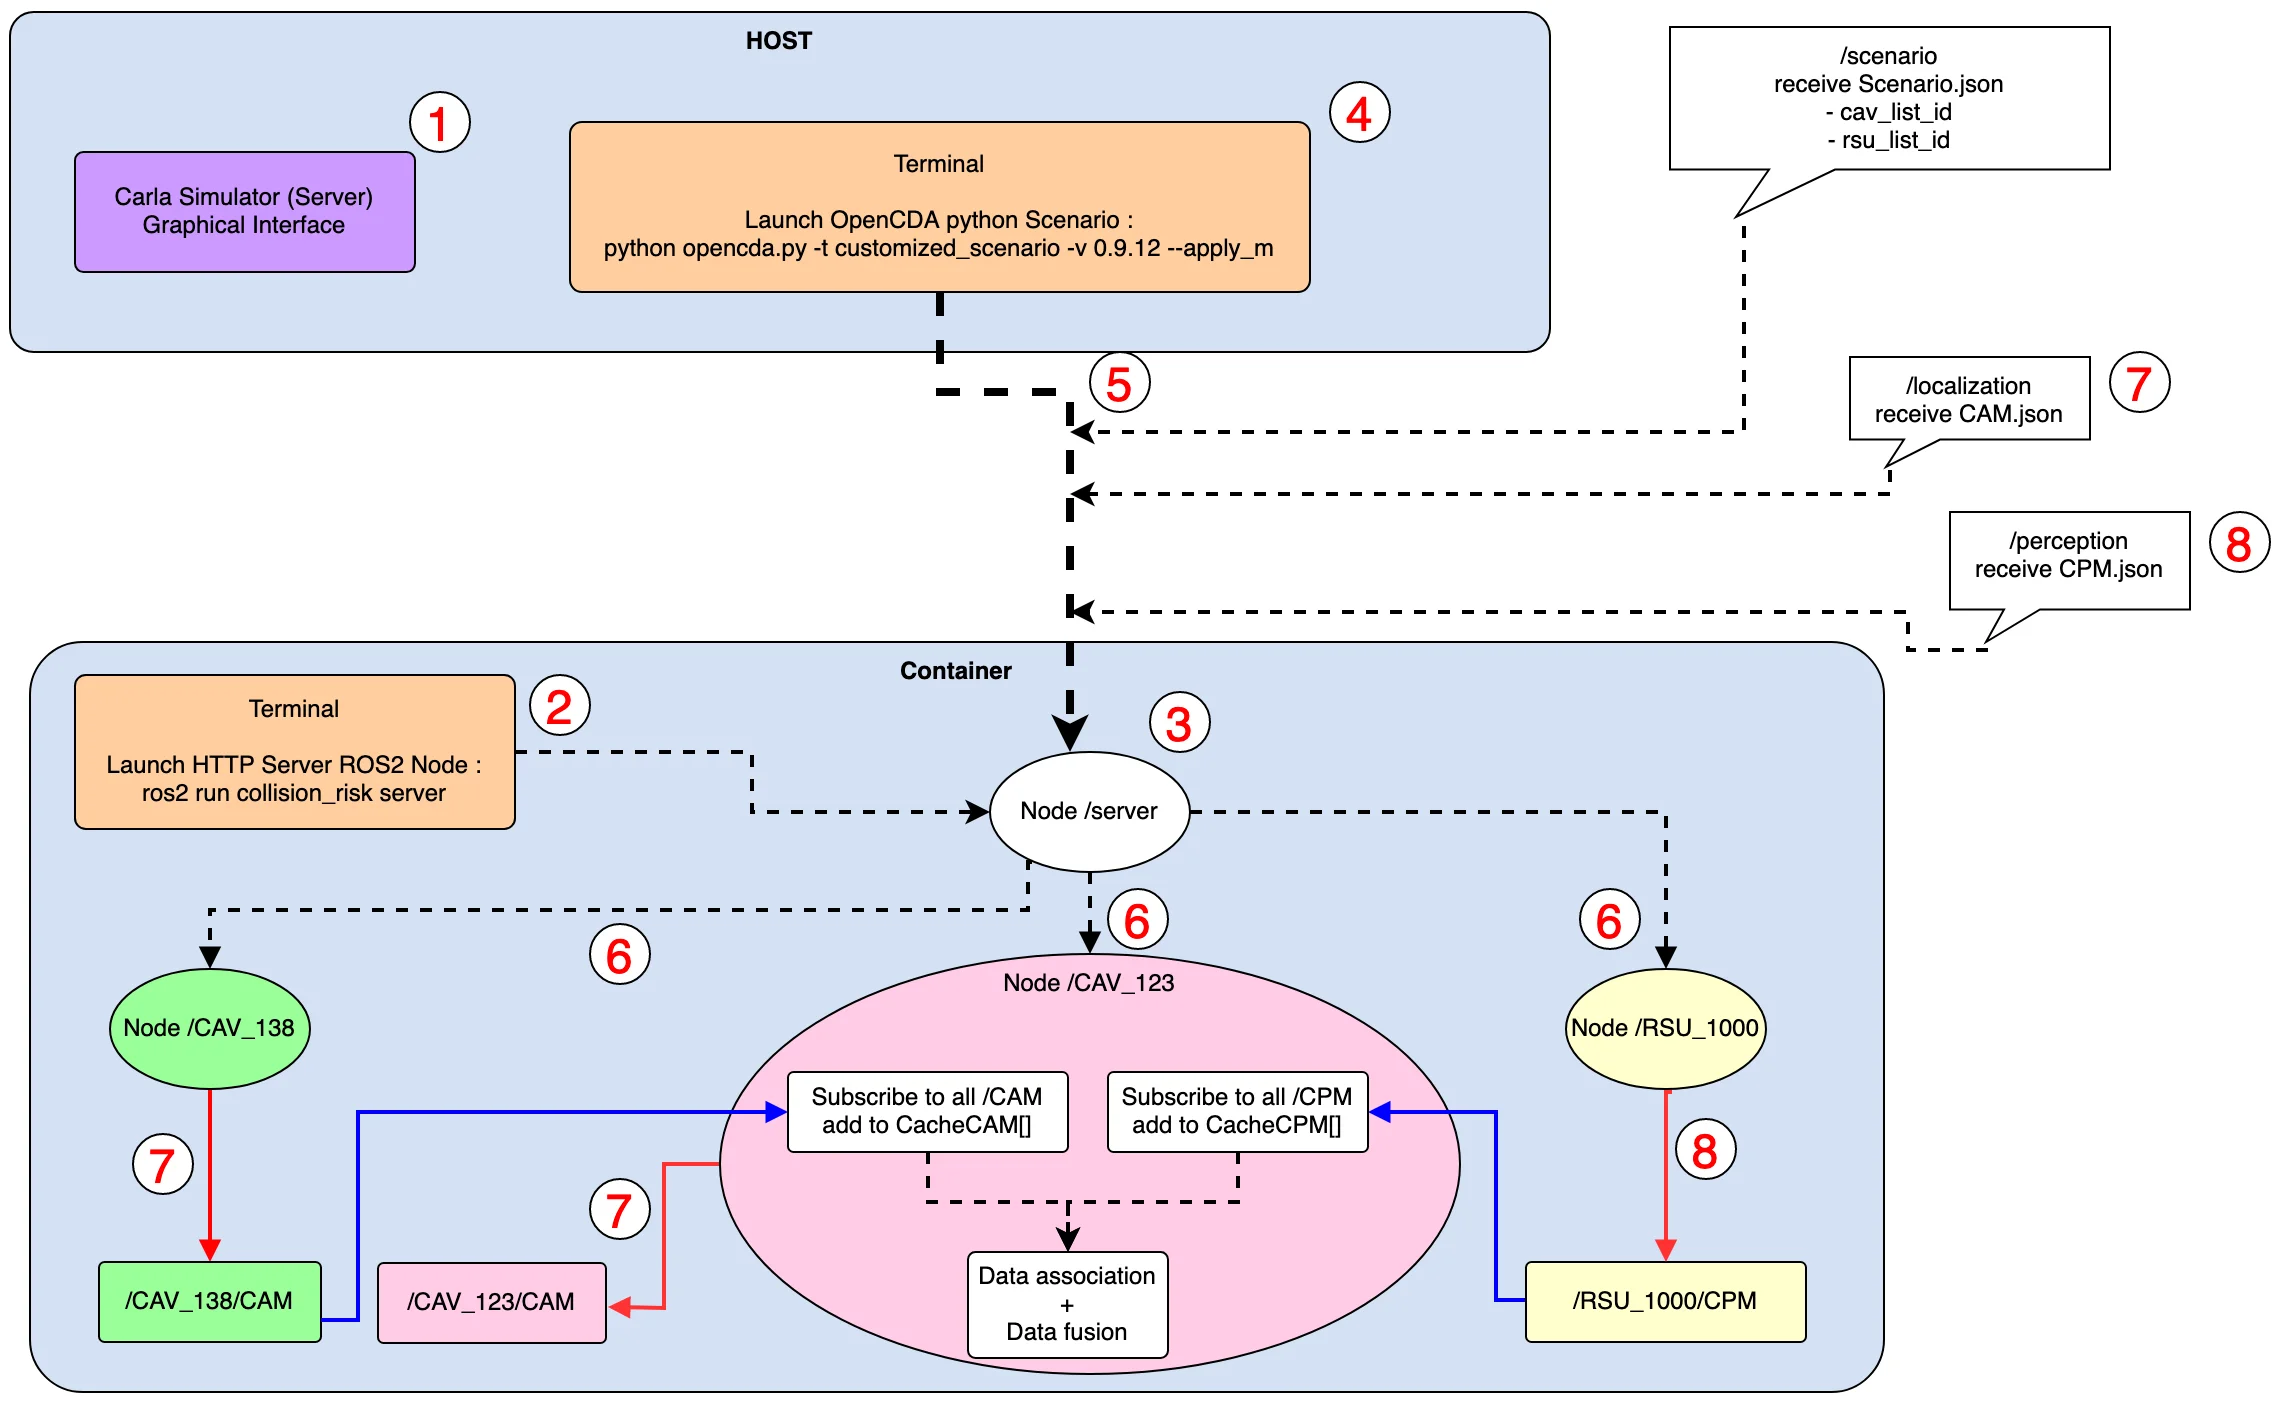
- The authors extend CARLA with OpenCDA and ROS 2 to generate V2X messages from vehicles and roadside units.
- The framework can generate datasets for testing driver-assistance algorithms.
- A pedestrian hidden from a connected vehicle illustrates the use of cooperative perception.
Figures from the paper
Abstract
Despite advancements in connected and autonomous vehicles (CAVs), vulnerable road users (VRUs) face a challenge as they lack Communication-Intelligent Transport System (C-ITS) equipment. This deficiency impedes their interaction with CAVs. We underscore the significance of Vehicle-to-Everything (V2X) communication in enhancing road safety with VRUs by facilitating information exchange between CAVs and the infrastructure. This communication is pivotal for reintegrating VRUs into the environmental awareness of CAVs. The Carla Simulator, used for autonomous vehicle training, currently lacks comprehensive V2X communication capabilities. In response, we propose an architecture for Carla, integrating OpenCDA and ROS2 to establish a simulated V2X network communication system for CAVs and roadside units (RSUs) within the Carla environment. This setup allows for the generation of V2X datasets and the refinement of algorithms for Advanced Driver Assistance Systems (ADAS). To illustrate and assess our proposed architecture, we present a scenario involving a pedestrian concealed in a blind spot for a connected vehicle.
How to cite
J. Grosset, J.-M. Bonnin, A.-J. Fougères, M. Tsukada, and M. Djoko-Kouam, “Generation of V2X messages from Carla Simulator for cooperative perception: Application to pedestrian safety,” in IEEE 100th Vehicular Technology Conference (VTC2024-Fall), Washington D.C., USA, 2024, doi: 10.1109/VTC2024-Fall63153.2024.10757467.
BibTeX
@inproceedings{Grosset2024,
  title         = {Generation of V2X messages from Carla Simulator for cooperative perception: Application to pedestrian safety},
  author        = {Juliette Grosset and Jean-Marie Bonnin and Alain-Jérôme Fougères and Manabu Tsukada and Moise Djoko-Kouam},
  doi           = {10.1109/VTC2024-Fall63153.2024.10757467},
  year          = {2024},
  date          = {2024-10-07},
  urldate       = {2024-10-07},
  booktitle     = {IEEE 100th Vehicular Technology Conference (VTC2024-Fall)},
  address       = {Washington D.C., USA},
  abstract      = {Despite advancements in connected and autonomous vehicles (CAVs), vulnerable road users (VRUs) face a challenge as they lack Communication-Intelligent Transport System (C-ITS) equipment. This deficiency impedes their interaction with CAVs. We underscore the significance of Vehicle-to-Everything (V2X) communication in enhancing road safety with VRUs by facilitating information exchange between CAVs and the infrastructure. This communication is pivotal for reintegrating VRUs into the environmental awareness of CAVs. The Carla Simulator, used for autonomous vehicle training, currently lacks comprehensive V2X communication capabilities. In response, we propose an architecture for Carla, integrating OpenCDA and ROS2 to establish a simulated V2X network communication system for CAVs and roadside units (RSUs) within the Carla environment. This setup allows for the generation of V2X datasets and the refinement of algorithms for Advanced Driver Assistance Systems (ADAS). To illustrate and assess our proposed architecture, we present a scenario involving a pedestrian concealed in a blind spot for a connected vehicle.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}