
Regionally Optimized Path Planning with Genetic Algorithm-Based Potential Fields
Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo, Mar 31, 2022
Summary in three lines
- The thesis proposes adapting autonomous driving behavior to local road characteristics.
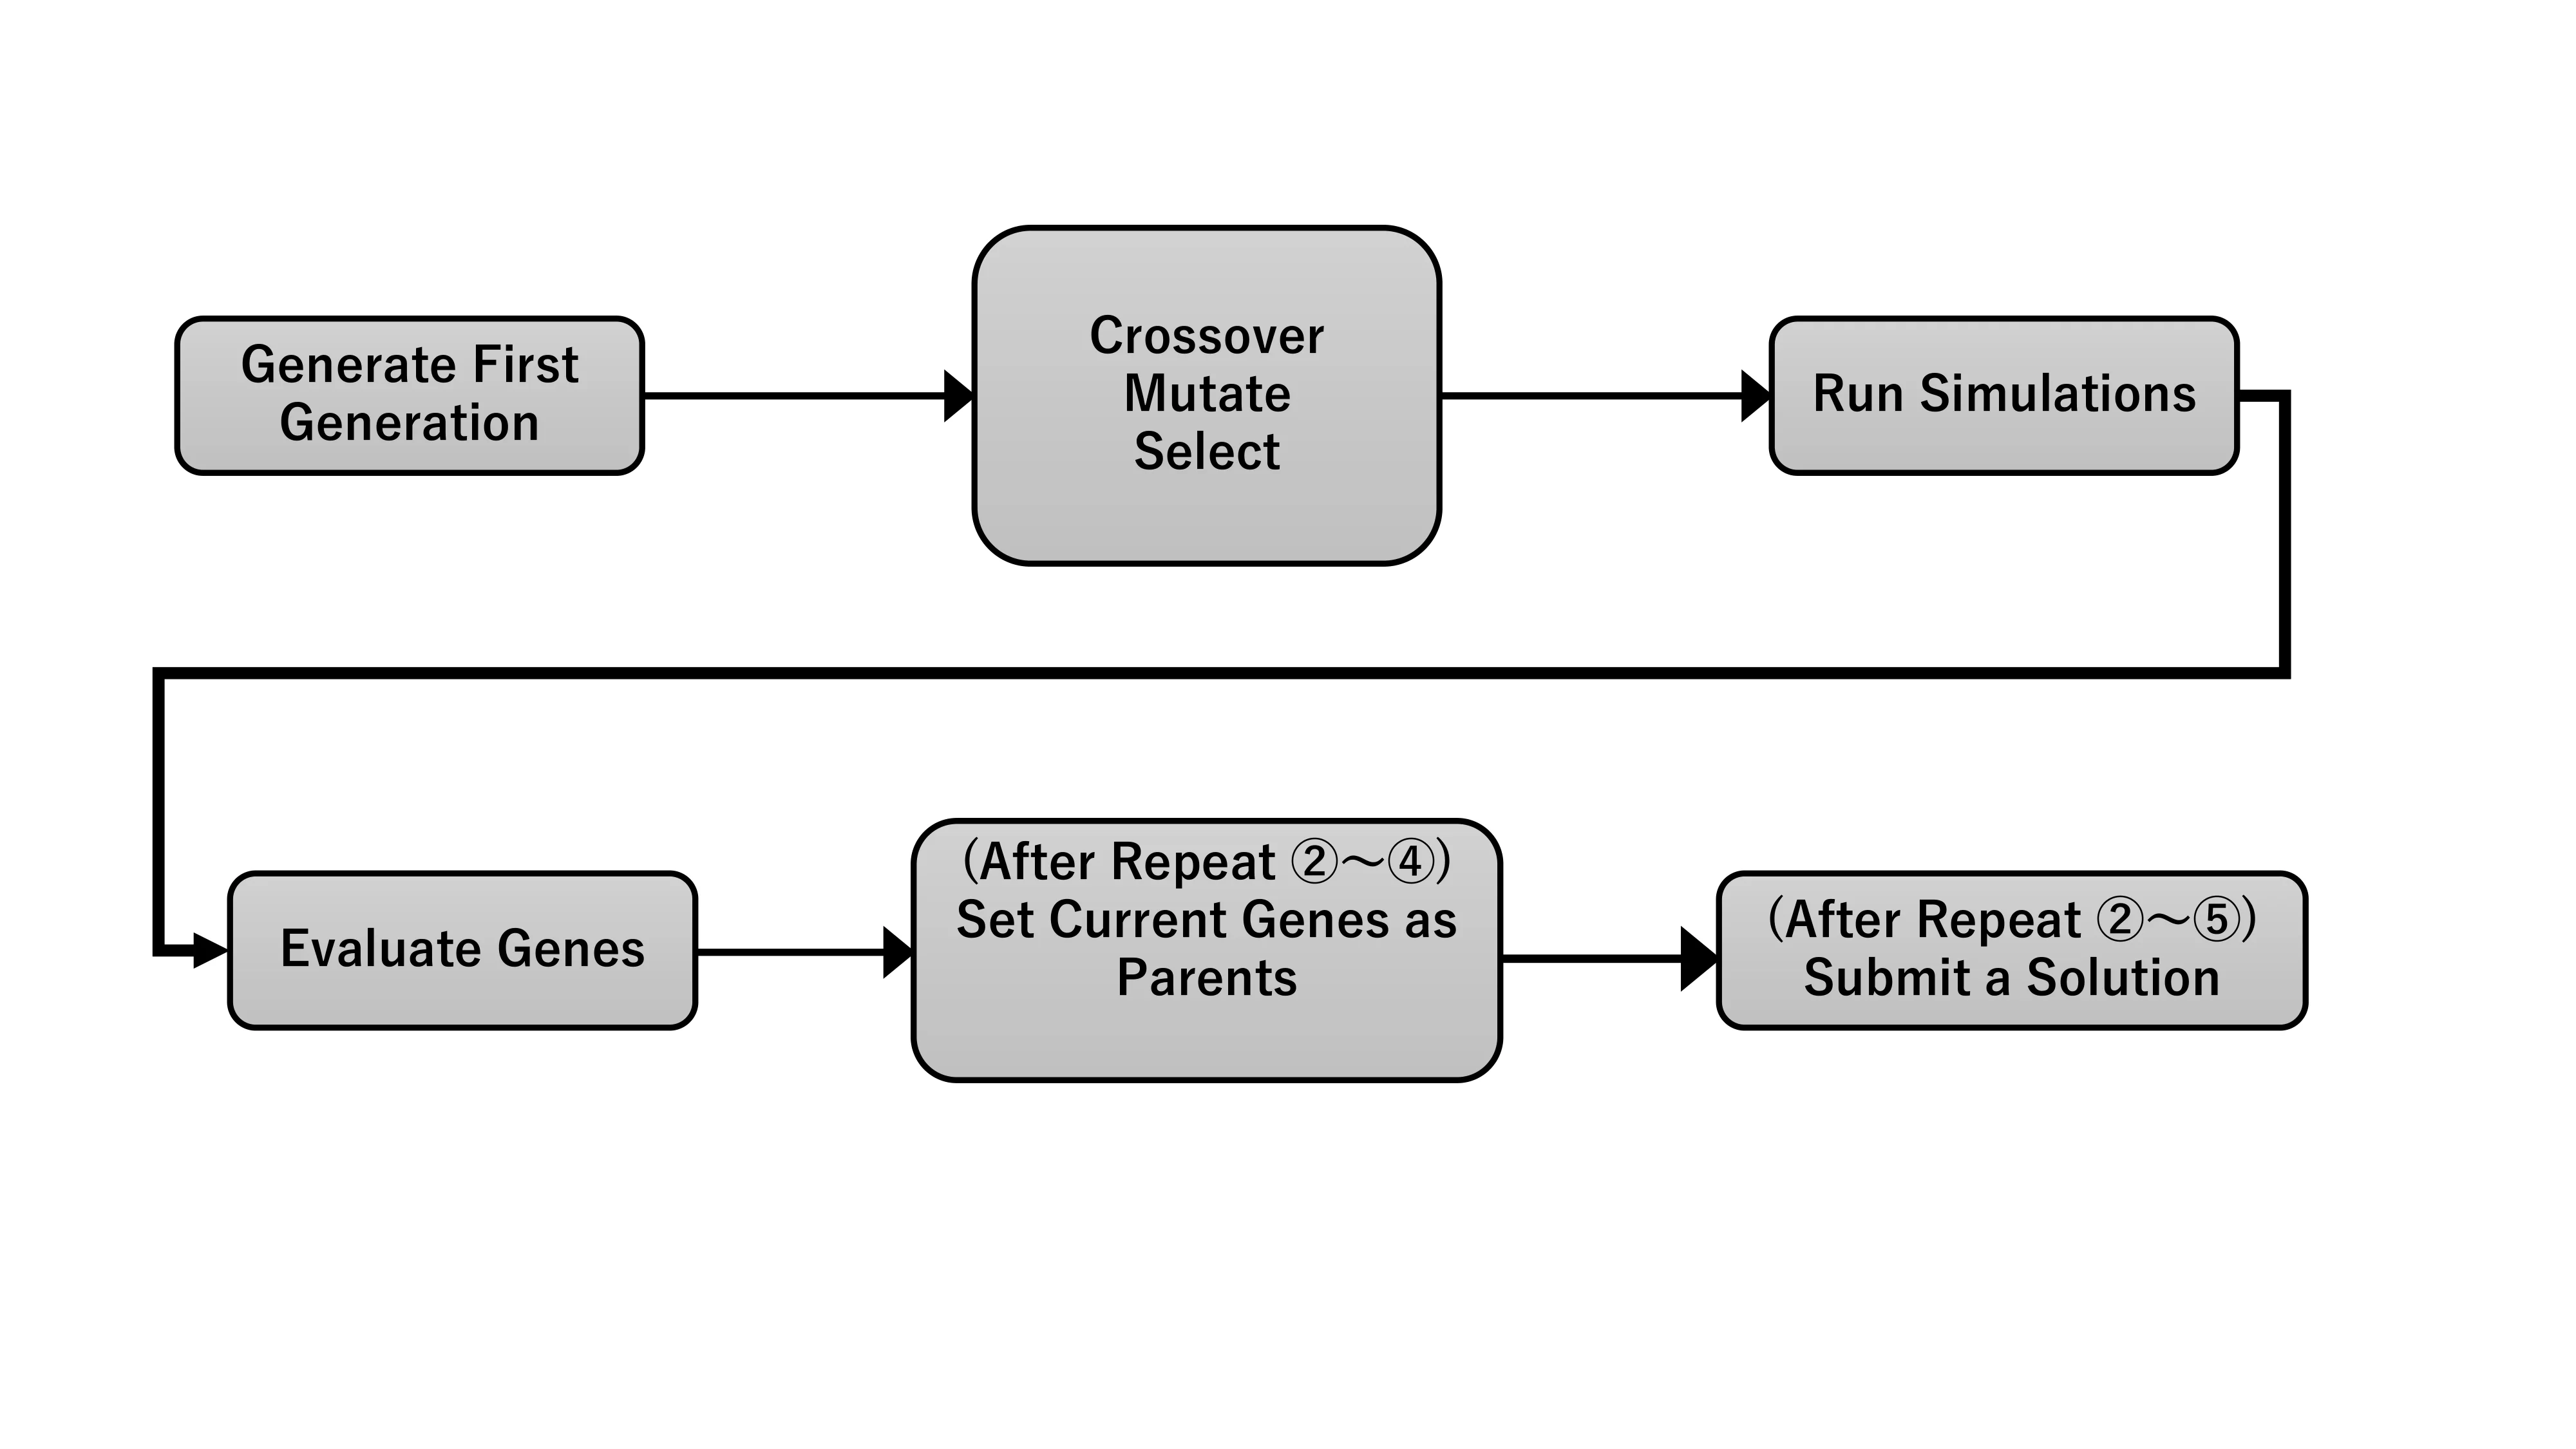
- A genetic algorithm tunes artificial potential-field parameters for specific road segments.
- In the reported test with one other vehicle, the tuned planner maintained a larger separation.
Figures from the paper
How to cite
T. Hirose, “Regionally Optimized Path Planning with Genetic Algorithm-Based Potential Fields,” in Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo, 2022.
BibTeX
@mastersthesis{Hirose2022,
  title     = {Regionally Optimized Path Planning with Genetic Algorithm-Based Potential Fields},
  author    = {Toshihiko Hirose},
  year      = {2022},
  date      = {2022-03-31},
  urldate   = {2022-03-31},
  school    = {Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo},
  keywords  = {ITS, Thesis},
  pubstate  = {published},
  tppubtype = {mastersthesis}
}