
DoA Estimation and Kalman Filter based Multi-Antenna System for Vehicle Position in mmWave Network
IEEE Open Journal of Vehicular Technology, vol. 6, pp. 2761–2775, Sep 14, 2025
DOI: 10.1109/OJVT.2025.3608747
Summary in three lines
- The paper estimates vehicle position and velocity from mmWave antenna-array signals in settings where GPS accuracy is limited.
- A low-complexity two-dimensional MUSIC estimator provides angular estimates for an unscented Kalman filter.
- Simulations compare positioning accuracy with a compressive-sensing method across noise levels and array sizes.
Figures from the paper
Abstract
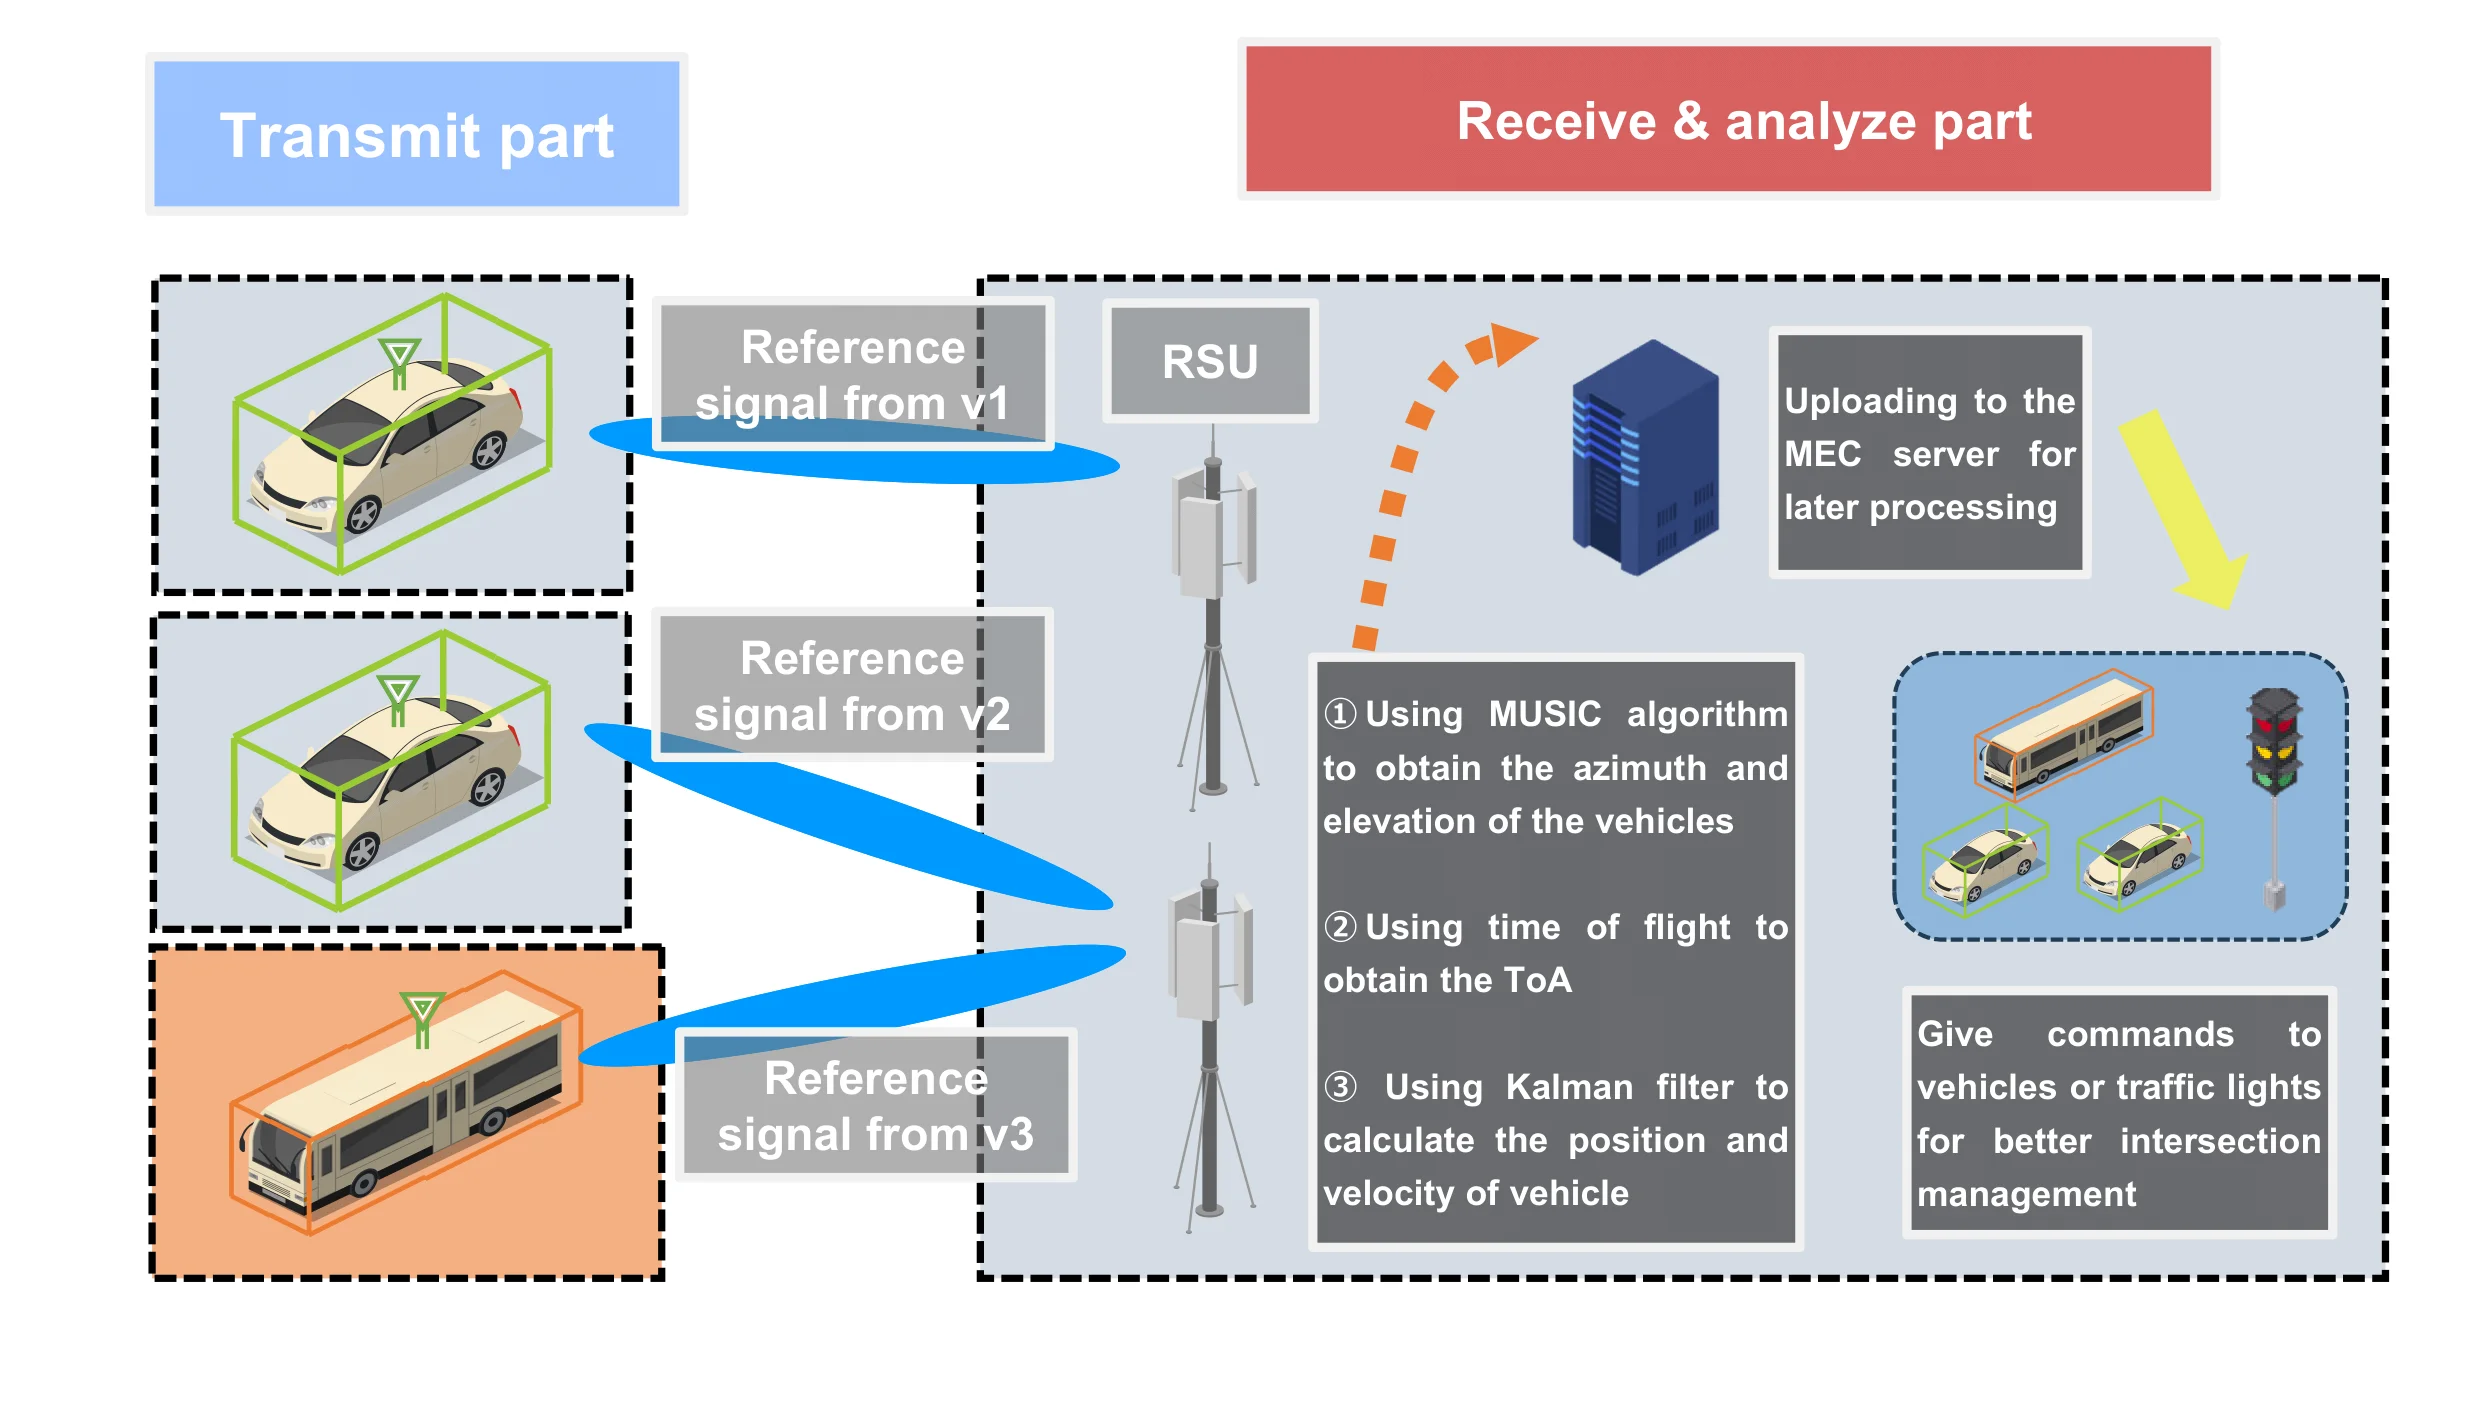
With the advancement of Beyond 5G/6G technologies, accurate positioning and velocity estimation in Internet of Vehicles (IoV) systems has become increasingly critical. Although GPS can provide real-time location information, its performance degrades significantly in environments with heavy obstructions, such as urban areas surrounded by skyscrapers. To address this limitation, this study proposes a positioning framework that relies on channel parameter estimation derived from multi-antenna signal processing. Specifically, we adopt an adaptive low-complexity 2D MUSIC (ALC2D-MUSIC) algorithm to estimate signal directions, and further apply an unscented Kalman filter (UKF) using extracted Direction of Arrival (DoA) and Time of Arrival (ToA) information to estimate vehicle positions and velocities. The proposed system is robust to variations in road geometry, making it suitable for deployment in diverse traffic environments. Simulation results demonstrate that our method achieves high estimation accuracy and outperforms a compressive sensing-based approach across different SNR levels, angular search resolutions, and antenna array sizes. Furthermore, the UKF-based tracking algorithm shows superior performance in curved road scenarios, validating its effectiveness under realistic mobility conditions.
Related research and software
How to cite
D. Hu, J. Nakazato, E. Javanmardi, K. Maruta, R. Dinis, and M. Tsukada, “DoA Estimation and Kalman Filter based Multi-Antenna System for Vehicle Position in mmWave Network,” IEEE Open Journal of Vehicular Technology, vol. 6, pp. 2761–2775, 2025, doi: 10.1109/OJVT.2025.3608747.
BibTeX
@article{Hu2025c,
  title         = {DoA Estimation and Kalman Filter based Multi-Antenna System for Vehicle Position in mmWave Network},
  author        = {Dou Hu and Jin Nakazato and Ehsan Javanmardi and Kazuki Maruta and Rui Dinis and Manabu Tsukada},
  doi           = {10.1109/OJVT.2025.3608747},
  issn          = {2644-1330},
  year          = {2025},
  date          = {2025-09-14},
  urldate       = {2025-09-14},
  journal       = {IEEE Open Journal of Vehicular Technology},
  volume        = {6},
  pages         = {2761--2775},
  abstract      = {With the advancement of Beyond 5G/6G technologies, accurate positioning and velocity estimation in Internet of Vehicles (IoV) systems has become increasingly critical. Although GPS can provide real-time location information, its performance degrades significantly in environments with heavy obstructions, such as urban areas surrounded by skyscrapers. To address this limitation, this study proposes a positioning framework that relies on channel parameter estimation derived from multi-antenna signal processing. Specifically, we adopt an adaptive low-complexity 2D MUSIC (ALC2D-MUSIC) algorithm to estimate signal directions, and further apply an unscented Kalman filter (UKF) using extracted Direction of Arrival (DoA) and Time of Arrival (ToA) information to estimate vehicle positions and velocities. The proposed system is robust to variations in road geometry, making it suitable for deployment in diverse traffic environments. Simulation results demonstrate that our method achieves high estimation accuracy and outperforms a compressive sensing-based approach across different SNR levels, angular search resolutions, and antenna array sizes. Furthermore, the UKF-based tracking algorithm shows superior performance in curved road scenarios, validating its effectiveness under realistic mobility conditions.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {article}
}