
Roadside LiDAR Assisted Cooperative Localization for Connected Autonomous Vehicles
Best Paper Award (Silver)ACM International Conference on Intelligent Computing and its Emerging Applications (ICEA 2023), Dec 14, 2023
Summary in three lines
- Onboard LiDAR map matching becomes less reliable when map features are sparse.
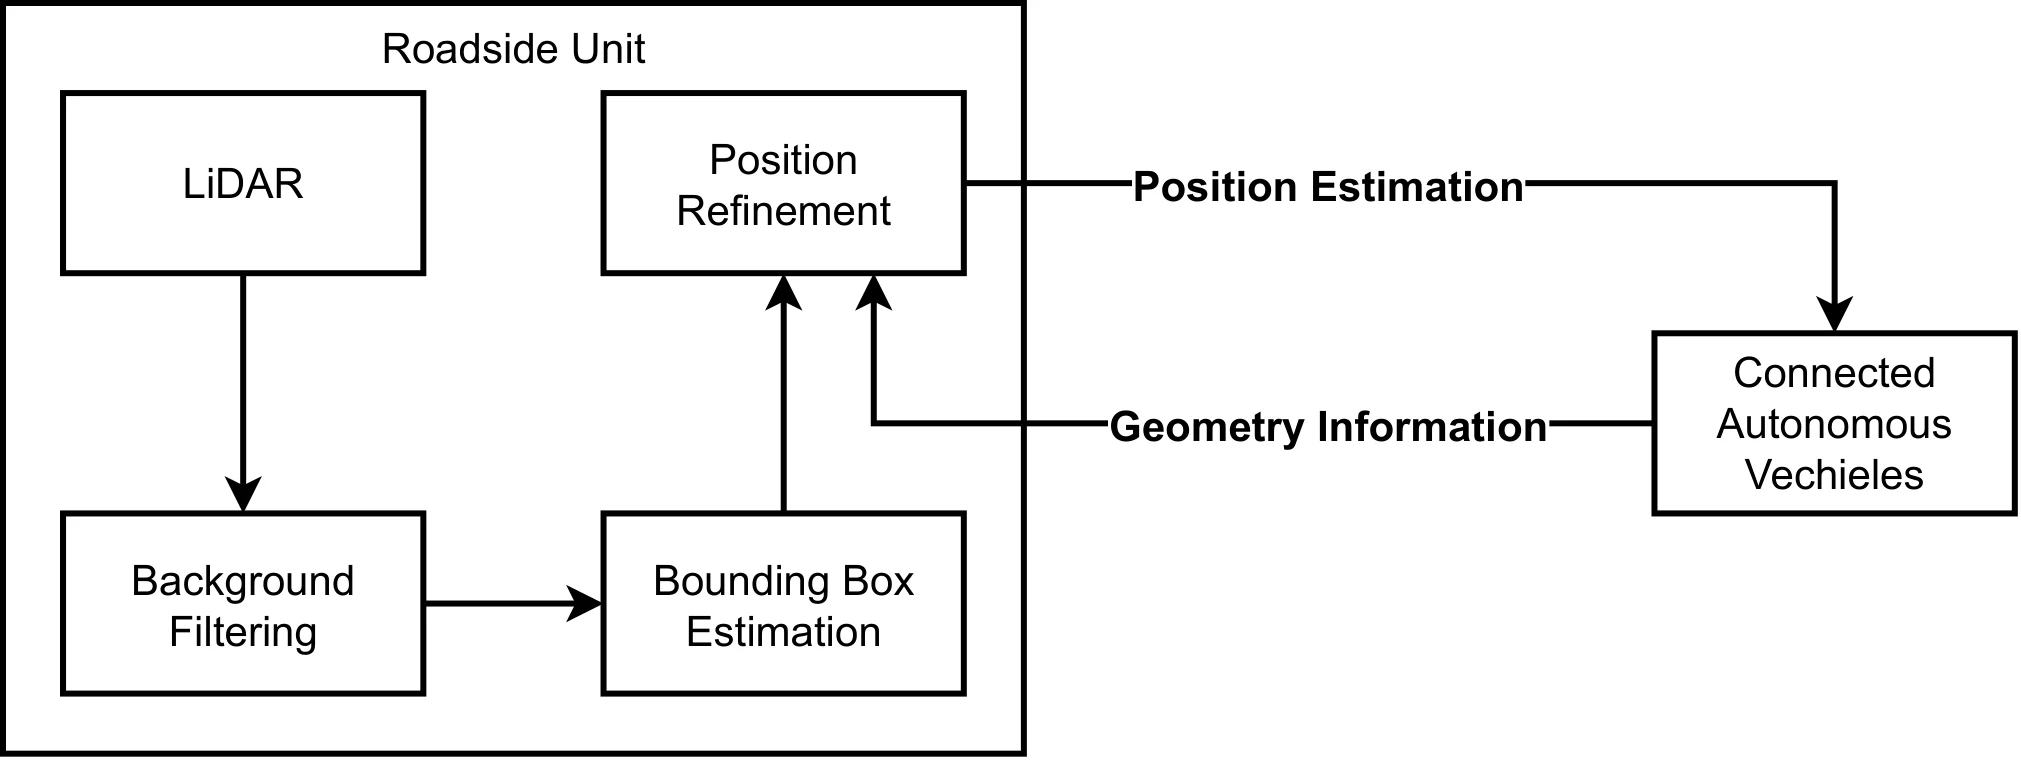
- The method uses roadside LiDAR and V2I to supply independent estimates of the connected vehicle’s position.
- In an AWSIM simulation of Nishi-Shinjuku, it lowered error relative to standalone NDT matching.
Figures from the paper
Abstract
Advancements in LiDAR technology have led to more cost-effective production while simultaneously improving precision and resolution. As a result, LiDAR has become integral to vehicle localization, achieving centimeter-level accuracy through techniques like Normal Distributions Transform (NDT) and other advanced 3D registration algorithms. Nonetheless, these approaches are reliant on high-definition 3D point cloud maps, the creation of which involves significant expenditure. When such maps are unavailable or lack sufficient features for 3D registration algorithms, localization accuracy diminishes, posing a risk to road safety. To address this, we proposed to use LiDAR-equipped roadside unit and Vehicle-to-Infrastructure (V2I) communication to accurately estimate the connected vehicle's position and help the vehicle when its self-localization is not accurate enough. Our simulation results indicate that this method outperforms traditional NDT scan matching-based approaches in terms of localization accuracy.
Related news
How to cite
Y. Jiang, E. Javanmardi, J. Nakazato, M. Tsukada, and H. Esaki, “Roadside LiDAR Assisted Cooperative Localization for Connected Autonomous Vehicles,” in ACM International Conference on Intelligent Computing and its Emerging Applications (ICEA 2023), 2023.
BibTeX
@inproceedings{Jiang2023,
  title         = {Roadside LiDAR Assisted Cooperative Localization for Connected Autonomous Vehicles},
  author        = {Yuze Jiang and Ehsan Javanmardi and Jin Nakazato and Manabu Tsukada and Hiroshi Esaki},
  url           = {https://arxiv.org/abs/2311.07913},
  year          = {2023},
  date          = {2023-12-14},
  urldate       = {2023-12-14},
  booktitle     = {ACM International Conference on Intelligent Computing and its Emerging Applications (ICEA 2023)},
  abstract      = {Advancements in LiDAR technology have led to more cost-effective production while simultaneously improving precision and resolution. As a result, LiDAR has become integral to vehicle localization, achieving centimeter-level accuracy through techniques like Normal Distributions Transform (NDT) and other advanced 3D registration algorithms. Nonetheless, these approaches are reliant on high-definition 3D point cloud maps, the creation of which involves significant expenditure. When such maps are unavailable or lack sufficient features for 3D registration algorithms, localization accuracy diminishes, posing a risk to road safety. To address this, we proposed to use LiDAR-equipped roadside unit and Vehicle-to-Infrastructure (V2I) communication to accurately estimate the connected vehicle's position and help the vehicle when its self-localization is not accurate enough. Our simulation results indicate that this method outperforms traditional NDT scan matching-based approaches in terms of localization accuracy.},
  note          = {Best Paper Award (Silver)},
  keywords      = {Award, ITS},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}