
Emergency-Aware Path Planning for Non-connected and Connected Autonomous Vehicles
Ph.D. Thesis, The University of Tokyo, Mar 31, 2024
Summary in three lines
- The thesis studies planning paralysis during emergencies in connected and non-connected autonomous vehicles.
- It identifies conditions that prevent potential-field planners from finding a safe path and models how drivers or vehicles may cooperate.
- The proposed framework monitors the planning field and prepares emergency trajectories with model predictive control.
Figures from the paper
Abstract
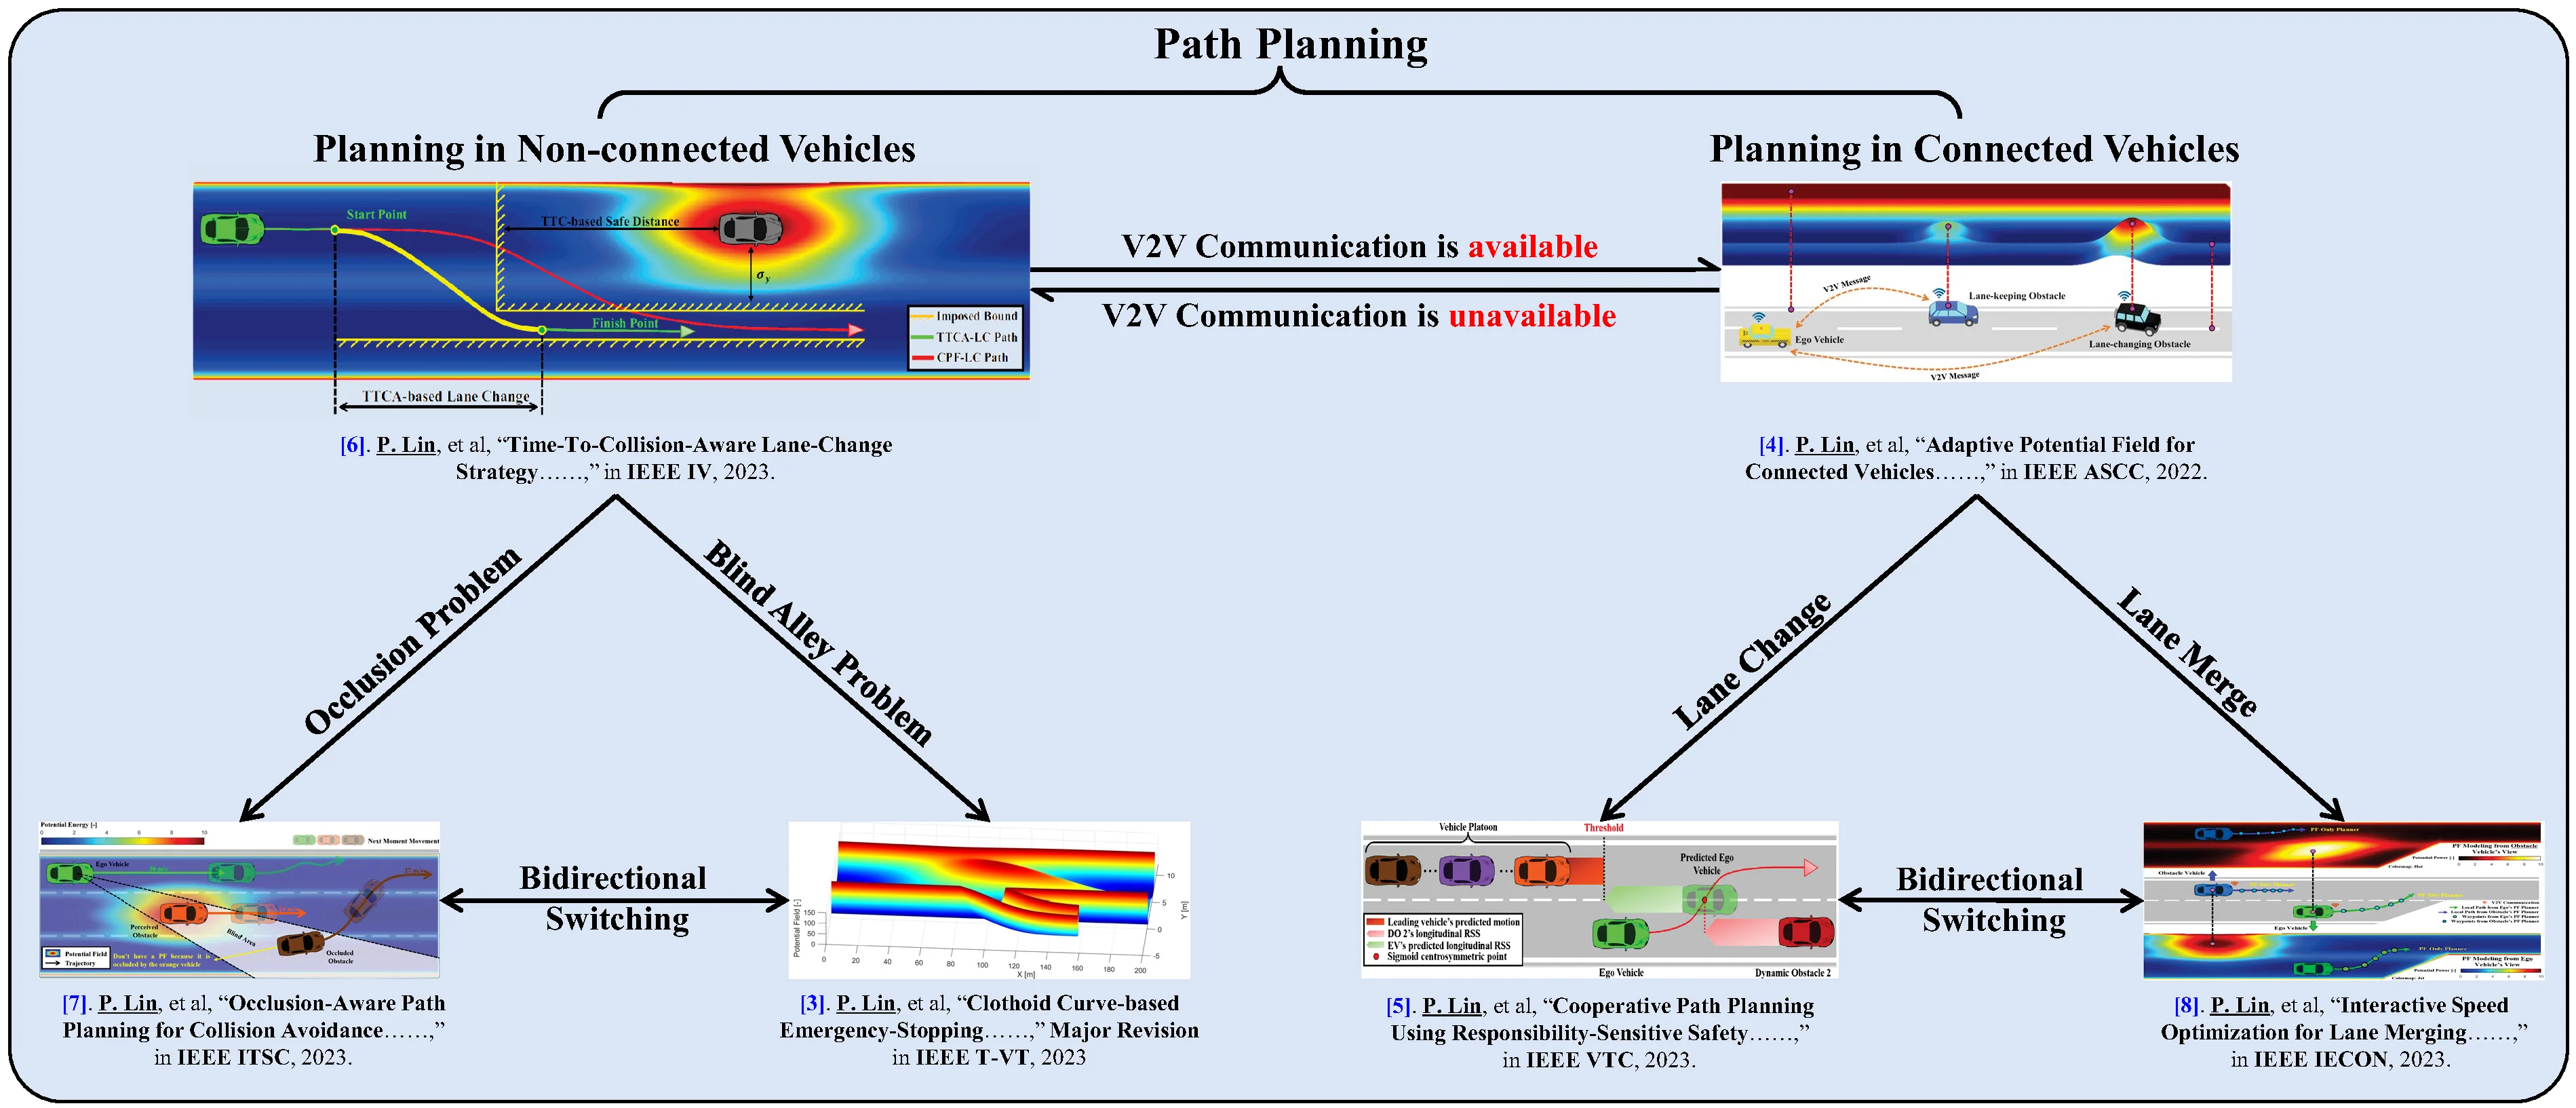
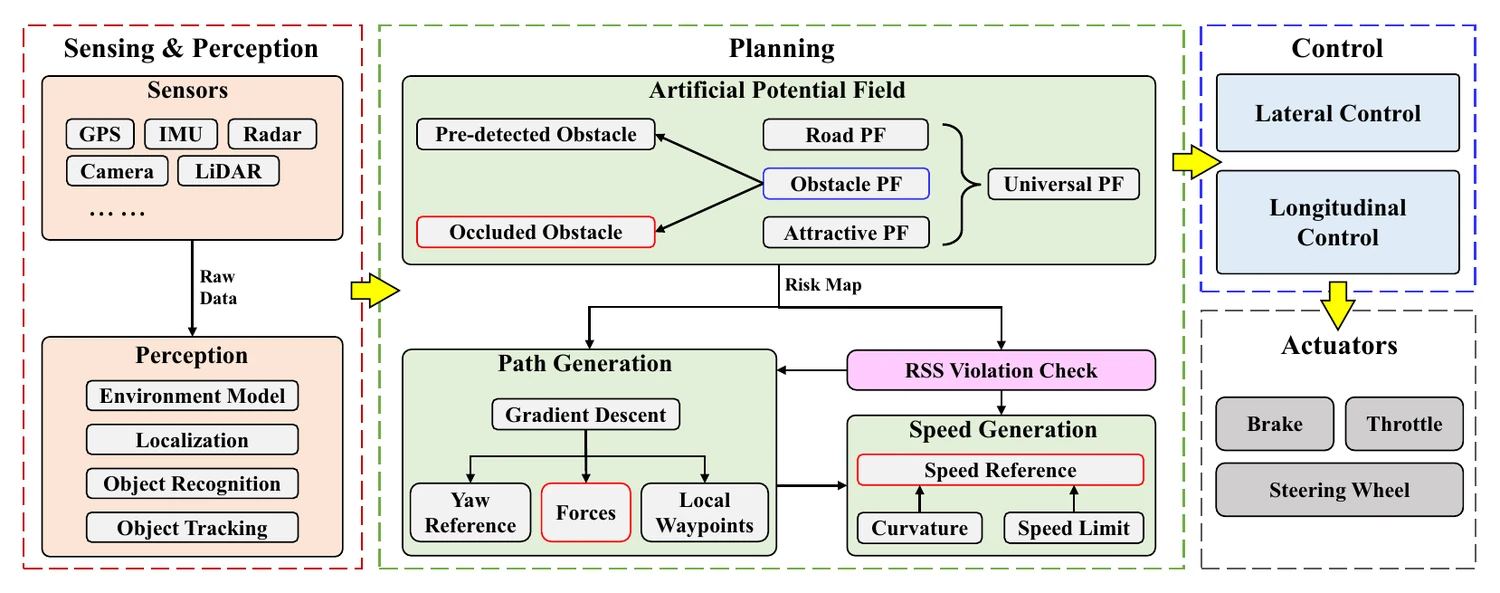
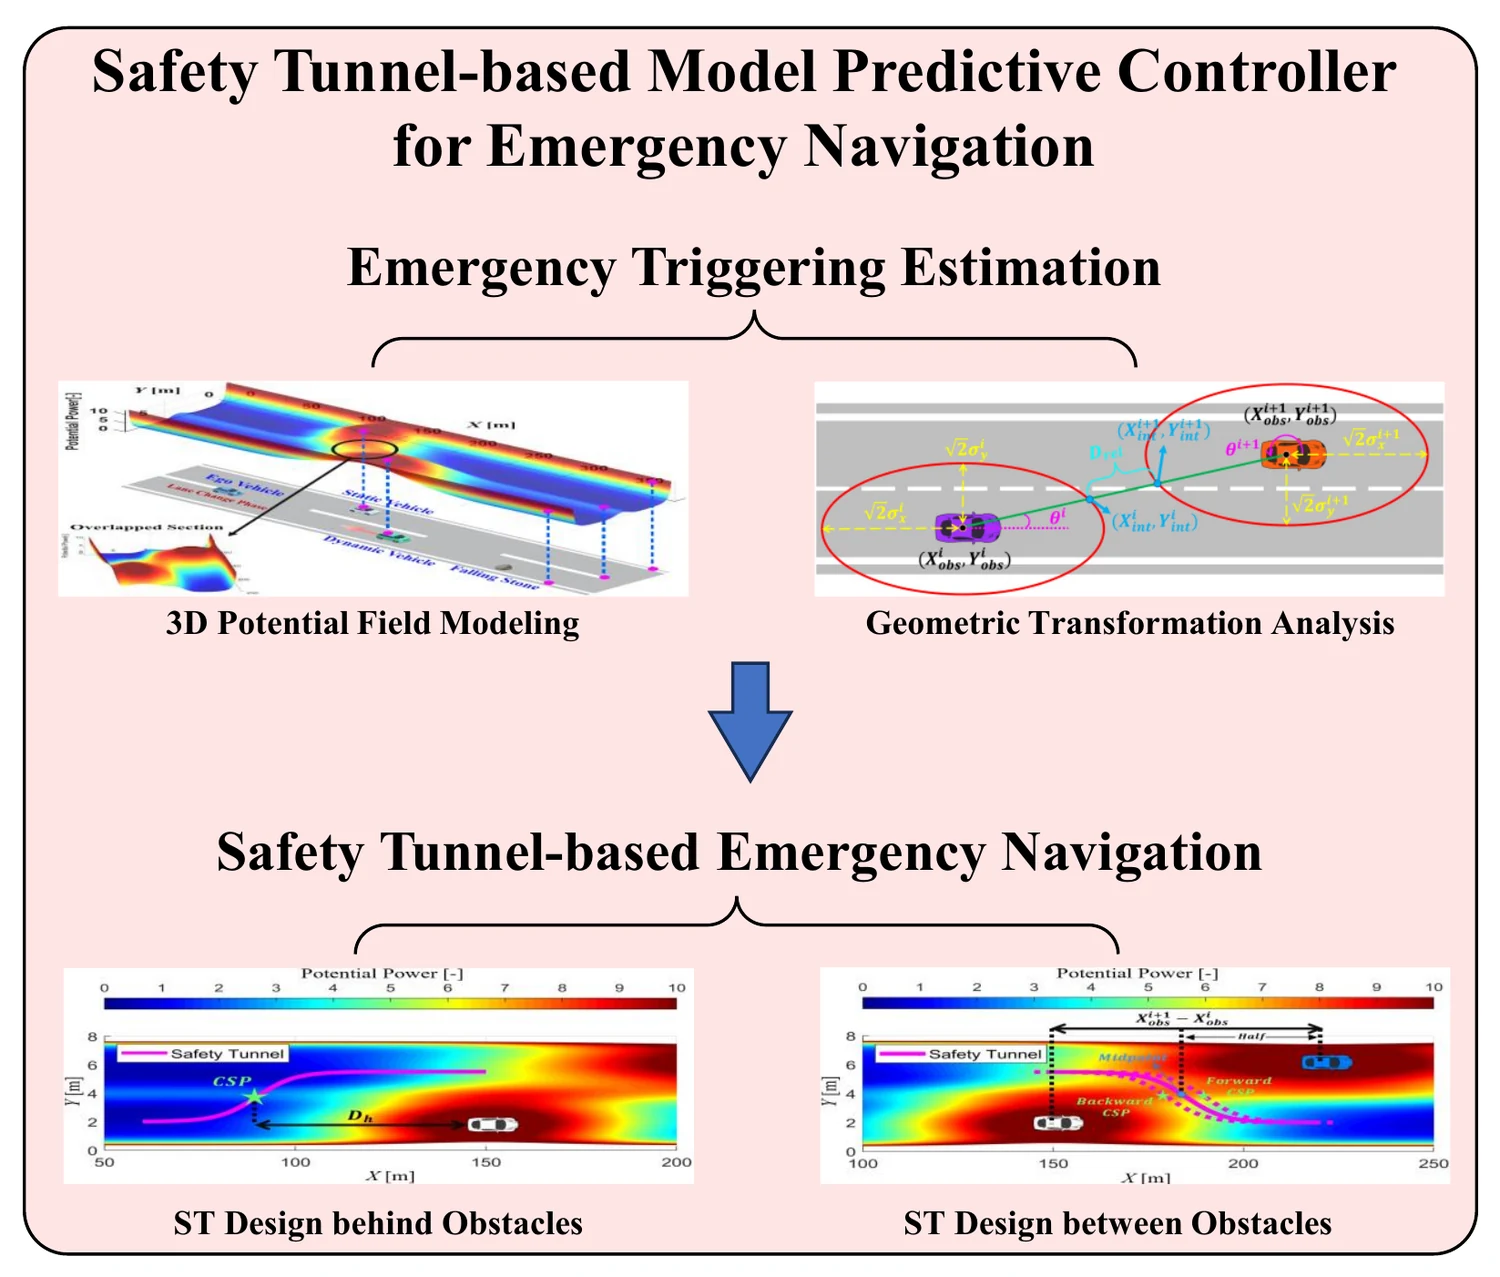
Automotive safety is a paramount concern in the ever-evolving world of transportation. With millions of vehicles on the road, ensuring the well-being of drivers, passengers, and pedestrians is a critical priority. Specifically, traffic injuries remain a significant and ongoing threat to human properties, result- ing in a substantial number of casualties every year. Therefore, autonomous vehicles, also known as self-driving cars, are revolutionizing transportation by offering the potential to enhance road safety, reduce congestion, and increase mobility, while reshaping the future of urban and personal mobility. An autonomous vehicle is equipped with advanced sensors and algorithms to navigate and operate without human intervention. However, despite years of research and development, autonomous vehicles continue to face safety challenges, with a series of traffic accidents still occurring during road tests. Three main challenges are summarized behind those tragedies: sensor failure that false detection or malfunctions lead to incorrect perception; software glitches that incorrect decision or planning paralysis leads to a fatal trajectory; communication Issues that fail to communicate with other road users. Planning paralysis refers to a situation where the autonomous vehicle struggles to make decisions or take action due to complex, ambiguous, or unforeseen scenarios on the road. This can occur when the vehicle’s algorithms and sensors are overwhelmed by a multitude of factors, such as traffic emergencies, adverse weather conditions, or unfamiliar environments. Address- ing planning paralysis is a significant challenge, as it requires sophisticated decision-making capabilities and robust planning algorithms to ensure safe and efficient navigation in real-world conditions. In this thesis, I present emergency-aware path planning for autonomous vehicles by incorporating optimization-based planning with two categories: non-connected and connected vehicles. The proposed planning module can stably generate a collision-free path under different traffic emergencies and can adapt to the collaboration intention of surrounding vehicles. This thesis work is composed of three steps that address the planning malfunctions in facing emergencies: (i) construct the risk map from the current traffic by potential field (PF); (ii) plan a collision-free path based on the collaboration intention of surrounding vehicles; (iii) monitor the PF and prepare for emer- gency navigation in the control layer based on the model predictive control (MPC). Besides, a significant problem for PF-based path planning is that there are four inherent limitations to stop the planner from generating a safe path. In specific traffic scenarios, those limitations can be triggered, leading to plan- ning paralysis. Therefore, monitoring and foreseeing the possible appearance of those limitations is necessary for ensuring driving safety. At the same time, if the planning paralysis becomes irreversible, it is imperative to implant an emergency navigation function in the control module. The experiments also show that our proposed path planning performs better in collision avoidance (stable path generation, curvature, safety, etc.) than previous methods.
How to cite
P. Lin, “Emergency-Aware Path Planning for Non-connected and Connected Autonomous Vehicles,” in Ph.D. Thesis, The University of Tokyo, 2024.
BibTeX
@phdthesis{Lin2024,
  title         = {Emergency-Aware Path Planning for Non-connected and Connected Autonomous Vehicles},
  author        = {Pengfei Lin},
  year          = {2024},
  date          = {2024-03-31},
  urldate       = {2024-03-30},
  school        = {Ph.D. Thesis, The University of Tokyo},
  abstract      = {Automotive safety is a paramount concern in the ever-evolving world of transportation. With millions of vehicles on the road, ensuring the well-being of drivers, passengers, and pedestrians is a critical priority. Specifically, traffic injuries remain a significant and ongoing threat to human properties, result- ing in a substantial number of casualties every year. Therefore, autonomous vehicles, also known as self-driving cars, are revolutionizing transportation by offering the potential to enhance road safety, reduce congestion, and increase mobility, while reshaping the future of urban and personal mobility. An autonomous vehicle is equipped with advanced sensors and algorithms to navigate and operate without human intervention. However, despite years of research and development, autonomous vehicles continue to face safety challenges, with a series of traffic accidents still occurring during road tests. Three main challenges are summarized behind those tragedies: sensor failure that false detection or malfunctions lead to incorrect perception; software glitches that incorrect decision or planning paralysis leads to a fatal trajectory; communication Issues that fail to communicate with other road users. Planning paralysis refers to a situation where the autonomous vehicle struggles to make decisions or take action due to complex, ambiguous, or unforeseen scenarios on the road. This can occur when the vehicle’s algorithms and sensors are overwhelmed by a multitude of factors, such as traffic emergencies, adverse weather conditions, or unfamiliar environments. Address- ing planning paralysis is a significant challenge, as it requires sophisticated decision-making capabilities and robust planning algorithms to ensure safe and efficient navigation in real-world conditions. In this thesis, I present emergency-aware path planning for autonomous vehicles by incorporating optimization-based planning with two categories: non-connected and connected vehicles. The proposed planning module can stably generate a collision-free path under different traffic emergencies and can adapt to the collaboration intention of surrounding vehicles. This thesis work is composed of three steps that address the planning malfunctions in facing emergencies: (i) construct the risk map from the current traffic by potential field (PF); (ii) plan a collision-free path based on the collaboration intention of surrounding vehicles; (iii) monitor the PF and prepare for emer- gency navigation in the control layer based on the model predictive control (MPC). Besides, a significant problem for PF-based path planning is that there are four inherent limitations to stop the planner from generating a safe path. In specific traffic scenarios, those limitations can be triggered, leading to plan- ning paralysis. Therefore, monitoring and foreseeing the possible appearance of those limitations is necessary for ensuring driving safety. At the same time, if the planning paralysis becomes irreversible, it is imperative to implant an emergency navigation function in the control module. The experiments also show that our proposed path planning performs better in collision avoidance (stable path generation, curvature, safety, etc.) than previous methods.},
  keywords      = {ITS, Thesis},
  pubstate      = {published},
  tppubtype     = {phdthesis}
}