
Reliable Cooperative Perception for Connected Roadside Infrastructure
Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki Lab), 2023年3月31日
3行要約
- コネクテッド路側インフラからの協調認識情報を、より確実に届ける方法を研究する。
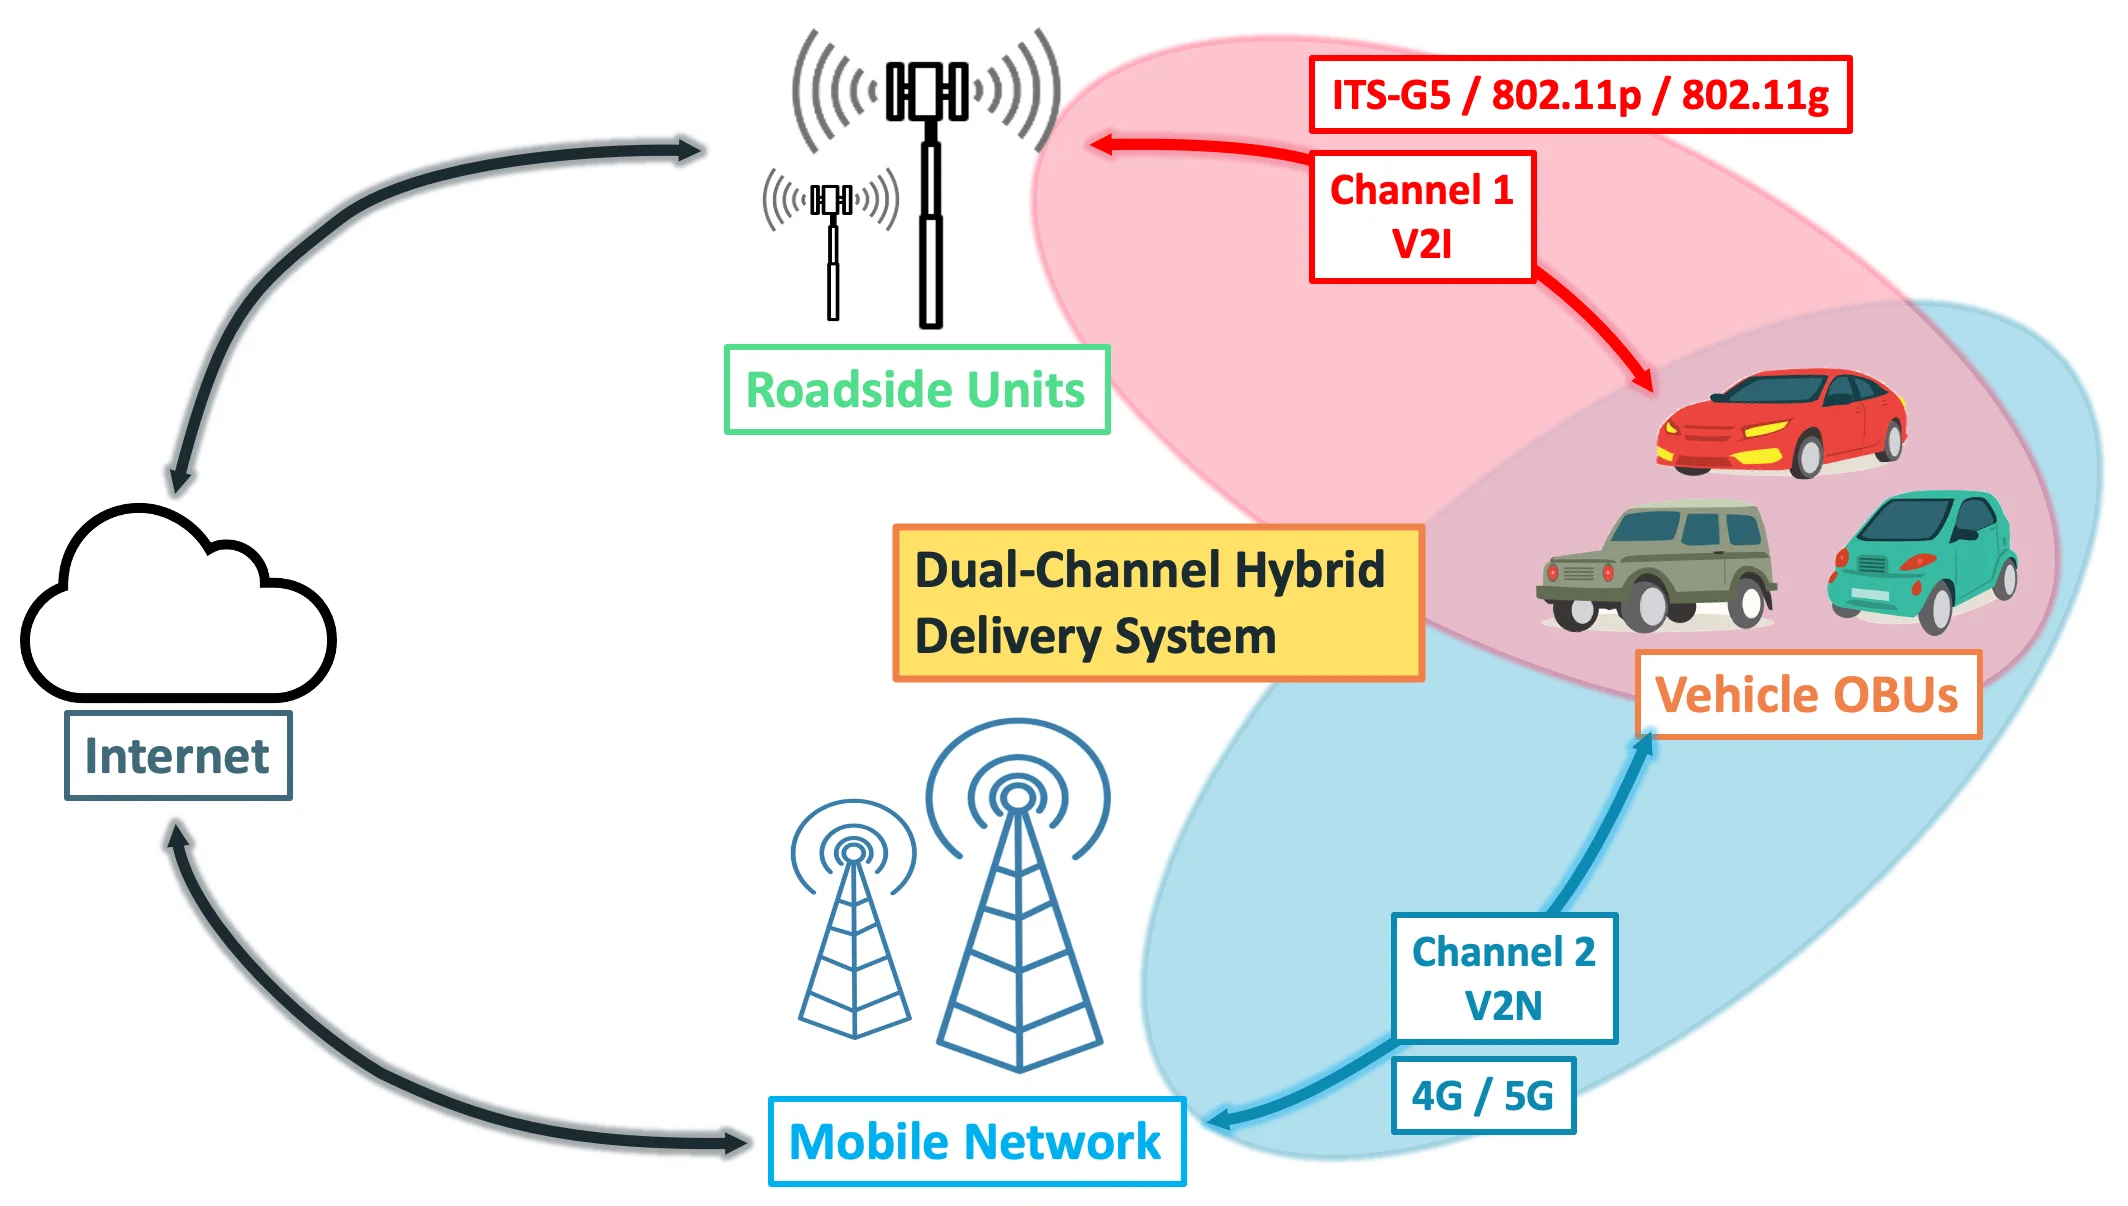
- AutowareV2Xで2経路配信、到達率のリアルタイム監視、状況に応じた配信を実装した。
- 実車試験で約30 msの遅延を測定し、片方の通信経路で損失が多い場合にも安定して受信できることを示した。
論文の図
引用方法
Y. Asabe, “Reliable Cooperative Perception for Connected Roadside Infrastructure,” in Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki Lab), 2023.
BibTeX
@mastersthesis{Asabe2023,
  title         = {Reliable Cooperative Perception for Connected Roadside Infrastructure},
  author        = {Yu Asabe},
  year          = {2023},
  date          = {2023-03-31},
  urldate       = {2023-03-31},
  school        = {Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki Lab)},
  keywords      = {ITS, Thesis},
  pubstate      = {published},
  tppubtype     = {mastersthesis}
}