
Reliable Cooperative Perception for Connected Roadside Infrastructure
Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki Lab), Mar 31, 2023
Summary in three lines
- The thesis studies how connected roadside systems can deliver collective perception more reliably.
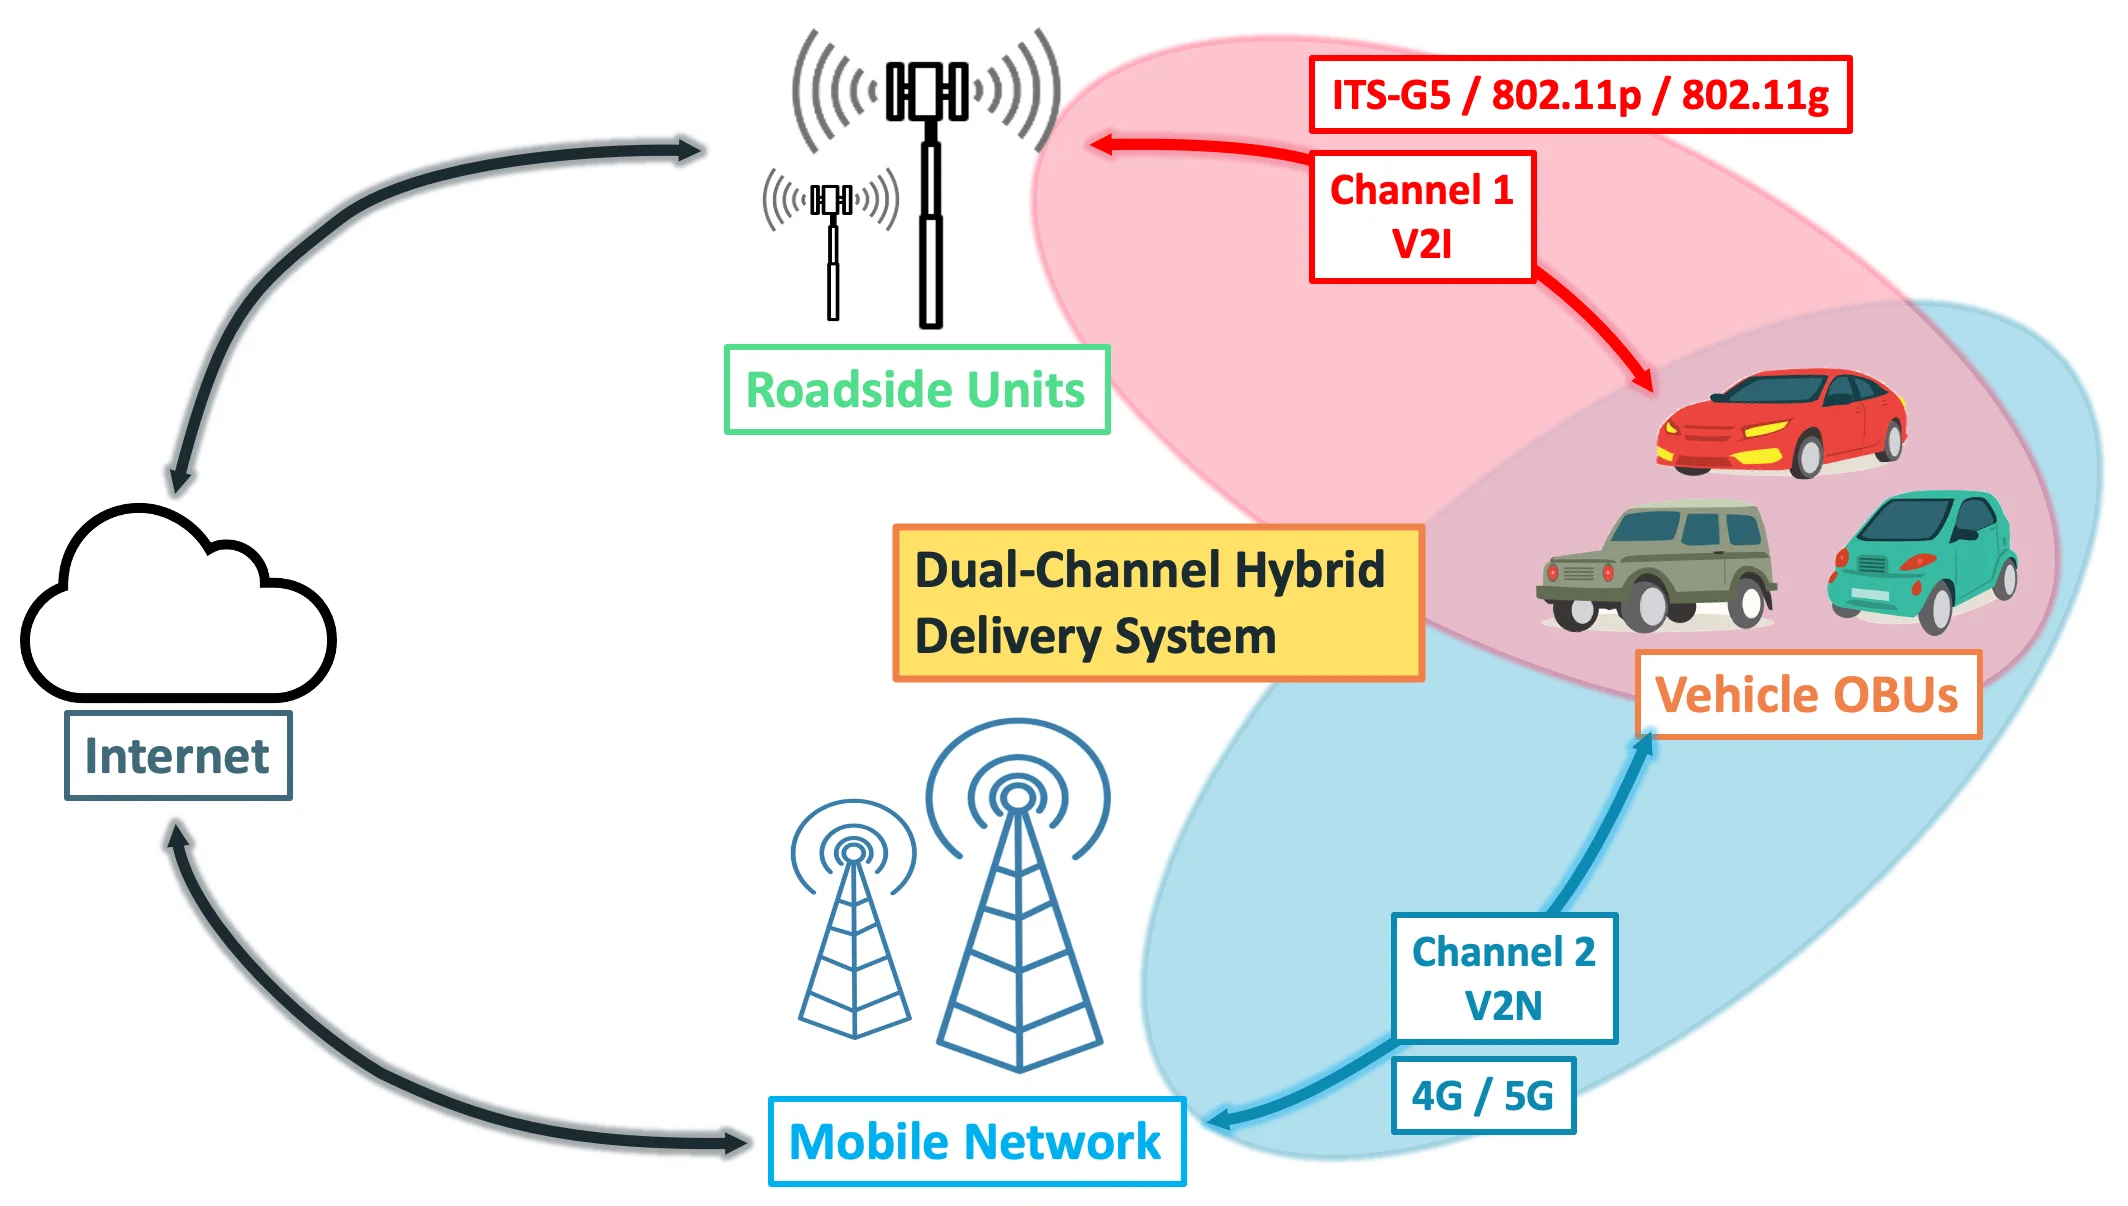
- AutowareV2X implements dual-channel delivery, real-time monitoring of packet delivery, and adaptive delivery.
- Field tests showed about 30 ms latency and reliable reception when one of the channels suffered significant loss.
Figures from the paper
How to cite
Y. Asabe, “Reliable Cooperative Perception for Connected Roadside Infrastructure,” in Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki Lab), 2023.
BibTeX
@mastersthesis{Asabe2023,
  title         = {Reliable Cooperative Perception for Connected Roadside Infrastructure},
  author        = {Yu Asabe},
  year          = {2023},
  date          = {2023-03-31},
  urldate       = {2023-03-31},
  school        = {Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki Lab)},
  keywords      = {ITS, Thesis},
  pubstate      = {published},
  tppubtype     = {mastersthesis}
}