
AutowareV2X: Reliable V2X Communication and Collective Perception for Autonomous Driving
IEEE 97th Vehicular Technology Conference (VTC2023-Spring), Florence, Italy, 2023年6月20日
GitHub(コード)Web サイトDOI: 10.1109/VTC2023-Spring57618.2023.10199425
3行要約
- AutowareV2Xは標準的なV2XメッセージをAutowareの自動運転機能に接続する。
- 協調認識情報を直接通信と携帯電話網で送り、受信側で新鮮なデータを選ぶ。
- 実車試験では端末間の遅延が約30 msで、死角の対象を認識して停止できた。
論文の図
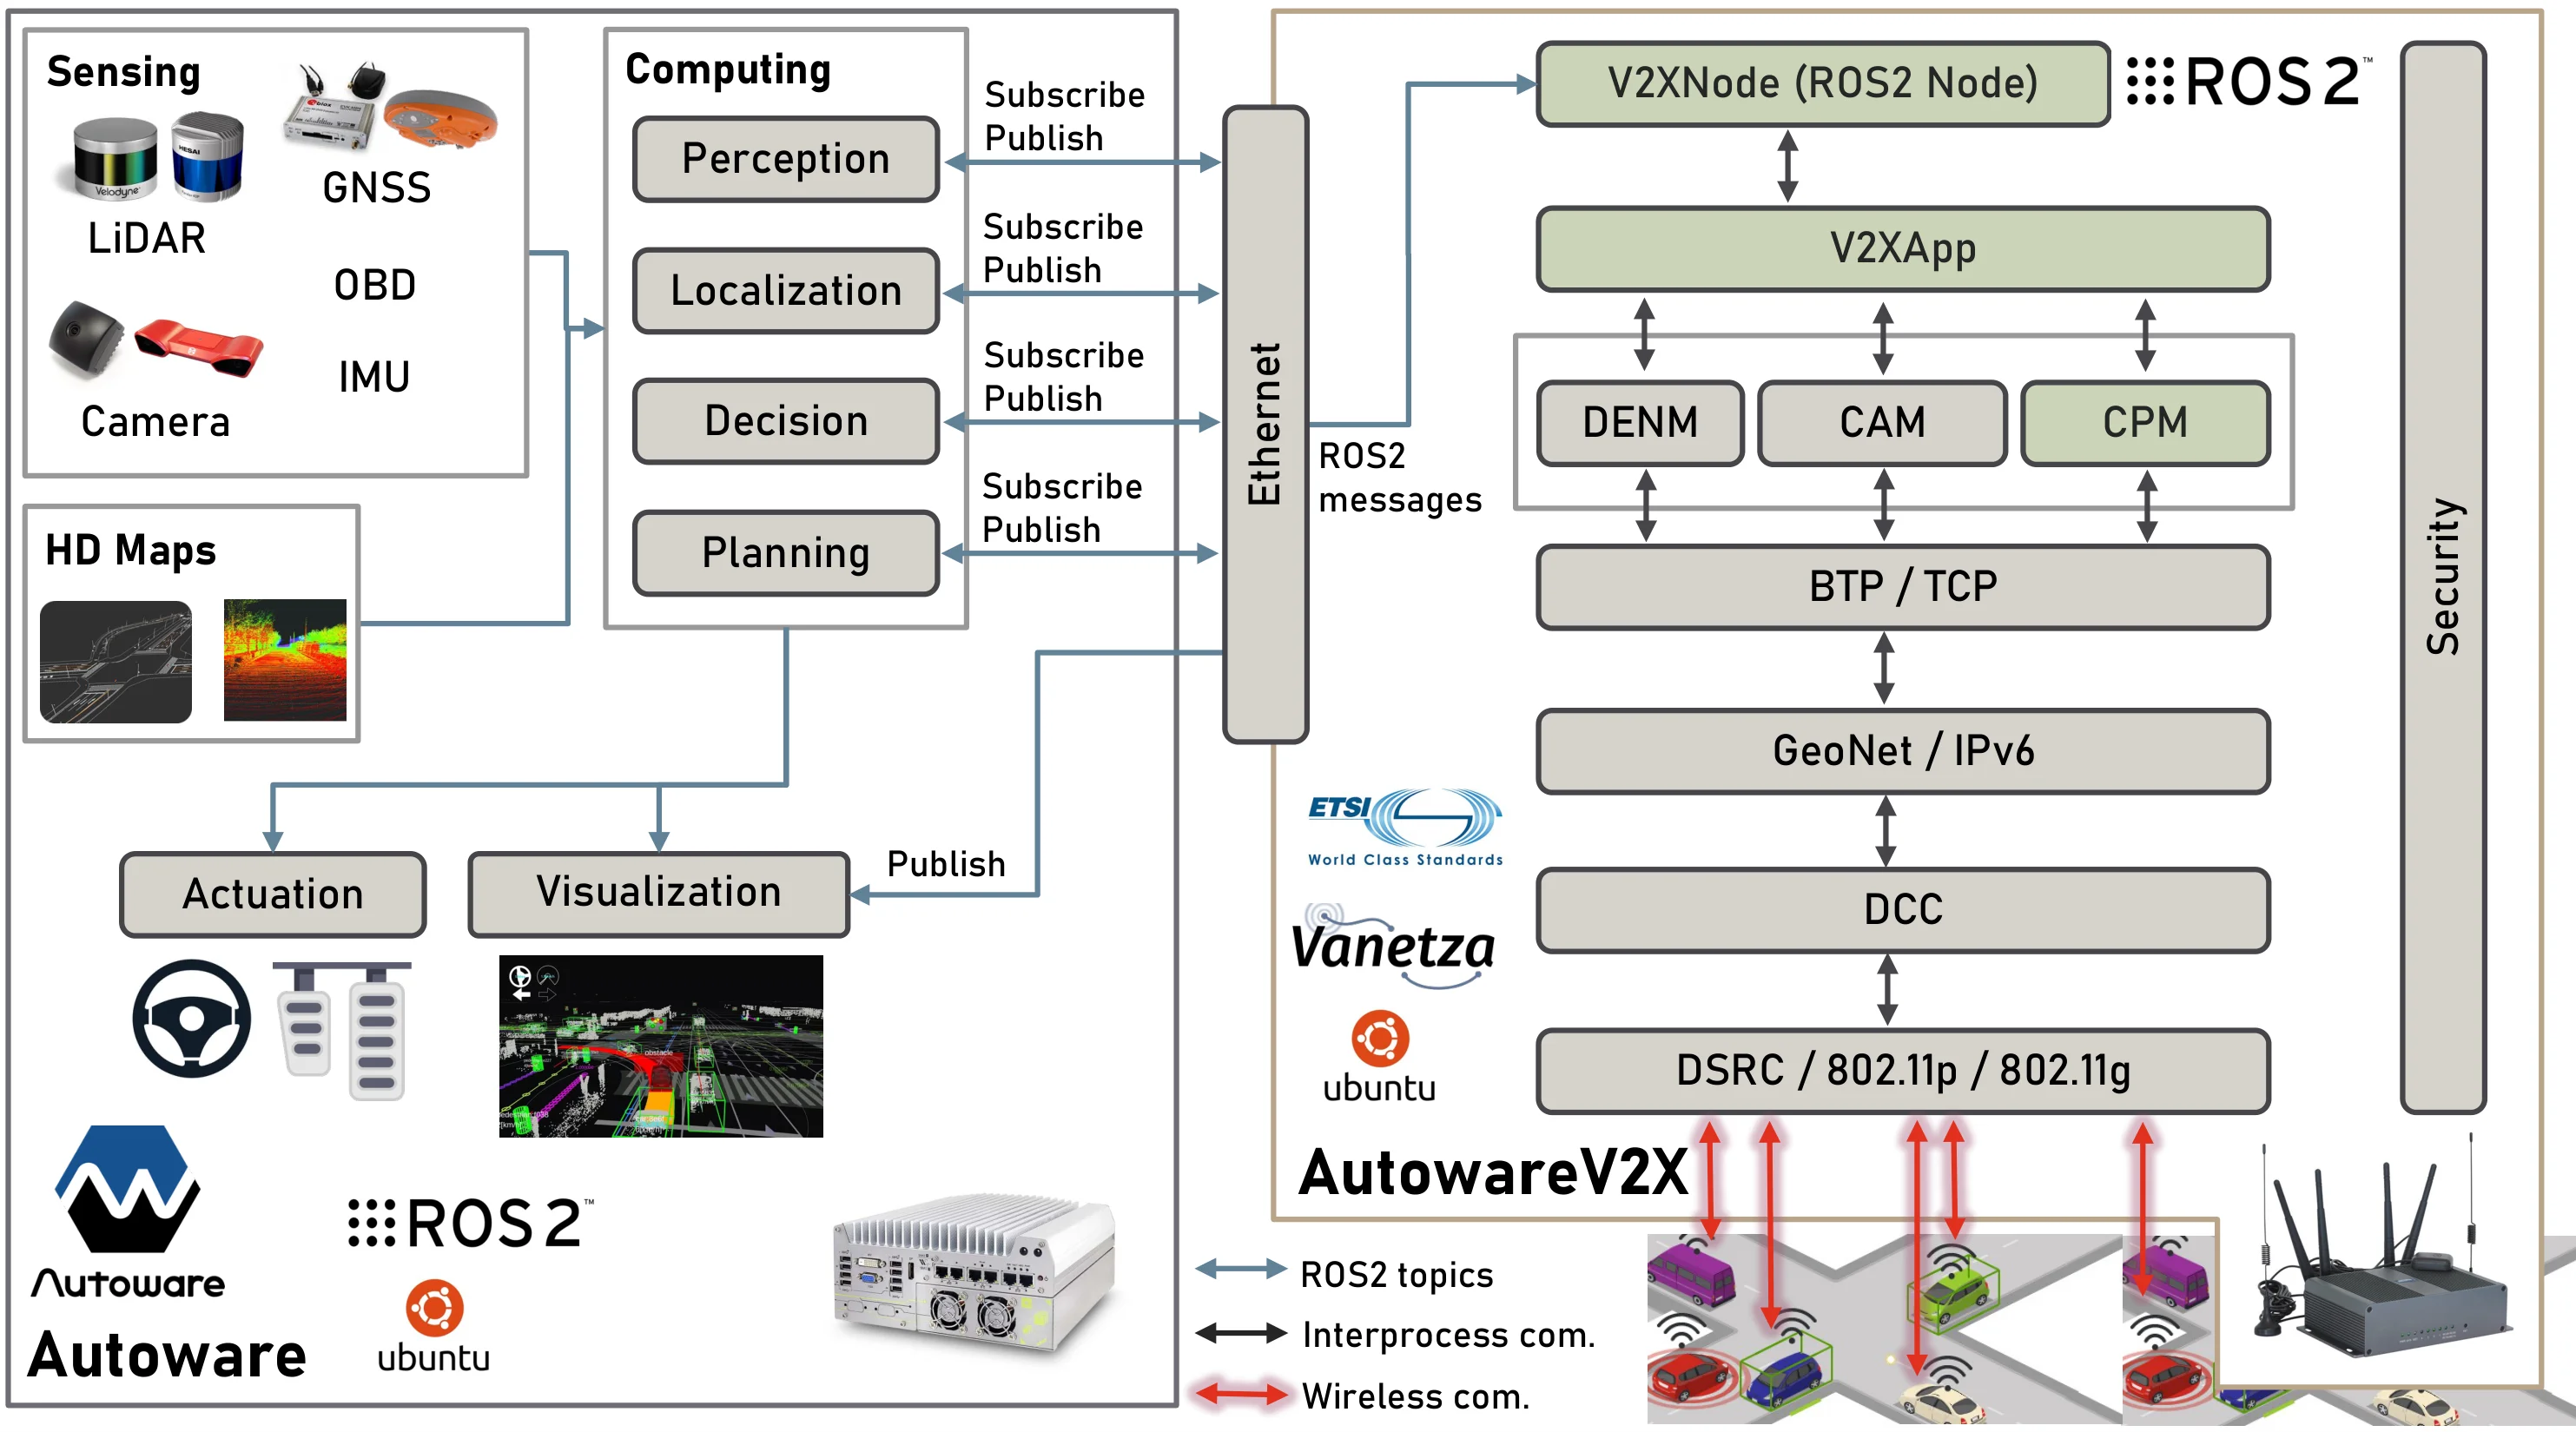
アブストラクト(原文)
For cooperative intelligent transport systems (C-ITS), vehicle-to-everything (V2X) communication is utilized to allow autonomous vehicles to share critical information with each other. We propose AutowareV2X, an implementation of a V2X communication module that is integrated into the autonomous driving (AD) software, Autoware. AutowareV2X provides external connectivity to the entire AD stack, enabling the end-to-end (E2E) experimentation and evaluation of connected autonomous vehicles (CAV). The Collective Perception Service was also implemented, allowing the transmission of Collective Perception Messages (CPMs). A dual-channel mechanism that enables wireless link redundancy on the critical object information shared by CPMs is also proposed. Performance evaluation in field experiments has indicated that the E2E latency of perception information is around 30 ms, and shared object data can be used by the AD software to conduct collision avoidance maneuvers. Dual-channel delivery of CPMs enabled the CAV to dynamically select the best CPM from CPMs received from different links, depending on the freshness of their information.
動画
コード
関連する研究・ソフトウェア
引用方法
Y. Asabe, E. Javanmardi, J. Nakazato, M. Tsukada, and H. Esaki, “AutowareV2X: Reliable V2X Communication and Collective Perception for Autonomous Driving,” in IEEE 97th Vehicular Technology Conference (VTC2023-Spring), Florence, Italy, 2023, doi: 10.1109/VTC2023-Spring57618.2023.10199425.
BibTeX
@inproceedings{Asabe2023b,
  title         = {AutowareV2X: Reliable V2X Communication and Collective Perception for Autonomous Driving},
  author        = {Yu Asabe and Ehsan Javanmardi and Jin Nakazato and Manabu Tsukada and Hiroshi Esaki},
  url           = {https://github.com/tlab-wide/AutowareV2X https://tlab-wide.github.io/AutowareV2X/main/ https://www.youtube.com/watch?v=57fx3-gUNxU},
  doi           = {10.1109/VTC2023-Spring57618.2023.10199425},
  year          = {2023},
  date          = {2023-06-20},
  urldate       = {2023-06-20},
  booktitle     = {IEEE 97th Vehicular Technology Conference (VTC2023-Spring)},
  address       = {Florence, Italy},
  abstract      = {For cooperative intelligent transport systems (C-ITS), vehicle-to-everything (V2X) communication is utilized to allow autonomous vehicles to share critical information with each other. We propose AutowareV2X, an implementation of a V2X communication module that is integrated into the autonomous driving (AD) software, Autoware. AutowareV2X provides external connectivity to the entire AD stack, enabling the end-to-end (E2E) experimentation and evaluation of connected autonomous vehicles (CAV). The Collective Perception Service was also implemented, allowing the transmission of Collective Perception Messages (CPMs). A dual-channel mechanism that enables wireless link redundancy on the critical object information shared by CPMs is also proposed. Performance evaluation in field experiments has indicated that the E2E latency of perception information is around 30 ms, and shared object data can be used by the AD software to conduct collision avoidance maneuvers. Dual-channel delivery of CPMs enabled the CAV to dynamically select the best CPM from CPMs received from different links, depending on the freshness of their information.},
  keywords      = {ITS, Software-Data},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}