
AutowareV2X: Reliable V2X Communication and Collective Perception for Autonomous Driving
IEEE 97th Vehicular Technology Conference (VTC2023-Spring), Florence, Italy, Jun 20, 2023
GitHub (code)WebsiteDOI: 10.1109/VTC2023-Spring57618.2023.10199425
Summary in three lines
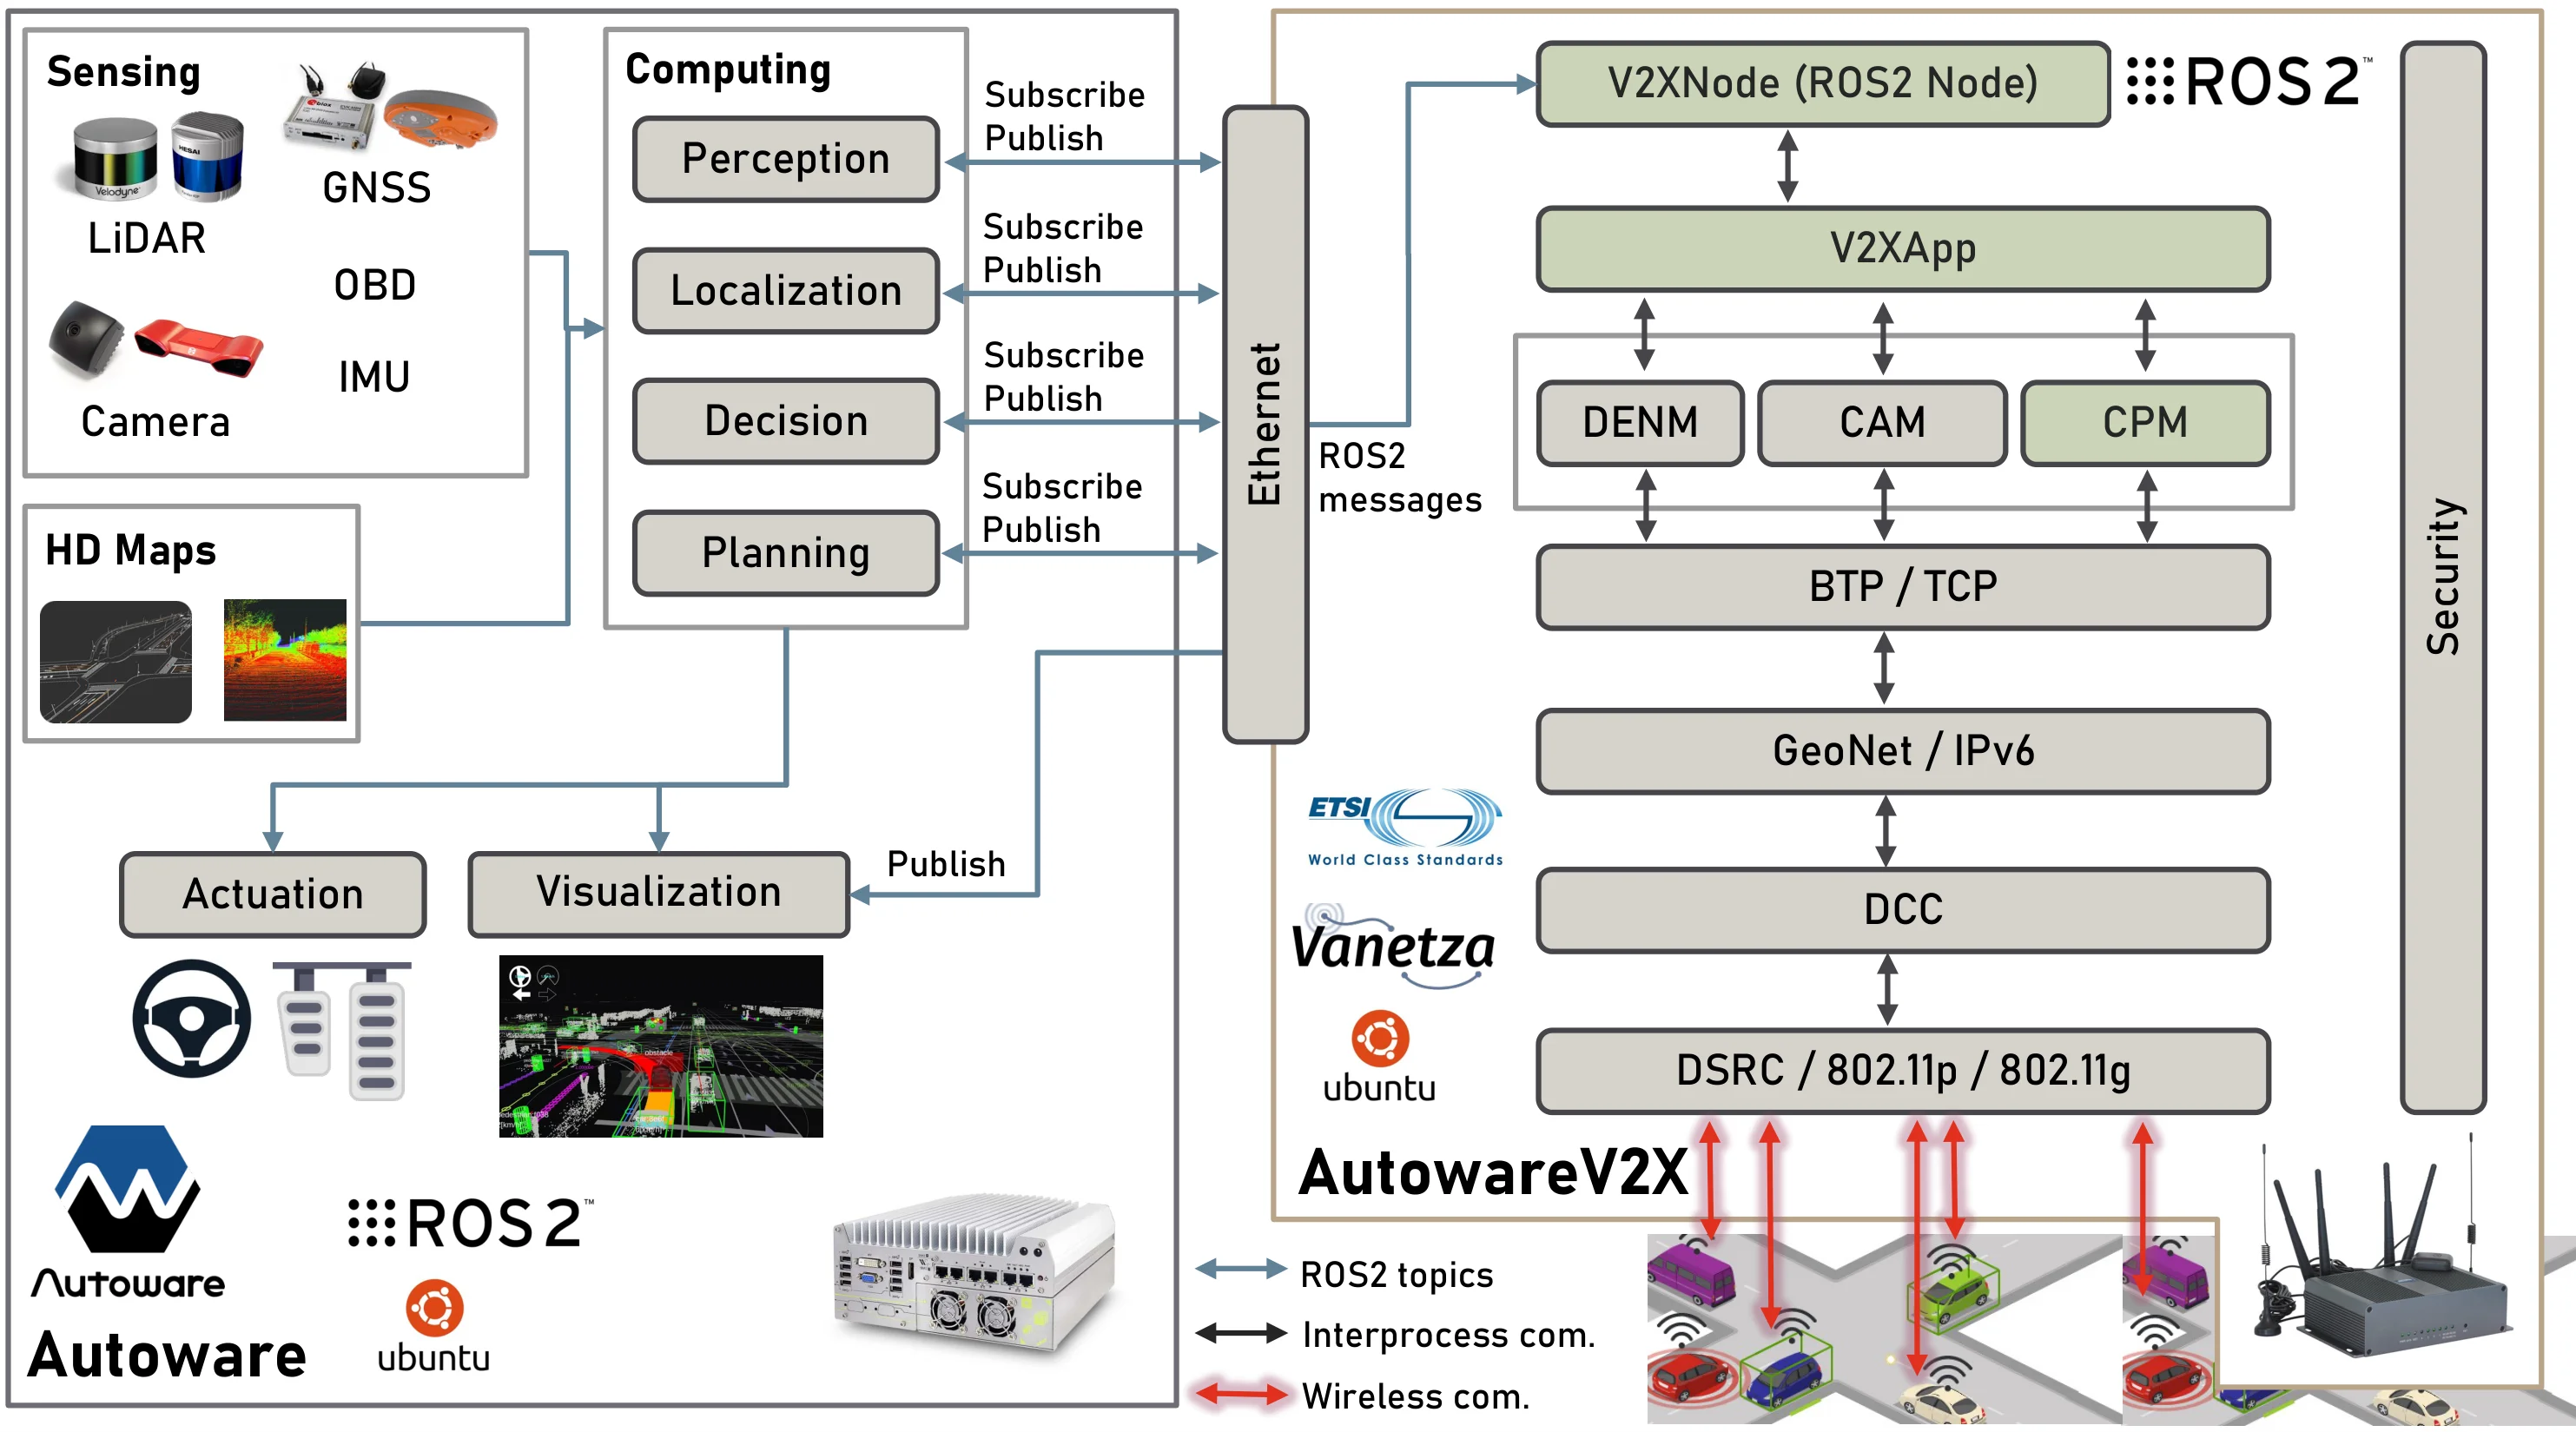
- AutowareV2X integrates standard V2X messages into the Autoware driving stack.
- The system uses both direct and cellular links for collective perception and selects fresh data at the receiver.
- Field tests showed about 30 ms end-to-end latency and braking for hazards in a blind spot.
Figures from the paper
Abstract
For cooperative intelligent transport systems (C-ITS), vehicle-to-everything (V2X) communication is utilized to allow autonomous vehicles to share critical information with each other. We propose AutowareV2X, an implementation of a V2X communication module that is integrated into the autonomous driving (AD) software, Autoware. AutowareV2X provides external connectivity to the entire AD stack, enabling the end-to-end (E2E) experimentation and evaluation of connected autonomous vehicles (CAV). The Collective Perception Service was also implemented, allowing the transmission of Collective Perception Messages (CPMs). A dual-channel mechanism that enables wireless link redundancy on the critical object information shared by CPMs is also proposed. Performance evaluation in field experiments has indicated that the E2E latency of perception information is around 30 ms, and shared object data can be used by the AD software to conduct collision avoidance maneuvers. Dual-channel delivery of CPMs enabled the CAV to dynamically select the best CPM from CPMs received from different links, depending on the freshness of their information.
Video
Code
Related research and software
How to cite
Y. Asabe, E. Javanmardi, J. Nakazato, M. Tsukada, and H. Esaki, “AutowareV2X: Reliable V2X Communication and Collective Perception for Autonomous Driving,” in IEEE 97th Vehicular Technology Conference (VTC2023-Spring), Florence, Italy, 2023, doi: 10.1109/VTC2023-Spring57618.2023.10199425.
BibTeX
@inproceedings{Asabe2023b,
  title         = {AutowareV2X: Reliable V2X Communication and Collective Perception for Autonomous Driving},
  author        = {Yu Asabe and Ehsan Javanmardi and Jin Nakazato and Manabu Tsukada and Hiroshi Esaki},
  url           = {https://github.com/tlab-wide/AutowareV2X https://tlab-wide.github.io/AutowareV2X/main/ https://www.youtube.com/watch?v=57fx3-gUNxU},
  doi           = {10.1109/VTC2023-Spring57618.2023.10199425},
  year          = {2023},
  date          = {2023-06-20},
  urldate       = {2023-06-20},
  booktitle     = {IEEE 97th Vehicular Technology Conference (VTC2023-Spring)},
  address       = {Florence, Italy},
  abstract      = {For cooperative intelligent transport systems (C-ITS), vehicle-to-everything (V2X) communication is utilized to allow autonomous vehicles to share critical information with each other. We propose AutowareV2X, an implementation of a V2X communication module that is integrated into the autonomous driving (AD) software, Autoware. AutowareV2X provides external connectivity to the entire AD stack, enabling the end-to-end (E2E) experimentation and evaluation of connected autonomous vehicles (CAV). The Collective Perception Service was also implemented, allowing the transmission of Collective Perception Messages (CPMs). A dual-channel mechanism that enables wireless link redundancy on the critical object information shared by CPMs is also proposed. Performance evaluation in field experiments has indicated that the E2E latency of perception information is around 30 ms, and shared object data can be used by the AD software to conduct collision avoidance maneuvers. Dual-channel delivery of CPMs enabled the CAV to dynamically select the best CPM from CPMs received from different links, depending on the freshness of their information.},
  keywords      = {ITS, Software-Data},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}