
Roadside Pedestrian Interaction: Reducing Negotiation Burden in Shared Spaces with Autonomous Vehicles
Ph.D. Thesis, The University of Tokyo, 2026年9月30日
3行要約
- 運転者の視線や身振りがなくなると、共有空間を歩く人に通行の調整負担が生じる。
- 横断の手掛かりを伝え、歩行者に追従できる路側スマートポールを提案する。
- VR、多文化比較、実地実験で反応時間、理解、作業負荷を評価した。
論文の図
アブストラクト(原文)
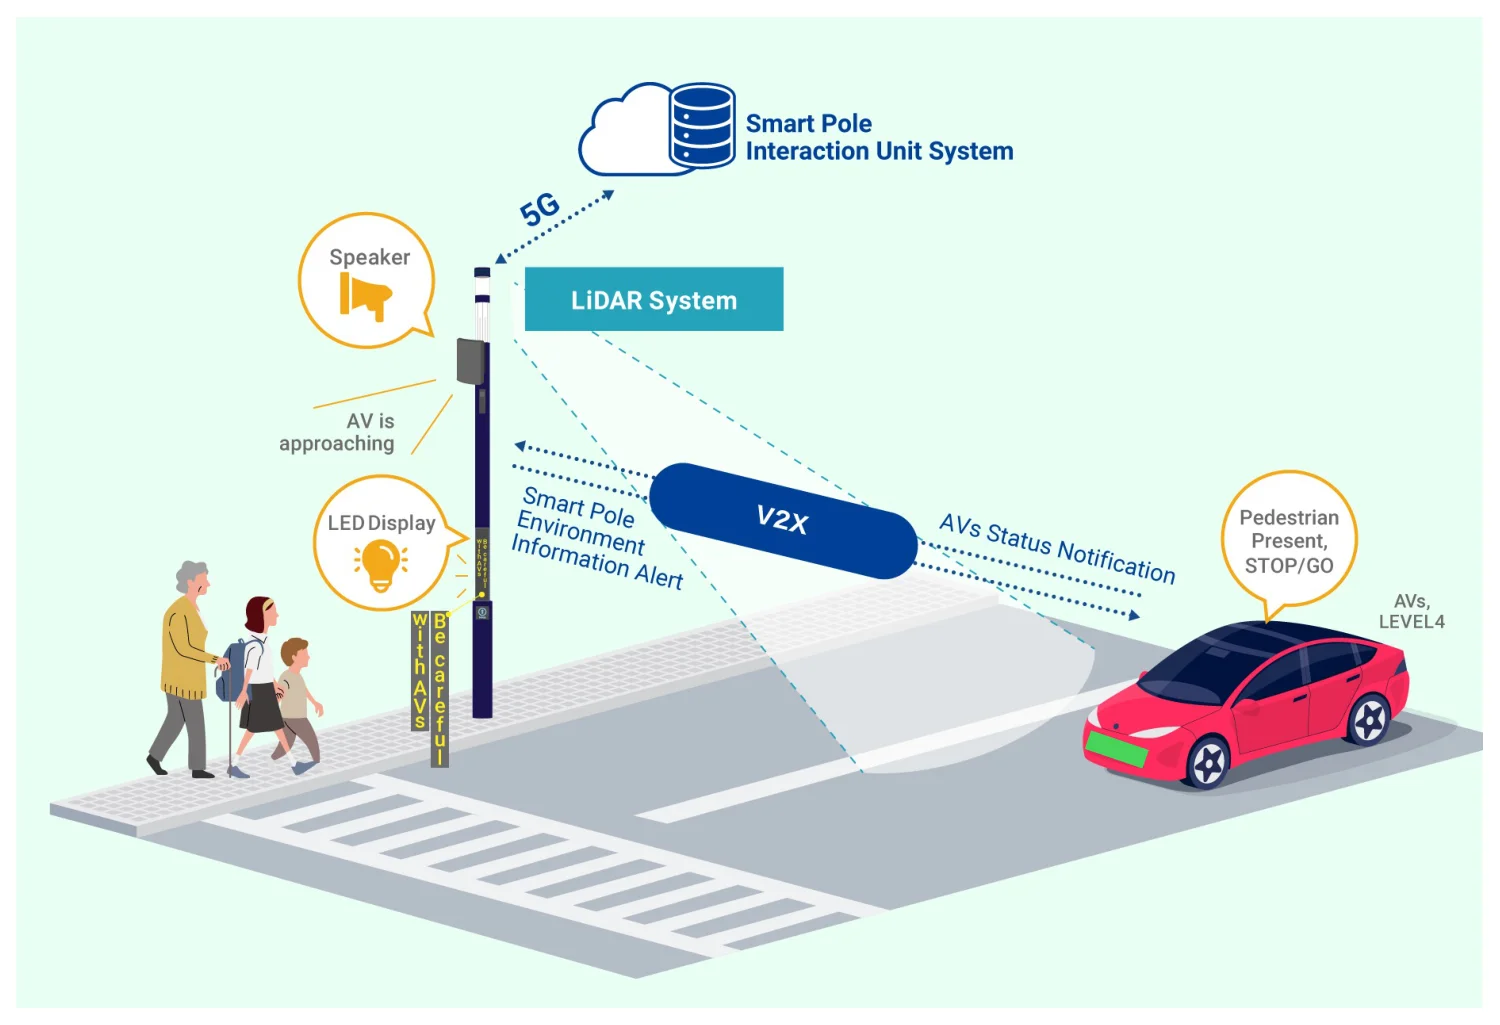
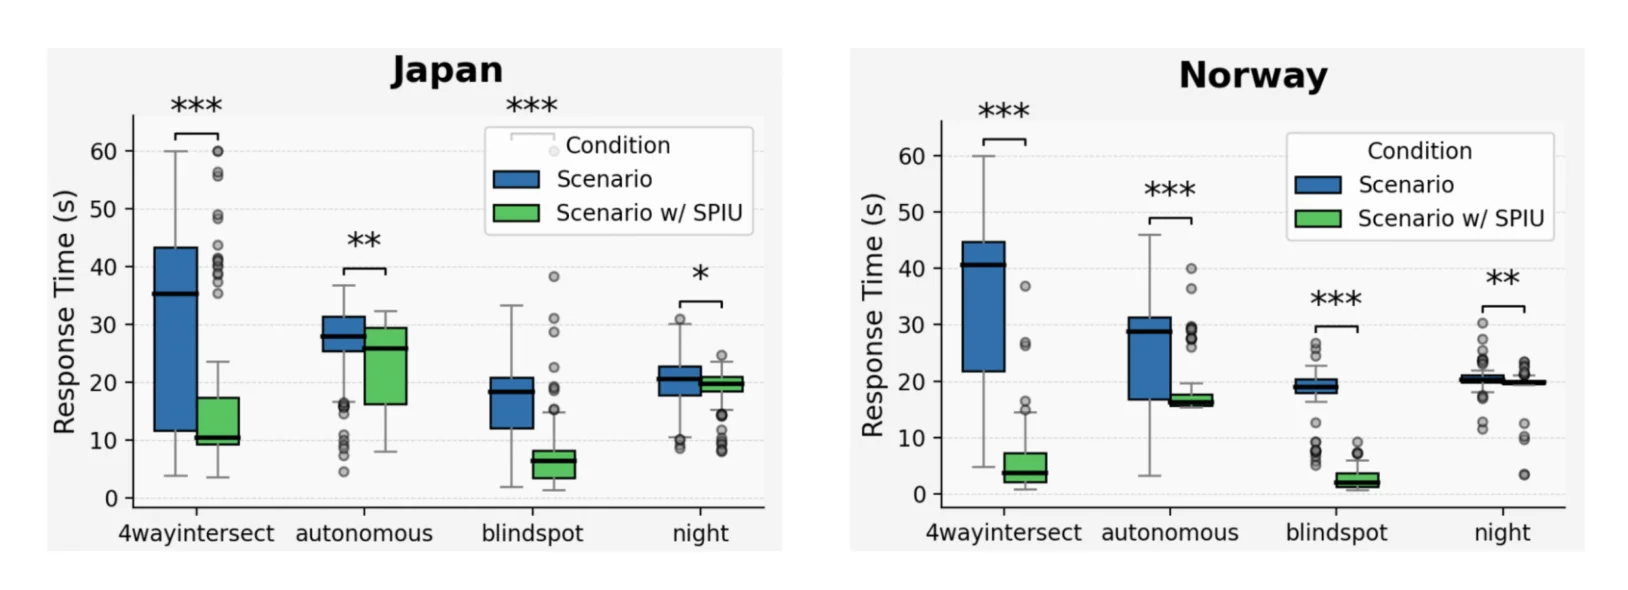
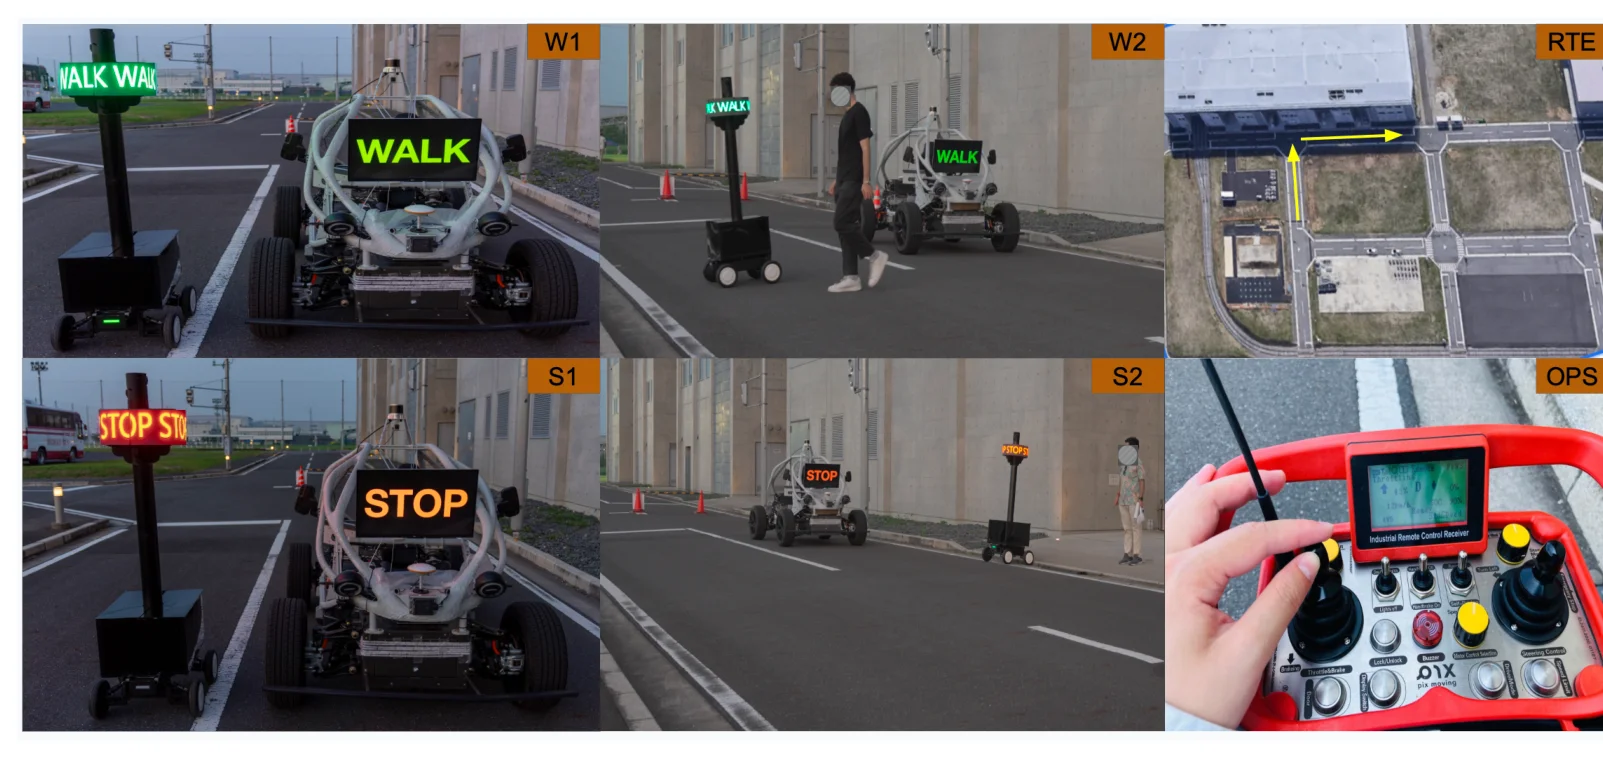
When autonomous vehicles (AVs) enter shared spaces—streets where pedestrians, cyclists, and slow vehicles negotiate informally—pedestrians lose the eye contact, gestures, and yielding cues they relied on with human drivers. Vehicle-mounted external human–machine interfaces (eHMI) only partly close this gap: they fail under occlusion, vary across manufacturers, and lose meaning when several AVs or delivery robots approach at once. Shared spaces amplify each of these failures, because negotiation there is continuous rather than signal-bound. This thesis proposes the Smart Pole Interaction Unit (SPIU): a pedestrian-side, infrastructure-based interface that receives or infers AV intent and presents legible, encounter-specific cues at the pedestrian’s decision point in a shared space. SPIU complements rather than replaces traffic signals and vehicle eHMI, and is most useful under occlusion, blind spots, multi-agent ambiguity, or low visibility—the conditions that make shared-space negotiation hardest. The thesis frames pedestrian–AV interaction as mediated negotiation—a communication problem, not only a vehicle-control one. Four studies develop and test the concept in shared-space scenarios. A VR pilot (Electronics 2023
引用方法
V. Chauhan, “Roadside Pedestrian Interaction: Reducing Negotiation Burden in Shared Spaces with Autonomous Vehicles,” in Ph.D. Thesis, The University of Tokyo, 2026.
BibTeX
@phdthesis{Chauhan2026c,
  title         = {Roadside Pedestrian Interaction: Reducing Negotiation Burden in Shared Spaces with Autonomous Vehicles},
  author        = {Vishal Chauhan},
  year          = {2026},
  date          = {2026-09-30},
  urldate       = {2026-09-30},
  school        = {Ph.D. Thesis, The University of Tokyo},
  abstract      = {When autonomous vehicles (AVs) enter shared spaces—streets where pedestrians, cyclists, and slow vehicles negotiate informally—pedestrians lose the eye contact, gestures, and yielding cues they relied on with human drivers. Vehicle-mounted external human–machine interfaces (eHMI) only partly close this gap: they fail under occlusion, vary across manufacturers, and lose meaning when several AVs or delivery robots approach at once. Shared spaces amplify each of these failures, because negotiation there is continuous rather than signal-bound. This thesis proposes the Smart Pole Interaction Unit (SPIU): a pedestrian-side, infrastructure-based interface that receives or infers AV intent and presents legible, encounter-specific cues at the pedestrian’s decision point in a shared space. SPIU complements rather than replaces traffic signals and vehicle eHMI, and is most useful under occlusion, blind spots, multi-agent ambiguity, or low visibility—the conditions that make shared-space negotiation hardest. The thesis frames pedestrian–AV interaction as mediated negotiation—a communication problem, not only a vehicle-control one. Four studies develop and test the concept in shared-space scenarios. A VR pilot (Electronics 2023},
  keywords      = {Thesis},
  pubstate      = {published},
  tppubtype     = {phdthesis}
}