
Model Predictive Path-Planning Controller with Potential Function for Emergency Collision Avoidance on Highway Driving
IEEE Robotics and Automation Letters (RA-L) with IEEE International Conference on Robotics and Automation (ICRA) option, vol. 7, pp. 4662–4669, 2022年4月22日
3行要約
- 高速道路で急な危険が生じると、従来のポテンシャル場では経路の生成が難しくなることがある。
- シグモイド形状の安全通過経路をモデル予測制御に組み込み、緊急時に切り替える条件を判定する。
- シミュレーションでは、ポテンシャル場のみを使う方式と比べて操舵の振動が抑えられた。
論文の図
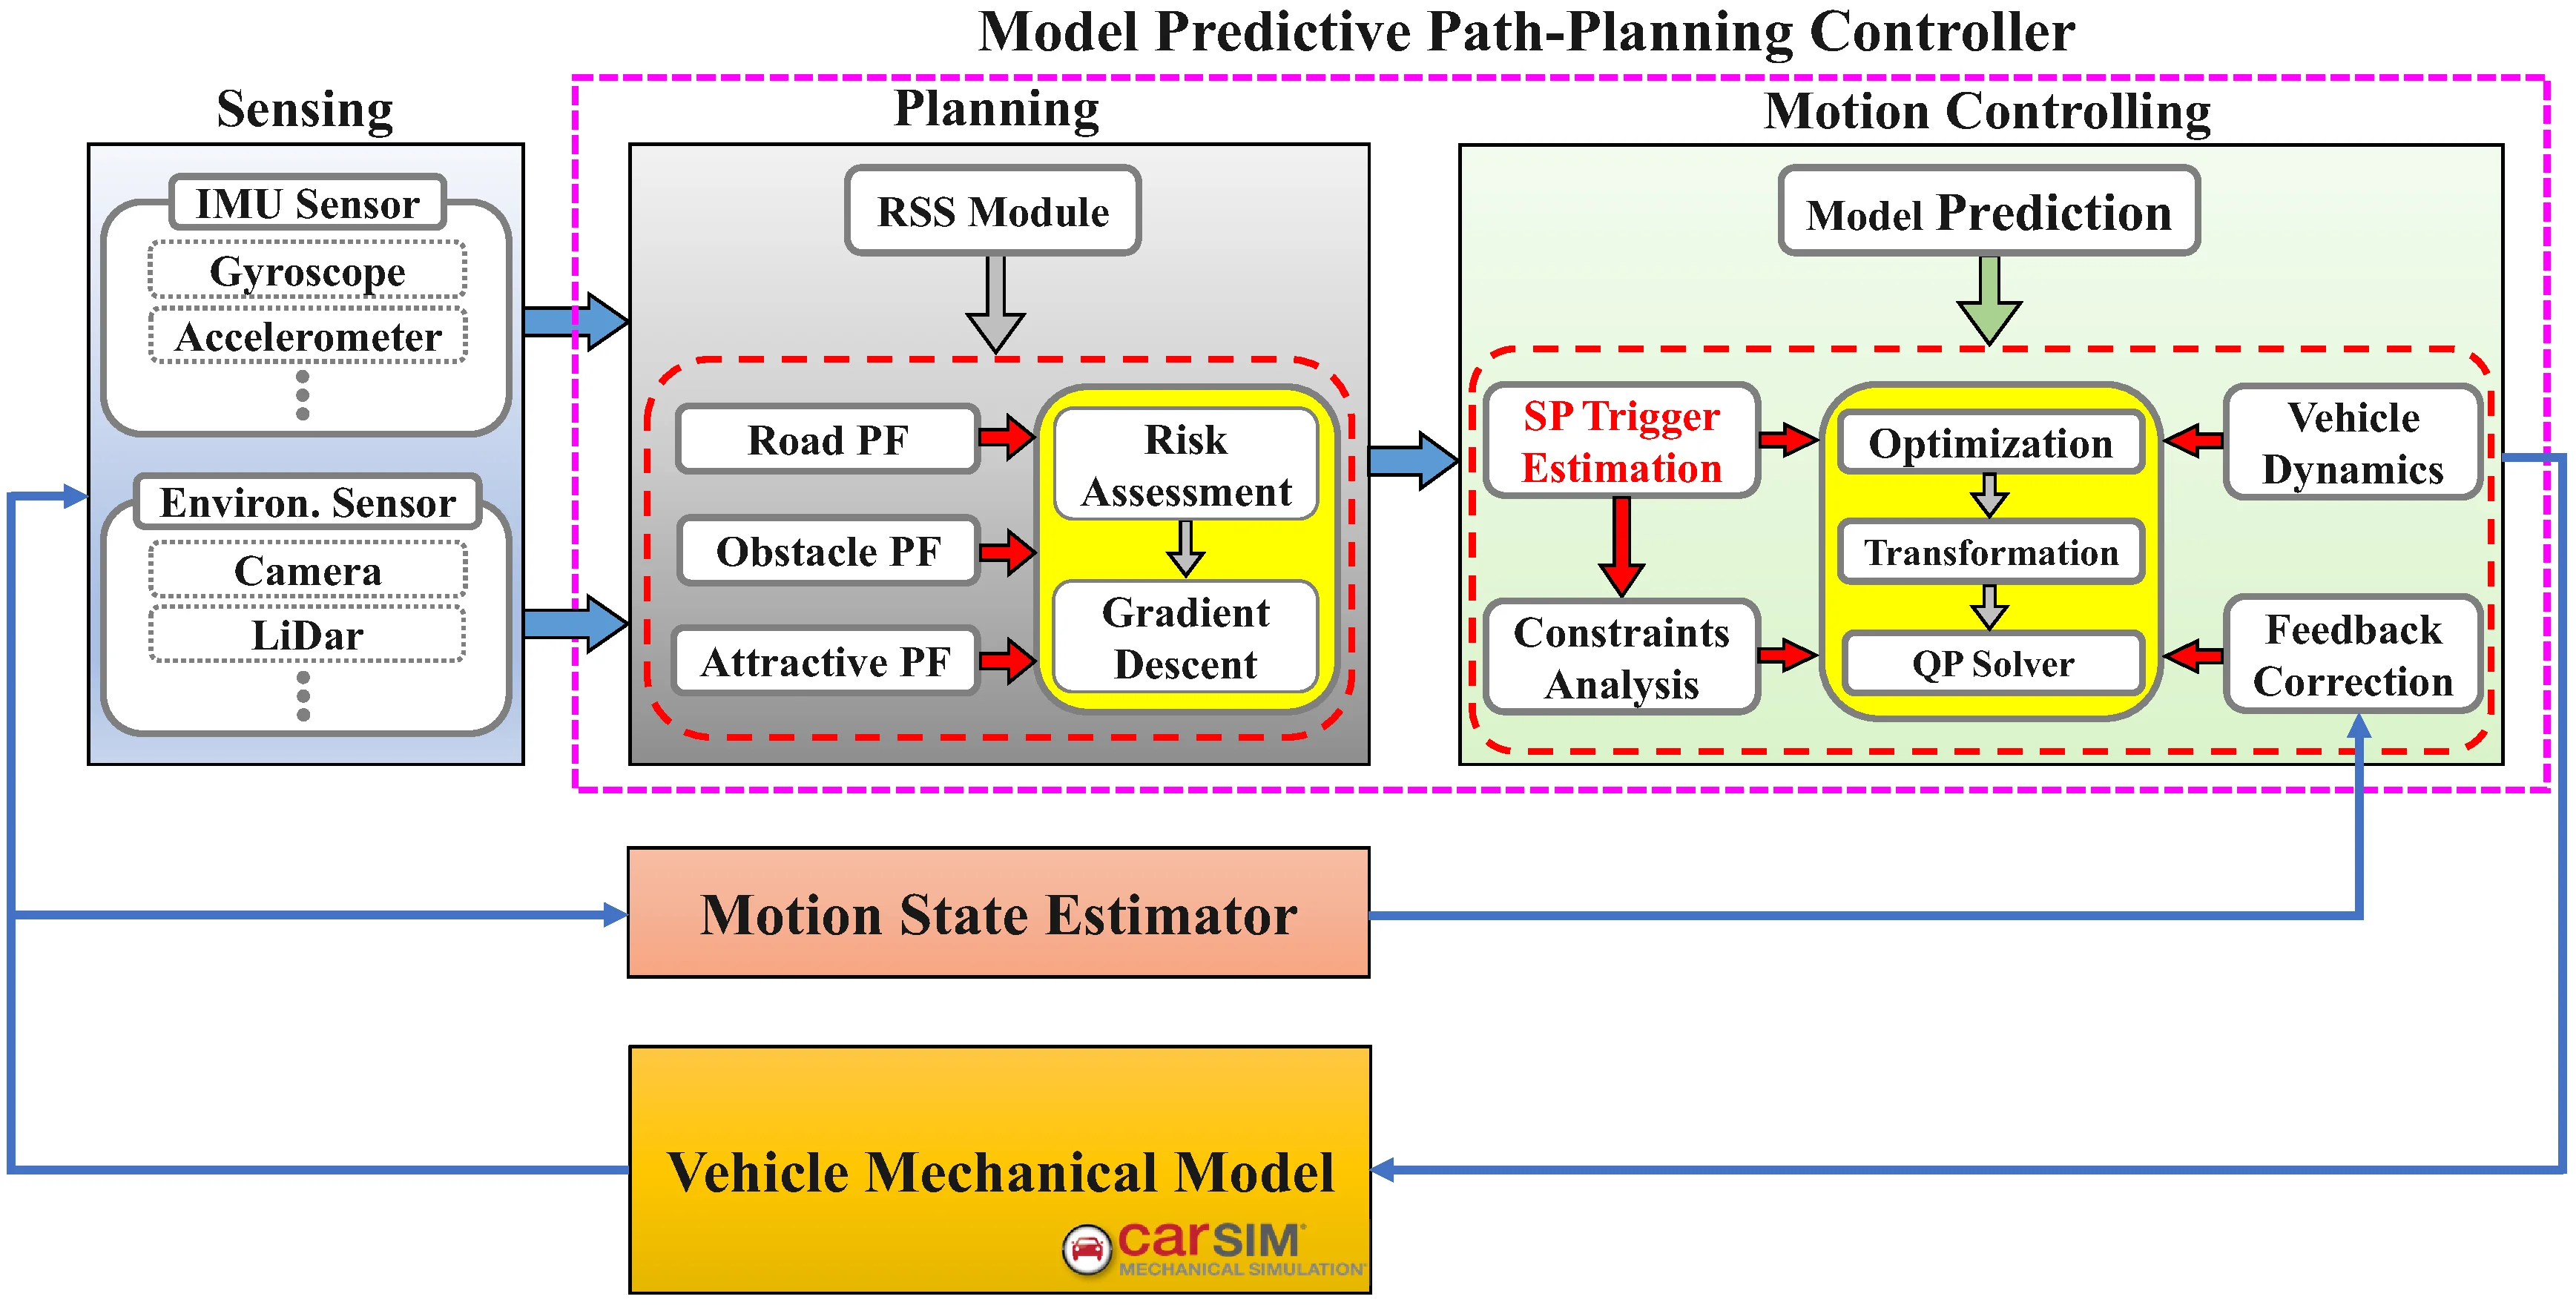
アブストラクト(原文)
Existing potential functions (PFs) utilized in autonomous vehicles mainly focus on solving the path-planning problems in some conventional driving scenarios; thus, their performance may not be satisfactory in the context of emergency obstacle avoidance. Therefore, we propose a novel model predictive path-planning controller (MPPC) combined with PFs to handle complex traffic scenarios (e.g., emergency avoidance when a sudden accident occurs). Specifically, to enhance the safety of the PFs, we developed an MPPC to handle an emergency case with a sigmoid-based safe passage embedded in the MPC constraints (SPMPC) with a specific triggering analysis algorithm on monitoring traffic emergencies. The presented PF-SPMPC algorithm was compiled in a comparative simulation study using MATLAB/Simulink and CarSim. The algorithm outperformed the latest PF-MPC approach to eliminate the severe tire oscillations and guarantee autonomous driving safety when handling the traffic emergency avoidance scenario.
引用方法
P. Lin and M. Tsukada, “Model Predictive Path-Planning Controller with Potential Function for Emergency Collision Avoidance on Highway Driving,” IEEE Robotics and Automation Letters (RA-L) with IEEE International Conference on Robotics and Automation (ICRA) option, vol. 7, pp. 4662–4669, 2022, doi: 10.1109/LRA.2022.3152693.
BibTeX
@article{Lin2022,
  title         = {Model Predictive Path-Planning Controller with Potential Function for Emergency Collision Avoidance on Highway Driving},
  author        = {Pengfei Lin and Manabu Tsukada},
  doi           = {10.1109/LRA.2022.3152693},
  isbn          = {2377-3766},
  year          = {2022},
  date          = {2022-04-22},
  urldate       = {2022-04-22},
  journal       = {IEEE Robotics and Automation Letters (RA-L) with IEEE International Conference on Robotics and Automation (ICRA) option},
  volume        = {7},
  issue         = {2},
  pages         = {4662--4669},
  abstract      = {Existing potential functions (PFs) utilized in autonomous vehicles mainly focus on solving the path-planning problems in some conventional driving scenarios; thus, their performance may not be satisfactory in the context of emergency obstacle avoidance. Therefore, we propose a novel model predictive path-planning controller (MPPC) combined with PFs to handle complex traffic scenarios (e.g., emergency avoidance when a sudden accident occurs). Specifically, to enhance the safety of the PFs, we developed an MPPC to handle an emergency case with a sigmoid-based safe passage embedded in the MPC constraints (SPMPC) with a specific triggering analysis algorithm on monitoring traffic emergencies. The presented PF-SPMPC algorithm was compiled in a comparative simulation study using MATLAB/Simulink and CarSim. The algorithm outperformed the latest PF-MPC approach to eliminate the severe tire oscillations and guarantee autonomous driving safety when handling the traffic emergency avoidance scenario.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {article}
}