
Clothoid Curve-based Emergency Stopping Path-Planning with Adaptive Potential Field for Autonomous Vehicles
IEEE Transactions on Vehicular Technology, vol. 73, pp. 9747–9762, 2024年7月24日
arXivDOI: 10.1109/TVT.2024.3380745
3行要約
- 急な割り込みで道路境界と障害物のポテンシャル場が重なると、局所解に閉じ込められることがある。
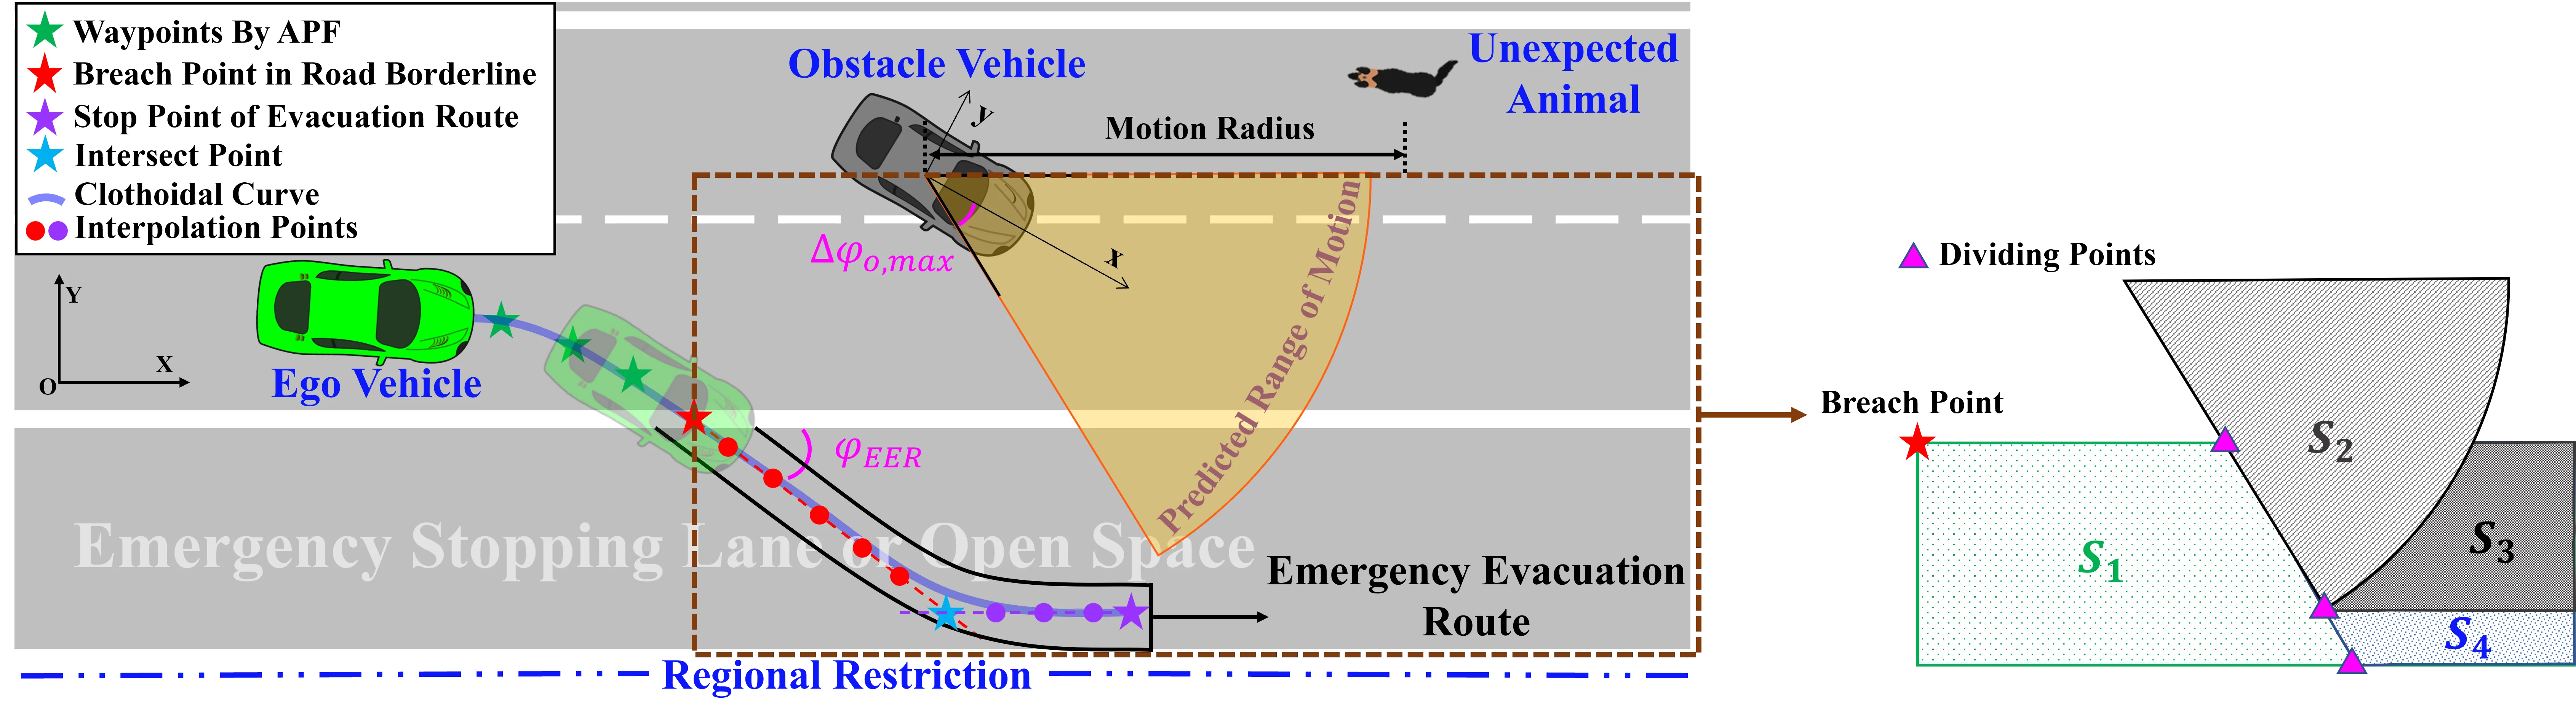
- この状況を検出し、停止点を選んでクロソイド曲線で緊急経路を生成する。
- 比較評価では車輪のスリップ時間が61.9%、最大操舵角振幅が76.9%減った。
論文の図
アブストラクト(原文)
Potential Field-based path planning methods are widely embraced in the context of autonomous vehicles due to their real-time efficiency and simplicity. While the potential field effectively enforces a rigid road boundary to keep the vehicle within the confines of the road, it can lead to the “blind alley” problem caused by local minima in specific high- speed scenarios, resulting in indecision, erratic behavior, or even accidents. Therefore, the objective of this research is to anticipate and address the aforementioned problem in order to proactively avoid potential collisions. We have also found that existing methods do not offer a root cause analysis or practical solutions for this issue, which limits the practicality of the potential field in handling complicated traffic situations. In this paper, we propose an Emergency-Stopping Path Planning (ESPP) approach that incorporates an adaptive potential field with the clothoid curve. First, we design an emergency triggering estimation to detect the ”blind alley” problem. Second, we regionalize the driving scene to search for the optimal breach point on the road PF and the final stopping point for the vehicle by considering the motion range of the obstacle. Finally, we use the optimized clothoid curve to fit these calculated points under vehicle dynamics constraints to generate a smooth emergency avoidance path. The proposed ESPP method was evaluated by conducting the co-simulation between MATLAB/Simulink and CarSim Simulator in a freeway scene. The simulation results reveal that the proposed method shows increased performance in emergency collision avoidance and renders the vehicle safer, in which the duration of wheel slip is 61.9% shorter, and the maximum steering angle amplitude is 76.9% lower than other potential field-based methods.
引用方法
P. Lin, E. Javanmardi, and M. Tsukada, “Clothoid Curve-based Emergency Stopping Path-Planning with Adaptive Potential Field for Autonomous Vehicles,” IEEE Transactions on Vehicular Technology, vol. 73, pp. 9747–9762, 2024, doi: 10.1109/TVT.2024.3380745.
BibTeX
@article{Lin2024b,
  title         = {Clothoid Curve-based Emergency Stopping Path-Planning with Adaptive Potential Field for Autonomous Vehicles},
  author        = {Pengfei Lin and Ehsan Javanmardi and Manabu Tsukada},
  doi           = {10.1109/TVT.2024.3380745},
  issn          = {0018-9545},
  url           = {https://arxiv.org/abs/2308.10049},
  eprint        = {2308.10049},
  archiveprefix = {arXiv},
  primaryclass  = {cs.RO},
  year          = {2024},
  date          = {2024-07-24},
  urldate       = {2024-03-22},
  journal       = {IEEE Transactions on Vehicular Technology},
  volume        = {73},
  issue         = {7},
  pages         = {9747--9762},
  abstract      = {Potential Field-based path planning methods are widely embraced in the context of autonomous vehicles due to their real-time efficiency and simplicity. While the potential field effectively enforces a rigid road boundary to keep the vehicle within the confines of the road, it can lead to the “blind alley” problem caused by local minima in specific high- speed scenarios, resulting in indecision, erratic behavior, or even accidents. Therefore, the objective of this research is to anticipate and address the aforementioned problem in order to proactively avoid potential collisions. We have also found that existing methods do not offer a root cause analysis or practical solutions for this issue, which limits the practicality of the potential field in handling complicated traffic situations. In this paper, we propose an Emergency-Stopping Path Planning (ESPP) approach that incorporates an adaptive potential field with the clothoid curve. First, we design an emergency triggering estimation to detect the ”blind alley” problem. Second, we regionalize the driving scene to search for the optimal breach point on the road PF and the final stopping point for the vehicle by considering the motion range of the obstacle. Finally, we use the optimized clothoid curve to fit these calculated points under vehicle dynamics constraints to generate a smooth emergency avoidance path. The proposed ESPP method was evaluated by conducting the co-simulation between MATLAB/Simulink and CarSim Simulator in a freeway scene. The simulation results reveal that the proposed method shows increased performance in emergency collision avoidance and renders the vehicle safer, in which the duration of wheel slip is 61.9% shorter, and the maximum steering angle amplitude is 76.9% lower than other potential field-based methods.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {article}
}