
A Rule-Compliance Path Planner for Lane-Merge Scenarios Based on Responsibility-Sensitive Safety
18th International Conference on Control, Automation, Robotics and Vision (ICARCV 2024), Dubai, UAE, 2024年12月12日
arXivDOI: 10.1109/ICARCV63323.2024.10821557
3行要約
- 合流時に運転意図や優先権が曖昧だと、車両の軌跡が振動する。
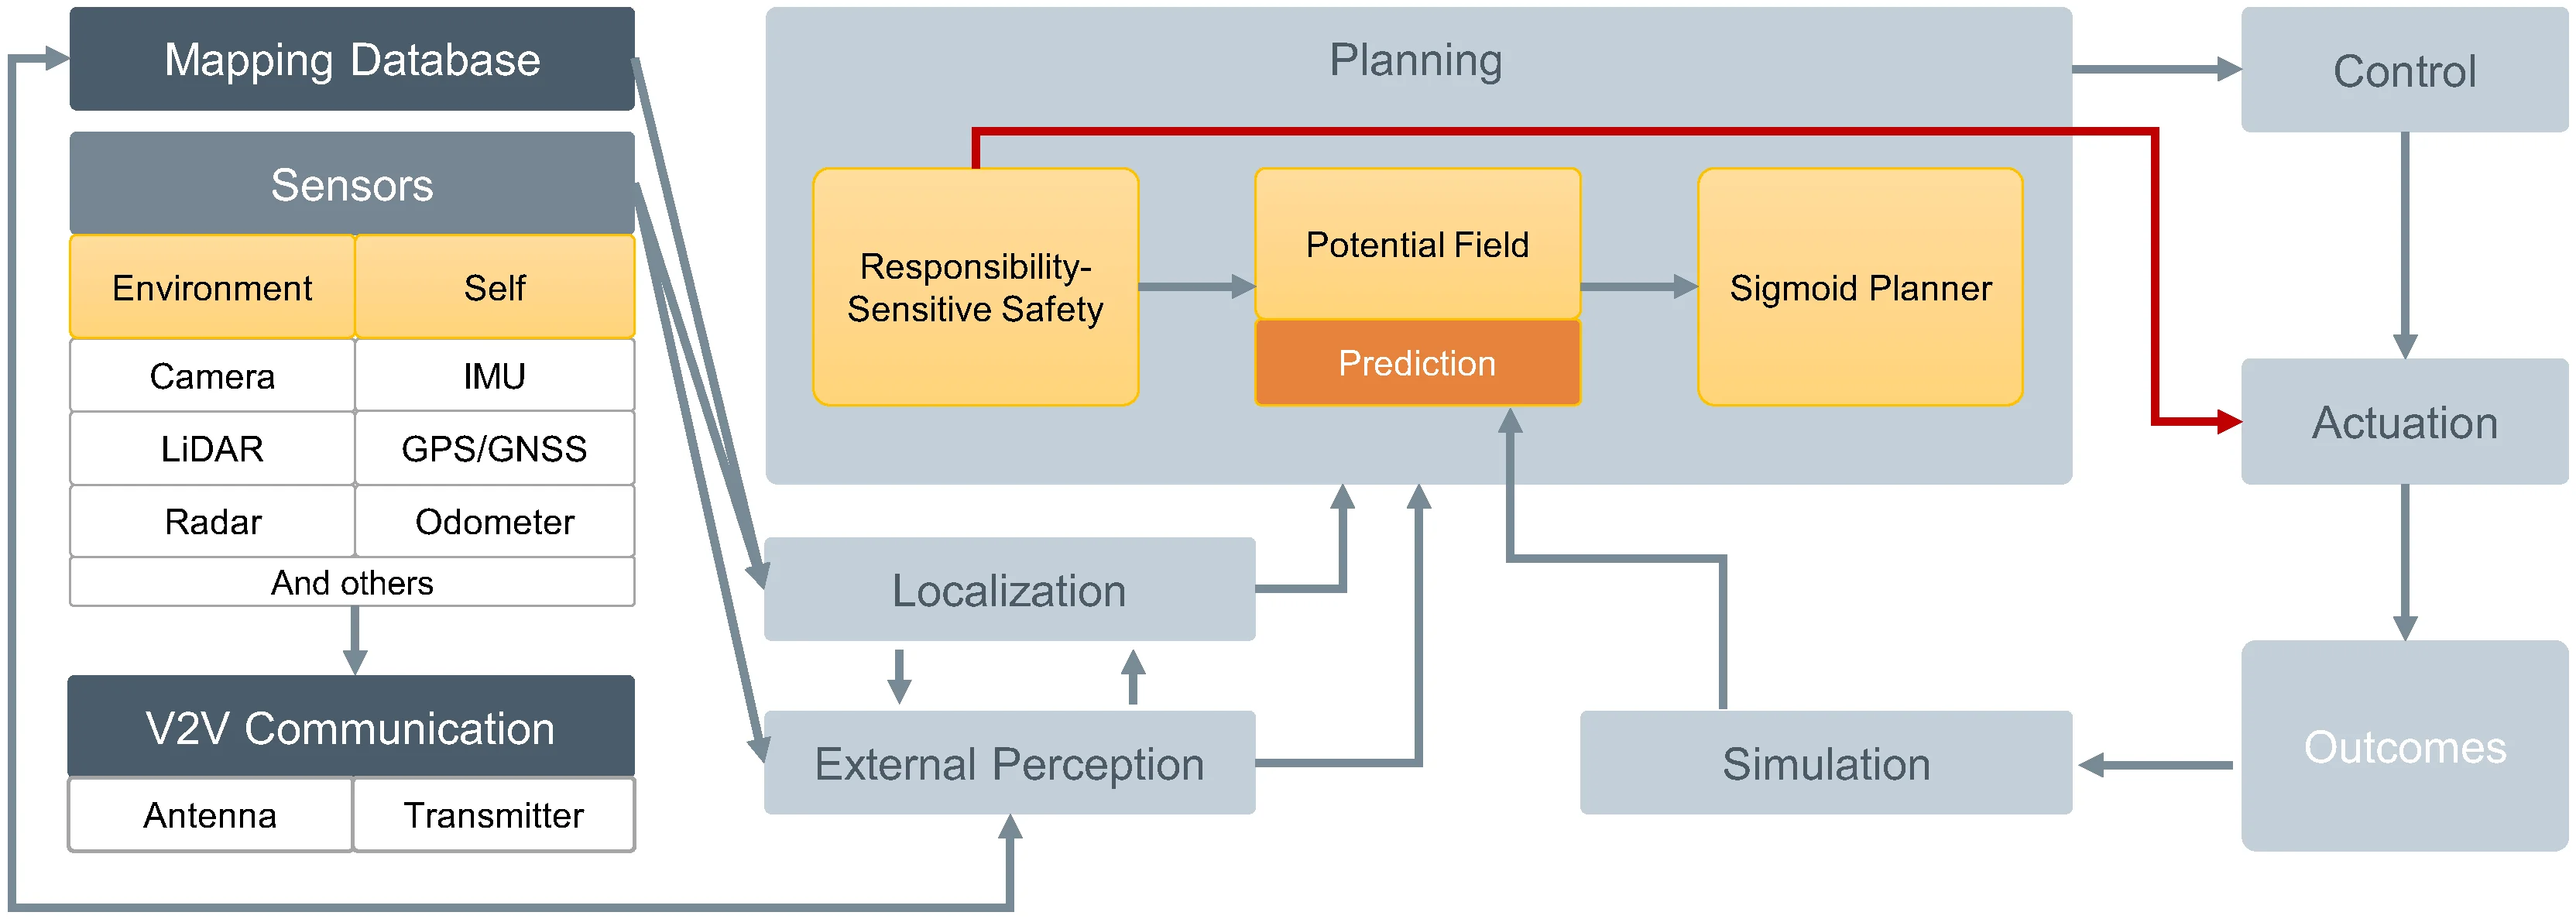
- 拡張RSSで優先権を判定し、ポテンシャル場とシグモイド曲線で経路を生成する。車両間で情報を共有する。
- シミュレーションで振動を解消し、合流時間を72.3%、経路長を53.4%短縮した。
論文の図
アブストラクト(原文)
Lane merging is one of the critical tasks for selfdriving cars, and how to perform lane-merge maneuvers effectively and safely has become one of the important standards in measuring the capability of autonomous driving systems. However, due to the ambiguity in driving intentions and right-of-way issues, the lane merging process in autonomous driving remains deficient in terms of maintaining or ceding the right-of-way and attributing liability, which could result in protracted durations for merging and problems such as trajectory oscillation. Hence, we present a rule-compliance path planner (RCPP) for lane-merge scenarios, which initially employs the extended responsibility-sensitive safety (RSS) to elucidate the right-of-way, followed by the potential field-based sigmoid planner for path generation. In the simulation, we have validated the efficacy of the proposed algorithm. The algorithm demonstrated superior performance over previous approaches in aspects such as merging time (Saved 72.3%), path length (reduced 53.4%), and eliminating the trajectory oscillation.
引用方法
P. Lin, E. Javanmardi, Y. Jiang, and M. Tsukada, “A Rule-Compliance Path Planner for Lane-Merge Scenarios Based on Responsibility-Sensitive Safety,” in 18th International Conference on Control, Automation, Robotics and Vision (ICARCV 2024), Dubai, UAE, 2024, doi: 10.1109/ICARCV63323.2024.10821557.
BibTeX
@inproceedings{Lin2024c,
  title         = {A Rule-Compliance Path Planner for Lane-Merge Scenarios Based on Responsibility-Sensitive Safety},
  author        = {Pengfei Lin and Ehsan Javanmardi and Yuze Jiang and Manabu Tsukada},
  doi           = {10.1109/ICARCV63323.2024.10821557},
  url           = {https://arxiv.org/abs/2403.13251},
  year          = {2024},
  date          = {2024-12-12},
  urldate       = {2024-12-12},
  booktitle     = {18th International Conference on Control, Automation, Robotics and Vision (ICARCV 2024)},
  address       = {Dubai, UAE},
  abstract      = {Lane merging is one of the critical tasks for selfdriving cars, and how to perform lane-merge maneuvers effectively and safely has become one of the important standards in measuring the capability of autonomous driving systems. However, due to the ambiguity in driving intentions and right-of-way issues, the lane merging process in autonomous driving remains deficient in terms of maintaining or ceding the right-of-way and attributing liability, which could result in protracted durations for merging and problems such as trajectory oscillation. Hence, we present a rule-compliance path planner (RCPP) for lane-merge scenarios, which initially employs the extended responsibility-sensitive safety (RSS) to elucidate the right-of-way, followed by the potential field-based sigmoid planner for path generation. In the simulation, we have validated the efficacy of the proposed algorithm. The algorithm demonstrated superior performance over previous approaches in aspects such as merging time (Saved 72.3%), path length (reduced 53.4%), and eliminating the trajectory oscillation.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}