
AutoMCM: Maneuver Coordination Service with Abstracted Functions for Autonomous Driving
24th IEEE International Conference on Intelligent Transportation Systems (ITSC 2021), Indianapolis, IN, USA, 2021年9月19日
arXivDOI: 10.1109/ITSC48978.2021.9564556
3行要約
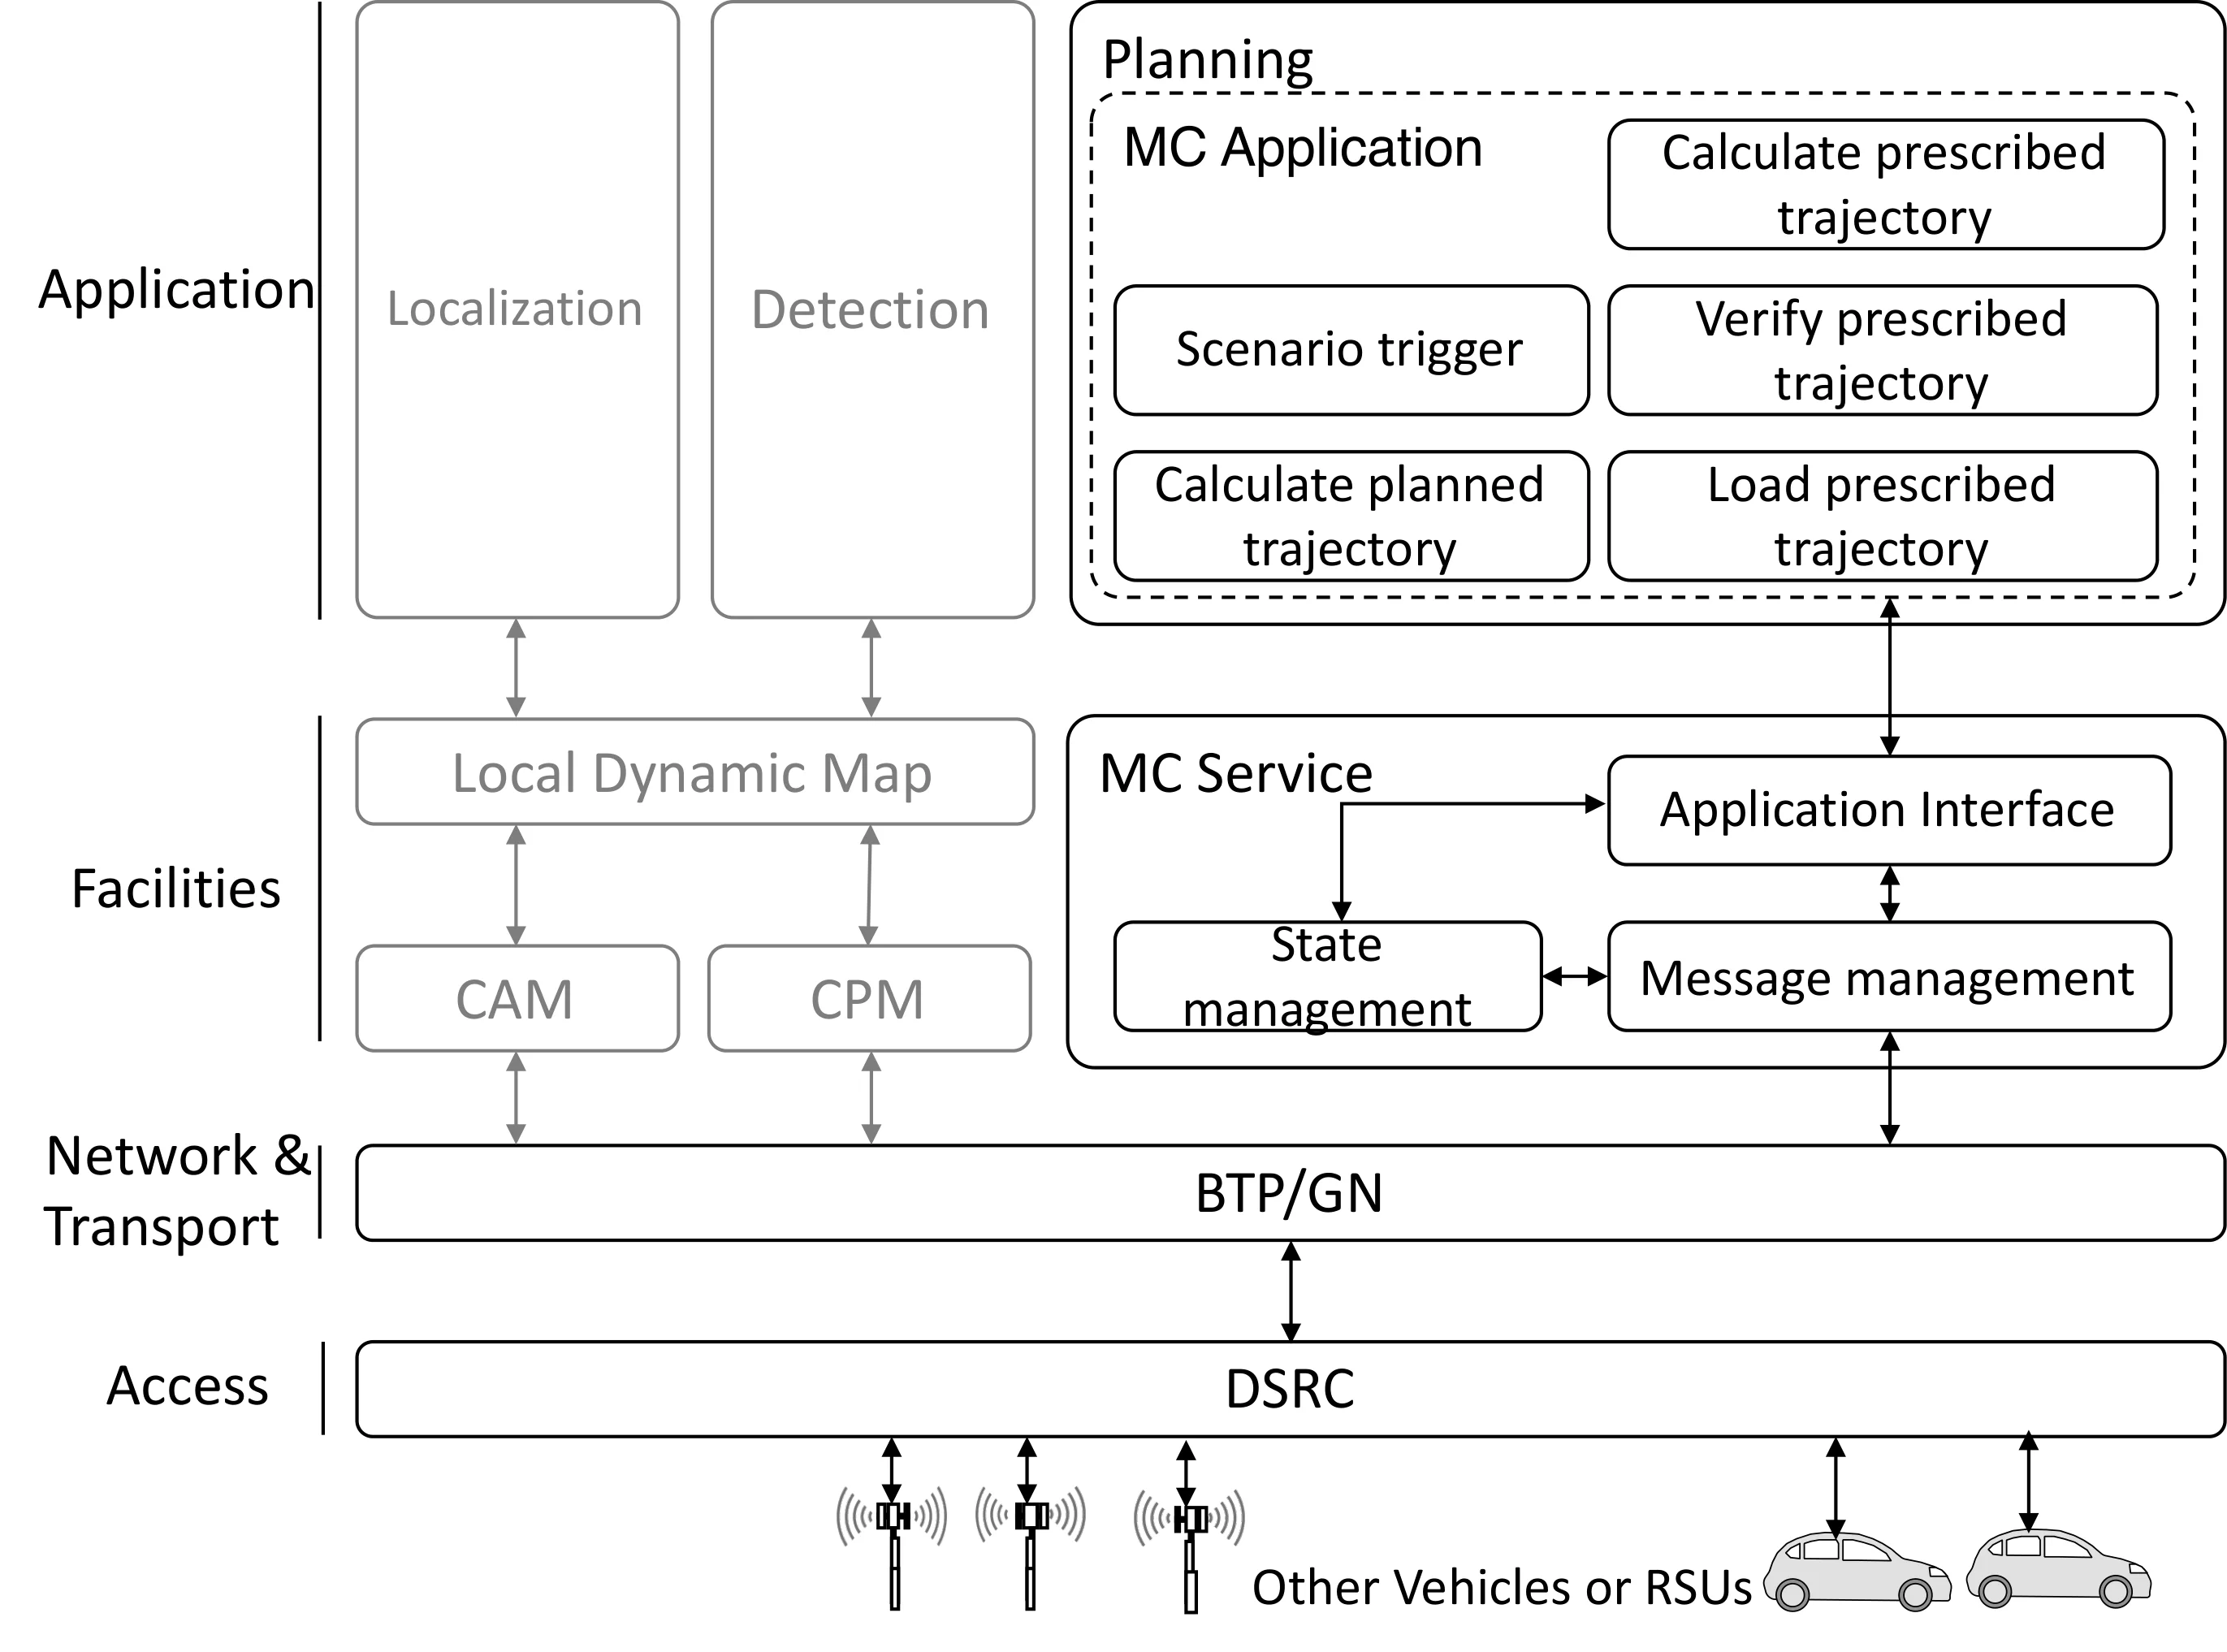
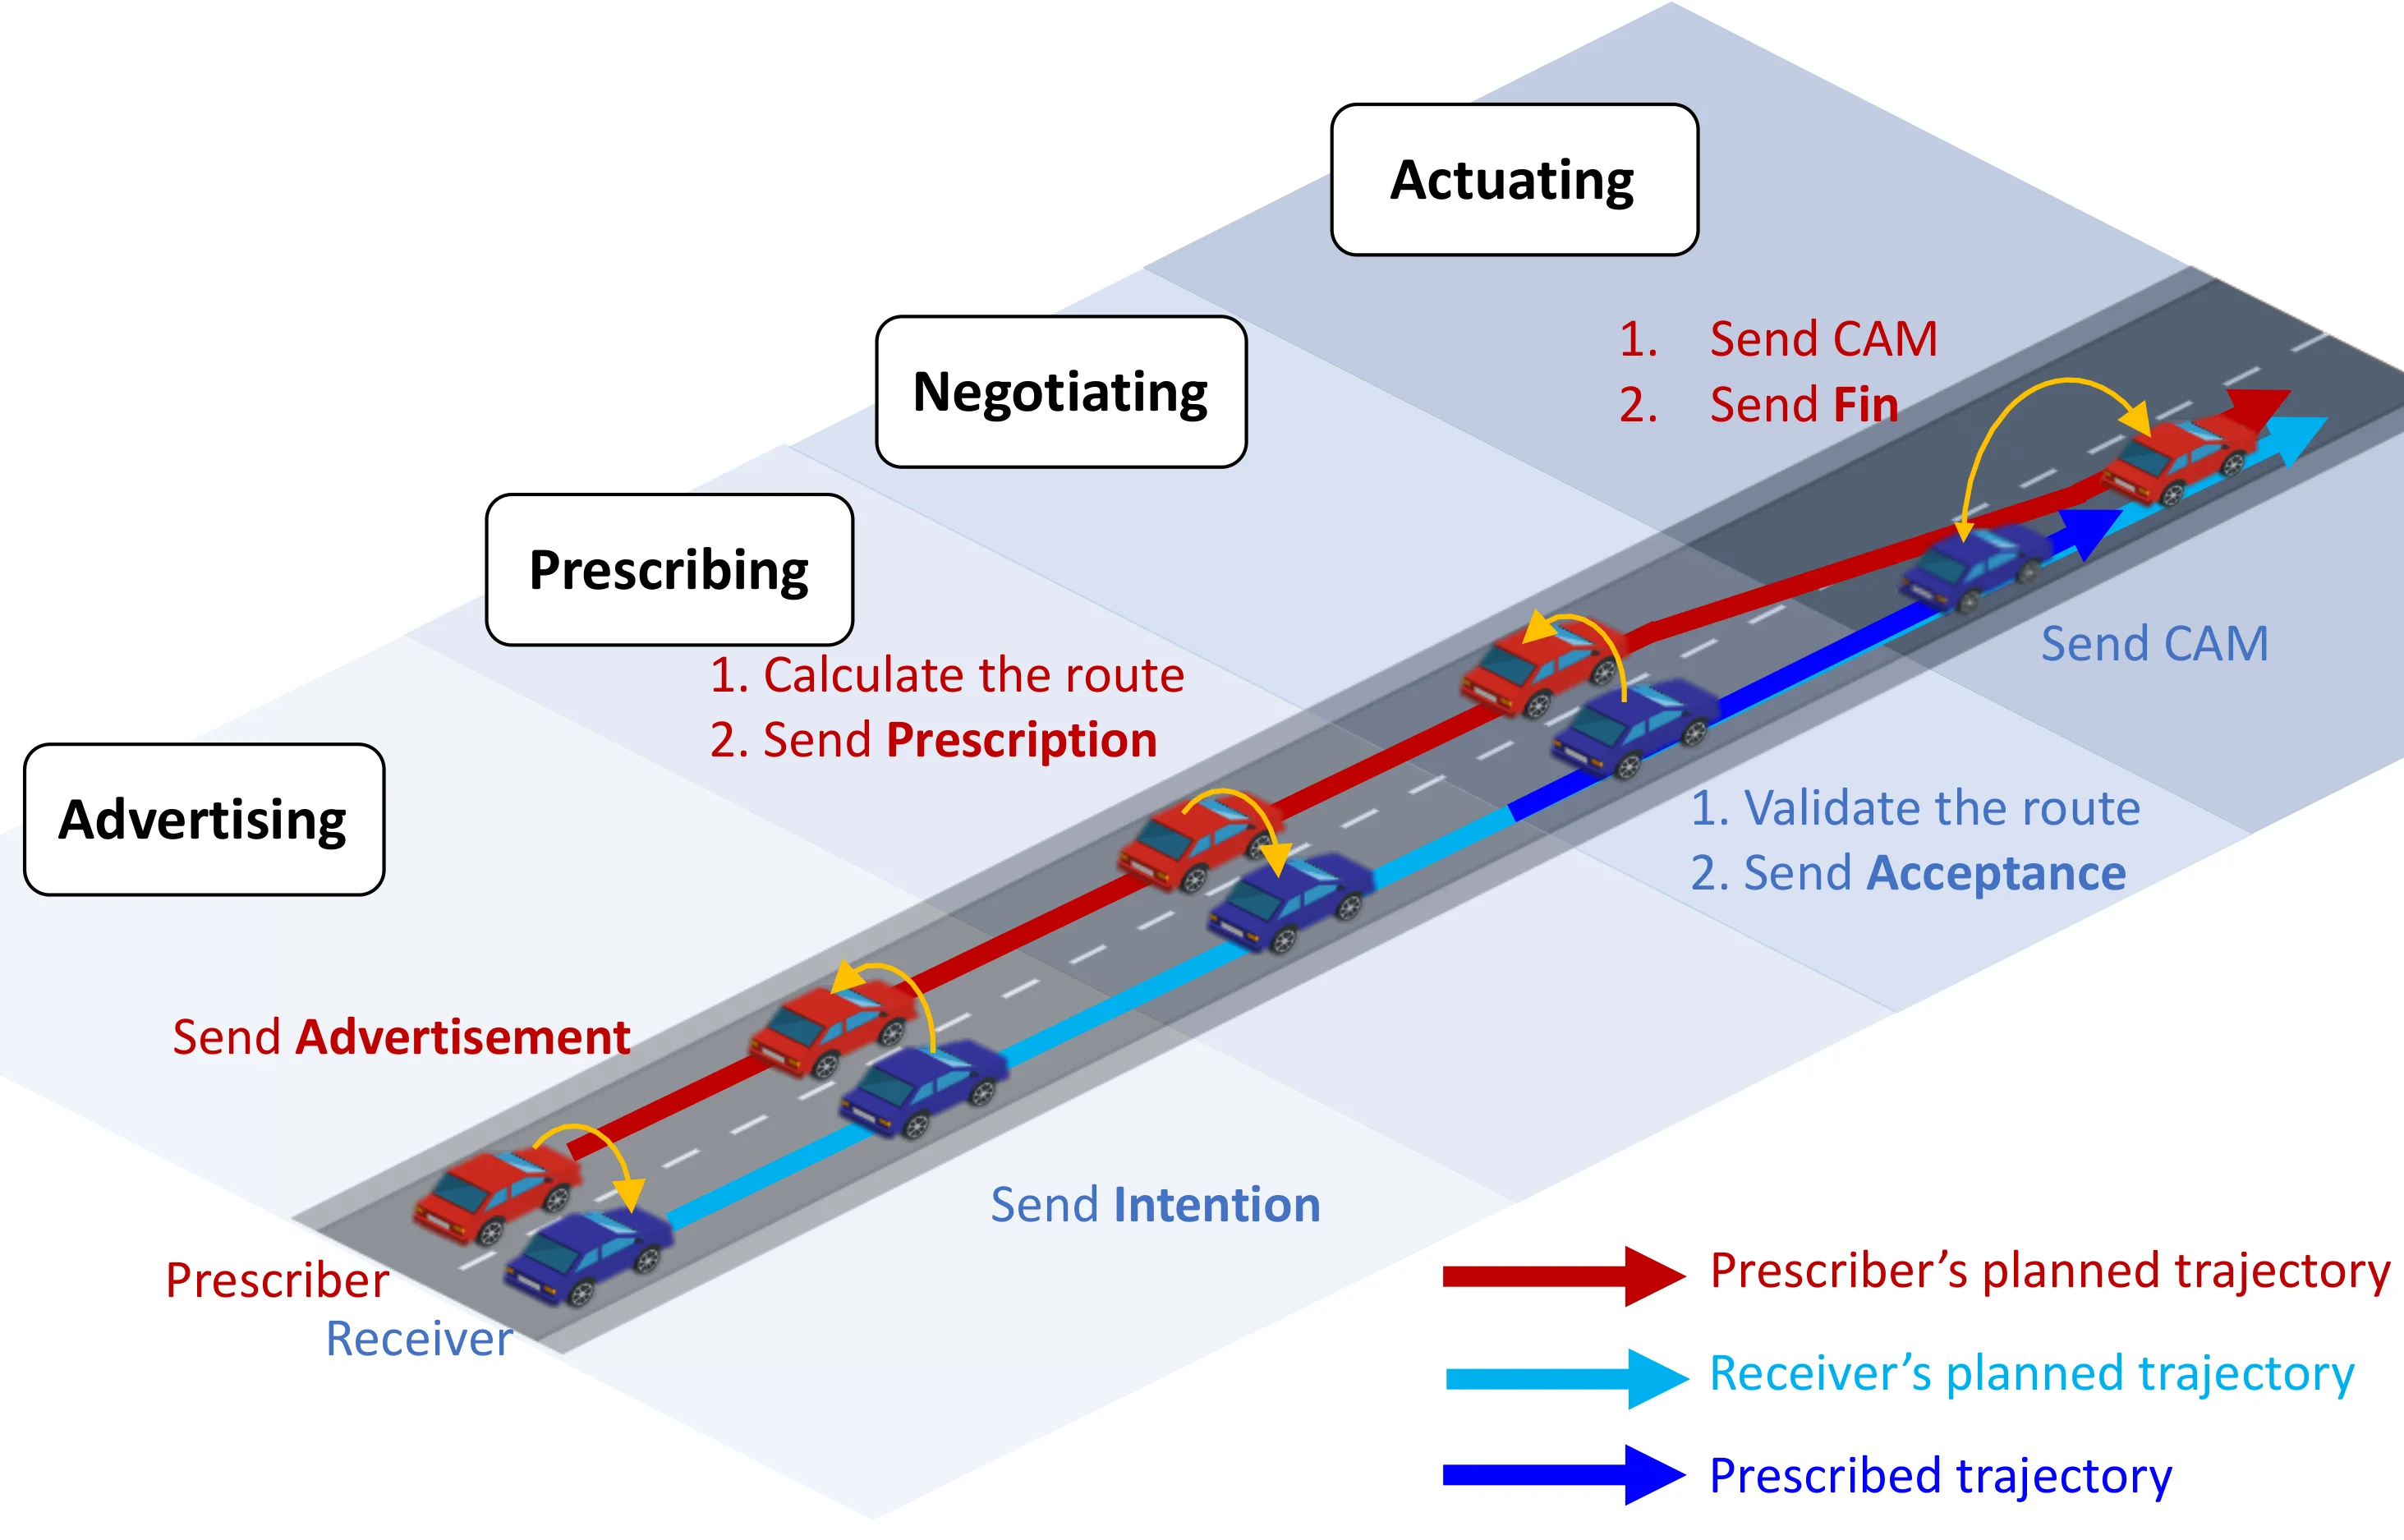
- AutoMCMは、走行調停のための7種類のメッセージと、調停機能を抽象化したサービスを備える。
- AutowareとOpenC2Xを拡張して実装し、調停が必要なイベントに応じてメッセージを交換する。
- 実験では通信量を抑えながら評価シナリオの走行を速め、適切なタイムアウト設定でパケット損失に対応できることを示した。
論文の図
アブストラクト(原文)
A cooperative intelligent transport system (C-ITS) uses vehicle-to-everything (V2X) technology to make self-driving vehicles safer and more efficient. Current C-ITS applications have mainly focused on real-time information sharing, such as for cooperative perception. In addition to better real-time perception, self-driving vehicles need to achieve higher safety and efficiency by coordinating action plans. This study designs a maneuver coordination (MC) protocol that uses seven messages to cover various scenarios and an abstracted MC support service. We implement our proposal as AutoMCM by extending two open-source software tools: Autoware for autonomous driving and OpenC2X for C-ITS. The results show that our system effectively reduces the communication bandwidth by limiting message exchange in an event-driven manner. Furthermore, it shows that the vehicles run 15% faster when the vehicle speed is 30 km/h and 28% faster when the vehicle speed is 50 km/h using our scheme. Our system shows robustness against packet loss in experiments when the message timeout parameters are appropriately set.
動画
関連する研究・ソフトウェア
引用方法
M. Mizutani, M. Tsukada, and H. Esaki, “AutoMCM: Maneuver Coordination Service with Abstracted Functions for Autonomous Driving,” in 24th IEEE International Conference on Intelligent Transportation Systems (ITSC 2021), Indianapolis, IN, USA, 2021, doi: 10.1109/ITSC48978.2021.9564556.
BibTeX
@inproceedings{Mizutani2021b,
  title         = {AutoMCM: Maneuver Coordination Service with Abstracted Functions for Autonomous Driving},
  author        = {Masaya Mizutani and Manabu Tsukada and Hiroshi Esaki},
  url           = {https://arxiv.org/abs/2107.06627 https://youtu.be/eC7L0R_1Ybo https://youtu.be/s3l5zypizxQ https://youtu.be/XBpZeT-apGE},
  doi           = {10.1109/ITSC48978.2021.9564556},
  year          = {2021},
  date          = {2021-09-19},
  urldate       = {2021-09-19},
  booktitle     = {24th IEEE International Conference on Intelligent Transportation Systems (ITSC 2021)},
  address       = {Indianapolis, IN, USA},
  abstract      = {A cooperative intelligent transport system (C-ITS) uses vehicle-to-everything (V2X) technology to make self-driving vehicles safer and more efficient. Current C-ITS applications have mainly focused on real-time information sharing, such as for cooperative perception. In addition to better real-time perception, self-driving vehicles need to achieve higher safety and efficiency by coordinating action plans. This study designs a maneuver coordination (MC) protocol that uses seven messages to cover various scenarios and an abstracted MC support service. We implement our proposal as AutoMCM by extending two open-source software tools: Autoware for autonomous driving and OpenC2X for C-ITS. The results show that our system effectively reduces the communication bandwidth by limiting message exchange in an event-driven manner. Furthermore, it shows that the vehicles run 15% faster when the vehicle speed is 30 km/h and 28% faster when the vehicle speed is 50 km/h using our scheme. Our system shows robustness against packet loss in experiments when the message timeout parameters are appropriately set.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}