
Cooperative awareness using roadside unit networks in mixed traffic
IEEE Vehicular Networking Conference (VNC 2019), pp. 9–16, 2019年12月4日
PDFDOI: 10.1109/VNC48660.2019.9062773
3行要約
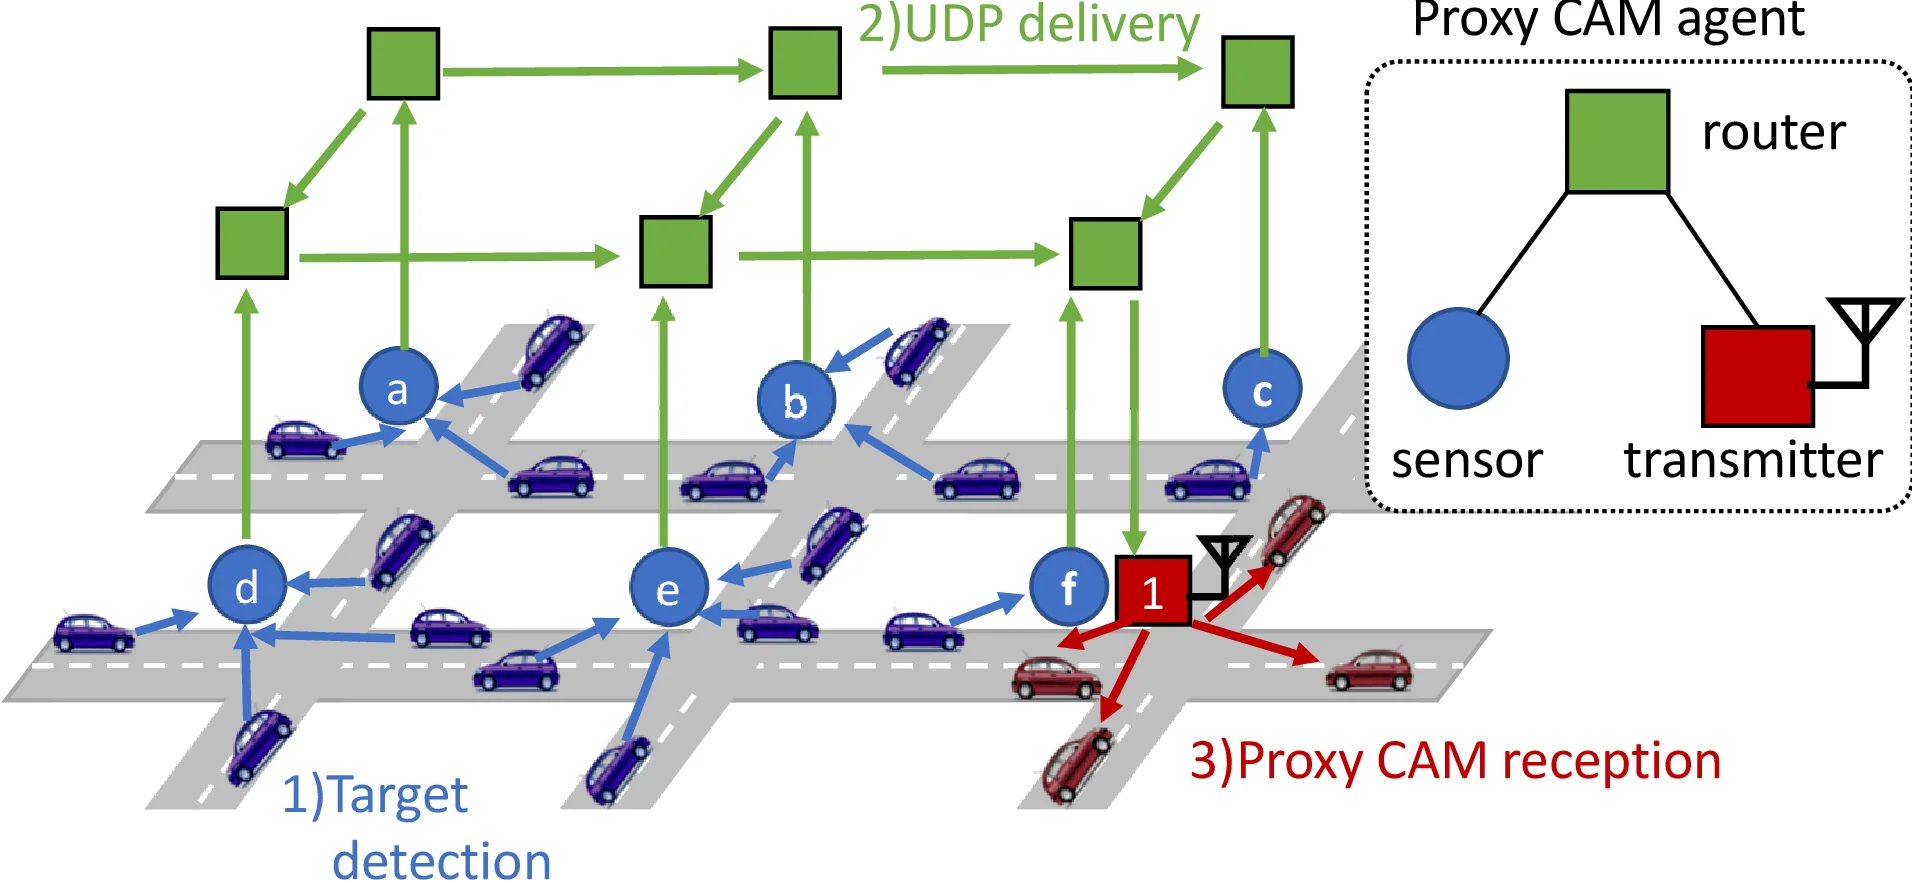
- Grid Proxy CAMは、自ら状態を発信できない車両を路側で検知し、その情報を通常の無線範囲の外にも届ける。
- 路側機を高速ネットワークで結び、安全への寄与に応じてメッセージを優先する。
- 東京とパリの地図を使ったシミュレーションでは、高い到達率と低遅延を保ちながら配信範囲を広げられることを示した。
論文の図
アブストラクト(原文)
Vehicle-to-vehicle (V2V) messaging is an indispensable component of connected autonomous vehicle systems. Although V2V standards have been specified by the European Union, United States, and Japan, the deployment phase represents mixed traffic in which connected and legacy vehicles co-exist. To enhance cooperative awareness in this mixed traffic, we assessed the special roadside unit that we developed in our previous work that generates required V2V messages on behalf of sensed target vehicles. In this paper, we extend our earlier work to propose a system called “Grid Proxy Cooperative Awareness Message to broaden the cooperative awareness message dissemination area by connecting infrastructure using high-speed roadside networks. To minimize delay in message delivery, we designed the proposed system to use edge computing. The proposed scheme delivers cooperative messages to a wider area with a low delay and a high packet delivery ratio by prioritizing packets by their respective safety contributions. Our simulation results indicate that the proposed scheme efficiently delivers messages in heavy road traffic conditions modeled on real maps of Tokyo and Paris.
動画
関連する研究・ソフトウェア
引用方法
M. Tsukada, M. Kitazawa, T. Oi, H. Ochiai, and H. Esaki, “Cooperative awareness using roadside unit networks in mixed traffic,” in IEEE Vehicular Networking Conference (VNC 2019), 2019, doi: 10.1109/VNC48660.2019.9062773.
BibTeX
@inproceedings{Tsukada2019b,
  title         = {Cooperative awareness using roadside unit networks in mixed traffic},
  author        = {Manabu Tsukada and Masahiro Kitazawa and Takaharu Oi and Hideya Ochiai and Hiroshi Esaki},
  url           = {https://hal.archives-ouvertes.fr/hal-02335068/?.pdf},
  doi           = {10.1109/VNC48660.2019.9062773},
  year          = {2019},
  date          = {2019-12-04},
  booktitle     = {IEEE Vehicular Networking Conference (VNC 2019)},
  pages         = {9--16},
  abstract      = {Vehicle-to-vehicle (V2V) messaging is an indispensable component of connected autonomous vehicle systems. Although V2V standards have been specified by the European Union, United States, and Japan, the deployment phase represents mixed traffic in which connected and legacy vehicles co-exist. To enhance cooperative awareness in this mixed traffic, we assessed the special roadside unit that we developed in our previous work that generates required V2V messages on behalf of sensed target vehicles. In this paper, we extend our earlier work to propose a system called “Grid Proxy Cooperative Awareness Message to broaden the cooperative awareness message dissemination area by connecting infrastructure using high-speed roadside networks. To minimize delay in message delivery, we designed the proposed system to use edge computing.  The proposed scheme delivers cooperative messages to a wider area with a low delay and a high packet delivery ratio by prioritizing packets by their respective safety contributions. Our simulation results indicate that the proposed scheme efficiently delivers messages in heavy road traffic conditions modeled on real maps of Tokyo and Paris.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}