
AutoC2X: Open-source software to realize V2X cooperative perception among autonomous vehicles
IEEE 92nd Vehicular Technology Conference (VTC2020-Fall), Victoria, B.C., Canada, 2020年11月18日
GitHub(コード)PDFDOI: 10.1109/VTC2020-Fall49728.2020.9348525
3行要約
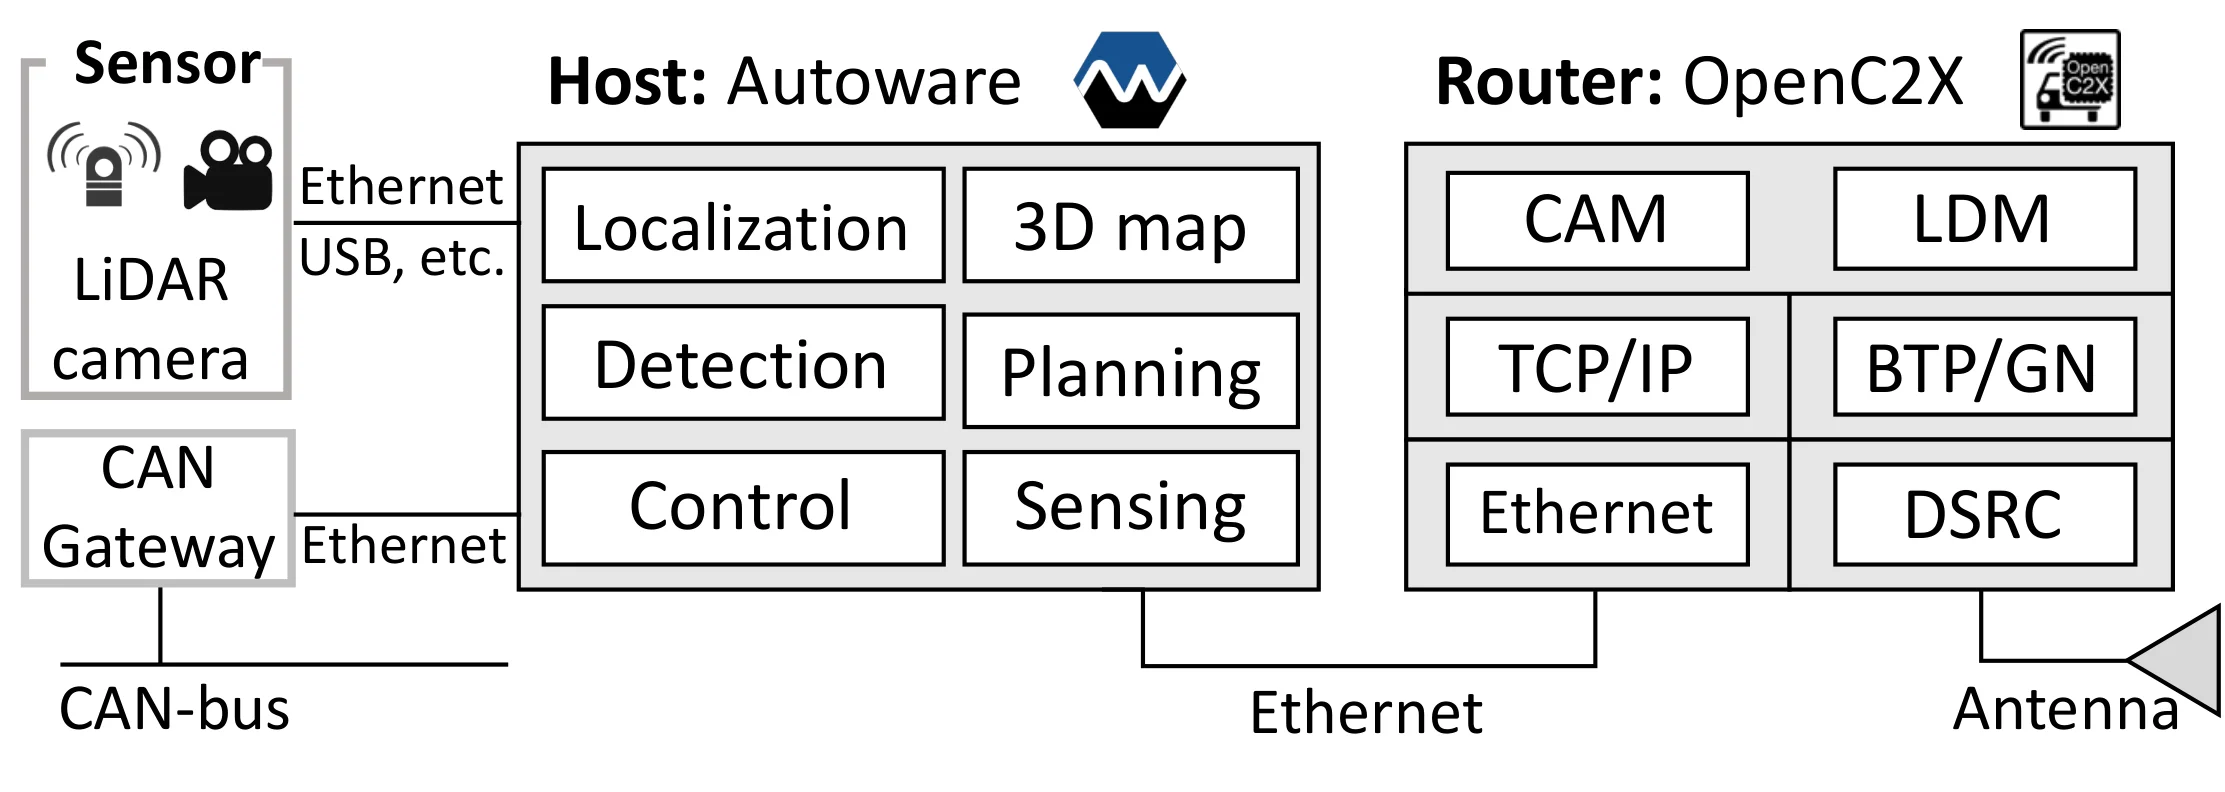
- AutoC2XはAutowareとOpenC2Xを接続し、センサーの認識情報をV2Xで共有する。
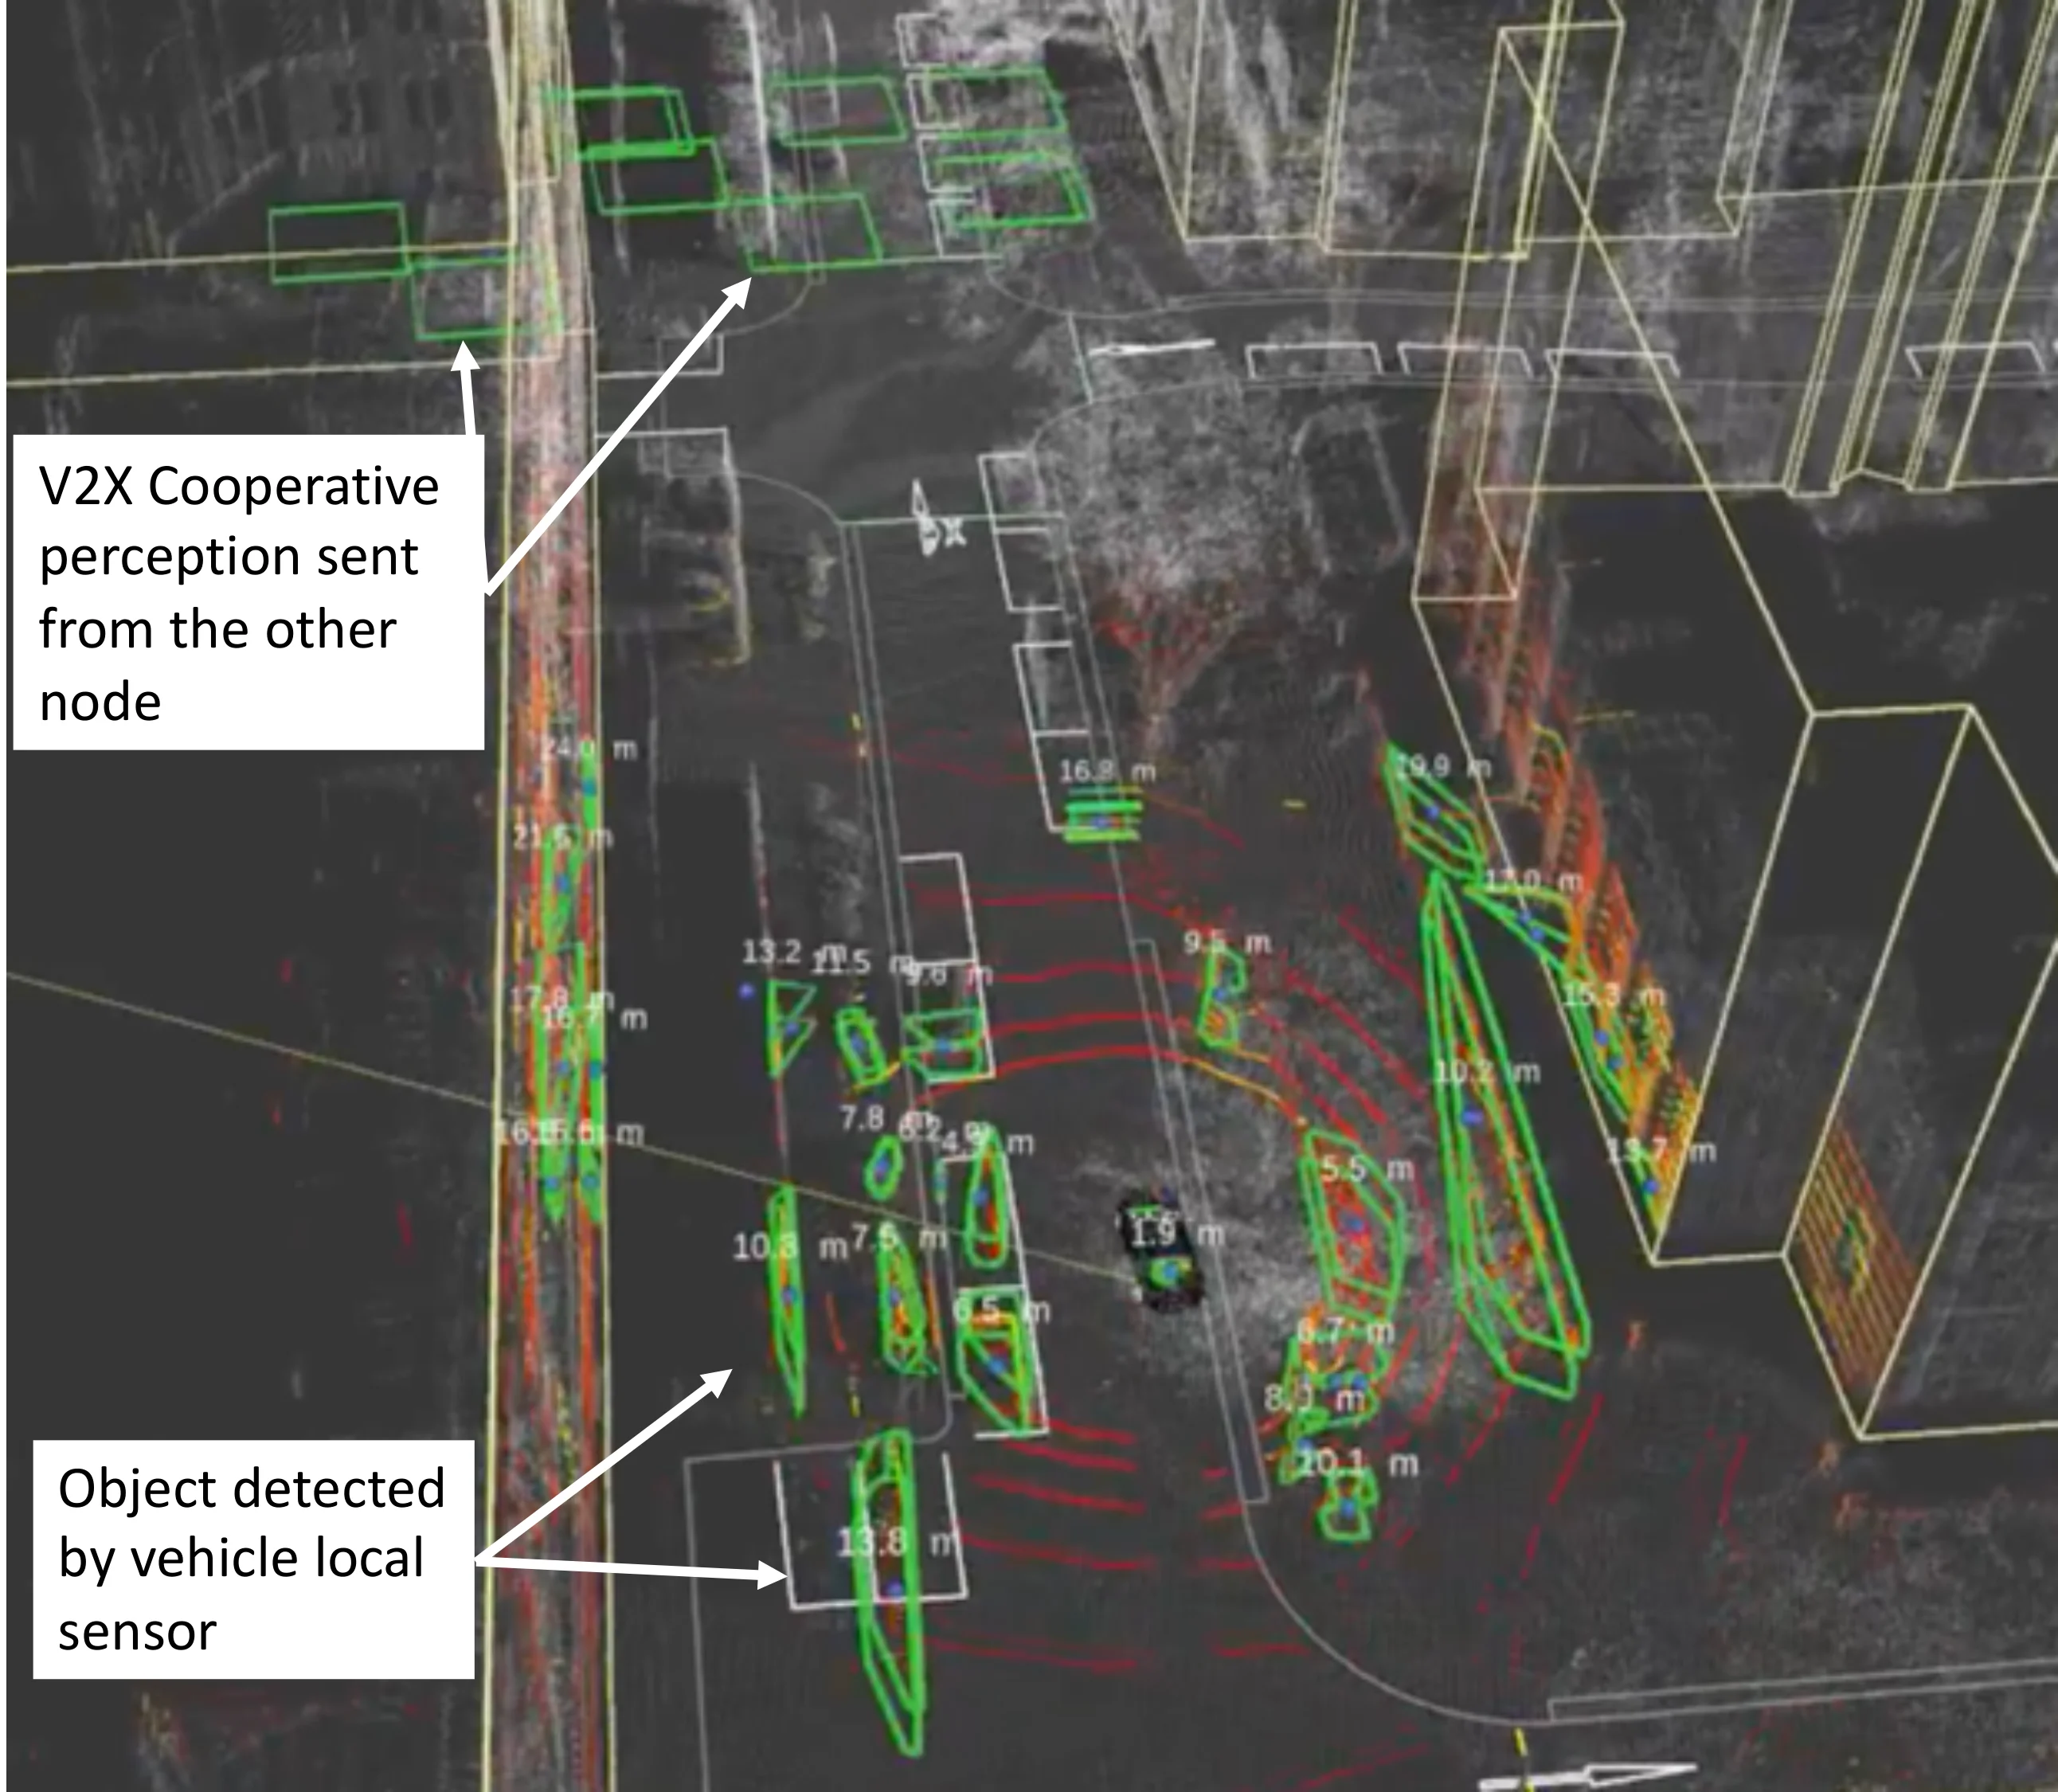
- オープンソースの実装により、路側で検知した物体を自動運転車の認識に取り込める。
- 実機を用いたフィールド実験では、観測された最も遅い場合でも認識メッセージは100 ms以内に届いた。
論文の図
アブストラクト(原文)
The realization of vehicle-to-everything (V2X) communication enhances the capabilities of autonomous vehicles in terms of safety efficiency and comfort. In particular, sensor data sharing, known as cooperative perception, is a crucial technique to accommodate vulnerable road users in a cooperative intelligent transport system (ITS). In this regard, open-source software plays a significant role in prototyping, validation, and deployment. Specifically, in the developer community, Autoware is a popular open-source software for self-driving vehicles, and OpenC2X is an open-source experimental and prototyping platform for cooperative ITS. This paper reports on a system named AutoC2X to enable cooperative perception by using OpenC2X for Autoware-based autonomous vehicles. The developed system is evaluated by conducting field experiments involving real hardware. The results demonstrate that AutoC2X can deliver the cooperative perception message within 100 ms in the worst case.
動画
コード
関連する研究・ソフトウェア
引用方法
M. Tsukada, T. Oi, A. Ito, M. Hirata, and H. Esaki, “AutoC2X: Open-source software to realize V2X cooperative perception among autonomous vehicles,” in IEEE 92nd Vehicular Technology Conference (VTC2020-Fall), Victoria, B.C., Canada, 2020, doi: 10.1109/VTC2020-Fall49728.2020.9348525.
BibTeX
@inproceedings{Tsukada2020,
  title         = {AutoC2X: Open-source software to realize V2X cooperative perception among autonomous vehicles},
  author        = {Manabu Tsukada and Takaharu Oi and Akihide Ito and Mai Hirata and Hiroshi Esaki},
  url           = {https://github.com/esakilab/AutoC2X-AW https://hal.archives-ouvertes.fr/hal-02942051/document?.pdf https://youtu.be/kyv0sTyCIgU},
  doi           = {10.1109/VTC2020-Fall49728.2020.9348525},
  year          = {2020},
  date          = {2020-11-18},
  urldate       = {2020-11-18},
  booktitle     = {IEEE 92nd Vehicular Technology Conference (VTC2020-Fall)},
  address       = {Victoria, B.C., Canada},
  abstract      = {The realization of vehicle-to-everything (V2X) communication enhances the capabilities of autonomous vehicles in terms of safety efficiency and comfort. In particular, sensor data sharing, known as cooperative perception, is a crucial technique to accommodate vulnerable road users in a cooperative intelligent transport system (ITS). In this regard, open-source software plays a significant role in prototyping, validation, and deployment. Specifically, in the developer community, Autoware is a popular open-source software for self-driving vehicles, and OpenC2X is an open-source experimental and prototyping platform for cooperative ITS. This paper reports on a system named AutoC2X to enable cooperative perception by using OpenC2X for Autoware-based autonomous vehicles. The developed system is evaluated by conducting field experiments involving real hardware. The results demonstrate that AutoC2X can deliver the cooperative perception message within 100 ms in the worst case.},
  keywords      = {ITS, Software-Data},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}