
AutoC2X: Open-source software to realize V2X cooperative perception among autonomous vehicles
IEEE 92nd Vehicular Technology Conference (VTC2020-Fall), Victoria, B.C., Canada, Nov 18, 2020
GitHub (code)PDFDOI: 10.1109/VTC2020-Fall49728.2020.9348525
Summary in three lines
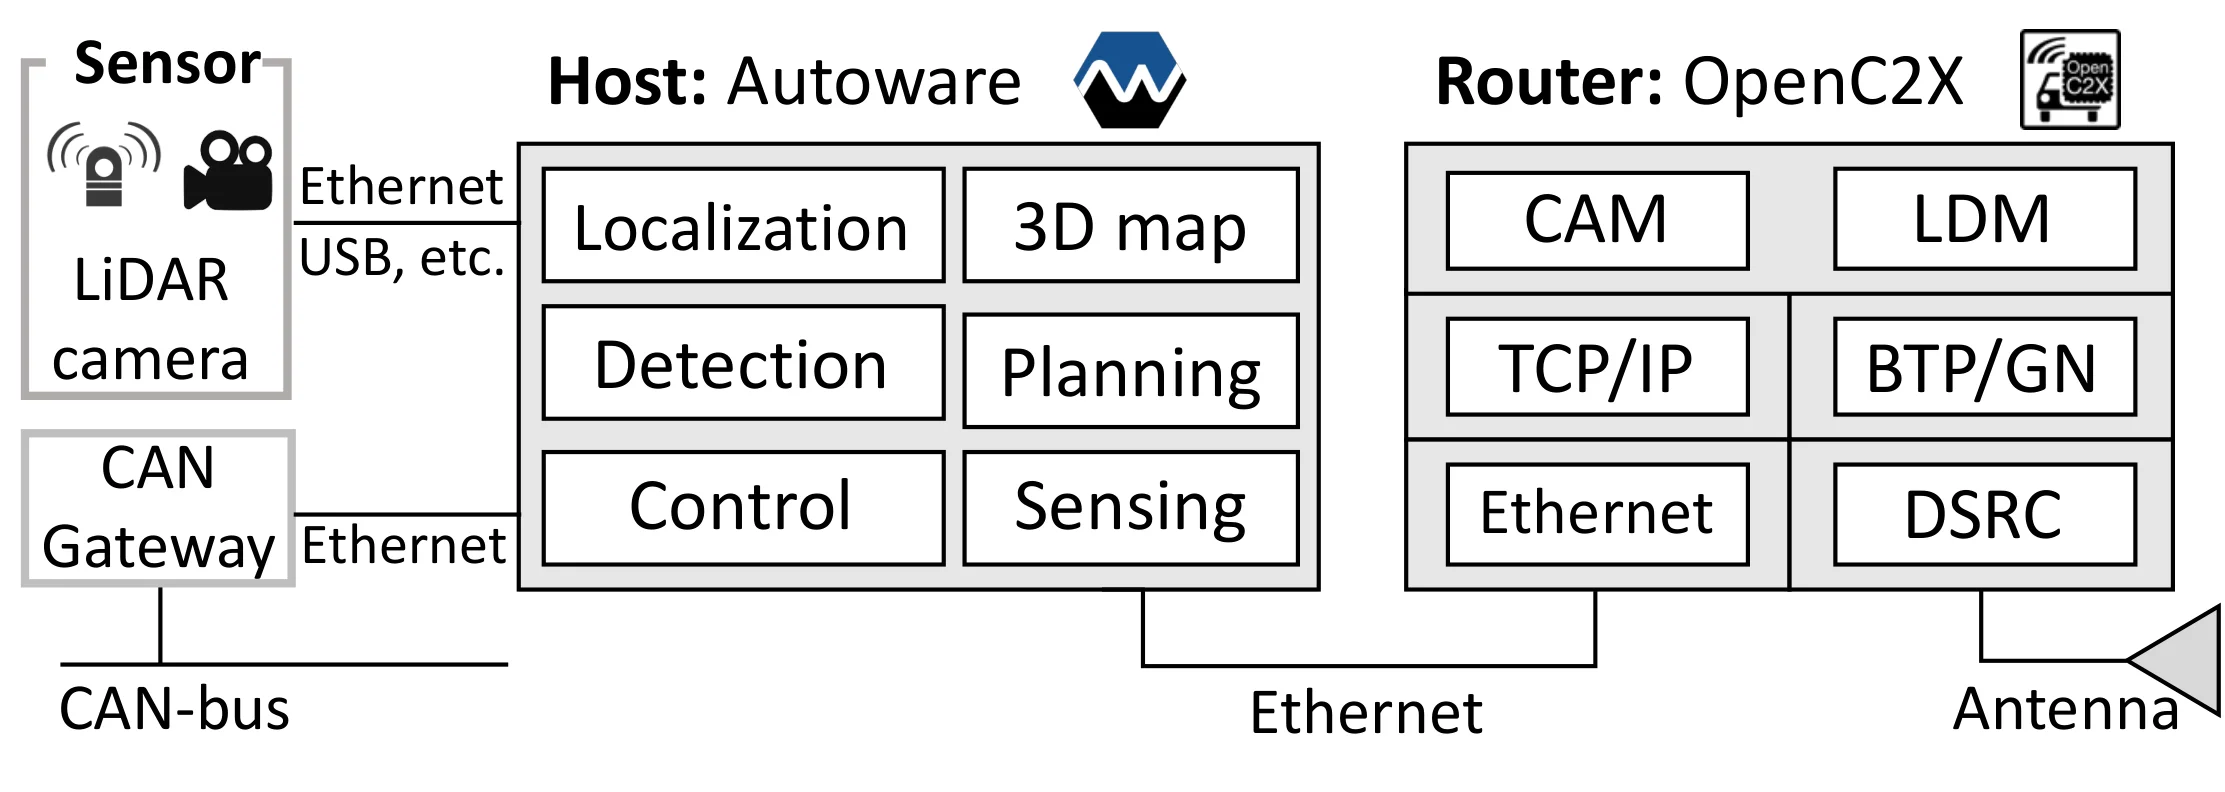
- AutoC2X connects the Autoware driving stack with OpenC2X to share sensor detections through V2X.
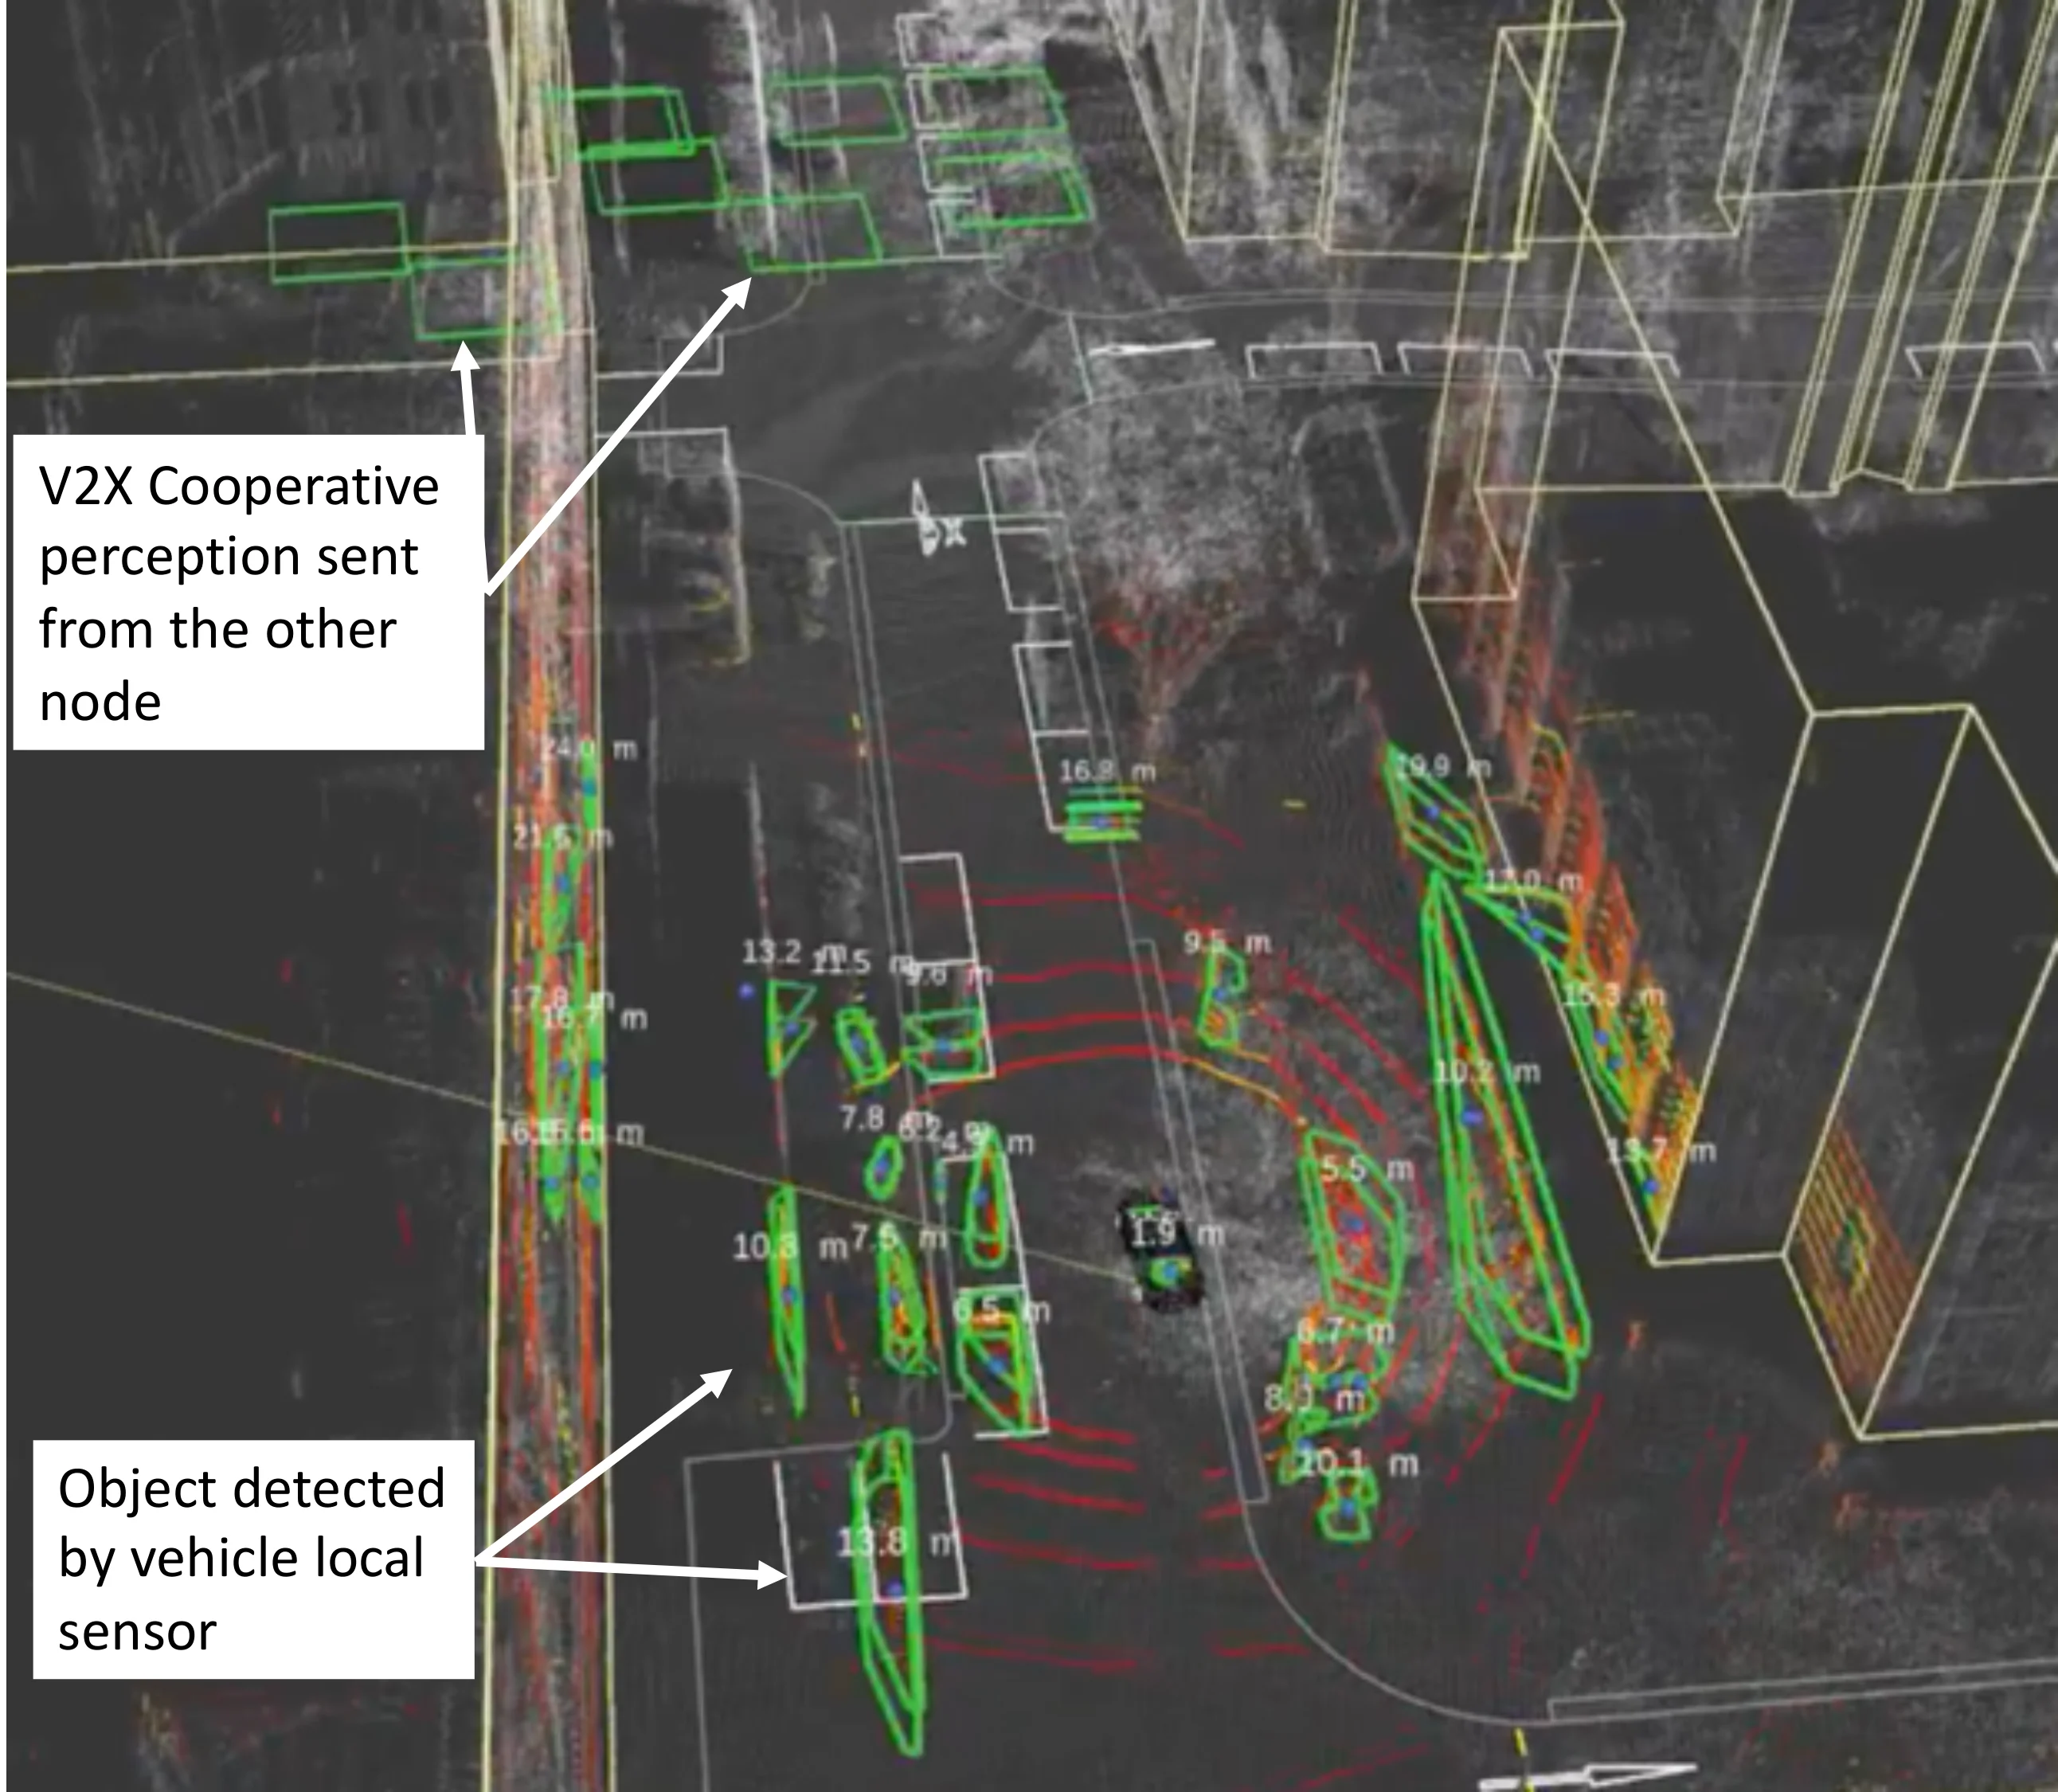
- The open-source integration brings roadside detections into the vehicle's perception view.
- In field experiments with real hardware, perception messages arrived within 100 ms in the worst observed case.
Figures from the paper
Abstract
The realization of vehicle-to-everything (V2X) communication enhances the capabilities of autonomous vehicles in terms of safety efficiency and comfort. In particular, sensor data sharing, known as cooperative perception, is a crucial technique to accommodate vulnerable road users in a cooperative intelligent transport system (ITS). In this regard, open-source software plays a significant role in prototyping, validation, and deployment. Specifically, in the developer community, Autoware is a popular open-source software for self-driving vehicles, and OpenC2X is an open-source experimental and prototyping platform for cooperative ITS. This paper reports on a system named AutoC2X to enable cooperative perception by using OpenC2X for Autoware-based autonomous vehicles. The developed system is evaluated by conducting field experiments involving real hardware. The results demonstrate that AutoC2X can deliver the cooperative perception message within 100 ms in the worst case.
Video
Code
Related research and software
How to cite
M. Tsukada, T. Oi, A. Ito, M. Hirata, and H. Esaki, “AutoC2X: Open-source software to realize V2X cooperative perception among autonomous vehicles,” in IEEE 92nd Vehicular Technology Conference (VTC2020-Fall), Victoria, B.C., Canada, 2020, doi: 10.1109/VTC2020-Fall49728.2020.9348525.
BibTeX
@inproceedings{Tsukada2020,
  title         = {AutoC2X: Open-source software to realize V2X cooperative perception among autonomous vehicles},
  author        = {Manabu Tsukada and Takaharu Oi and Akihide Ito and Mai Hirata and Hiroshi Esaki},
  url           = {https://github.com/esakilab/AutoC2X-AW https://hal.archives-ouvertes.fr/hal-02942051/document?.pdf https://youtu.be/kyv0sTyCIgU},
  doi           = {10.1109/VTC2020-Fall49728.2020.9348525},
  year          = {2020},
  date          = {2020-11-18},
  urldate       = {2020-11-18},
  booktitle     = {IEEE 92nd Vehicular Technology Conference (VTC2020-Fall)},
  address       = {Victoria, B.C., Canada},
  abstract      = {The realization of vehicle-to-everything (V2X) communication enhances the capabilities of autonomous vehicles in terms of safety efficiency and comfort. In particular, sensor data sharing, known as cooperative perception, is a crucial technique to accommodate vulnerable road users in a cooperative intelligent transport system (ITS). In this regard, open-source software plays a significant role in prototyping, validation, and deployment. Specifically, in the developer community, Autoware is a popular open-source software for self-driving vehicles, and OpenC2X is an open-source experimental and prototyping platform for cooperative ITS. This paper reports on a system named AutoC2X to enable cooperative perception by using OpenC2X for Autoware-based autonomous vehicles. The developed system is evaluated by conducting field experiments involving real hardware. The results demonstrate that AutoC2X can deliver the cooperative perception message within 100 ms in the worst case.},
  keywords      = {ITS, Software-Data},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}