
Networked Roadside Perception Units for Autonomous Driving
Sensors, vol. 20, no. 18, 2020年9月17日
3行要約
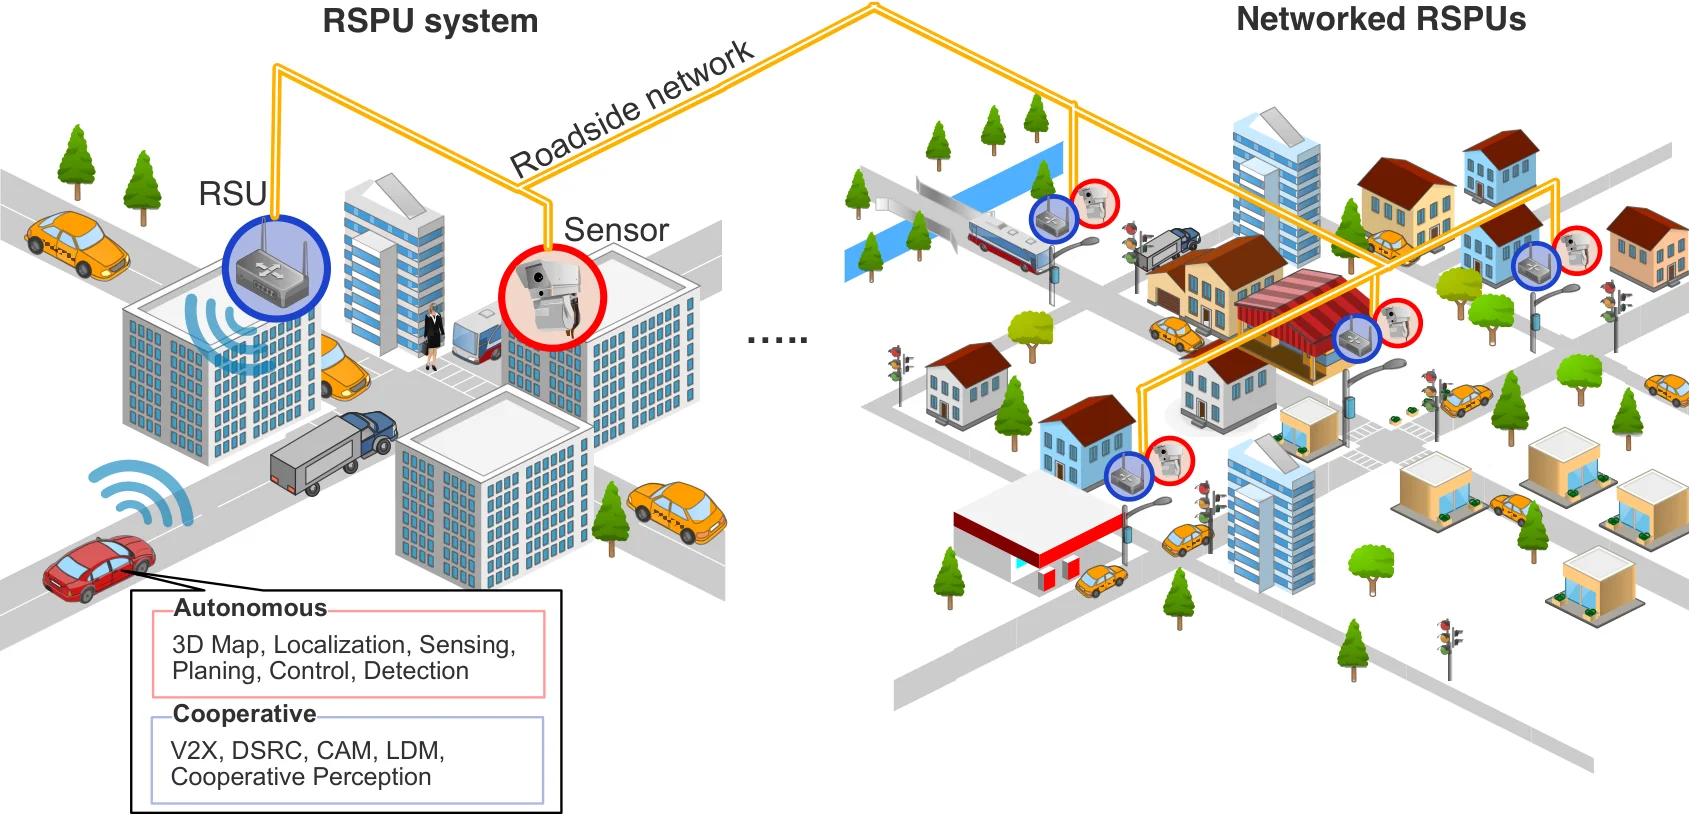
- 路側認識ユニットは路側センサーとV2X機器を組み合わせ、AutoC2Xで認識情報を車両へ共有する。
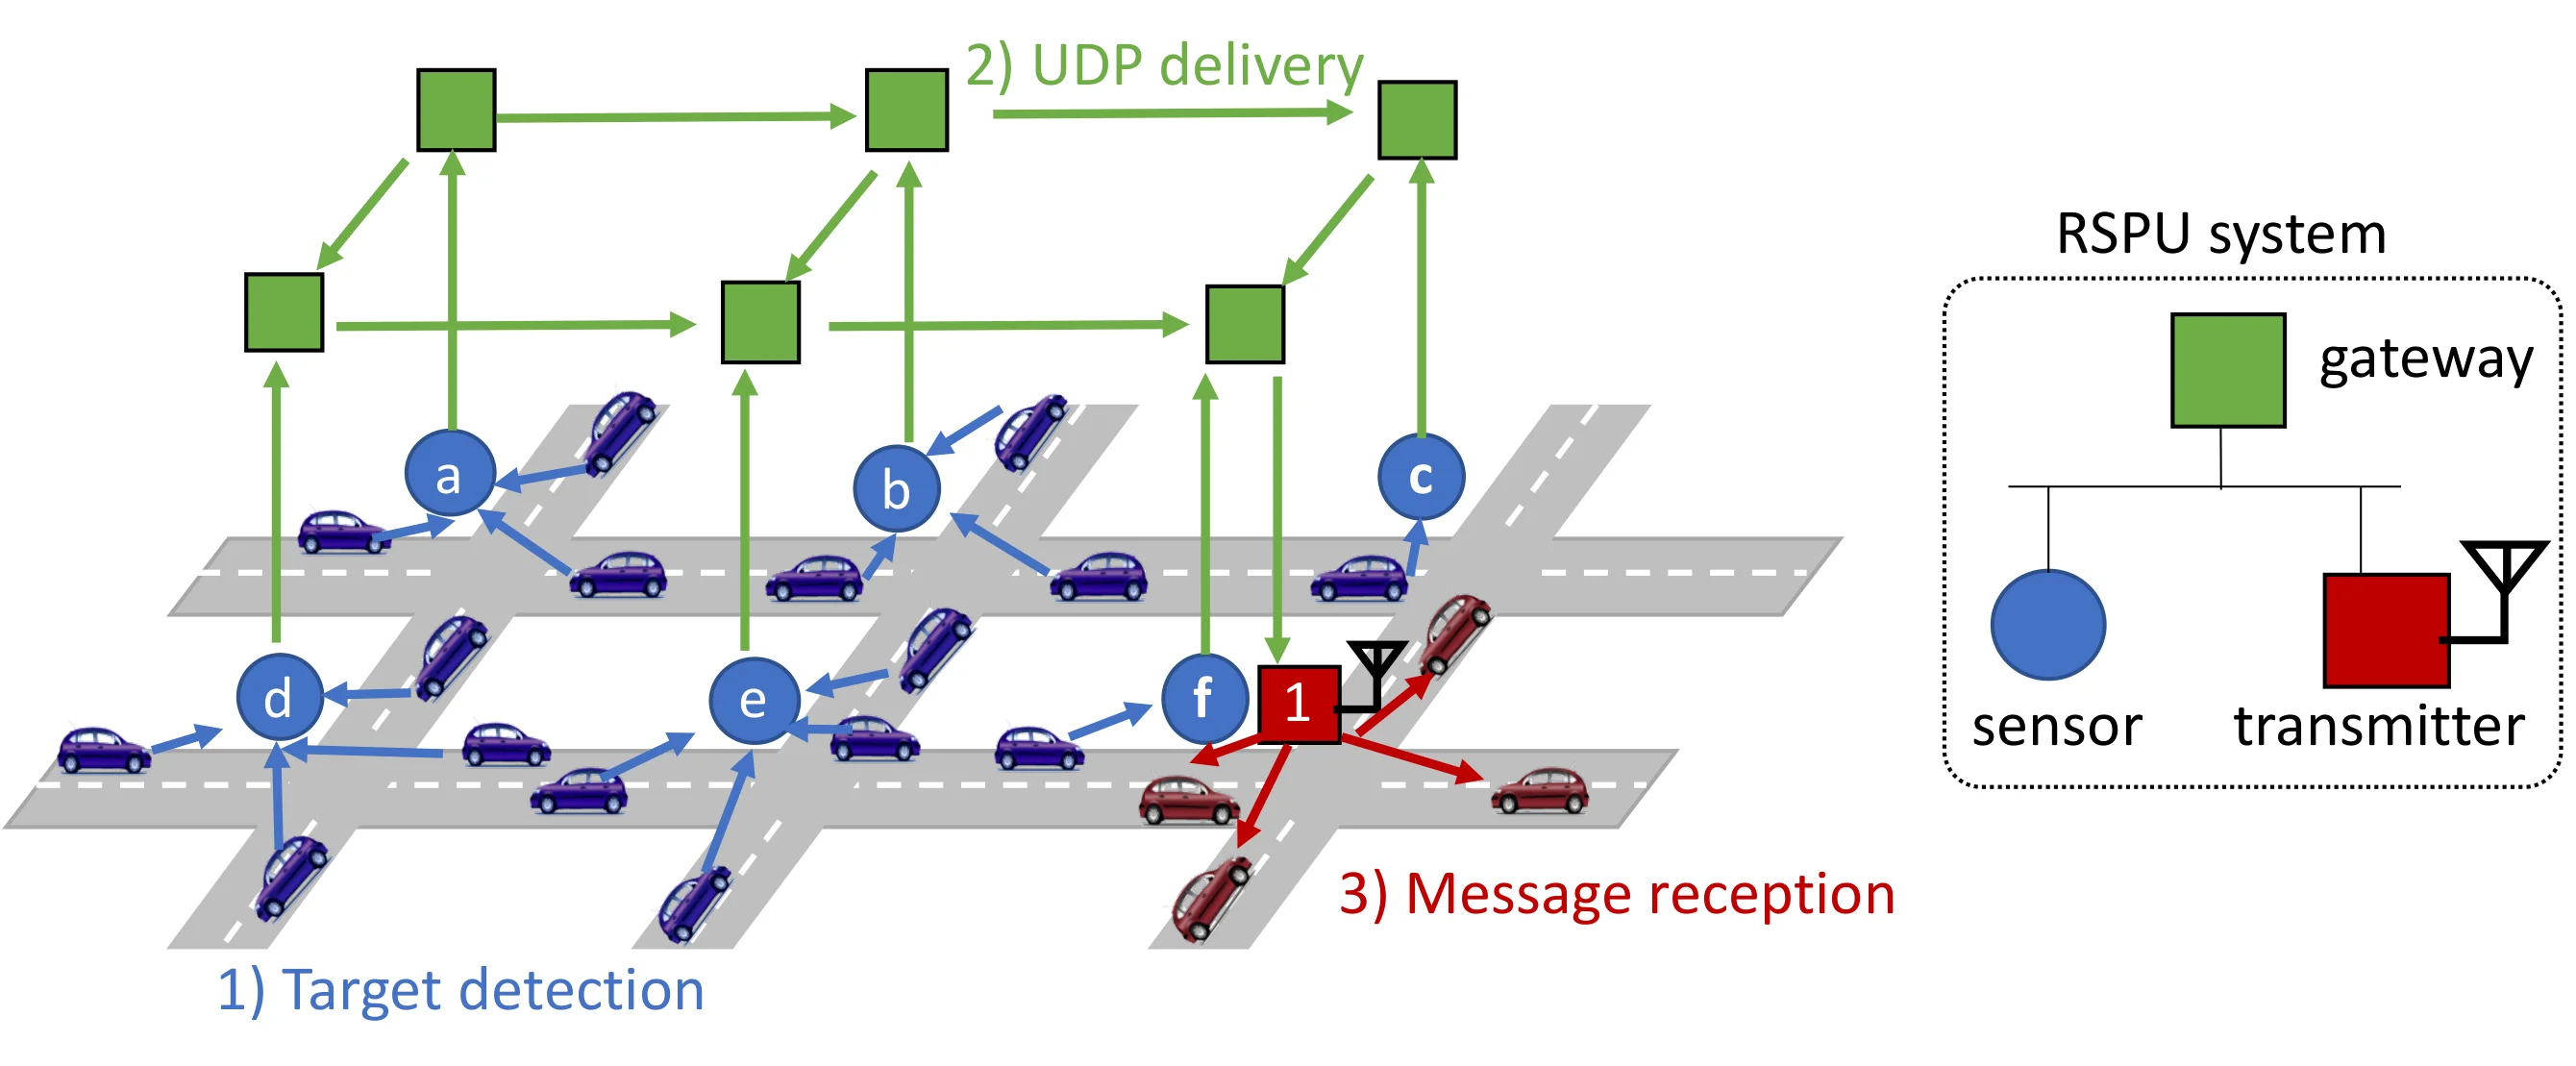
- 路側ユニットを有線網で結び、メッセージの優先制御で協調認識の範囲を広げた。
- 実地試験では100 ms以内にメッセージが届き、シミュレーションでは交通量が多い場合にも優先制御によって高い到達率と低遅延を保った。
論文の図
アブストラクト(原文)
Vehicle-to-Everything (V2X) communication enhances the capability of autonomous driving through better safety, efficiency, and comfort. In particular, sensor data sharing, known as cooperative perception, is a crucial technique to accommodate vulnerable road users in a cooperative intelligent transport system (ITS). In this paper, we describe a roadside perception unit (RSPU) that combines sensors and roadside units (RSUs) for infrastructure-based cooperative perception. We propose a software called AutoC2X that we designed to realize cooperative perception for RSPUs and vehicles. We also propose the concept of networked RSPUs, which is the inter-connection of RSPUs along a road over a wired network, and helps realize broader cooperative perception. We evaluated the RSPU system and the networked RSPUs through a field test, numerical analysis, and simulation experiments. Field evaluation showed that, even in the worst case, our RSPU system can deliver messages to an autonomous vehicle within 100 ms. The simulation result shows that the proposed priority algorithm achieves a wide perception range with a high delivery ratio and low latency, especially under heavy road traffic conditions.
動画
関連する研究・ソフトウェア
引用方法
M. Tsukada, T. Oi, M. Kitazawa, and H. Esaki, “Networked Roadside Perception Units for Autonomous Driving,” Sensors, vol. 20, no. 18, 2020, doi: 10.3390/s20185320.
BibTeX
@article{Tsukada2020b,
  title         = {Networked Roadside Perception Units for Autonomous Driving},
  author        = {Manabu Tsukada and Takaharu Oi and Masahiro Kitazawa and Hiroshi Esaki},
  url           = {https://www.mdpi.com/1424-8220/20/18/5320/pdf?.pdf https://youtu.be/n7gD0L7NDEM},
  doi           = {10.3390/s20185320},
  issn          = {1424-8220},
  year          = {2020},
  date          = {2020-09-17},
  urldate       = {2020-09-17},
  journal       = {Sensors},
  volume        = {20},
  number        = {18},
  abstract      = {Vehicle-to-Everything (V2X) communication enhances the capability of autonomous driving through better safety, efficiency, and comfort. In particular, sensor data sharing, known as cooperative perception, is a crucial technique to accommodate vulnerable road users in a cooperative intelligent transport system (ITS). In this paper, we describe a roadside perception unit (RSPU) that combines sensors and roadside units (RSUs) for infrastructure-based cooperative perception. We propose a software called AutoC2X that we designed to realize cooperative perception for RSPUs and vehicles. We also propose the concept of networked RSPUs, which is the inter-connection of RSPUs along a road over a wired network, and helps realize broader cooperative perception. We evaluated the RSPU system and the networked RSPUs through a field test, numerical analysis, and simulation experiments. Field evaluation showed that, even in the worst case, our RSPU system can deliver messages to an autonomous vehicle within 100 ms. The simulation result shows that the proposed priority algorithm achieves a wide perception range with a high delivery ratio and low latency, especially under heavy road traffic conditions.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {article}
}