
Enhancing Reliability in Infrastructure-based Collective Perception: A Dual-Channel Hybrid Delivery Approach with Real-Time Monitoring
IEEE Open Journal of Vehicular Technology, vol. 5, pp. 1124–1138, Aug 30, 2024
DOI: 10.1109/OJVT.2024.3443877
Summary in three lines
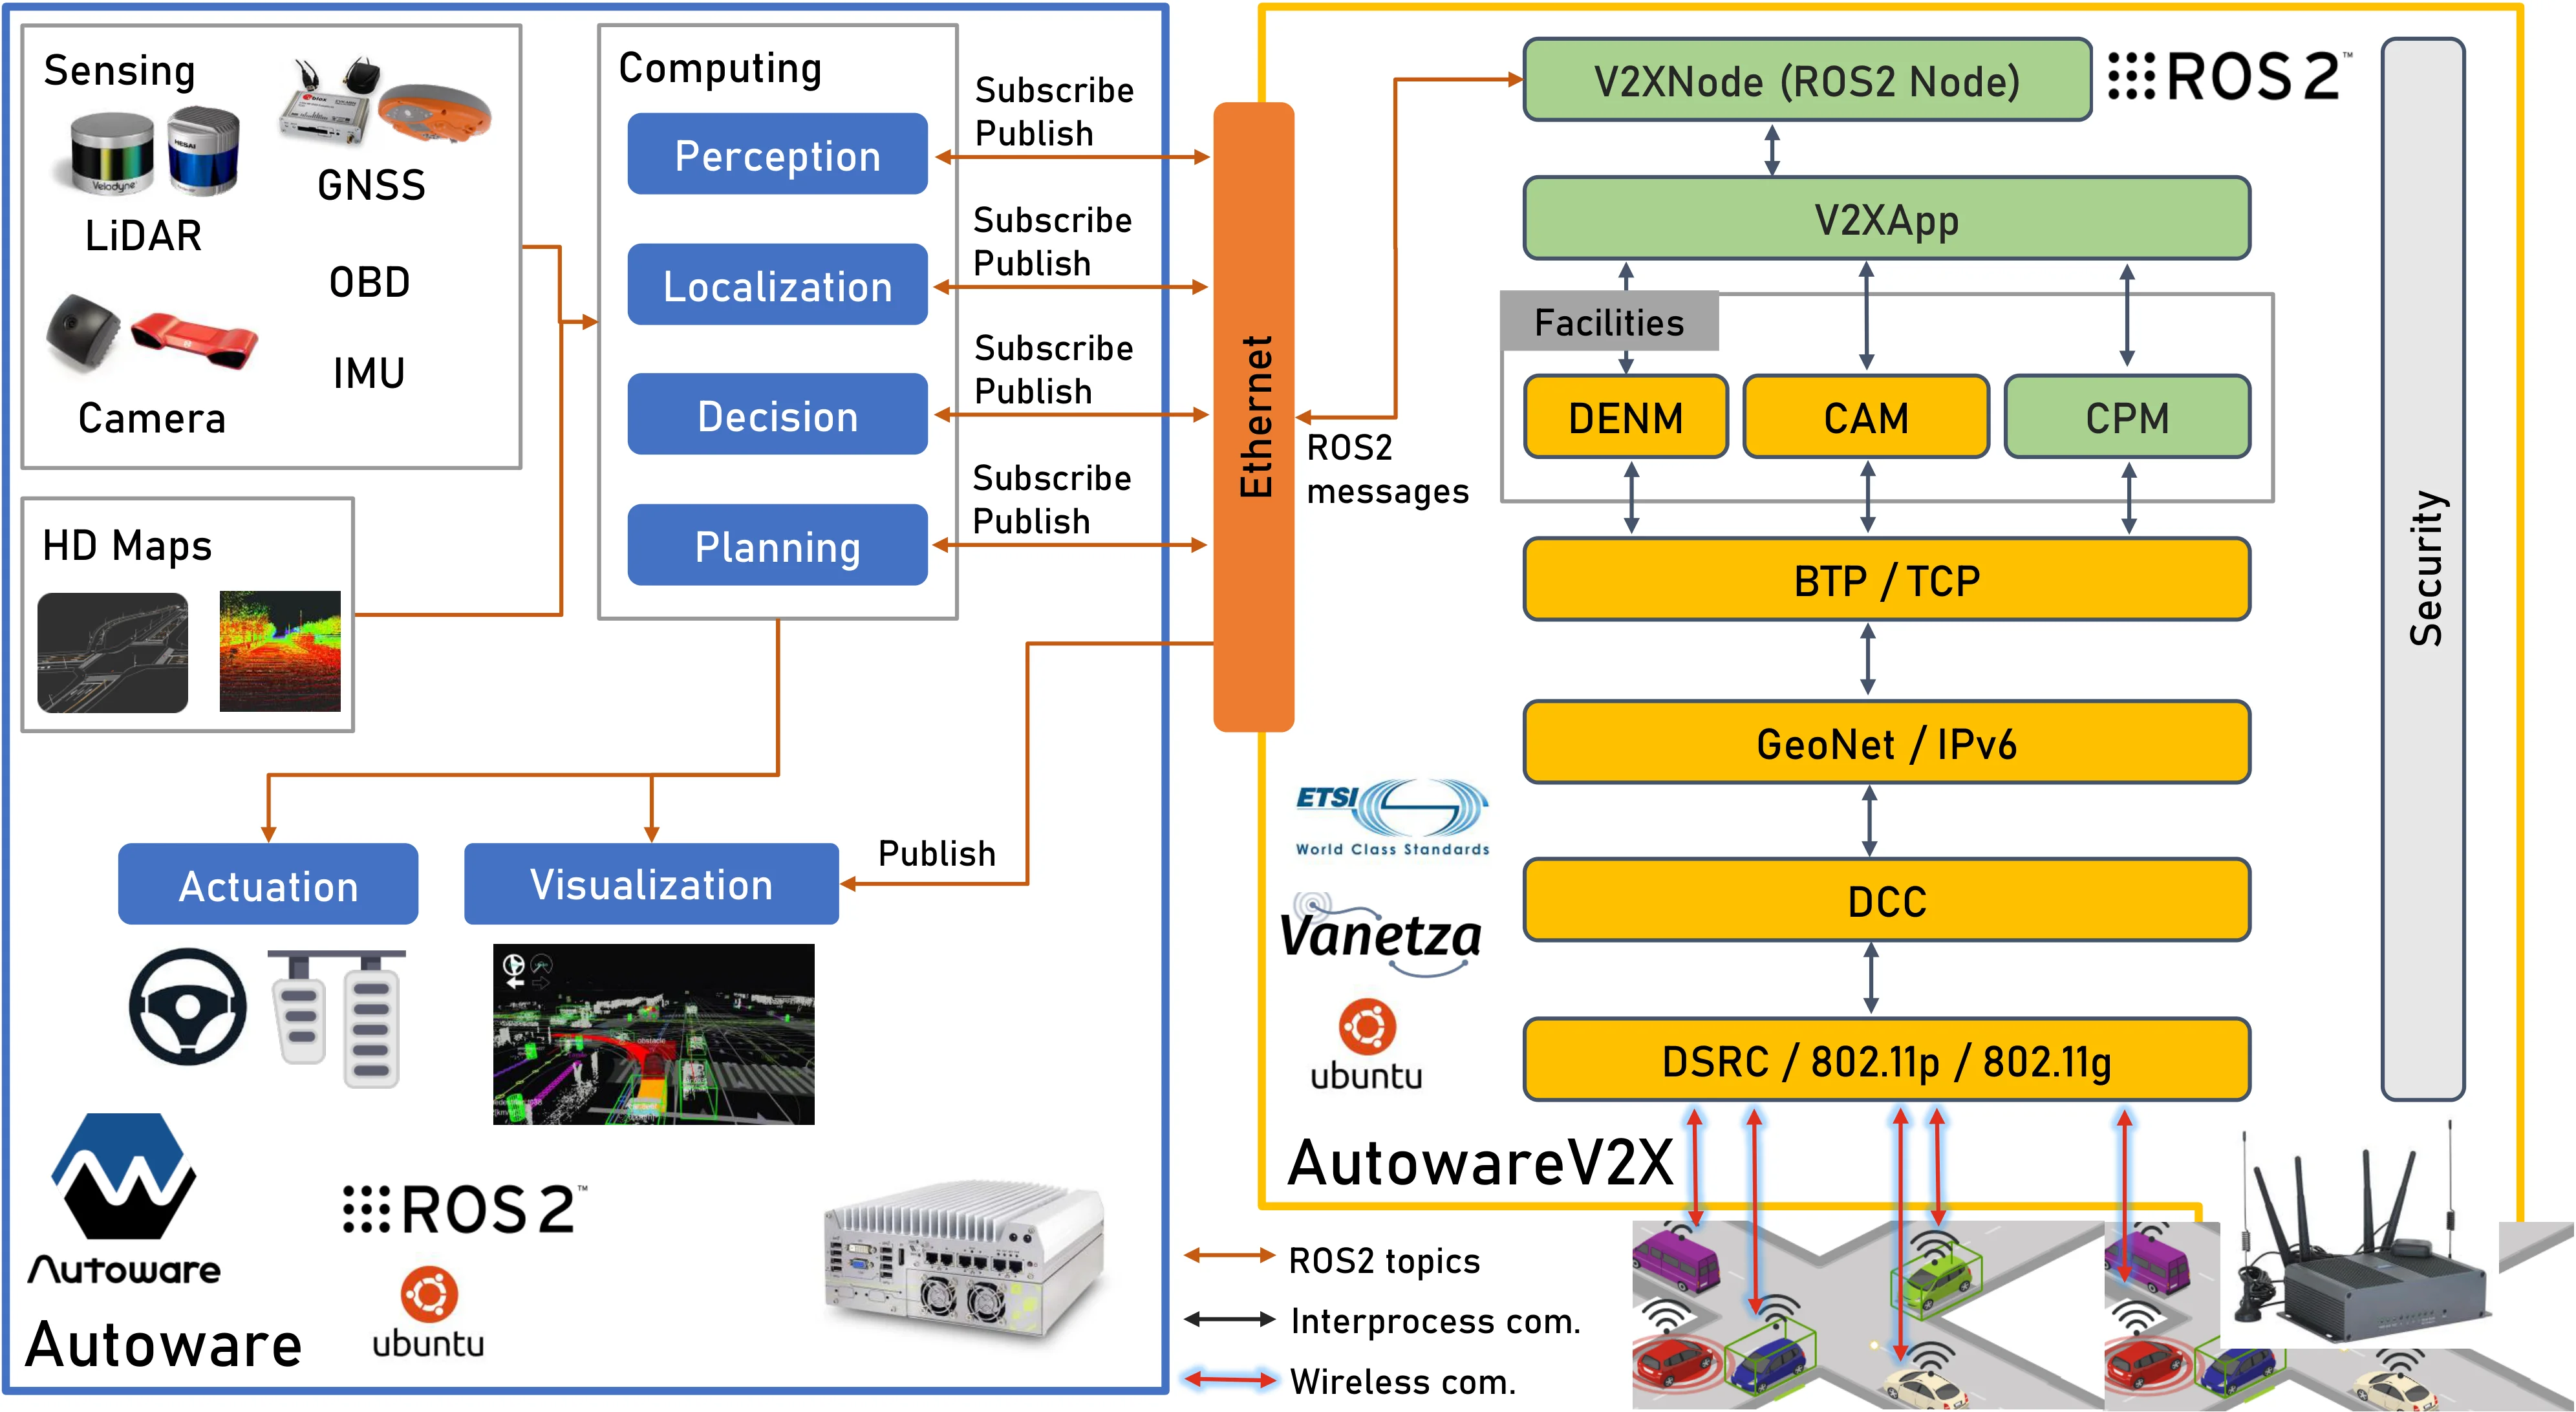
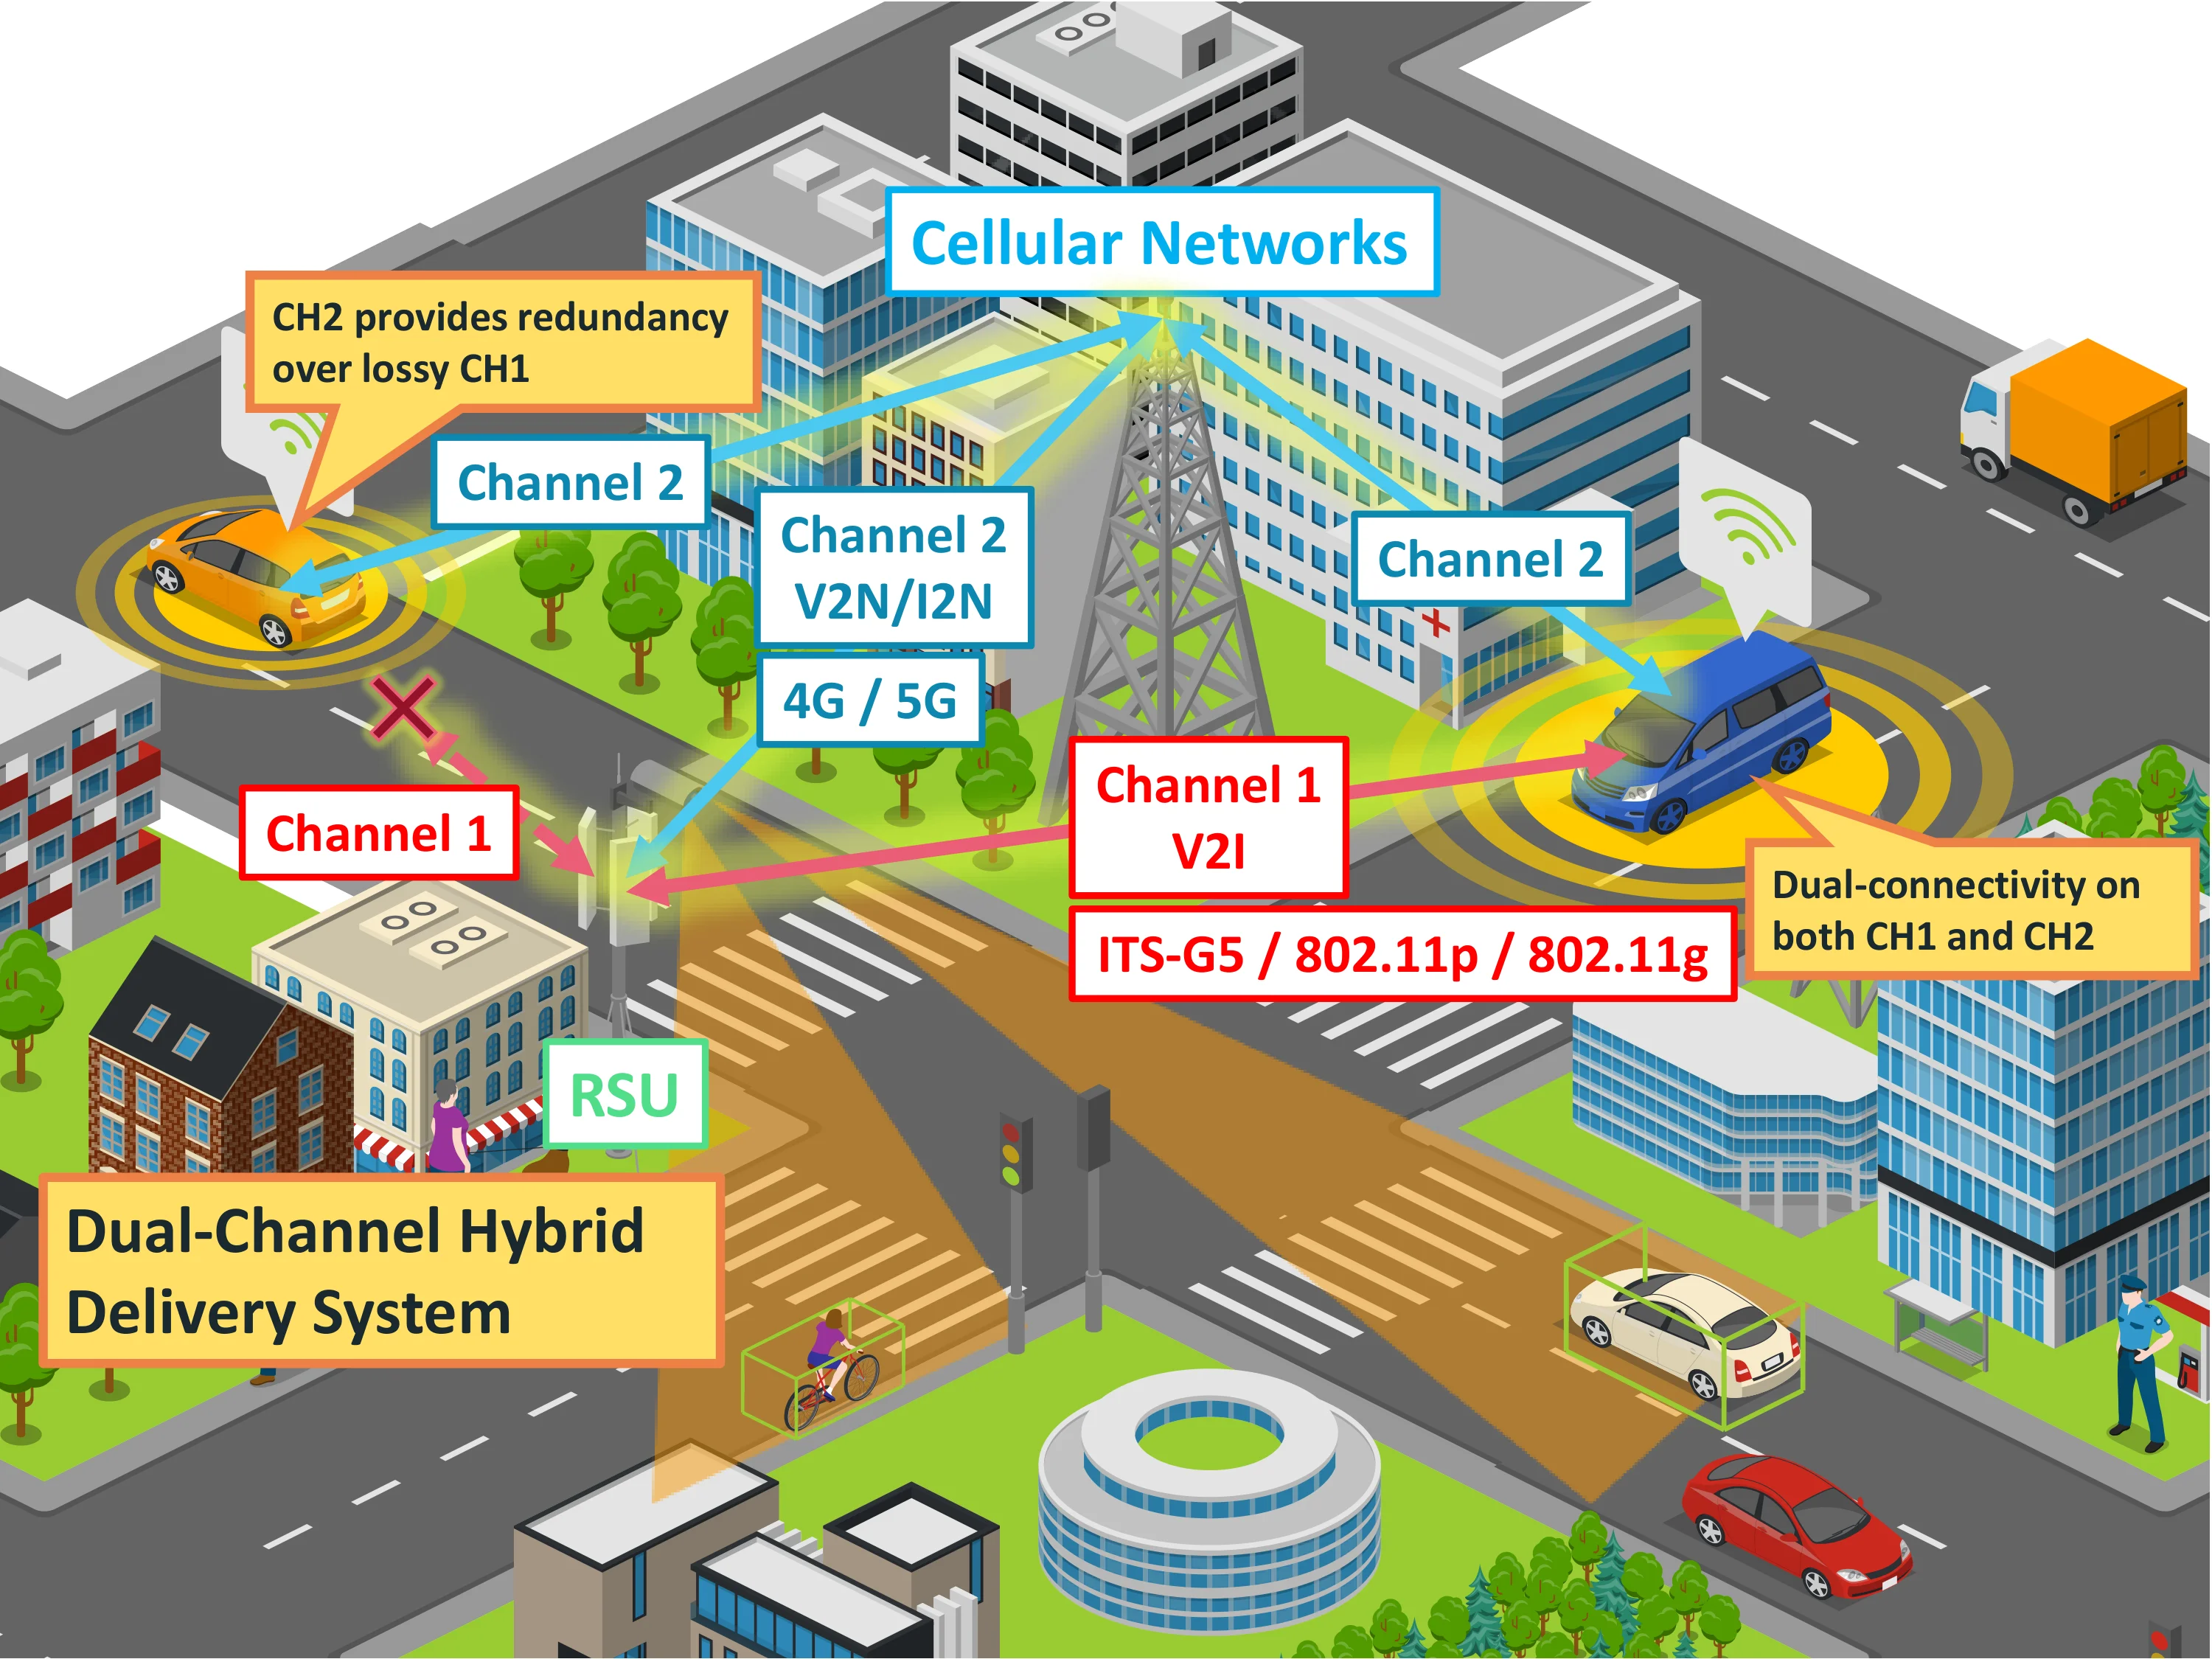
- Extends AutowareV2X (VTC2023-Spring) into a journal article and formalizes dual-channel hybrid delivery, which keeps the freshest Collective Perception Message by comparing ReferenceTime values.
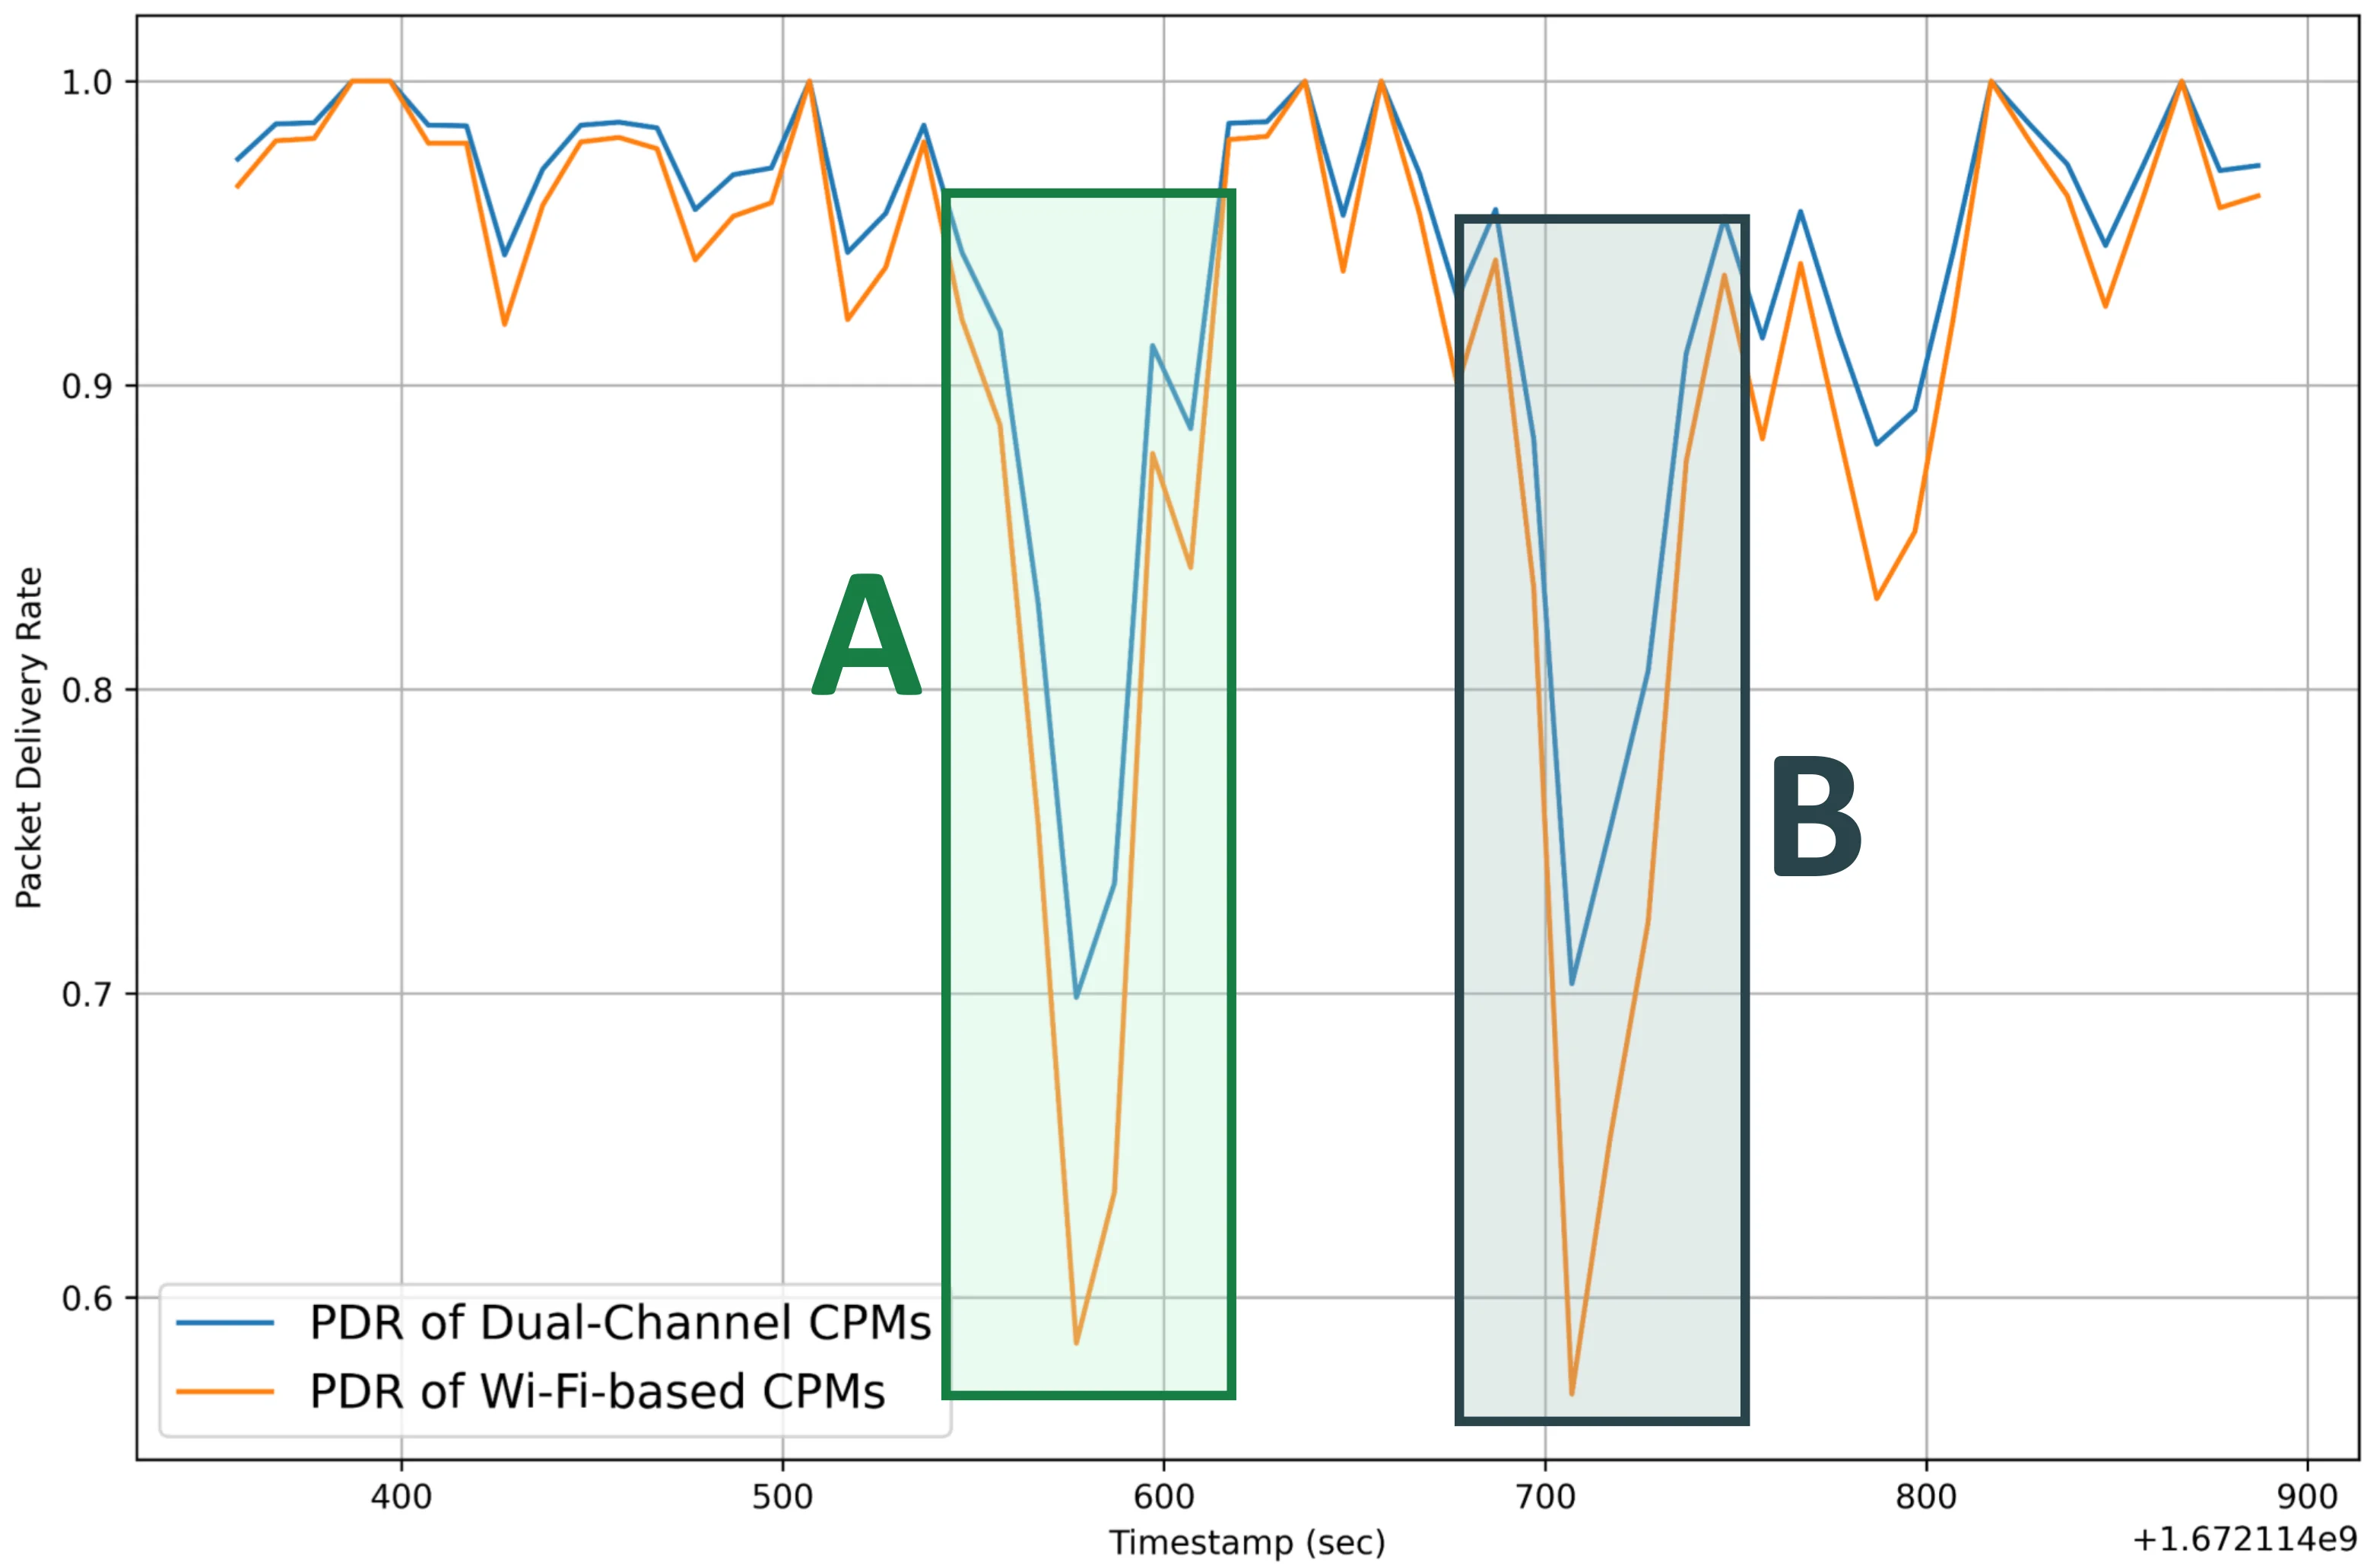
- Monitors the packet delivery rate (PDR) of messages from roadside units in real time; Wi-Fi PDR/RSSI and LTE acceptance-rate heatmaps show LTE filling in where one channel degrades.
- Dual-channel delivery clearly improves the PDR over Wi-Fi alone while keeping end-to-end latency at about 30 ms.
Figures from the paper
Abstract
Standalone autonomous vehicles primarily rely on their onboard sensors and may have blind spots or limited situational awareness in complex or dynamic traffic scenarios, leading to difficulties in making safe decisions. Collective perception enables connected autonomous vehicles (CAVs) to overcome the limitations of standalone autonomous vehicles by sharing sensory information with nearby road users. However, unfavorable conditions of the wireless communication medium it uses can lead to limited reliability and reduced quality of service. In this paper, we propose methods for increasing the reliability of collective perception through real-time packet delivery rate monitoring and a dual-channel hybrid delivery approach. We have implemented AutowareV2X, a vehicle-to-everything (V2X) communication module integrated into the autonomous driving (AD) software Autoware. AutowareV2X provides connectivity to the AD stack, enabling end-to-end (E2E) experimentation and evaluation of CAVs. The Collective Perception Service (CPS) was also implemented, allowing the transmission of Collective Perception Messages (CPMs). Our proposed methods using AutowareV2X were evaluated using actual hardware and vehicles in reallife field tests. Results have indicated that the E2E network latency of the perception information sent is around 30 ms, and the AD software can use shared object data to conduct collision avoidance maneuvers. The dual-channel delivery of CPMs enabled the CAV to dynamically select the best CPM from CPMs received from different links, depending on the freshness of their information. This enabled the reliable transmission of CPMs even when there was significant packet loss on one of the transmitting channels.
Video
Code
Related research and software
How to cite
Y. Asabe, E. Javanmardi, J. Nakazato, M. Tsukada, and H. Esaki, “Enhancing Reliability in Infrastructure-based Collective Perception: A Dual-Channel Hybrid Delivery Approach with Real-Time Monitoring,” IEEE Open Journal of Vehicular Technology, vol. 5, pp. 1124–1138, 2024, doi: 10.1109/OJVT.2024.3443877.
BibTeX
@article{Asabe2024,
  title         = {Enhancing Reliability in Infrastructure-based Collective Perception: A Dual-Channel Hybrid Delivery Approach with Real-Time Monitoring},
  author        = {Yu Asabe and Ehsan Javanmardi and Jin Nakazato and Manabu Tsukada and Hiroshi Esaki},
  doi           = {10.1109/OJVT.2024.3443877},
  issn          = {2644-1330},
  year          = {2024},
  date          = {2024-08-30},
  urldate       = {2024-08-30},
  journal       = {IEEE Open Journal of Vehicular Technology},
  volume        = {5},
  pages         = {1124--1138},
  abstract      = {Standalone autonomous vehicles primarily rely on their onboard sensors and may have blind spots or limited situational awareness in complex or dynamic traffic scenarios, leading to difficulties in making safe decisions. Collective perception enables connected autonomous vehicles (CAVs) to overcome the limitations of standalone autonomous vehicles by sharing sensory information with nearby road users. However, unfavorable conditions of the wireless communication medium it uses can lead to limited reliability and reduced quality of service. In this paper, we propose methods for increasing the reliability of collective perception through real-time packet delivery rate monitoring and a dual-channel hybrid delivery approach. We have implemented AutowareV2X, a vehicle-to-everything (V2X) communication module integrated into the autonomous driving (AD) software Autoware. AutowareV2X provides connectivity to the AD stack, enabling end-to-end (E2E) experimentation and evaluation of CAVs. The Collective Perception Service (CPS) was also implemented, allowing the transmission of Collective Perception Messages (CPMs). Our proposed methods using AutowareV2X were evaluated using actual hardware and vehicles in reallife field tests. Results have indicated that the E2E network latency of the perception information sent is around 30 ms, and the AD software can use shared object data to conduct collision avoidance maneuvers. The dual-channel delivery of CPMs enabled the CAV to dynamically select the best CPM from CPMs received from different links, depending on the freshness of their information. This enabled the reliable transmission of CPMs even when there was significant packet loss on one of the transmitting channels.},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {article}
}