
Reinforcement Learning Based Optimal Camera Placement for Depth Observation of Indoor Scenes
Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki Lab), Sep 30, 2021
Summary in three lines
- The thesis defines RL-OCP, a system that moves indoor depth cameras to improve its observations as it learns about a scene.
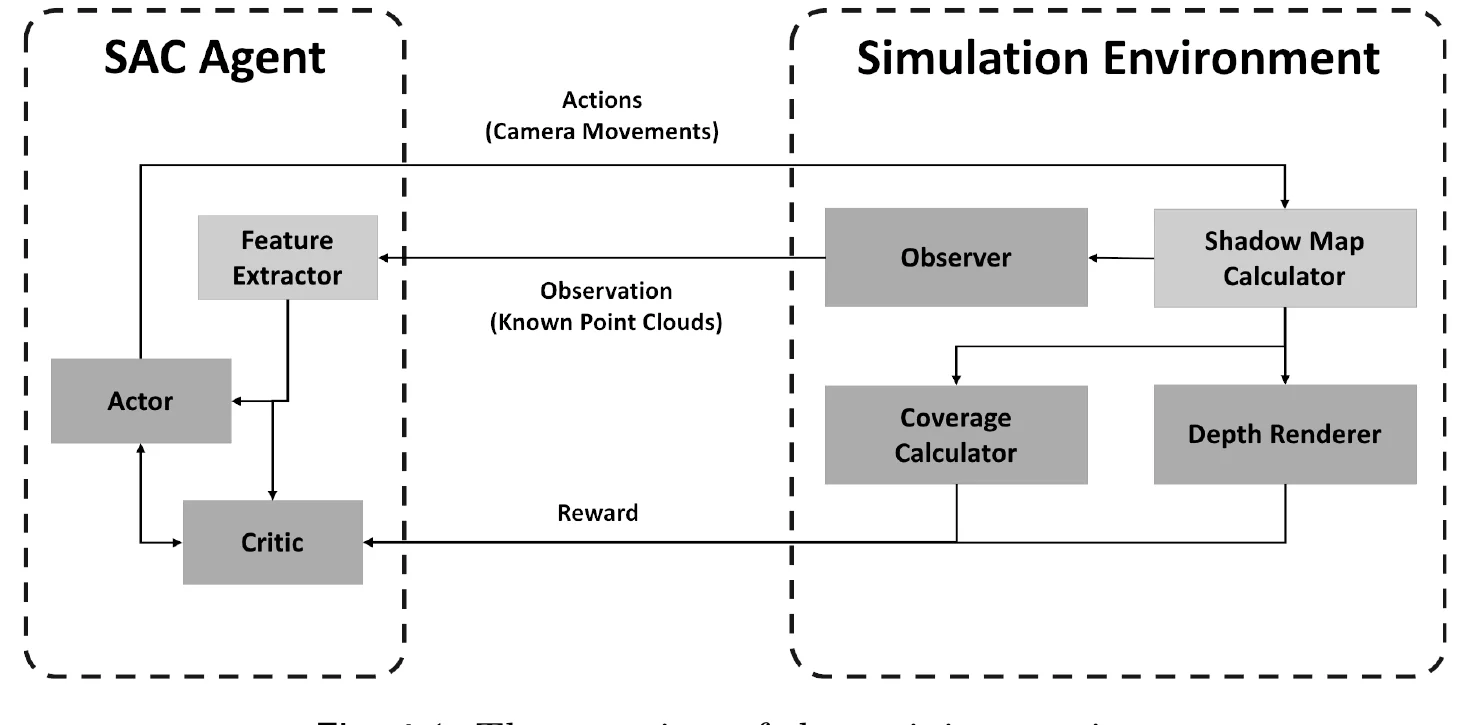
- It develops a simulator that uses shadow maps to estimate visibility, coverage and depth error, and learns camera movements with Soft Actor-Critic.
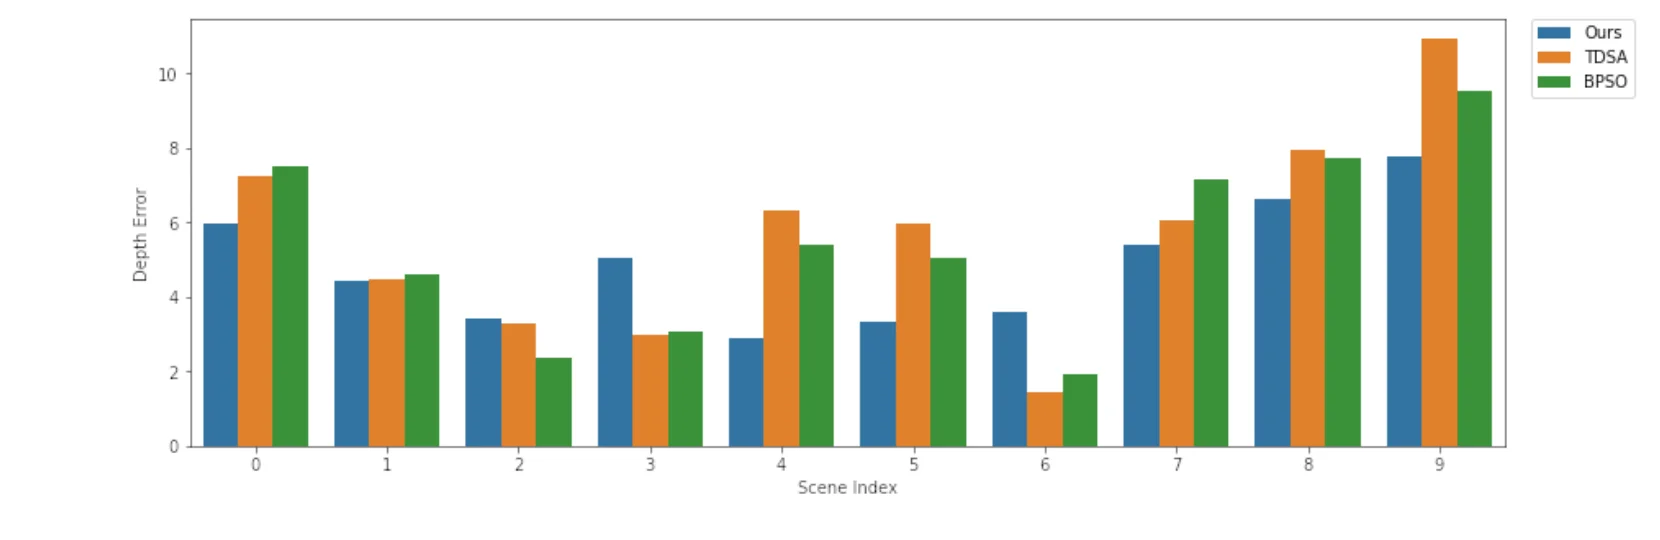
- In ten test scenes, the method lowered error in seven and kept total depth error below 90% of the offline baselines.
Figures from the paper
How to cite
Y. Chen, “Reinforcement Learning Based Optimal Camera Placement for Depth Observation of Indoor Scenes,” in Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki Lab), 2021.
BibTeX
@mastersthesis{Chen2021b,
  title         = {Reinforcement Learning Based Optimal Camera Placement for Depth Observation of Indoor Scenes},
  author        = {Yichuan Chen},
  year          = {2021},
  date          = {2021-09-30},
  urldate       = {2021-09-30},
  school        = {Master Thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki Lab)},
  keywords      = {SDM, Thesis},
  pubstate      = {published},
  tppubtype     = {mastersthesis}
}