
Towards Robust LiDAR Localization: Deep Learning-based Uncertainty Estimation
, Sep 23, 2025
Summary in three lines
- LiDAR scan matching can become unreliable in scenes with sparse features or moving objects.
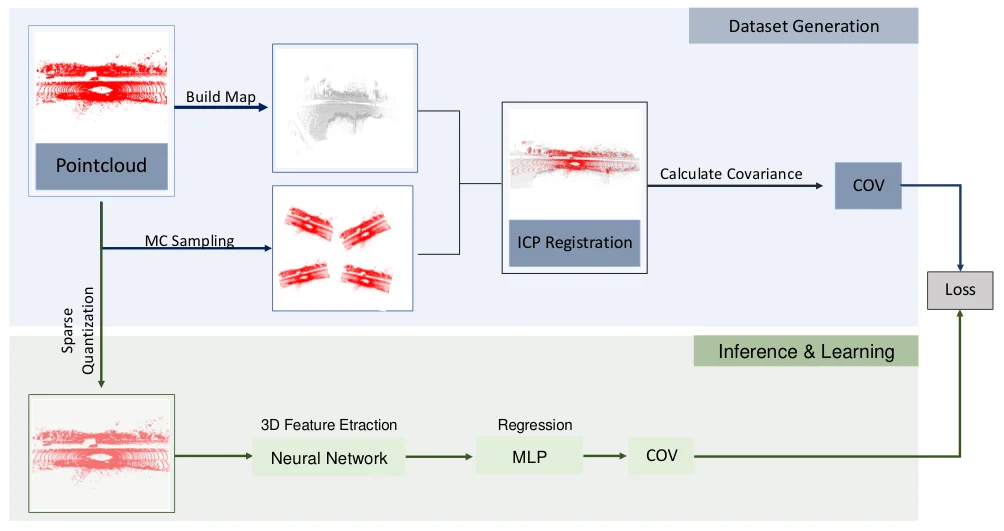
- A deep model estimates the six-degree-of-freedom ICP error covariance before matching, even without a reference map.
- Using the covariance in a Kalman filter reduced localization errors on KITTI in map-based localization and SLAM.
Figures from the paper
How to cite
M. Dolatabadi, F. Ayar, E. Javanmardi, M. Tsukada, and M. Javanmardi, “Towards Robust LiDAR Localization: Deep Learning-based Uncertainty Estimation,” in , 2025.
BibTeX
@unpublished{Dolatabadi2025,
  title         = {Towards Robust LiDAR Localization: Deep Learning-based Uncertainty Estimation},
  author        = {Minoo Dolatabadi and Fardin Ayar and Ehsan Javanmardi and Manabu Tsukada and Mahdi Javanmardi},
  year          = {2025},
  date          = {2025-09-23},
  eprint        = {2509.18954},
  archiveprefix = {arXiv},
  primaryclass  = {cs.RO},
  url           = {https://arxiv.org/abs/2509.18954},
  note          = {Preprint}
}