
Maneuver coordination service with abstracted functions for cooperative autonomous driving
Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki and Ochiai Lab), Mar 31, 2021
Summary in three lines
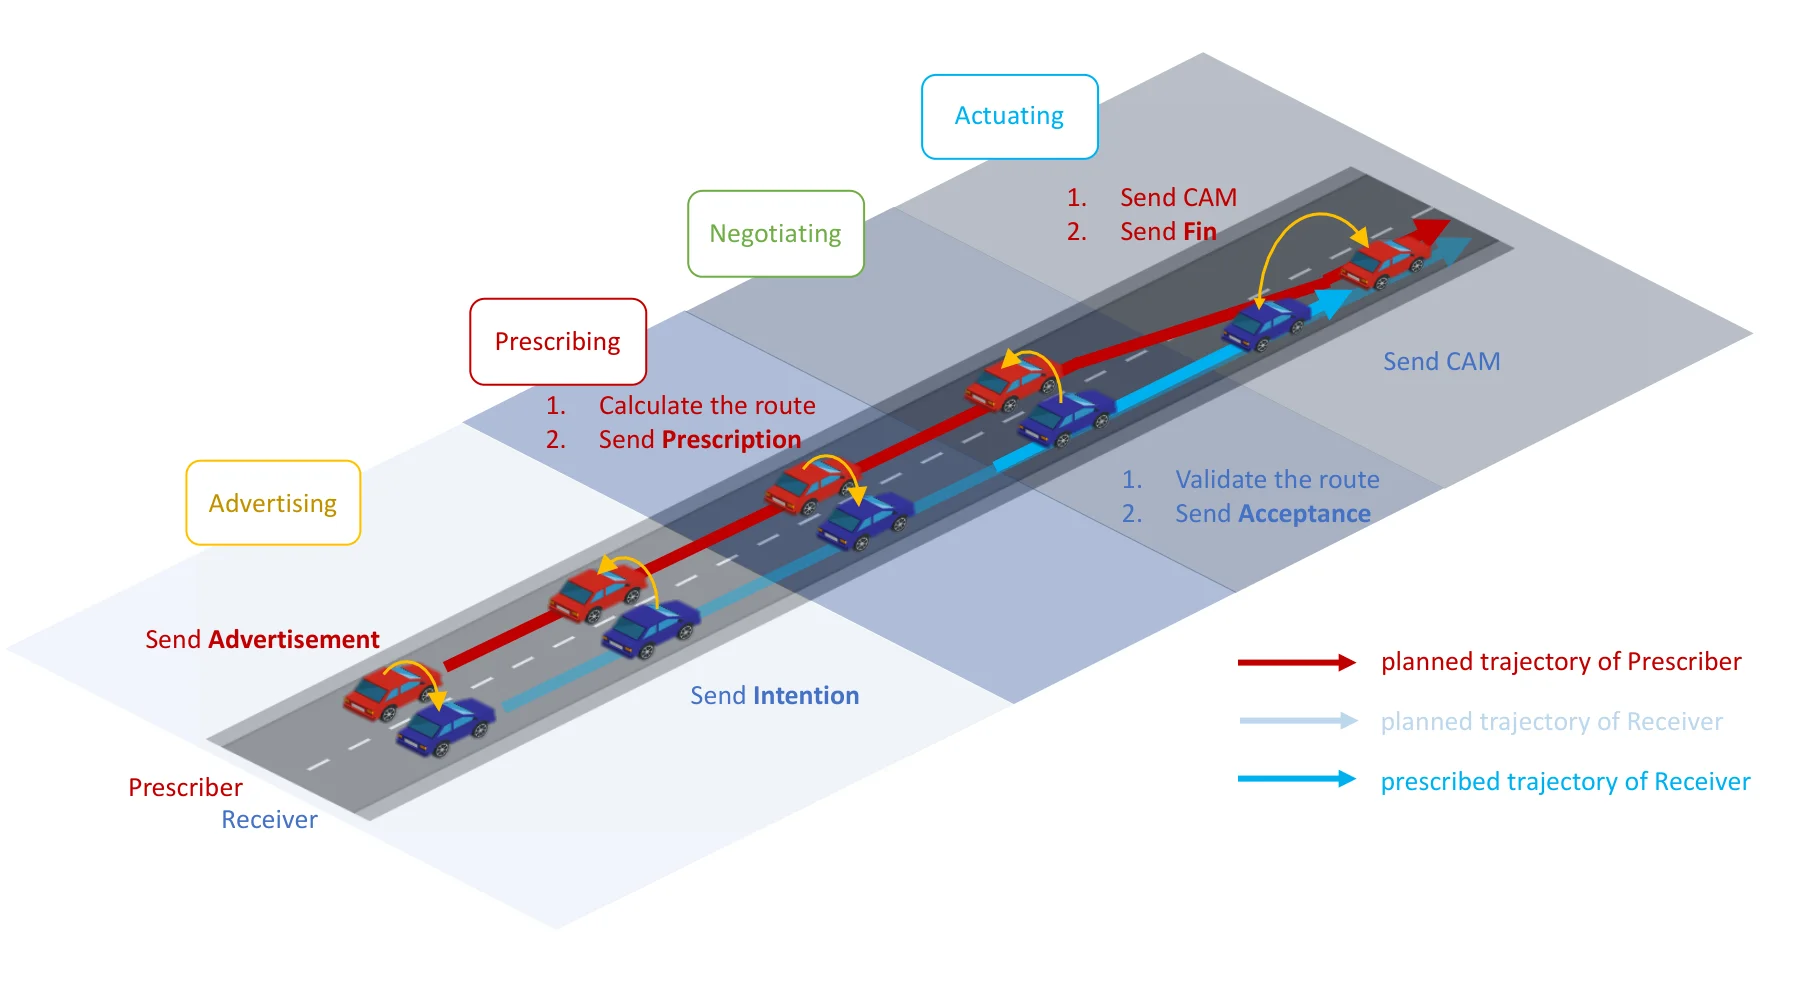
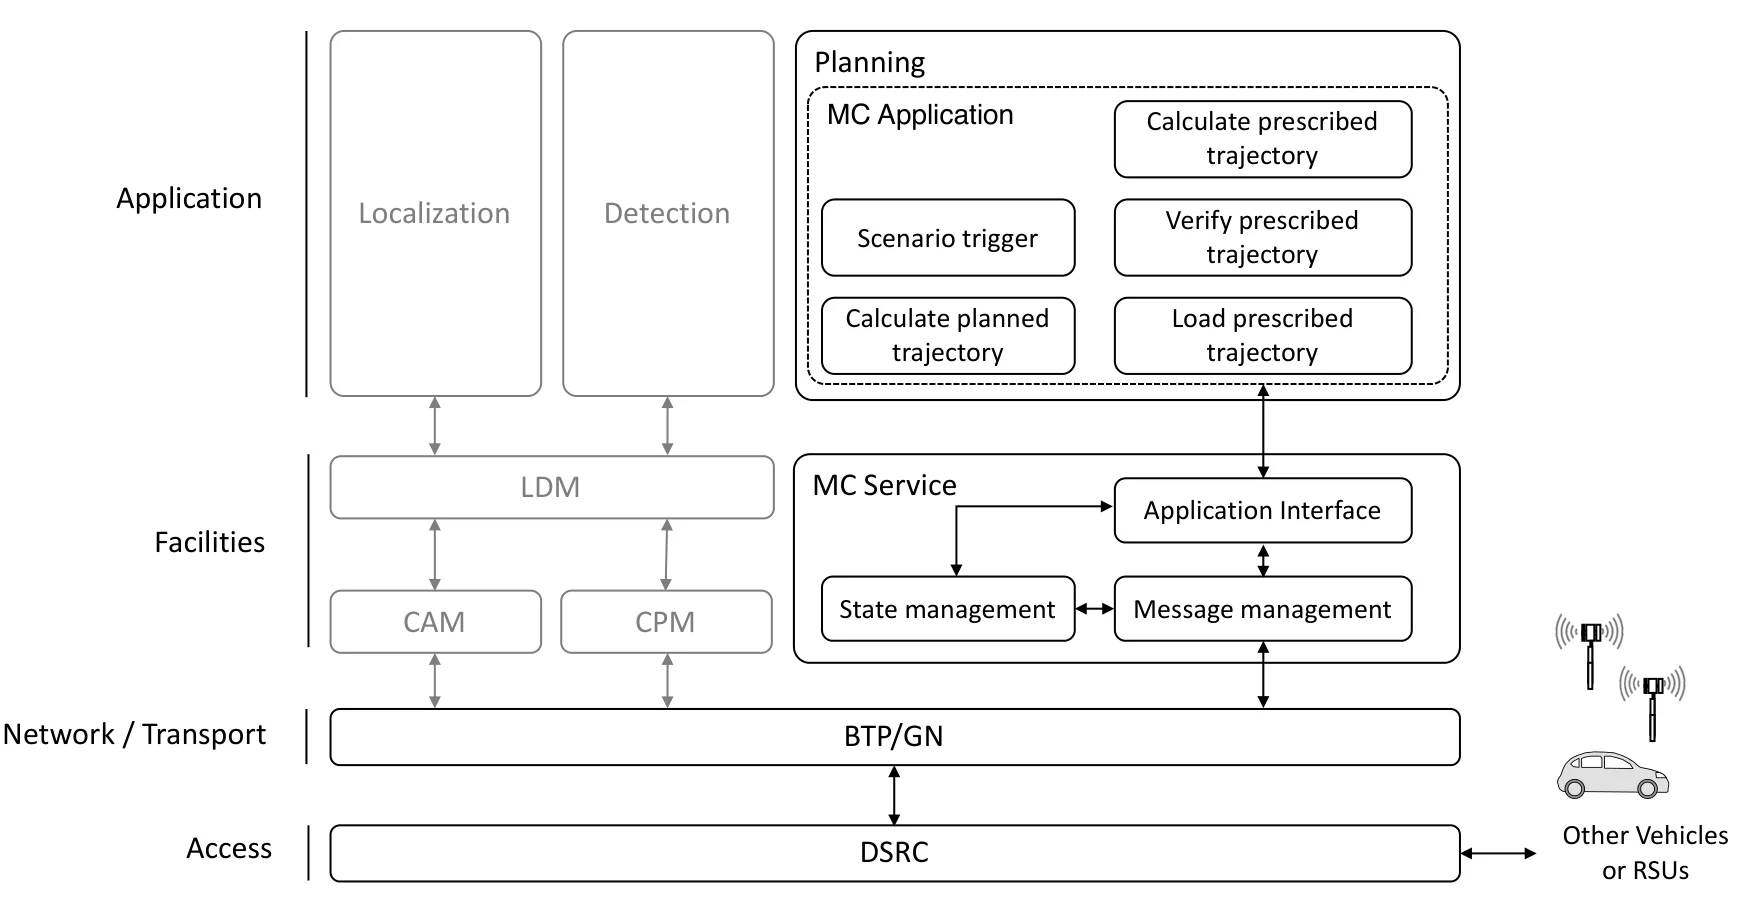
- The thesis proposes a maneuver coordination service for connected automated driving with an abstracted set of functions.
- It implements the coordination messages and functions by extending open-source automated driving and V2X software.
- The evaluation examines communication volume, execution time and the effect of coordination on traffic flow.
Figures from the paper
How to cite
M. Mizutani, “Maneuver coordination service with abstracted functions for cooperative autonomous driving,” in Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki and Ochiai Lab), 2021.
BibTeX
@mastersthesis{Mizutani2021,
  title     = {Maneuver coordination service with abstracted functions for cooperative autonomous driving},
  author    = {Masaya Mizutani},
  year      = {2021},
  date      = {2021-03-31},
  urldate   = {2021-03-31},
  school    = {Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki and Ochiai Lab)},
  keywords  = {ITS, Thesis},
  pubstate  = {published},
  tppubtype = {mastersthesis}
}