
Infrastructure-aided cooperative perception for connected autonomous vehicles
Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki and Ochiai Lab), Mar 31, 2020
Summary in three lines
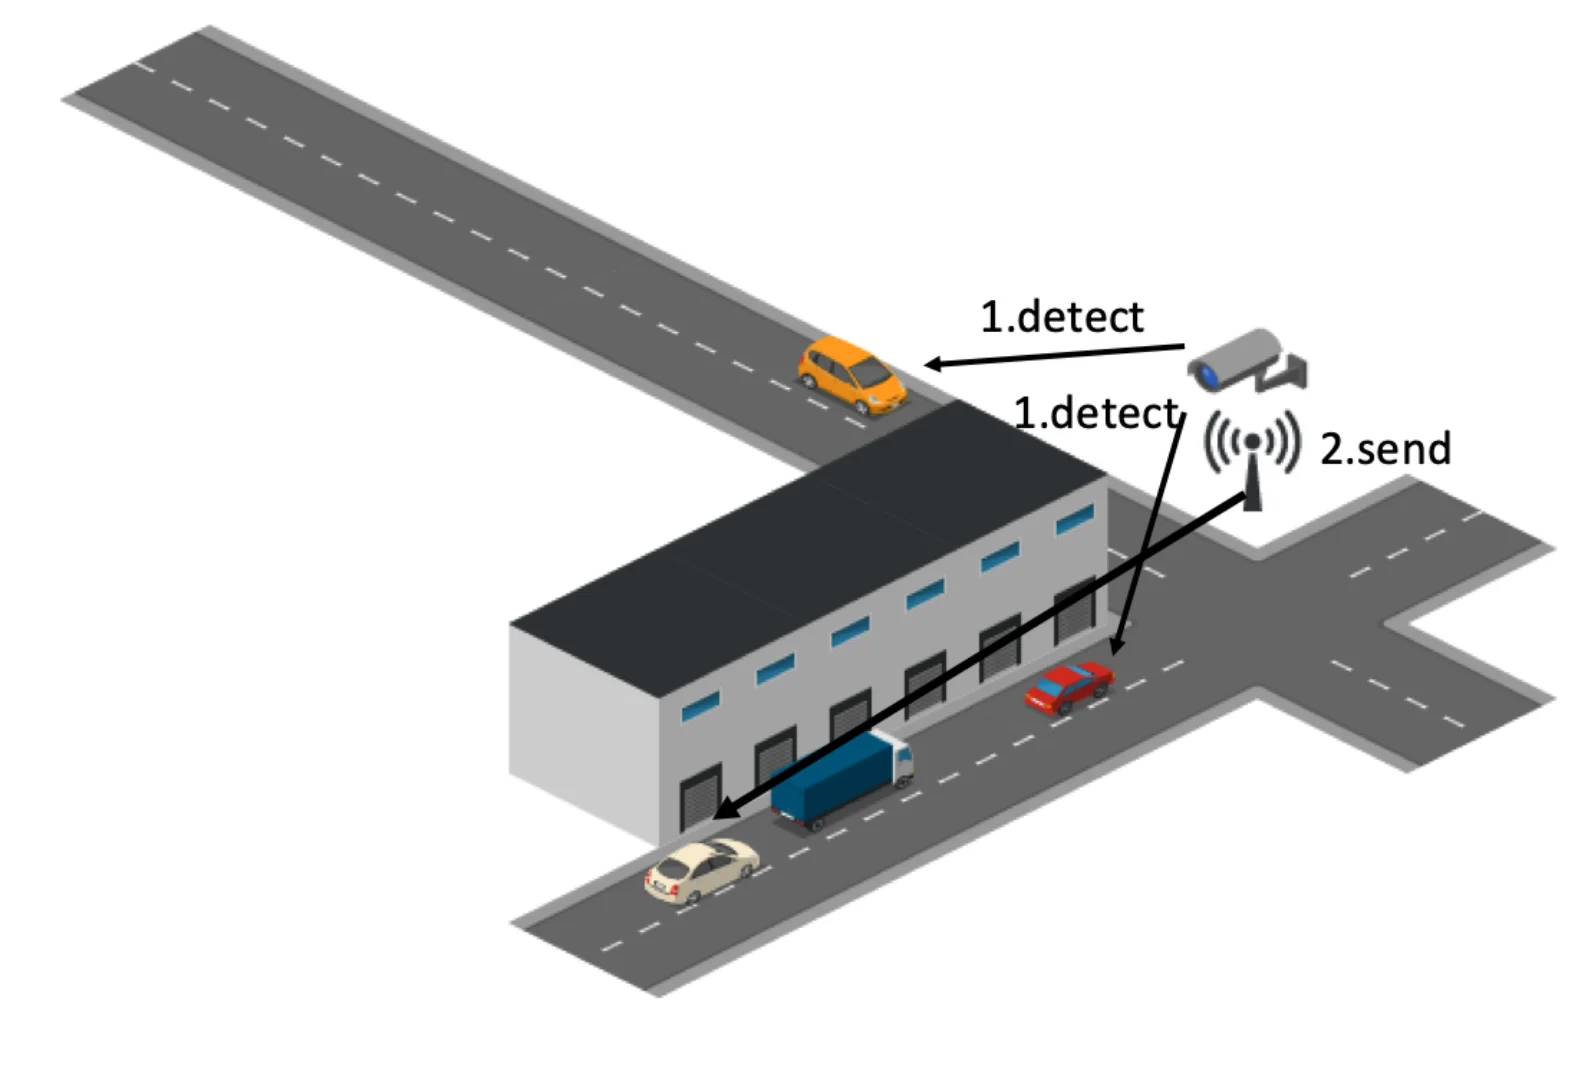
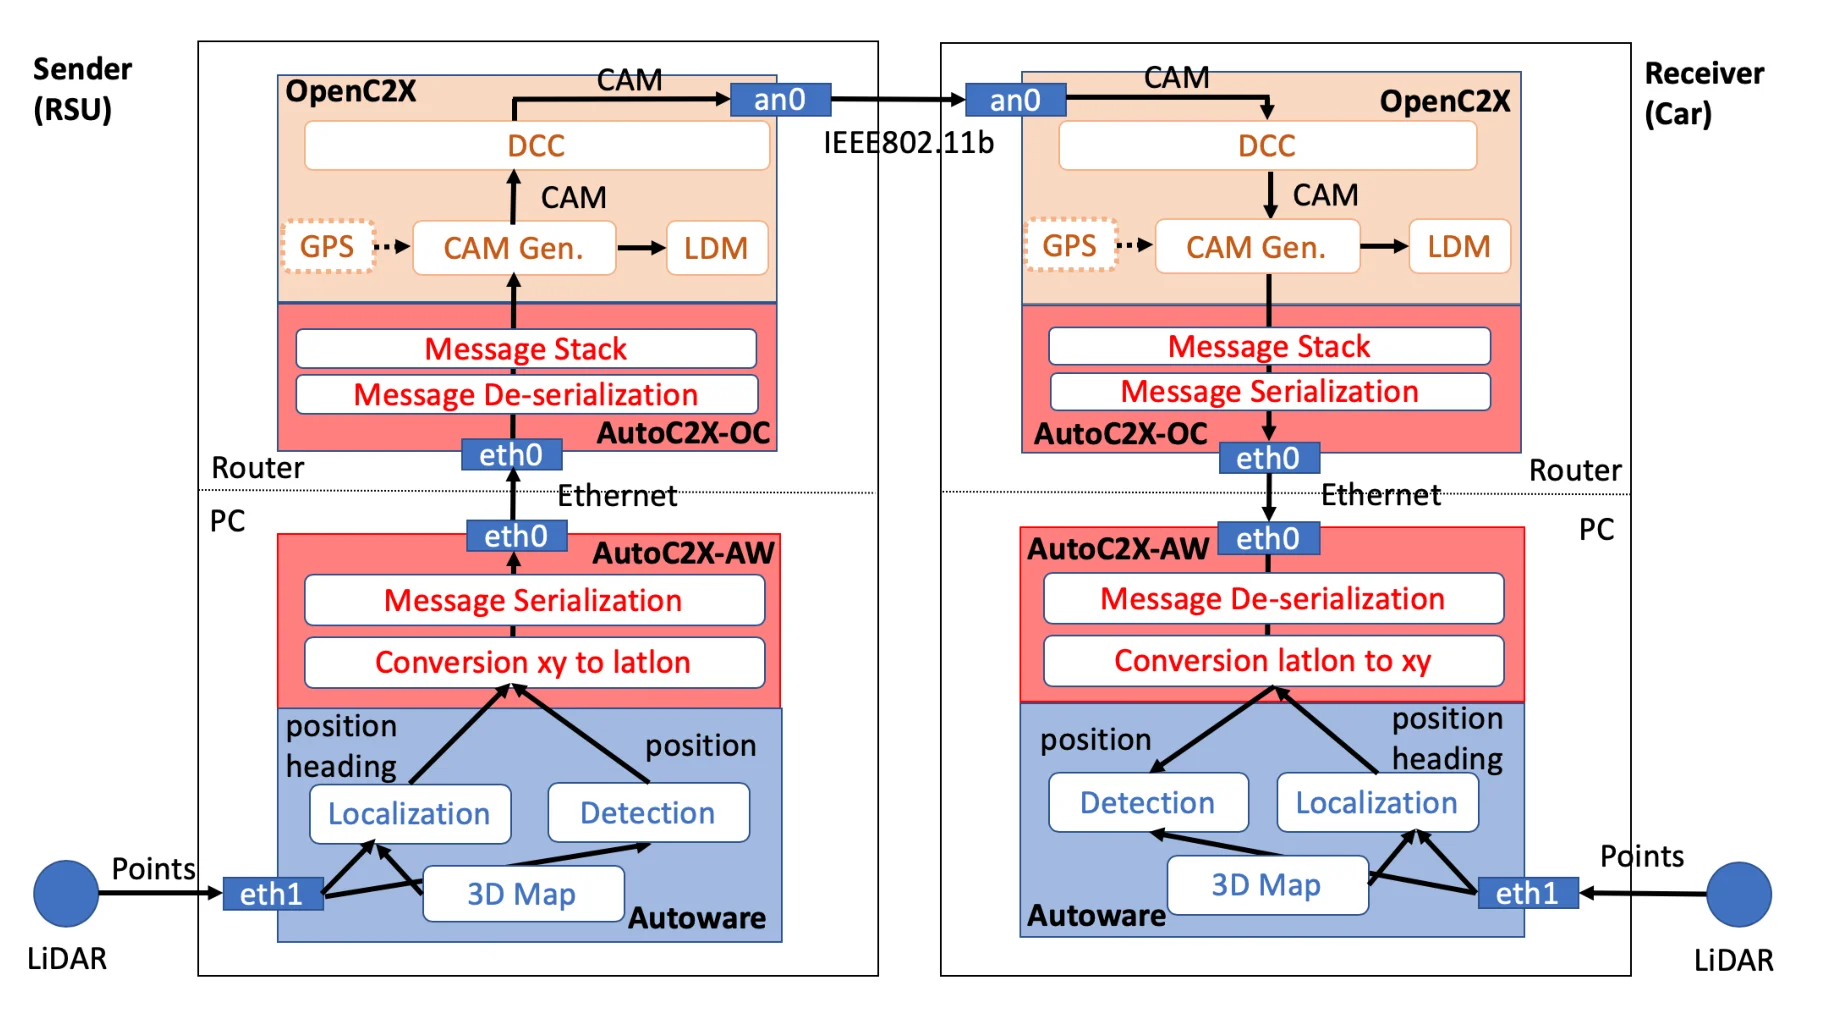
- The thesis integrates Autoware and OpenC2X to extend an automated vehicle's perception with roadside sensing.
- The AutoC2X prototype sends roadside object detections to the vehicle and displays them alongside local observations.
- In indoor and outdoor tests, most detections were delivered within the 100 ms CAM generation interval.
Figures from the paper
How to cite
T. Oi, “Infrastructure-aided cooperative perception for connected autonomous vehicles,” in Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki and Ochiai Lab), 2020.
BibTeX
@mastersthesis{Oi2020,
  title     = {Infrastructure-aided cooperative perception for connected autonomous vehicles},
  author    = {Takaharu Oi},
  url       = {https://tlab.hongo.wide.ad.jp/papers/2020_M_Oi.pdf},
  year      = {2020},
  date      = {2020-03-31},
  school    = {Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo (Esaki and Ochiai Lab)},
  keywords  = {ITS, Thesis},
  pubstate  = {published},
  tppubtype = {mastersthesis}
}