
Fairness-aware Cooperative Path Planning for Efficient Traffic Flow of Connected and Autonomous Vehicles
Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo, Sep 30, 2021
Summary in three lines
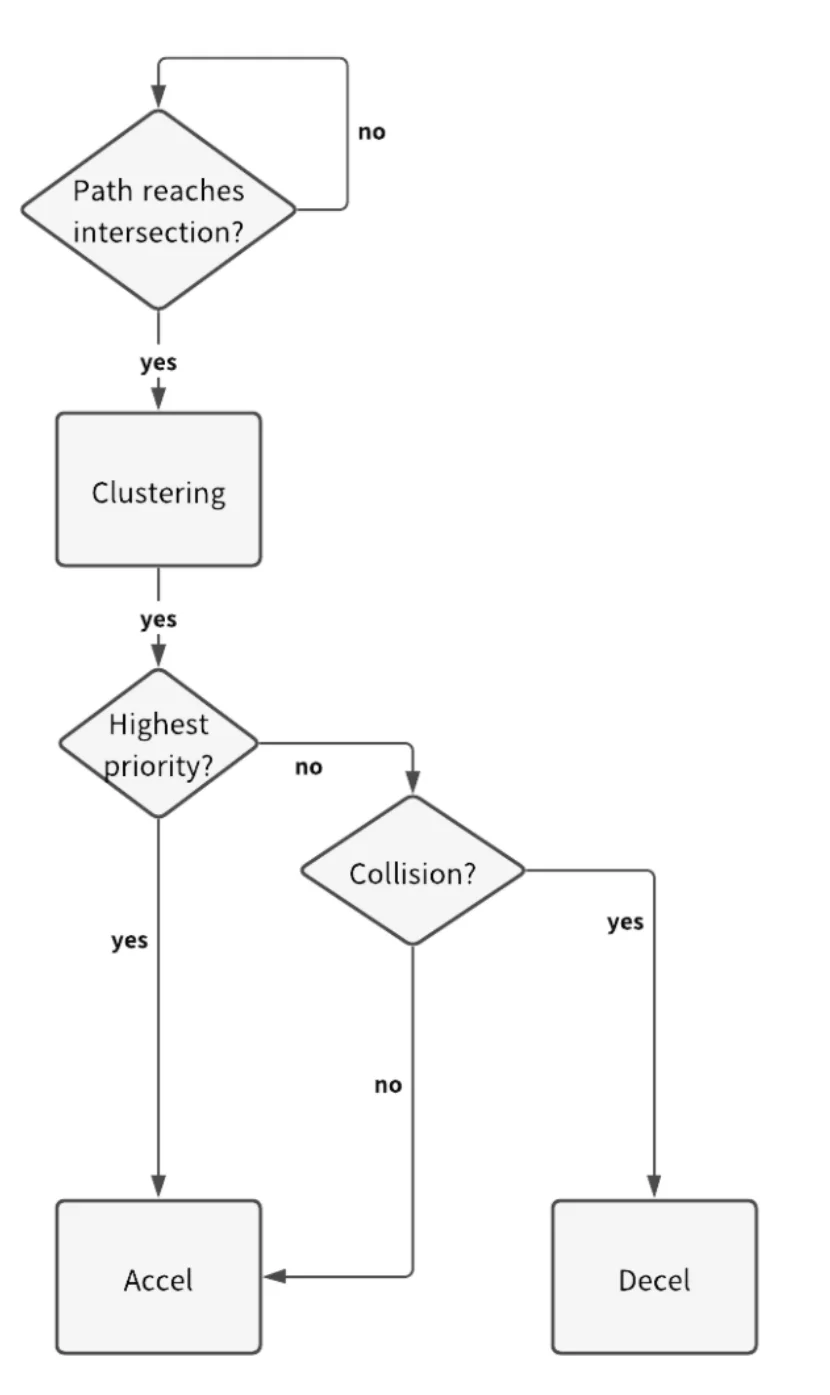
- The thesis coordinates intersection crossings by clustering nearby connected vehicles traveling in the same direction.
- It caps cluster size to limit how long traffic from one direction can occupy the intersection.
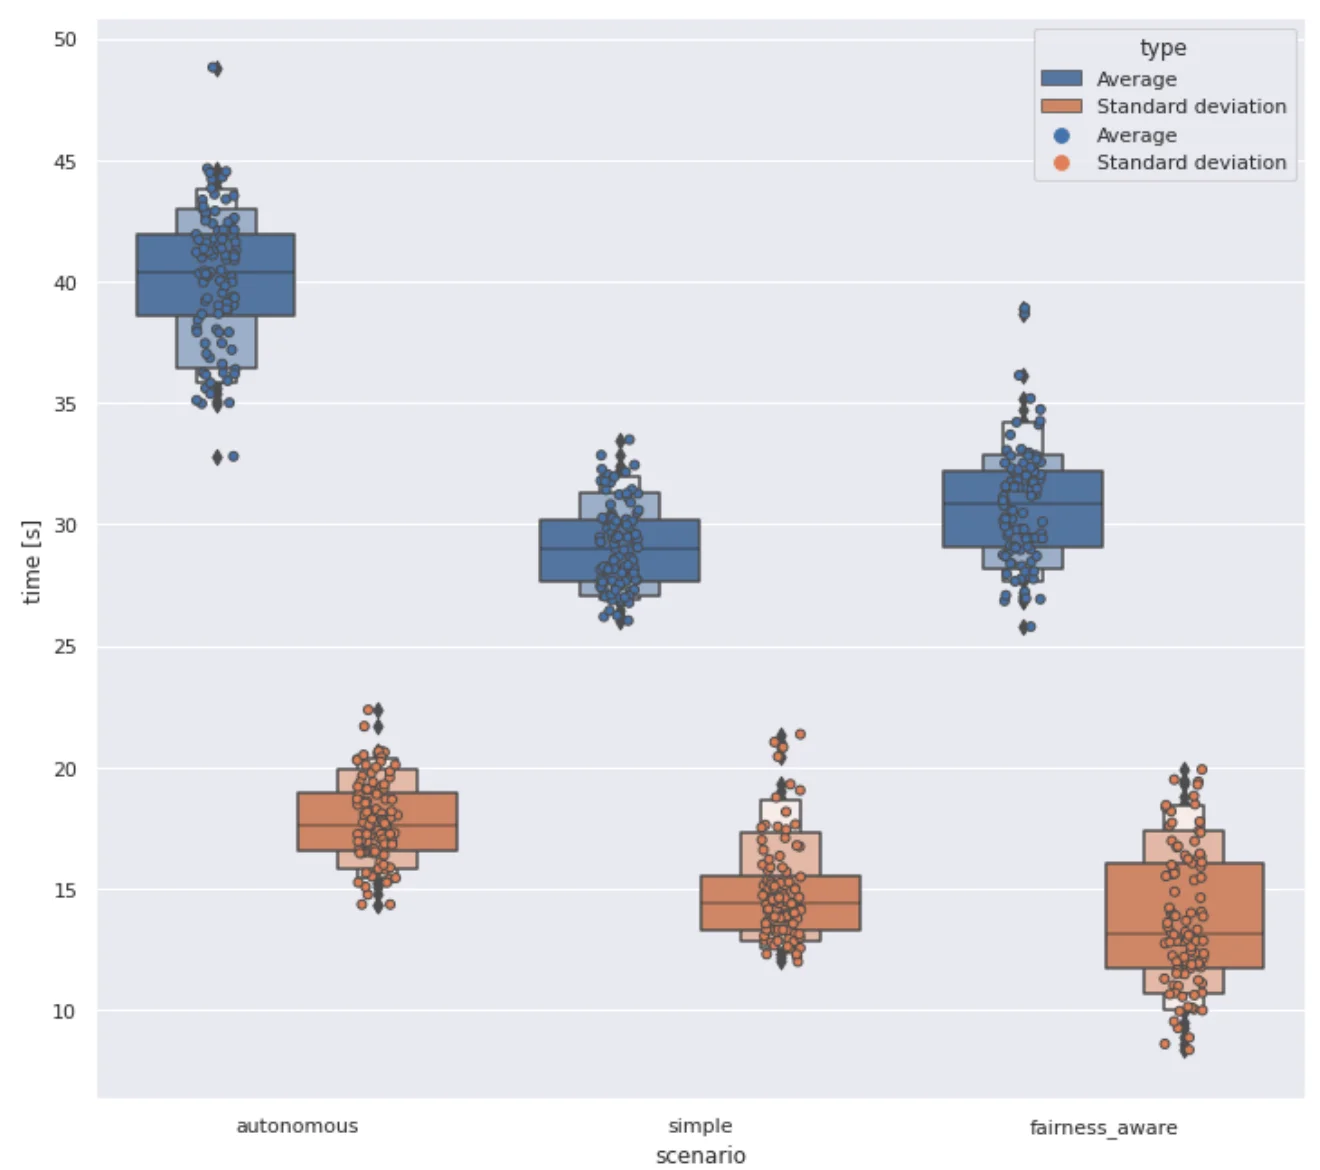
- In Autoware and LGSVL experiments, clustering reduced mean crossing time by 23.4%, and the size cap reduced the variation in crossing times when clusters grew large.
Figures from the paper
How to cite
K. Tsujio, “Fairness-aware Cooperative Path Planning for Efficient Traffic Flow of Connected and Autonomous Vehicles,” in Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo, 2021.
BibTeX
@mastersthesis{Tsujio2021,
  title     = {Fairness-aware Cooperative Path Planning for Efficient Traffic Flow of Connected and Autonomous Vehicles},
  author    = {Kohei Tsujio},
  year      = {2021},
  date      = {2021-09-30},
  urldate   = {2021-09-30},
  school    = {Master's thesis, Graduate School of Information Science and Technology, The University of Tokyo},
  keywords  = {ITS, Thesis},
  pubstate  = {published},
  tppubtype = {mastersthesis}
}