
An Open-Source Modular Benchmark for Diffusion-Based Motion Planning in Closed-Loop Autonomous Driving
29th IEEE International Conference on Intelligent Transportation Systems (ITSC 2026), Naples, Italy, Sep 15, 2026
Summary in three lines
- This open benchmark runs modular diffusion motion planning inside an Autoware ROS 2 closed loop.
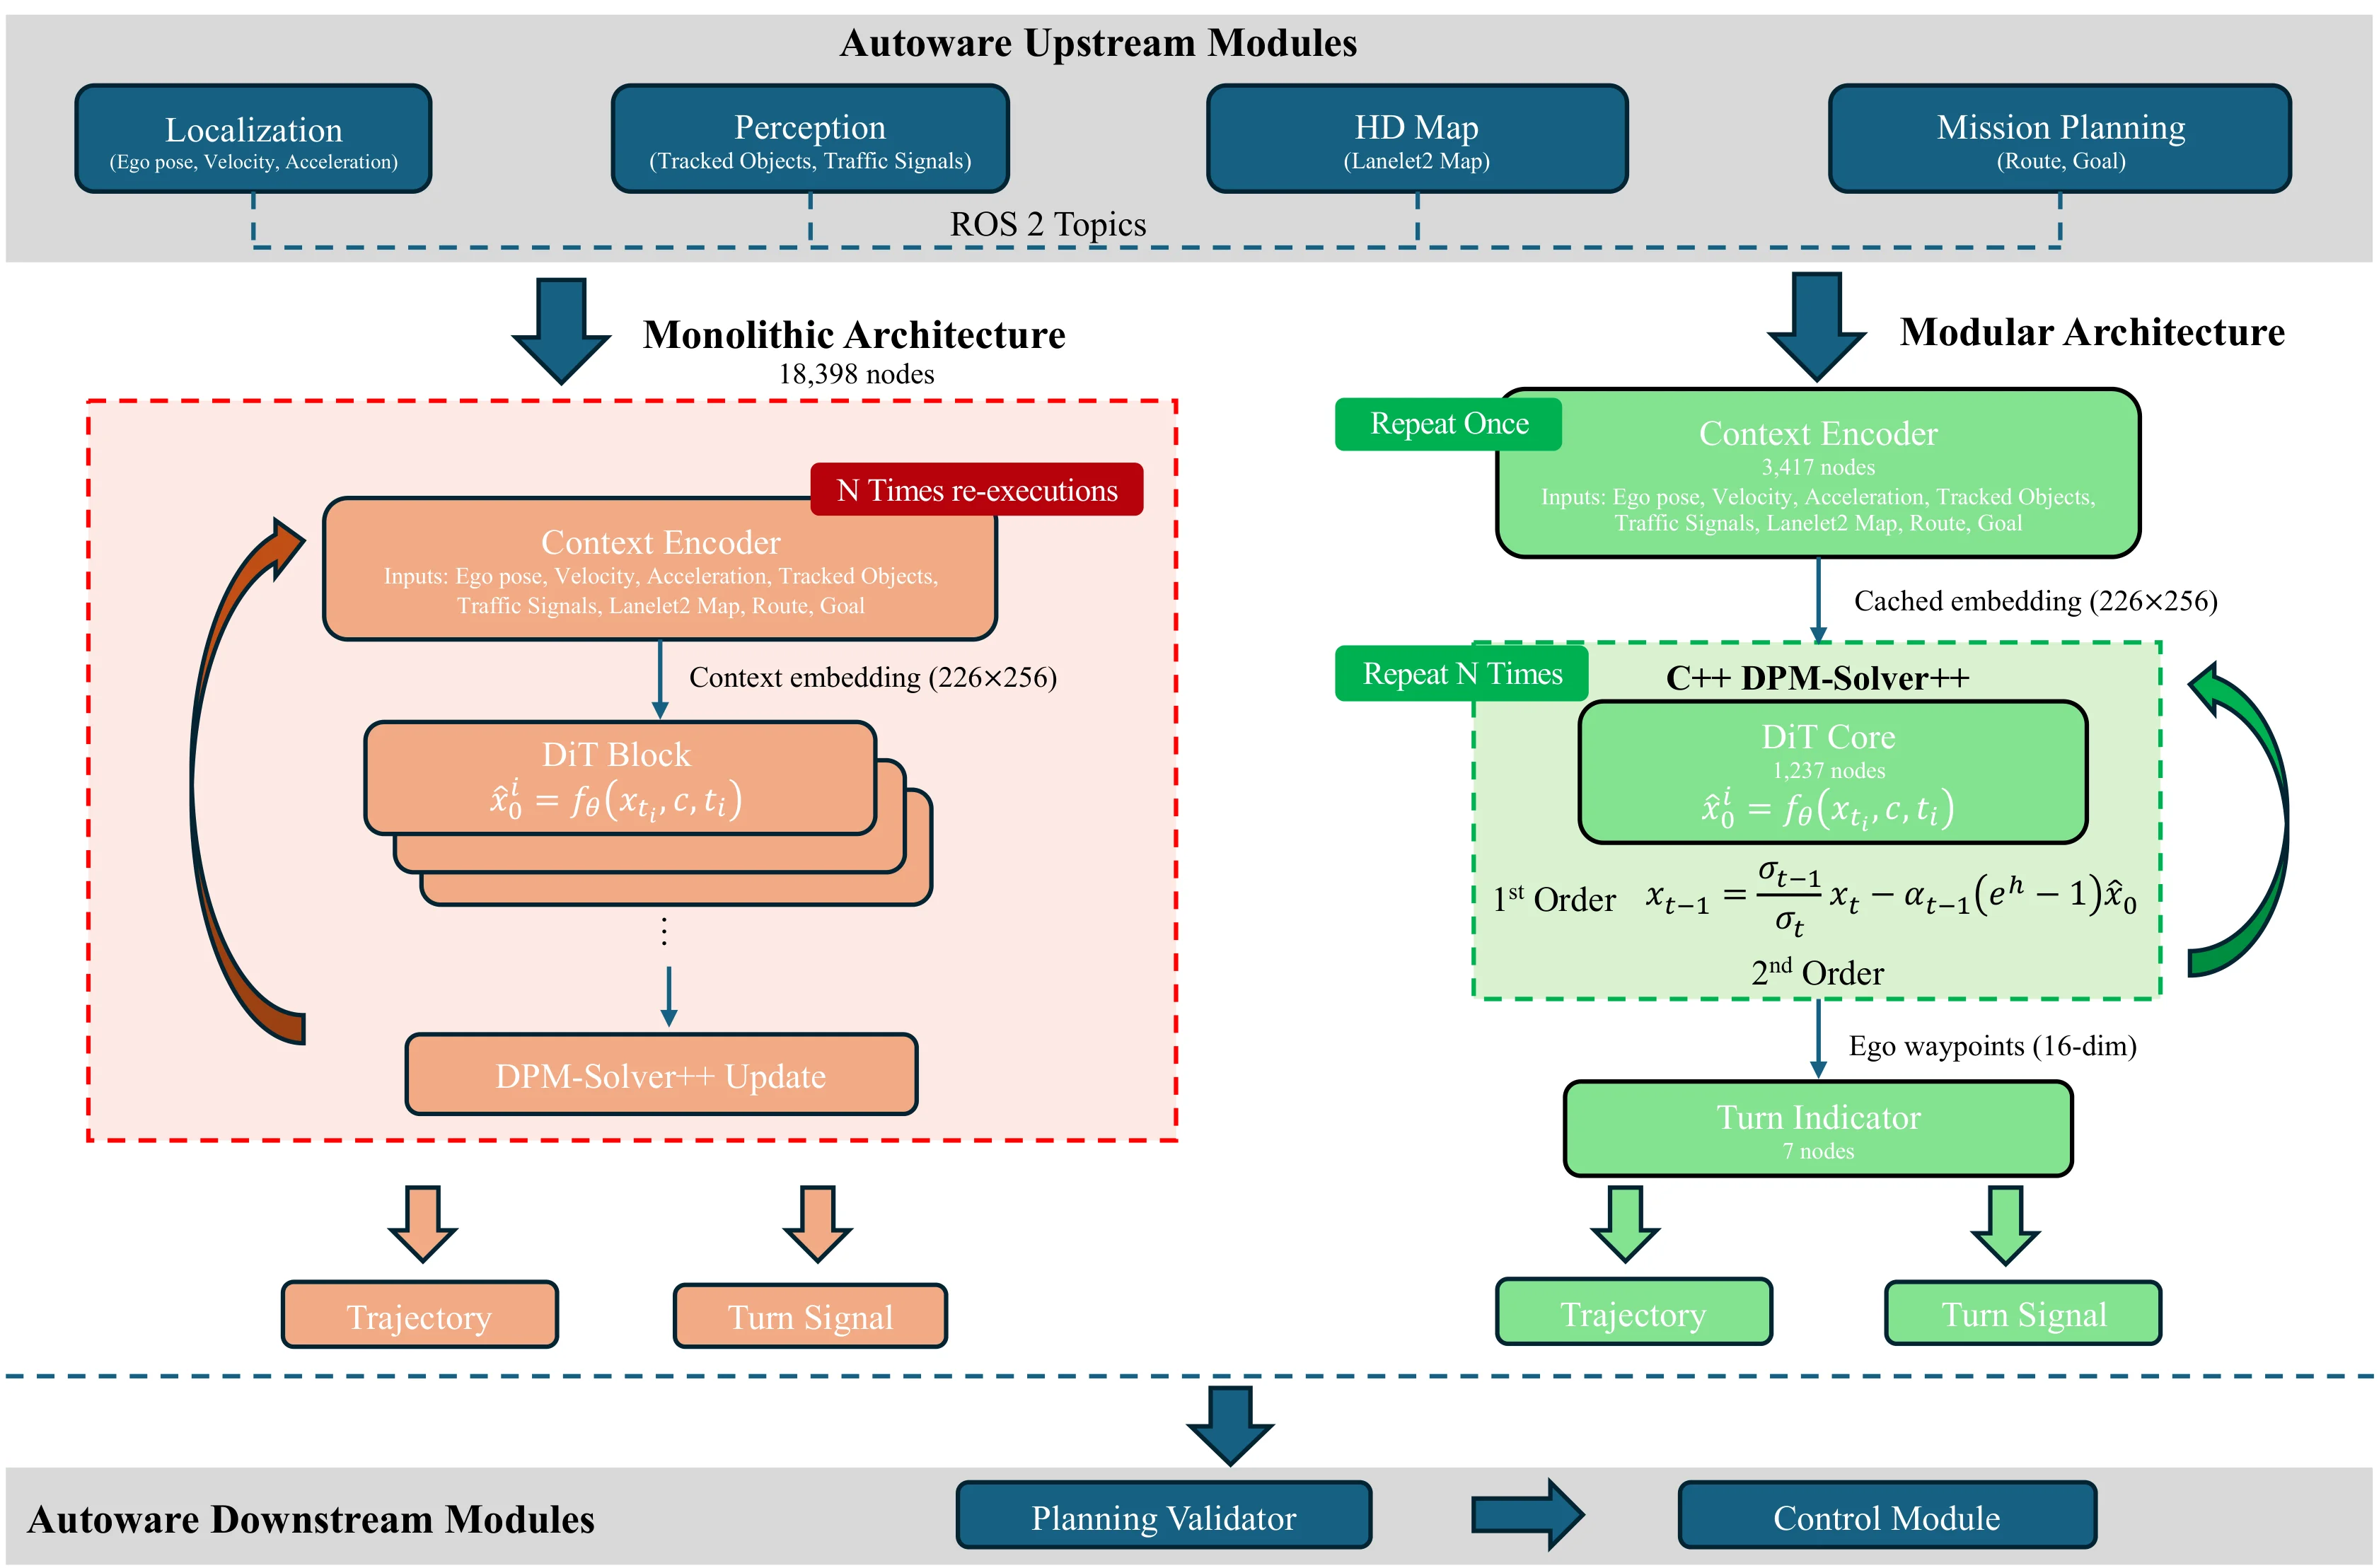
- It splits a monolithic model and moves the denoising solver to C++, enabling caching and runtime solver choices.
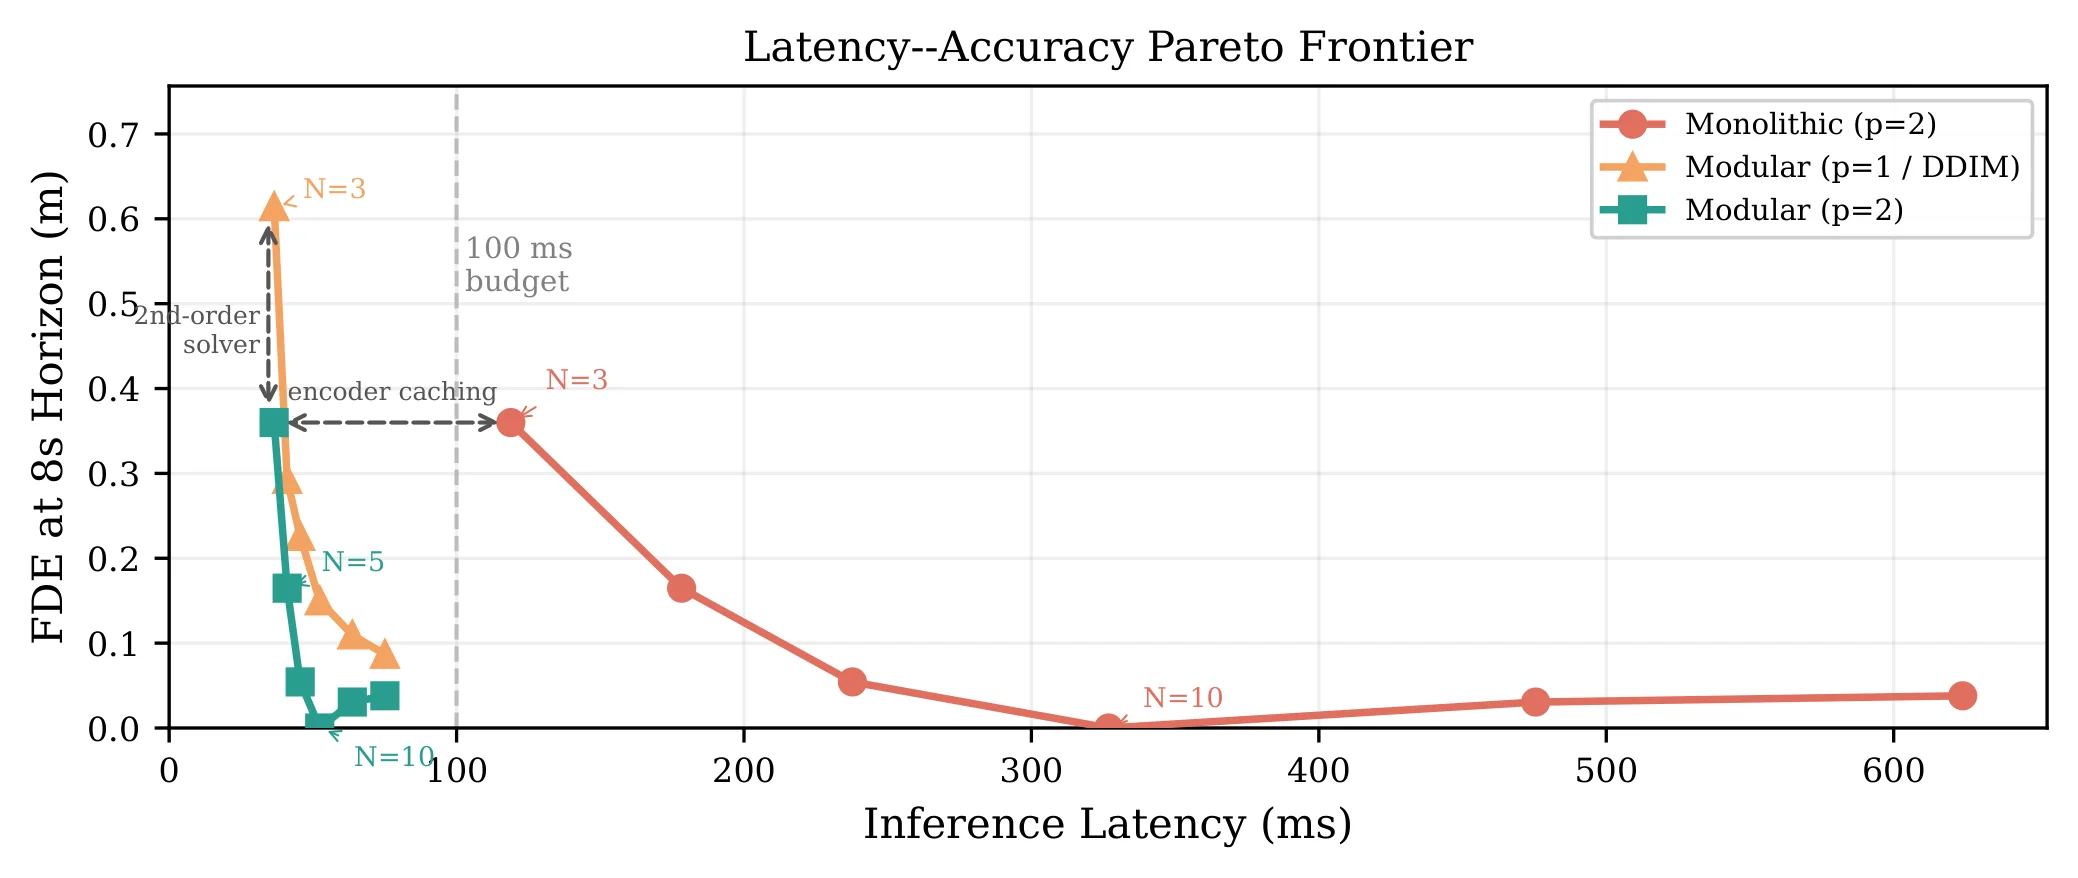
- AWSIM tests quantify the latency gains of caching and the trajectory-error reduction of a second-order solver.
Figures from the paper
Abstract
Diffusion-based motion planners have achieved state-of-the-art results on benchmarks such as nuPlan, yet their evaluation within closed-loop production autonomous driving stacks remains largely unexplored. Existing evaluations abstract away ROS 2 communication latency and real-time scheduling constraints, while monolithic ONNX deployment freezes all solver parameters at export time. We present an open-source modular benchmark that addresses both gaps: using ONNX GraphSurgeon, we decompose a monolithic 18,398-node diffusion planner into three independently executable modules and reimplement the DPM-Solver++ denoising loop in native C++. Integrated as a ROS 2 node within Autoware, the open-source AD stack deployed on real vehicles worldwide, the system enables runtime-configurable solver parameters without model recompilation and per-step observability of the denoising process, breaking the black box of monolithic deployment. Unlike evaluations in standalone simulators such as CARLA, our benchmark operates within a production-grade stack and is validated through AWSIM closed-loop simulation. Through systematic comparison of DPM-Solver++ (first- and second-order) and DDIM across six step-count configurations (N in 3, 5, 7, 10, 15, 20), we show that encoder caching yields a 3.2x latency reduction, and that second-order solving reduces FDE by 41% at N=3 compared to first-order. The complete codebase will be released as open-source, providing a direct path from simulation benchmarks to real-vehicle deployment. Project page:
Related news
How to cite
Y. Li, S. Thompson, Y. Zhang, E. Javanmardi, and M. Tsukada, “An Open-Source Modular Benchmark for Diffusion-Based Motion Planning in Closed-Loop Autonomous Driving,” in 29th IEEE International Conference on Intelligent Transportation Systems (ITSC 2026), Naples, Italy, 2026.
BibTeX
@inproceedings{Yun2026,
  title         = {An Open-Source Modular Benchmark for Diffusion-Based Motion Planning in Closed-Loop Autonomous Driving},
  author        = {Yun Li and Simon Thompson and Yidu Zhang and Ehsan Javanmardi and Manabu Tsukada},
  url           = {https://arxiv.org/abs/2603.01023},
  year          = {2026},
  date          = {2026-09-15},
  urldate       = {2026-09-15},
  booktitle     = {29th IEEE International Conference on Intelligent Transportation Systems (ITSC 2026)},
  address       = {Naples, Italy},
  abstract      = {Diffusion-based motion planners have achieved state-of-the-art results on benchmarks such as nuPlan, yet their evaluation within closed-loop production autonomous driving stacks remains largely unexplored. Existing evaluations abstract away ROS 2 communication latency and real-time scheduling constraints, while monolithic ONNX deployment freezes all solver parameters at export time. We present an open-source modular benchmark that addresses both gaps: using ONNX GraphSurgeon, we decompose a monolithic 18,398-node diffusion planner into three independently executable modules and reimplement the DPM-Solver++ denoising loop in native C++. Integrated as a ROS 2 node within Autoware, the open-source AD stack deployed on real vehicles worldwide, the system enables runtime-configurable solver parameters without model recompilation and per-step observability of the denoising process, breaking the black box of monolithic deployment. Unlike evaluations in standalone simulators such as CARLA, our benchmark operates within a production-grade stack and is validated through AWSIM closed-loop simulation. Through systematic comparison of DPM-Solver++ (first- and second-order) and DDIM across six step-count configurations (N in {3, 5, 7, 10, 15, 20}), we show that encoder caching yields a 3.2x latency reduction, and that second-order solving reduces FDE by 41% at N=3 compared to first-order. The complete codebase will be released as open-source, providing a direct path from simulation benchmarks to real-vehicle deployment. Project page:},
  keywords      = {ITS},
  pubstate      = {published},
  tppubtype     = {inproceedings}
}