
A Feature-Aware Elite-Imitation MARL for Multi-UAV Trajectory Optimization in Mountain Terrain Detection
Drones, Sep 13, 2025
WebsiteDOI: 10.3390/drones9090645
Summary in three lines
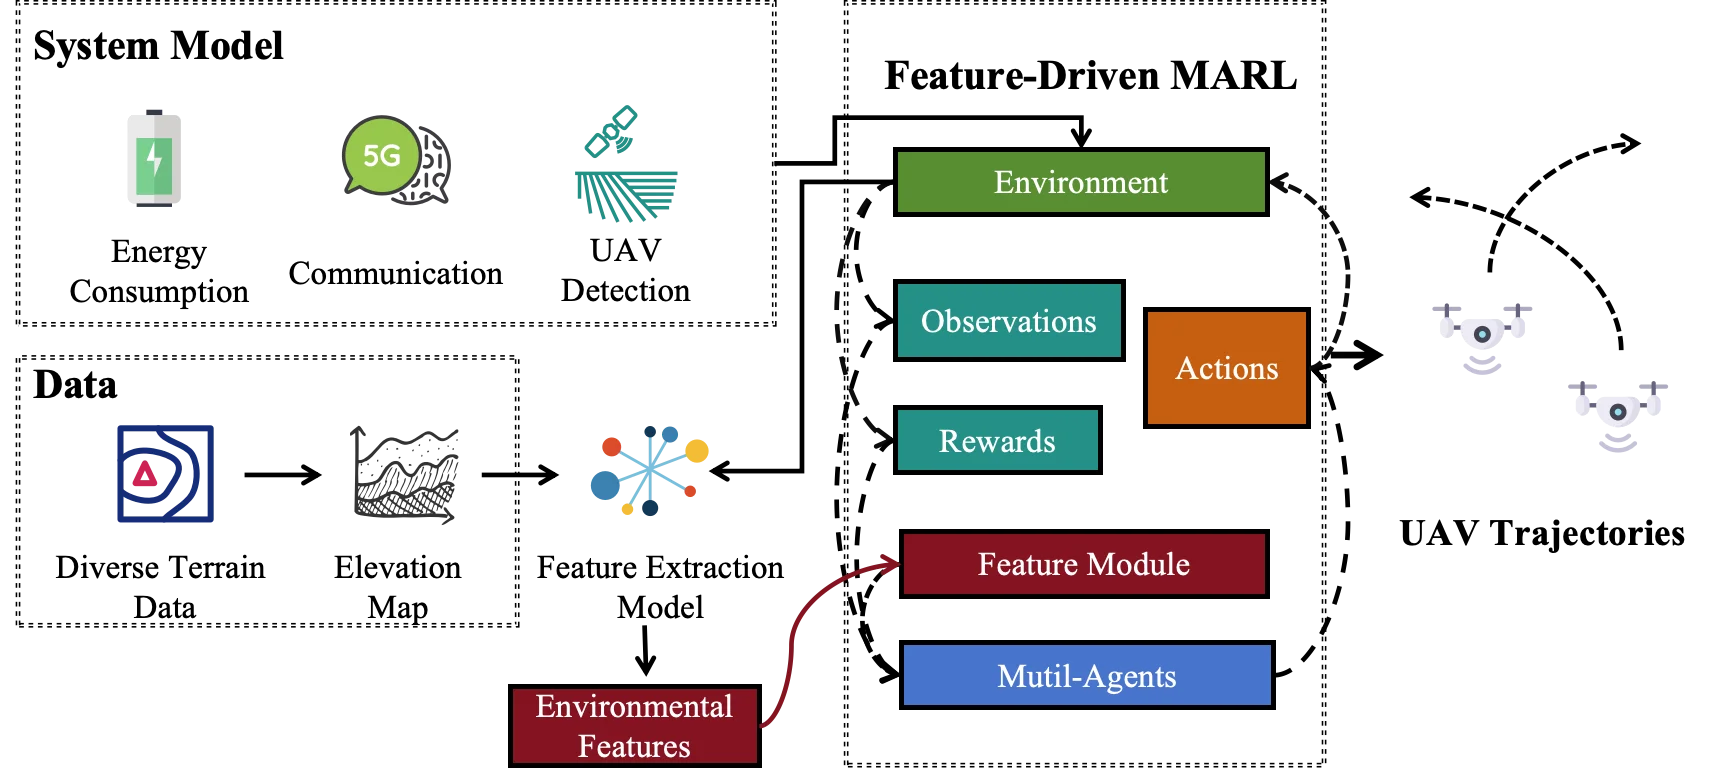
- FA-EIMARL plans coordinated UAV sensing routes over varied mountainous terrain.
- It builds transferable features from partial terrain information and periodically shares strong agents’ policies through elite imitation.
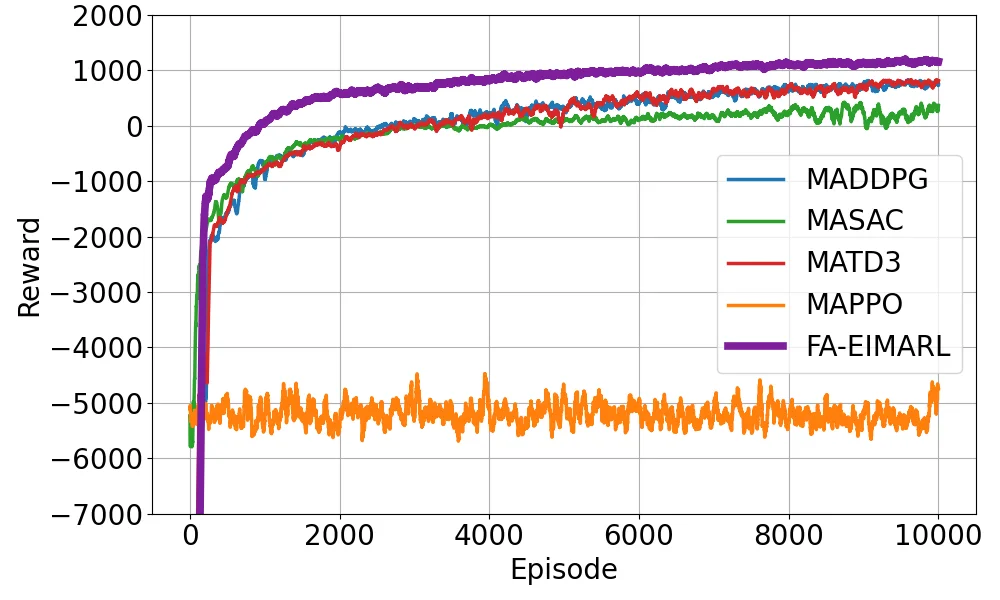
- In simulation it improves reward, convergence and computational efficiency while adapting to different terrain shapes.
Figures from the paper
Video
Related research and software
How to cite
Q. Zhou, Y. Tao, Q. Su, and M. Tsukada, “A Feature-Aware Elite-Imitation MARL for Multi-UAV Trajectory Optimization in Mountain Terrain Detection,” Drones, 2025, doi: 10.3390/drones9090645.
BibTeX
@article{Zhou2025b,
  title         = {A Feature-Aware Elite-Imitation MARL for Multi-UAV Trajectory Optimization in Mountain Terrain Detection},
  author        = {Quanxi Zhou and Ye Tao and Qianxiao Su and Manabu Tsukada},
  url           = {https://www.mdpi.com/2504-446X/9/9/645/pdf},
  doi           = {10.3390/drones9090645},
  year          = {2025},
  date          = {2025-09-13},
  urldate       = {2025-09-13},
  journal       = {Drones},
  keywords      = {Other},
  pubstate      = {published},
  tppubtype     = {article}
}